Aerospace and Defence Manufacturing Robotics
Automated titanium airframe drilling, composite fiber placement (AFP), satellite optical gimbal alignment, and turbine blisk inspection.
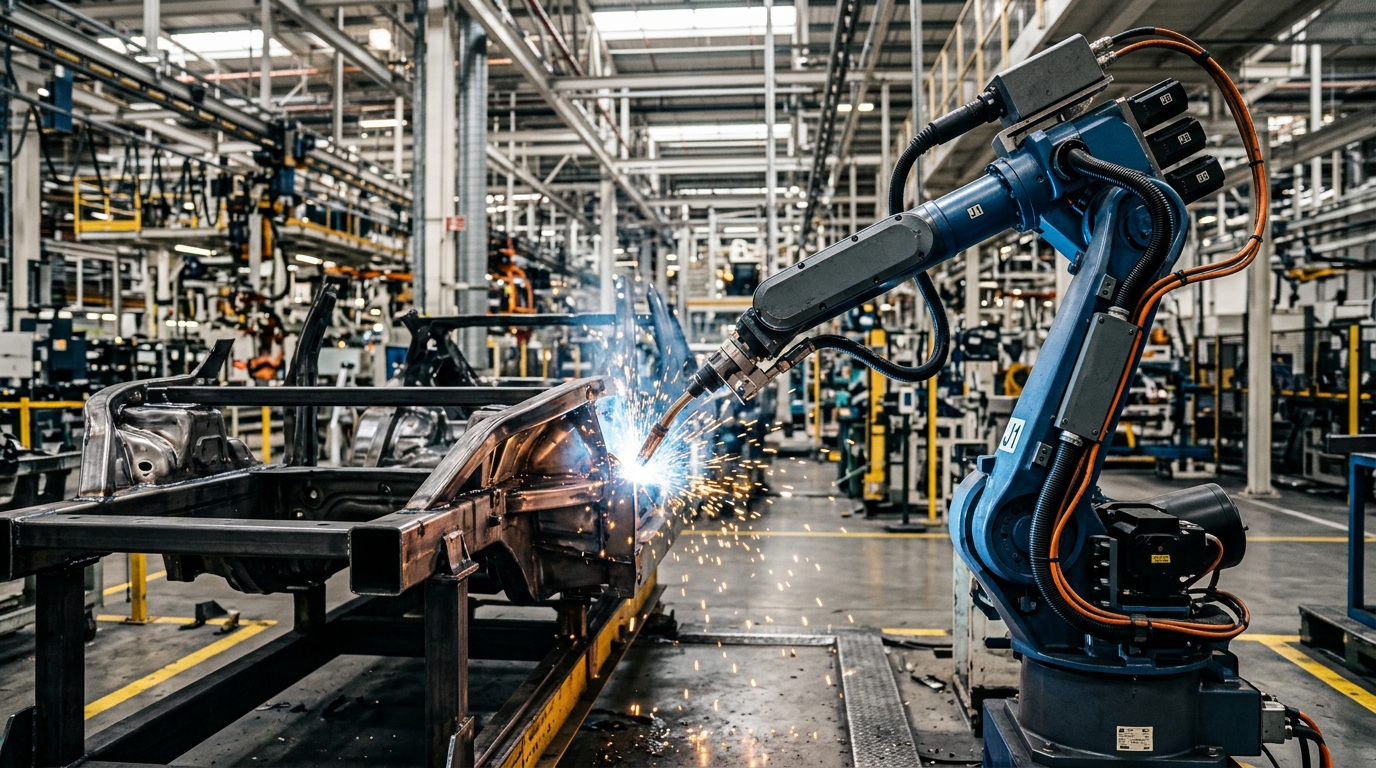
Takt Time Reduction
Down from 78s baseline on EV battery chassis trays
Sub-Millimeter Precision
Closed-loop laser triangulation seam tracking guidance
Max Dynamic Payload
Rigid heavy-duty articulated arm and gantry tooling
Defect Interception & Uptime
Zero unplanned line shutdowns across continuous 24/7 duty
Robotic Applications in Aerospace and Defence Manufacturing
Turnkey robotic workcells, kinematic metrics, and operational architectures deployed across modern aerospace and defence manufacturing manufacturing plants.
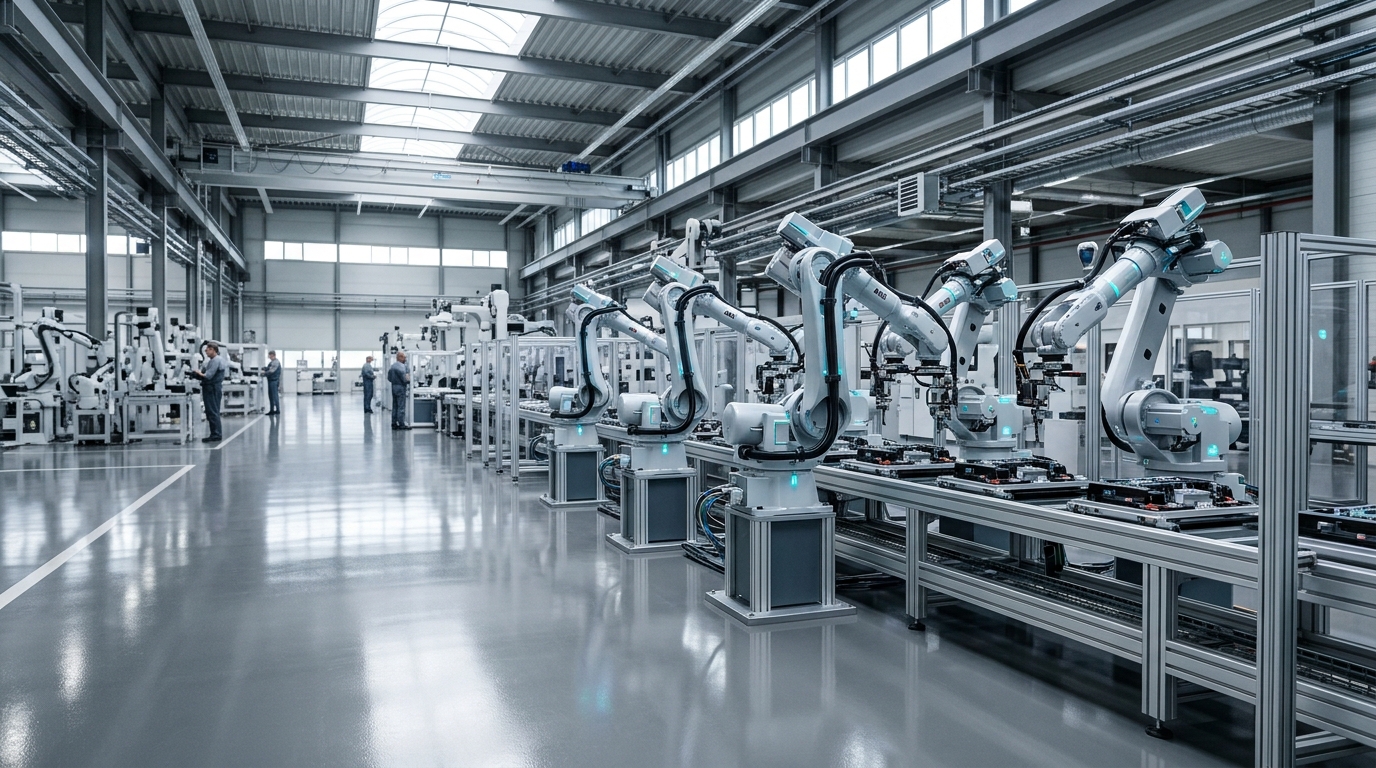
EV Battery Pack Module Assembly Cell
Automated robotic cell executing prismatic and pouch battery cell stacking, busbar laser welding, thermal paste dispensing, and high-voltage isolation testing.
Body-in-White 7th-Axis Gantry Welding
7th-axis linear track robotic spot welding and fiber laser seam joining for automotive body-in-white (BIW) framing and high-strength aluminum door apertures.
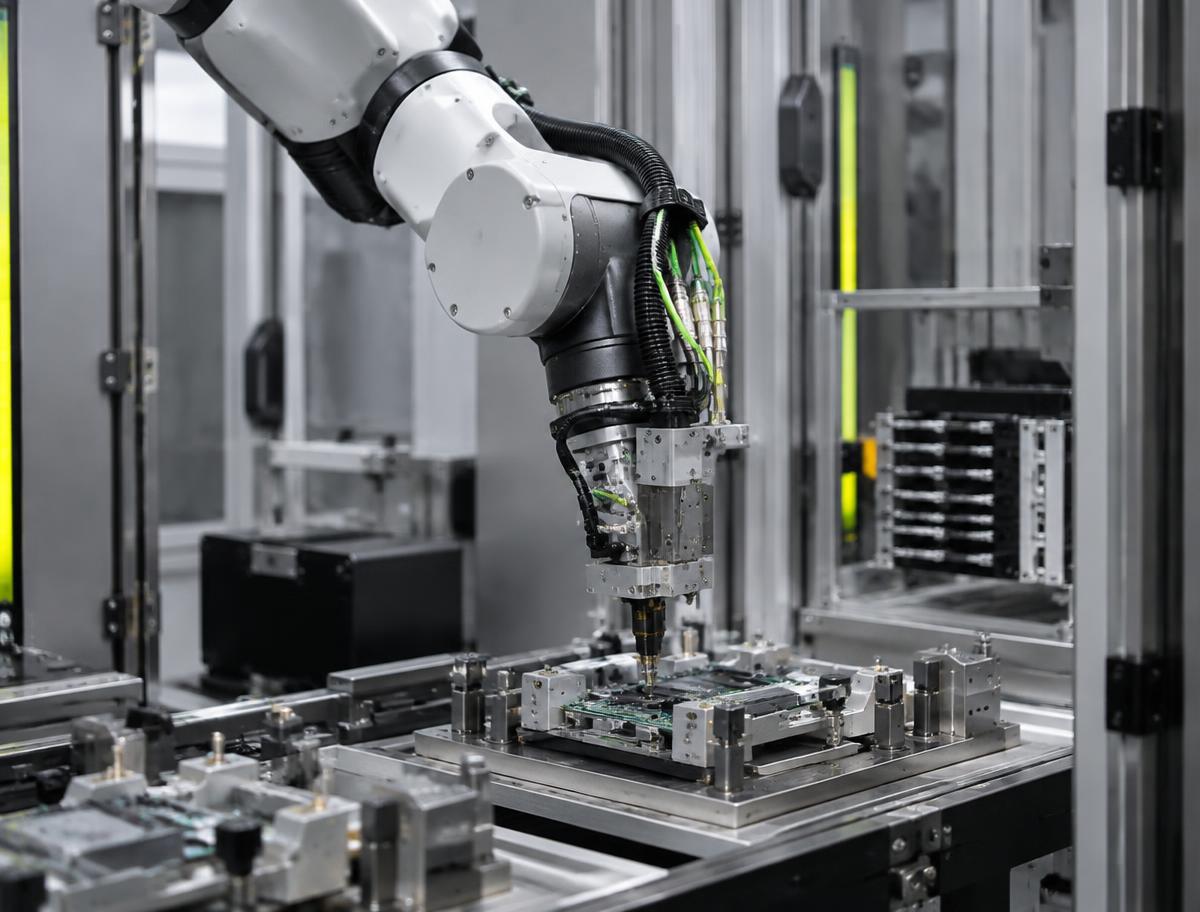
Powertrain & Gearbox Articulated Handling
High-torque articulated handling arms automating engine decking, electric drive unit (EDU) stator-rotor insertion, and transmission pallet transfer.
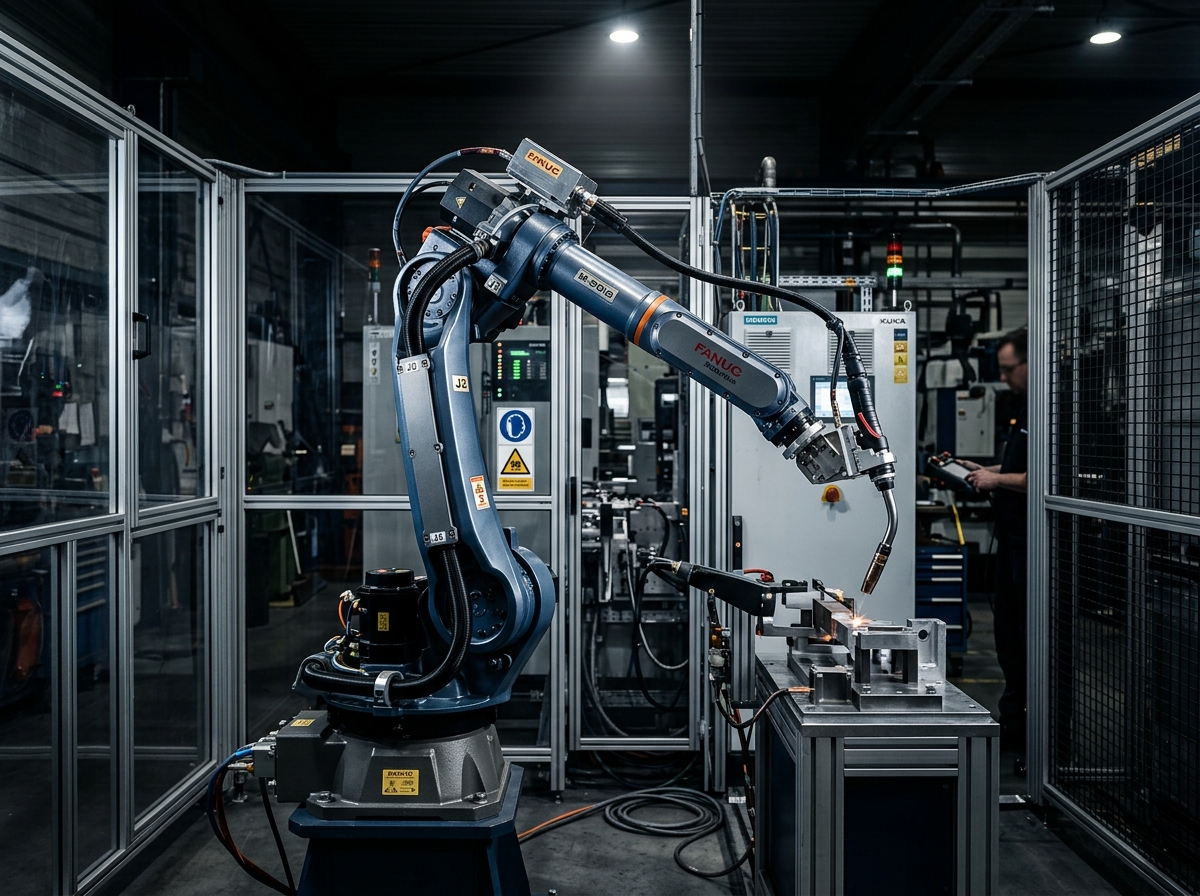
Dual-Gripper CNC Machine Tending Cell
Turnkey robotic tending cell loading and unloading high-tonnage stamping presses and multi-axis CNC milling centers with pneumatic zero-point fixtures.
Select Your Aerospace and Defence Manufacturing Automation Requirement
Toggle between core automation processes to inspect matching kinematic models, payload capacities, cycle times, and directly download engineering CAD files.
INDUS-BAT-K150 (7-DOF)
Engineered specifically for prismatic cell stacking, busbar tightening, and high-voltage module casing insertion with constant 6-DOF force/torque regulation.
Aerospace and Defence Manufacturing Automation Use Cases
Every production task has specific mechanical shock profiles, positioning tolerances, sensing architectures, and functional safety constraints. Explore detailed engineering breakdowns for each verified operation.
Automated Aircraft Wing Skin Drilling & Blind Fastening
Manual drilling of 50,000+ fastener holes per commercial aircraft wing causes operator repetitive strain and hole burrs.
High-stiffness multi-axis mobile gantry robot with end effector carrying automatic drill spindle and fastener feed.
One-shot drilling, countersinking, sealant injection, and blind bolt insertion along 18-meter aircraft wing skin.
Automated Fiber Placement (AFP) for Fuselage Barrels
Manual composite layup of carbon fiber prepreg is slow, labor-intensive, and prone to air pocket voids and fiber misalignment.
Heavy articulated 6-axis robot mounted on linear rail equipped with AFP consolidation head and laser heater.
Continuous consolidation of 16 individual carbon fiber tows (1/4-inch width) onto rotating cylindrical fuselage mandrel with laser heating.
5-Axis Robotic Adaptive Milling & Polishing of Turbine Blisks
Jet engine Inconel integrally bladed rotors (blisks) have complex twisted 3D airfoil contours that deform during machining.
High-accuracy articulated robot with active force compliance end-effector and abrasive belt grinding tool.
Robotic deburring, blending, and mirror polishing of forged titanium/Inconel jet engine turbine compressor blades.
Automated Robotic Laser Depainting of Commercial Aircraft
Chemical paint stripping uses toxic methylene chloride baths that damage aluminum anodization and harm human health.
Mobile omnidirectional scissor-lift robot equipped with long-reach 6-axis arm and laser ablation scanner head.
Pulsed CO2/fiber laser vaporization of polyurethane topcoat and epoxy primer across complete Boeing 777 fuselage.
Satellite Deployable Mesh Antenna Robotic Sewing & Tensioning
Deployable space satellite parabolic antennas require gold-plated molybdenum wire mesh tensioned with micron precision.
Dual collaborative robot arms holding tensioned mesh and sewing micro-ties through composite ribs.
Robotic stitching of micro-mesh onto carbon composite deployable perimeter ring inside aerospace cleanroom.
Composite Missile Solid Rocket Motor Casing Ultrasonic NDT
Sub-surface delaminations in filament-wound carbon/epoxy rocket motor cases can cause catastrophic booster burst during launch.
Twin-column coordinated robot gantry guiding ultrasonic water-jet nozzles along rotating rocket casing.
Phased-array ultrasonic testing (PAUT) of cylindrical rocket motor casings immersed in water squirter inspection booth.
Aircraft Landing Gear High-Tonnage Bushing Cryo Press-Fit
Interference fit of bronze/beryllium bushings into high-strength 300M alloy steel landing gear struts requires extreme alignment.
Heavy articulated robot with insulated cryogenic gripper feeding a 350 kN servo-hydraulic press cell.
Liquid nitrogen chilling of bushings to -196°C and automated insertion into 300M steel landing gear cylinders under 30-ton press.
Jet Engine Titanium Exhaust Nozzle Robotic TIG Welding
Titanium absorbs oxygen, nitrogen, and hydrogen above 400°C, causing weld embrittlement and catastrophic flight failure.
High-precision 6-axis robot with secondary coordinated workpiece turntable and custom trailing inert gas shoe.
Multi-pass pulsed Gas Tungsten Arc Welding (GTAW) of titanium Ti-6Al-4V nozzle petals inside localized trailing gas shield.
Fighter Jet Cockpit Polycarbonate Canopy Precision Drilling
High-performance polycarbonate windshields are sensitive to micro-crazing and stress cracks under drilling friction heat.
High-precision gantry robot carrying specialized cryogenic CO2 spray-cooled diamond drill spindle.
Drilling 300+ precision perimeter fastener holes through 25mm thick stretched acrylic/polycarbonate fighter jet canopies.
Turbine Vane Plasma-Spray Thermal Barrier Coating (TBC)
Turbine blades operate above metal melting temperatures; yttria-stabilized zirconia (YSZ) coating must have exact thickness and porosity.
Articulated robot arm carrying heavy plasma torch (25 kg) inside noise-attenuated acoustic spray booth.
Atmospheric Plasma Spray (APS) depositing 300 µm ceramic thermal barrier coating on gas turbine guide vanes at 10,000°C plasma temp.
Aircraft Nose Radome Microwave Transmission Robotic Testing
Aircraft radar radomes must provide uniform dielectric transparency across X-band and Ku-band without beam refraction errors.
Non-metallic carbon/fiberglass articulated manipulator positioning radar receiver inside radome while transmitter orbits outside.
Multi-axis microwave horn antenna scanning across contoured composite nose cone in anechoic chamber.
Satellite Titanium Fuel Tank Friction Stir Welding (FSW)
Thin-walled titanium propellant tanks cannot tolerate fusion weld porosity that could cause hydrazine leaks in orbit.
Ultra-heavy-duty multi-axis gantry machine with high-rigidity spindle head and backing mandrel.
Solid-state Friction Stir Welding (FSW) of titanium propellant tank hemispheres under 25 kN downward plunging forge force.
Manufacturing Challenges & Robotic Solutions
Comparing conventional production bottlenecks against deterministic multi-axis robotic automation.
Aerospace and Defence Manufacturing Automation Hurdles
Demanding environmental conditions, high-speed cycle times, and precision limits dictate deterministic robotics.
- Extremely tight hole tolerance (H7) and perpendicularity (<0.5°) across 50mm thick titanium-composite stacks
- Massive component scale (fuselage sections >15 meters) demanding ultra-rigid mobile or gantry robotics
- Composite delamination risks caused by excessive tool thrust or thermal breakdown
- Strict AS9100 quality data logging linking every single fastener to aircraft tail numbers
Robotic Automation Potential
High-stiffness mechanical transmission, multi-axis sensory feedback, and real-time motion control.
- Planetary roller screw actuators providing 25 kN feed thrust for one-shot titanium drilling
- High-stiffness RV and cycloidal gearheads eliminating tool chatter during titanium milling
- Laser projection guided Automated Fiber Placement (AFP) heads laying composite prepreg tapes
Accelerate Aerospace and Defence Manufacturing Automation
Access our specialized kinematics sizing tools, discuss payload vs cycle takt trade-offs, and receive 3D CAD space-claim models verified for this manufacturing discipline.
Connected Ecosystem
Other Manufacturing Sectors
Related Industrial Sectors
- Automotive
High-precision robotics meeting the extreme uptime and sub-millimeter tolerances of modern EV & automotive production.
- Electronics
Sub-micron repeatability and cleanroom-compliant automation for high-density electronic assemblies.
- Manufacturing
Rugged robotic automation engineered for high-uptime machine tending and harsh factory environments.