Machine Integration
Interfacing standalone production machinery, robotics, sensors, and legacy controllers into deterministic, high-throughput manufacturing cells.
Unify disparate OEM machines, PLCs, robotic cells, and safety loops into a synchronized plant subsystem with centralized HMI and MES telemetry.
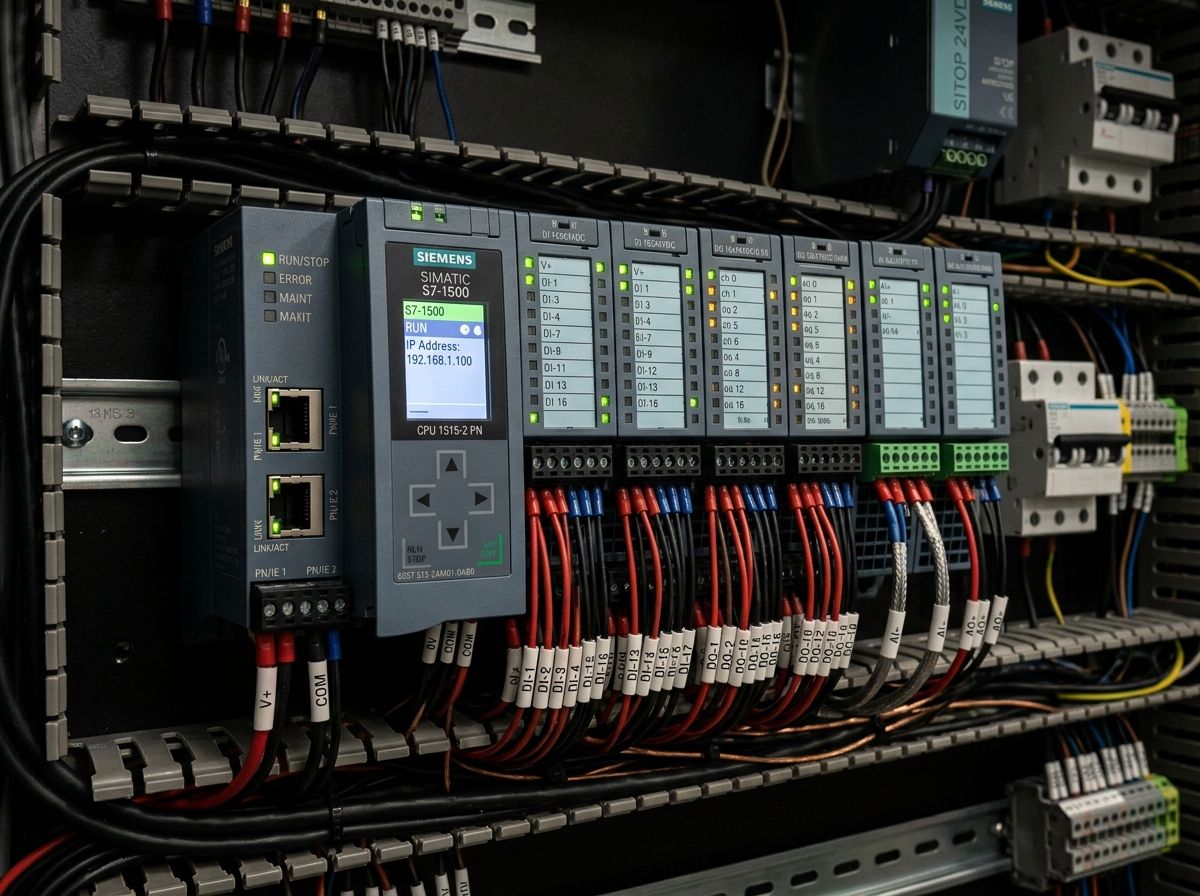
Machine Integration package engineered with deterministic feedback loops, certified safety architecture, and full test logs.
The Industrial Integration Challenge
Most manufacturing plants operate a patchwork of isolated machines delivered by different OEMs across different decades. These islands of automation speak incompatible communication protocols, use contradictory safety interlock schemes, and lack coordinated pacing. The result is continuous line starvation, manual handling bottlenecks, and zero centralized visibility into production bottlenecks.
What The Solution Includes
We define clear engineering boundaries so plant managers and system integrators know exactly what INDUS designs, supplies, and commissions versus what requires plant facility hookup.
Engineered & Supplied by INDUS
Delivered fully tested and validated- Multi-vendor PLC interfacing (Siemens S7, Rockwell ControlLogix, Beckhoff, Omron)
- Industrial communication fieldbus gateways (EtherCAT, PROFINET IRT, EtherNet/IP, Modbus TCP)
- Hardware safety circuit bridging and emergency interlock coordination
- Centralized operator HMI panel PCs with unified recipe management and fault diagnostics
- Edge IIoT gateways for OPC UA and MQTT telemetry streaming to SCADA / MES
- Legacy machine retrofit kits (optical sensor integration, spindle monitoring, digital I/O isolation)
Customer Plant Interfaces Required
Facility supplies and utility connections- →Access to existing machine electrical cabinets and OEM PLC schematics/source code
- →Dedicated industrial Ethernet switch ports on customer plant network (IT/OT boundary)
- →Designated machine maintenance window for physical sensor installation and signal wiring
- →Customer automation engineer sign-off on machine cycle handshake timing
Machine Integration Architecture & Signal Flow
Interface Boundary Definition
Map all machine electrical I/O, OEM safety circuits, and digital registers; define safe handshaking state machines.
Verified Engineering Specifications
Performance parameters governed by international standards (ISO, IEC, DIN). Numerical values represent verified laboratory test benchmarks and require confirmation for specific workpiece payloads.
| Engineering Parameter | Benchmark Value | Governing Standard | Technical Qualification |
|---|---|---|---|
| Inter-Network Handshake Latency | < 2.0 ms | Real-Time Fieldbus Couplers | Deterministic cyclic data exchange across independent protocol domains. |
| Supported Industrial Protocols | EtherCAT, PROFINET, EtherNet/IP, Modbus TCP | IEC 61158 & IEEE 802.3 | Native driver support for Siemens, Rockwell, Beckhoff, Omron, and Schneider controllers. |
| Safety Interlock Response | < 15 ms | ISO 13849-1 Cat 4 PLe | Total time from peripheral safety trip to power cutoff on hazardous motion axes. |
| Data Telemetry Protocol | OPC UA / MQTT with Sparkplug B | IEC 62541 Standard | TLS 1.3 encrypted data channel with certificate-based authentication. |
| Legacy Signal Isolation | 2,500 VRMS Galvanic Isolation | DIN EN 60747-5-2 | Protects modern PLC modules from voltage spikes or ground loops in older machines. |
| HMI Enclosure Rating | IP65 Front Bezel / NEMA 4X | IEC 60529 | Resistant to coolant spray, oil mist, and industrial cleaning solvents. |
Typical Applications & Use Cases
Representative production environments where this system configuration eliminates manual handling and improves takt pacing.
Linking CNC milling centers with robotic tending arms and wash stations
Engineered with customized tool flanging, cycle interlocking, and dedicated safety boundaries.
Automotive stamping press to assembly conveyor interlocked synchronization
Engineered with customized tool flanging, cycle interlocking, and dedicated safety boundaries.
Retrofitting legacy packaging machinery with modern recipe control and telemetry
Engineered with customized tool flanging, cycle interlocking, and dedicated safety boundaries.
Multi-cell safety perimeter consolidation in plastics injection molding plants
Engineered with customized tool flanging, cycle interlocking, and dedicated safety boundaries.
Factory-wide MES data collection and OEE visualization across legacy lines
Engineered with customized tool flanging, cycle interlocking, and dedicated safety boundaries.
Plant Interfaces & Utility Requirements
Physical prerequisites required on the customer shop floor to enable rapid installation and commissioning.
400 VAC, 3-Phase + PE, 50/60 Hz (±10% allowable ripple)
Dedicated breaker recommended; 24 VDC / 20A redundant power for field sensors.
EtherCAT CoE or PROFINET IRT (Cat 6A shielded industrial Ethernet)
Deterministic master cycle rate ≤ 1.0 ms with distributed clocks enabled.
0.6 – 0.8 MPa (6 – 8 bar) clean dry air (ISO 8573-1:2010 Class 2:4:2)
Flow rate ≥ 150 NL/min with digital threshold interlock.
ISO 13849-1 Performance Level e (PLe) / Cat 4 compliant circuit
Dual-channel emergency stops, interlocked gates, and optional optical light curtains.
Testing, FAT & SAT Validation
Every system undergoes rigorous multi-phase verification before dispatch and after on-site installation.
I/O Loop & Signal Verification
Point-to-point electrical ringing of all discrete and network interface points between machines.
100% correct signal mapping, zero ground loop noise, verified galvanic isolation.
Handshake State Machine Testing
Simulating normal operating cycles, part present variations, and buffer full conditions.
Zero deadlock states; deterministic cycle handshakes completed within allocated timing window.
Fault Injection & Emergency Stop Audit
Intentional triggering of peripheral E-Stops, door interlocks, and network disconnections.
Controlled safe stop on all coordinated axes; zero tool collisions or uncontrolled coasting.
Site Acceptance Testing (SAT)
Live production run integrating all upstream and downstream machines under full factory load.
Target line takt achieved; real-time OEE and fault metrics verified in plant SCADA system.
Connected Product Ranges
Standard catalogue components verified for compatibility with this solution architecture.
High-Performance IPC Robot Controller
Multi-Fieldbus Gateway • 250 µs Cycle • Intel Core i7
Autonomous Mobile Robot Navigation & Fleet Gateway
VDA 5050 v2.0 • Natural Feature SLAM • Dual CAN-FD
6-Axis Robot Controller Cabinet with Teach Pendant
Integrated Safety PLC • Dual EtherCAT • Touch Pendant
Multi-Axis Cartesian Linear Gantry Robot
Line-linking transfer • Payloads 100-500 kg
Frequently Asked Questions
Engineering specifics regarding lead times, PLC protocols, safety compliance, and commissioning.
Deploy Machine Integration with Guaranteed FAT/SAT
Speak directly with our motion control application engineers for a detailed torque, inertia ratio, cycle takt simulation, and custom CAD space-claim envelope.
Explore Other Solution Packages
Smart Waste Collection Robot
An intelligent robotic waste collection system designed to identify, locate, and collect garbage automatically across urban, commercial, and campus environments.
Hospital Delivery Robot
An autonomous hospital delivery robot that transports medicines, medical supplies, documents and reports between hospital departments, reducing nurse workload and expediting pharmacy dispatch.
Agricultural Crop Monitoring Robot
An AI-powered agricultural robot that monitors crop health using cameras, sensors and computer vision, identifying early blight and pest threats across commercial greenhouses and open fields.