Engineering Intelligent Motion. Building the Future of Automation.
From Precision Motion to Physical AI.
INDUS Industrial Robotics bridges foundational mechanical engineering with modern embodied intelligence. We design, manufacture, and integrate multi-axis robotic arms, zero-backlash joint reducers, autonomous mobility platforms, and deterministic motion controllers that enable high-uptime, zero-defect industrial manufacturing.
Lost Motion Backlash
Quality Architecture
Deterministic Control
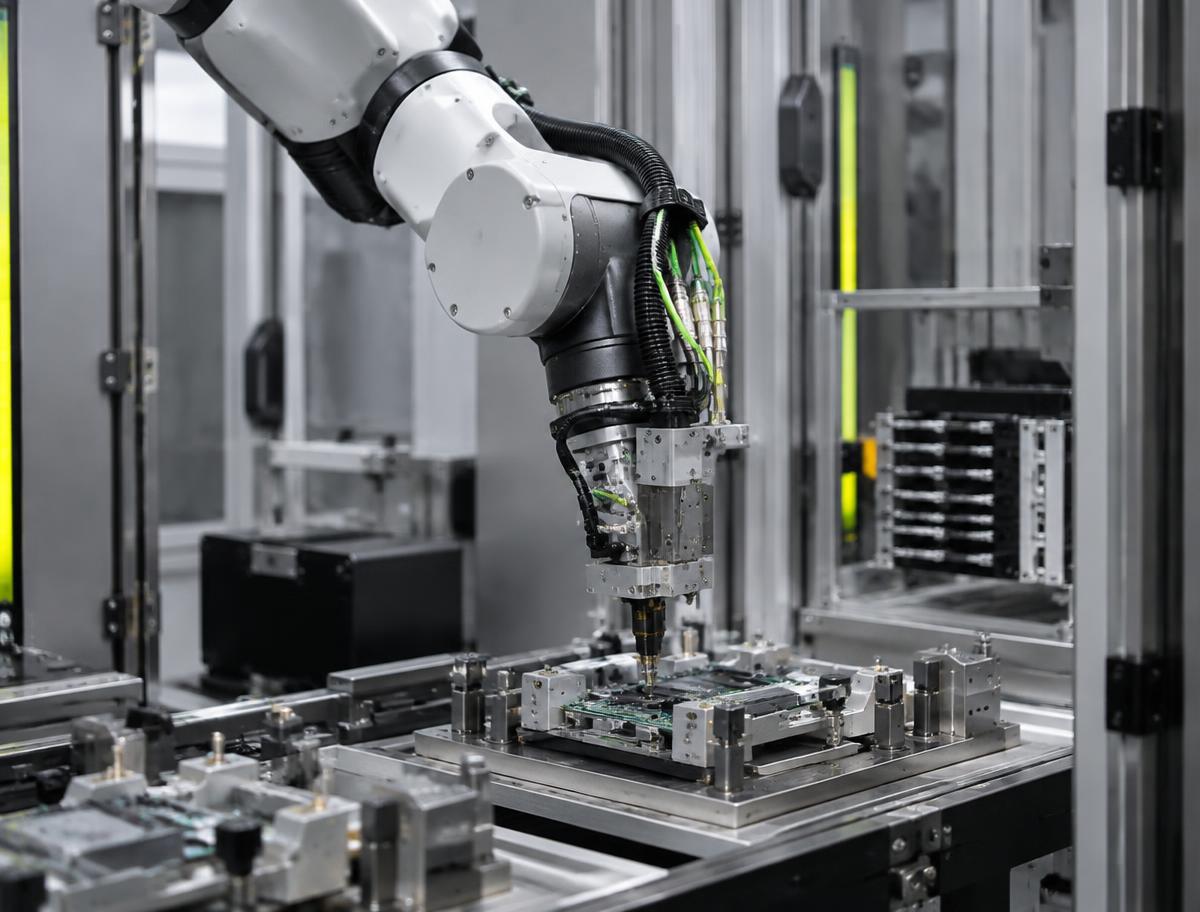
Continuous 24/7 duty cycles verified across multi-axis kinematic envelopes.
Engineering Precision Motion & Industrial Robotics
INDUS is an industrial robotics and precision motion technology engineering company. We specialize in designing and delivering high-performance robotic manipulators, zero-backlash mechanical gearheads, and intelligent motion subsystems that power modern automation.
Focus on Industrial Robotics & Kinematics
Modern manufacturing demands deterministic accuracy and rugged mechanical repeatability. INDUS develops 6-axis articulated arms, collaborative cobots, delta packaging manipulators, and autonomous mobile wheel platforms built specifically to withstand continuous multi-shift production.
Precision Motion Engineering
At the heart of every robotic joint is our precision actuation chain. We engineer strain-wave harmonic reducers, high-rigidity RV cycloidal drives, low-inertia frameless brushless torque motors, and optical absolute encoders that eliminate backlash and provide sub-arcminute lost motion.
Our Role in Industrial Automation
We partner with machine builders, system integrators, and plant engineers as a foundational mechatronics partner. By combining open fieldbuses (EtherCAT, PROFINET IRT) with standardized mechanical ISO interfaces, we help customers accelerate machine build schedules, eliminate kinematic integration risks, and ensure predictable factory floor uptime.
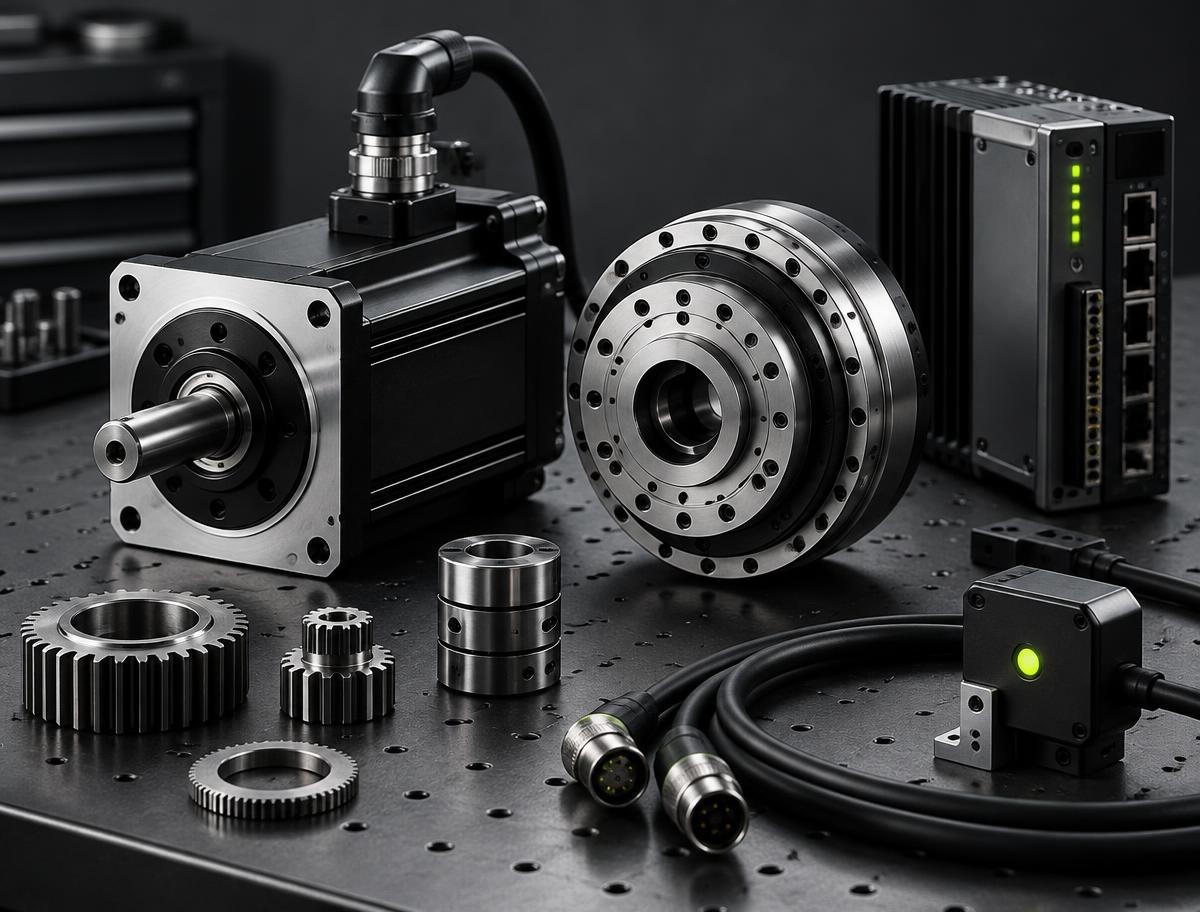
Every component is engineered from physical first principles to optimize inertia match, torsional stiffness, and thermal dissipation.
Our Engineering Mission & Vision
Founded on physical first principles, INDUS empowers industrial manufacturing with deterministic precision motion subsystems, intelligent robotic workcells, and adaptive physical AI architectures.
Our Mission
To engineer deterministic, high-durability robotics, precision motion subsystems, and turnkey industrial automation platforms that maximize manufacturing uptime, repeatable accuracy, and operational efficiency for industrial enterprises worldwide.
Our Vision
To serve as the global kinematic and robotic engineering foundation for next-generation smart factories, agile production cells, and physical AI systems, advancing embodied intelligence from experimental labs to industrial reality.
Six Engineering Pillars
The core principles governing every joint, actuator, controller, and algorithm developed by INDUS.
Precision Engineering
Deterministic mechanical architectures, zero-backlash strain-wave gearing, and sub-micron optical encoders ensuring repeatable accuracy across multi-shift production.
Intelligent Automation
Deterministic fieldbuses (EtherCAT CoE, PROFINET IRT) executing cyclic synchronous motion loops with sub-microsecond jitter and synchronized multi-axis coordination.
Robotics Innovation
Bridging digital simulations in NVIDIA Isaac Sim with physical hardware, testing adaptive trajectories, and implementing spatial AI models for autonomous tasks.
Industrial Reliability
High-power brushless actuators, sealed IP67/IP69K housings, and thermal soak validation guaranteeing high uptime in harsh industrial environments.
Application-Driven Design
Custom gear reductions, tailored flange adapters, and torque-inertia matching calculated specifically for the real mass, reach, and speed requirements of the workcell.
Human-Centred Engineering
Certified functional safety (ISO 13849-1, Cat 4 / PL e), dual-channel Safe Torque Off (STO), and power-force limiting mechanisms enabling safe operator interaction.
Engineering the Complete Robotics and Automation Stack
INDUS unifies mechanical joint engineering, power electronics, deterministic motion control, distributed robotics software, physics simulation, and turnkey factory integration.
Industrial Robotics
High-speed 6-axis articulated arms, collaborative cobots, and high-throughput delta manipulators engineered for continuous welding, machine tending, and micro-assembly.
Physical AI & Humanoid Robotics
Vision-Language-Action (VLA) models, spatial reasoning representations, and torque-controlled humanoid joint actuation for unstructured industrial environments.
Precision Motion Systems
Zero-backlash strain-wave gearheads, high-rigidity RV cycloidal drives, and precision planetary gearboxes delivering sub-arcminute lost motion accuracy.
Simulation & Digital Engineering
Digital twin creation, dynamic cycle-time simulation, reach envelope validation, and physics-based load emulation to de-risk deployments prior to steel cutting.
Perception & Computer Vision
Real-time 3D depth sensors, structured-light surface profilometry, and low-latency feature extraction for automated bin-picking, seam tracking, and metrology.
Motion Control & Mechatronics
High-density frameless BLDC torque motors, sub-microsecond synchronized multi-axis fieldbuses, and advanced field-oriented current control algorithms.
Robotics Software Platforms
Enterprise ROS2 architecture, real-time DDS middleware, modular microservices, hardware abstraction layers (HAL), and cloud telemetry connectivity.
Industrial Automation & Integration
Turnkey robotic cells, customized vacuum/pneumatic end-effectors, safety perimeter architectures, and field integration with industrial PLCs.
Robotics Reliability & Testing
Continuous dyno endurance benchmarking, CMM metrology verification of gear geometries, and dynamic path repeatability validation per ISO 9283 standards.
Manufacturing Infrastructure & Quality Metrology
Every robotic reducer, harmonic cup, servo actuator, and manipulator assembly is manufactured and validated under strict process controls. Our metrology facility benchmarks gear tooth runout, torsional backlash, and motor efficiency against international standards.
Documented quality management across precision machining, cleanroom assembly, and endurance testing.
Coordinate Measuring Machines verifying sub-micron pitch accuracy and tooth flank profiles.
Automated dynamic dynamometer test rigs validating continuous torque, efficiency curves, and thermal rise.
Laser tracking verification of manipulator pose repeatability and path velocity constancy.
Serialized Quality Traceability
Every component shipped from INDUS manufacturing facilities is serialized and benchmarked against rigorous mechanical and electrical directives, backed by individual inspection reports.
Our Engineering Philosophy
Inspired by deterministic physics, we believe robotics and automation should deliver uncompromised mechanical repeatability, structural longevity, and software transparency.
Engineering First
We design from physical first principles. Every torque curve, gear ratio, and stiffness calculation is verified through mathematical modeling before fabrication.
Precision by Design
Precision cannot be an afterthought. Sub-micron encoder feedback, zero-backlash flexsplines, and stiff structural castings are engineered into the fundamental geometry.
Safety and Reliability
Industrial automation demands predictable behavior. Functional safety interlocks, fail-safe holding brakes, and thermal stress buffers are built into every subsystem.
Application-Driven Innovation
Technology exists to solve manufacturing bottlenecks. We develop hardware and software tailored directly to cycle times, washdown environments, and payload demands.
Intelligent Automation
Deterministic hardware combined with physical AI and adaptive trajectory planning gives robotic cells the capability to handle variability without sacrificing speed.
Continuous Improvement
Real-world operational telemetry feeds back into mechanical refinement, firmware optimizations, and life-cycle support for existing and future deployments.
Robotics Safety & Reliability Architecture
Treating safety, fault containment, and hardware longevity as foundational engineering disciplines. Our robotics architectures prioritize sub-millisecond trip latency, fail-safe holding brakes, and continuous dynamic health telemetry.
Functional Safety Architecture
Dual-channel safety circuits, Cat 4 / PL e architecture considerations, and verified safe inputs and outputs designed to prevent uncommanded motion.
Motion Limits & Envelope Control
Configurable software and hardware axis limits, Safe Limited Speed (SLS), and Safe Direction (SDI) monitoring to prevent boundary violations.
Emergency Stop & Interlocks
Hardware-level Safe Torque Off (STO) integrated directly into servo inverters, isolating power from motor windings within milliseconds of trip signals.
Collision Detection & Compliance
Joint torque estimation and external force sensors triggering immediate dynamic deceleration upon unexpected resistance, protecting machinery and tooling.
Sensor & Actuator Telemetry
Real-time monitoring of motor winding temperatures, DC bus voltages, encoder signal integrity, and vibration anomalies across all active joints.
Reliability & Endurance Testing
Subjecting gearheads and joint actuators to continuous high-torque duty cycles, reversing shocks, and thermal swings to model component longevity.
System Validation Protocols
Laser interferometer and optical tracker validation of positional accuracy, multidirectional pose repeatability, and path velocity constancy.
Preventive Maintenance Design
Lubrication life calculations, seal degradation modeling, and edge telemetry thresholds enabling proactive servicing prior to unplanned line stops.
Our Co-Engineering Model
We partner directly with plant managers, robotics system integrators, and machine OEMs. From application discovery to final commissioning, our engineers work alongside your team at every phase.
Application Discovery
Understand manufacturing process, constraints & targets
Engineering Development Roadmap
Our structured multi-stage execution framework translates complex industrial automation requirements into validated, repeatable, high-uptime deployments.
Application Feasibility
Understanding constraints & preliminary scoping
- Manufacturing process understanding
- Technical specifications definition
- Physical and environmental constraints
- Initial feasibility and ROI assessment
Engineering Design
Kinematic sizing & system architecture
- Mechanical joint & link architecture
- Electrical and power distribution design
- Optimal robot manipulator selection
- Motion control & fieldbus network design
Simulation & Validation
Virtual commissioning & stress modeling
- Physics-based motion simulation
- Multi-axis path planning & smoothing
- Dynamic collision and reach analysis
- Finite Element structural validation
Integration & Commissioning
Hardware realization & factory staging
- Precision mechanical hardware assembly
- Fieldbus and firmware stack integration
- Full-system dry run and cycle testing
- Factory acceptance testing (FAT)
Reliability & Optimization
Lifecycle engineering & performance tuning
- Continuous operational performance evaluation
- Dynamic reliability & thermal verification
- Process optimization & cycle trimming
- Long-term lifecycle engineering support
Impact of Robotics & Physical AI
By eliminating mechanical backlash and embedding deterministic intelligence into every workcell, we empower manufacturers to build resilient, high-speed, and safe production operations.
Industrial Productivity
Automated robotic cells operate with deterministic repeatability, eliminating shift-to-shift variance and maintaining steady production cadence across demanding multi-shift schedules.
Precision & Quality
Combining stiff zero-backlash mechanical joints with optical encoder feedback ensures that every spot weld, sealant bead, and micro-component placement matches exact tolerances.
Worker Safety
Robotic automation relieves human operators from repetitive strain injuries, high-heat environments, toxic fumes, and heavy lifting while maintaining collaborative safety zones.
Intelligent Manufacturing
Modern robotics goes beyond fixed programming. By incorporating edge sensor telemetry and physical AI models, industrial workcells can accommodate part variations and auto-correct.
Leadership. Engineering. Innovation.
Meet the leaders, advisors and multidisciplinary engineering professionals driving robotics, precision motion and intelligent industrial automation at INDUS.
Strategic governance, investor backing, and long-term hardware capitalization.
Kinematics modeling, sub-millisecond FOC firmware, and power electronics.
Vision-Language-Action (VLA) physical AI, digital twins, and humanoid joints.
Executive Leadership & Board of Directors
(6 Leaders)Pranav P R
Chief Executive Officer (CEO)
Robotics Strategy, Industrial Kinematics & Enterprise Architecture
Dr. Seshadri Srinivasan
Director
Robotics Architecture, Cyber-Physical Controls & Kinematic Optimization
Dr. Annanya Pandey
Director
Intelligent Systems, Applied Physical AI & Advanced Automation
Swathi Iyer
Lead Investor
Deep-Tech Growth, Hardware Scaling & Capital Formation
Naveen Thiruvengadam
Founder & Guide
Foundational Mechatronics, Systems Architecture & Mentorship
Lavanya Srihari
Investor
Industrial Automation Incubation & Enterprise Partnerships
Advisory Board
(1 Advisors)Balaji Venkatraman
Strategic Advisor
Sales, Marketing & Business Acceleration
Executive Management & Operational Leadership
(3 Leaders)Kumar V
Chief Operating Officer (COO) & Head of Robotics Reliability
Manufacturing Operations, Supply Chain & ISO 9001 Metrology
Murali Krishnamurthi
US Markets – Industrial Automation
North American Automation OEMs & Enterprise Integration
Shaji K Namath
APJC Manufacturing & Industrial Automation
Asia-Pacific Manufacturing Ecosystems & Factory Automation
Physical AI & Humanoid Robotics Core
(4 Roles)Ananya Panday
Lead, Physical AI & Embodied Intelligence
VLA Models & Spatial Reasoning
Sreeja Bhattadri
Robotics Simulation Engineer
Isaac Sim & Sim-to-Real Optimization
Lalitha Kulkarni
Robot Perception & Computer Vision Engineer
3D Scene Understanding & Depth Sensing
Path Planning & Navigation Engineer
Autonomous Localization & Trajectory Optimization
Join our team to develop real-time obstacle avoidance, graph-based SLAM, and dynamic spline trajectory generation for mobile robotics.
Motion Control & Mechatronics Engineering
(4 Specialists)Neha Hebbar
Robotics Motion Control Expert
Deterministic FOC, Servo Loop Sizing & Kinematics
Abhishek Raman
Electrical Engineer
Motor Drivers & Power Electronics
Tanushree
Actuator Geartrain Mechanical Engineer
High-Torque Density Gearboxes
Swesha
Mechatronics & Embedded Systems Engineer
Firmware & Sensor-Actuator Bus Integration
Software Platform & Infrastructure
(2 Roles)Sruthi Rajagopalan
Robotics Software Platform Engineer
ROS2 & Distributed Systems
Robotics Integration & DevOps Engineer
Fleet Management & CI/CD Pipelines
Seeking an engineer to build containerized simulation pipelines, OTA firmware delivery networks, and distributed robotics observability systems.
Engineering Interns & Specialized Associates
(5 Associates)Gautham VB
AI Motion Control Engineer
Dynamic Trajectory Optimization & Reinforcement Learning
Vishnu Aditya
AI Motion Control Engineer
Adaptive Servo Tuning & Sensor Fusion
Rishi Kumar
Robotics & Vision Coordination Engineer
Visual Servoing & Hand-Eye Calibration
Mirdhula
Robotics Reliability & Testing Engineer
Dynamic Dyno Benchmarking & Thermal Profiling
Srilakshana
Industrial Process Engineering Intern
Manufacturing Process Workflow & Cell Layout Optimization
Driving Robotics Innovation Through Engineering Talent
We cultivate a culture of deep technical rigor where robotics research, simulation testing, student fellowships, and hands-on hardware fabrication converge.
Robotics Research & Development
Dedicated prototyping labs testing non-linear friction compensation, flexspline tooth wear under cyclic loading, and zero-backlash harmonic gearhead optimization.
Physical AI & Embodied Intelligence
Developing spatial representations and Vision-Language-Action (VLA) models allowing industrial arms to perform complex multi-modal manipulation in dynamic workcells.
Simulation & Digital Engineering
Photorealistic physics simulations in NVIDIA Isaac Sim bridging sim-to-real transfer, evaluating reach envelopes, cycle-time optimizations, and collision avoidance before deployment.
Engineering Internships & Fellowships
Partnering with top technical institutions to mentor promising undergraduate and graduate engineers in embedded firmware, motor driver design, and robotics vision.
Humanoid Robotics Exploration
Evaluating high-torque density compact rotary actuators, compliant joint impedance control, and bipedal stability algorithms for next-generation humanoid form factors.
Specialized Engineering Projects
Collaborative joint-development programs with machine builders custom-engineering robotic wrist axes, high-speed delta pickers, and automated tool-change systems.
Robotics Engineering Across Real-World Industries
Real-world engineering scenarios demonstrating how INDUS precision motion components, robotic manipulators, and integration architectures solve difficult manufacturing challenges.
Body-in-White Seam Welding & Battery Tray Insertion
High dynamic inertia causing torsional deflection and seam tracking inaccuracies on high-payload car chassis assembly lines.
Deployed 6-axis articulated arm cells configured with EtherCAT synchronized servo drives and laser vision seam tracking.
Eliminated joint backlash, achieved sub-millimeter seam repeatability, and enabled continuous multi-shift production.
Engineering Connections. Industrial Impact.
Collaborating across global manufacturing hubs. Whether designing a custom gearhead ratio for an OEM in the US or commissioning a 6-axis welding cell in India, our engineering network provides direct technical consultation.
INDUS Robotics Engineering HQ & Metrology Lab
Central R&D, Kinematics Engineering & Manufacturing Metrology
Harmonic reducer development, multi-axis arm staging, CMM inspection, and dyno test benches.
US Industrial Automation Desk
North American OEM Application Sizing & Systems Integration
Direct engineering sizing for automotive tier-1s, packaging machinery builders, and warehouse AMR fleets.
APJC Manufacturing Automation Desk
Regional Integration Alliances & Factory Automation Support
Electronics manufacturing workcells, wafer transfer kinematics, and high-speed pick-and-place packaging lines.
Let's Build the Next Generation of Intelligent Industry.
Connect with our engineering team to explore robotics, precision motion and automation opportunities for your application. We assist with kinematics sizing, 3D CAD modeling, and plant integration.