Automotive Robotics
Body welding, component assembly, powertrain handling, and battery pack lines.
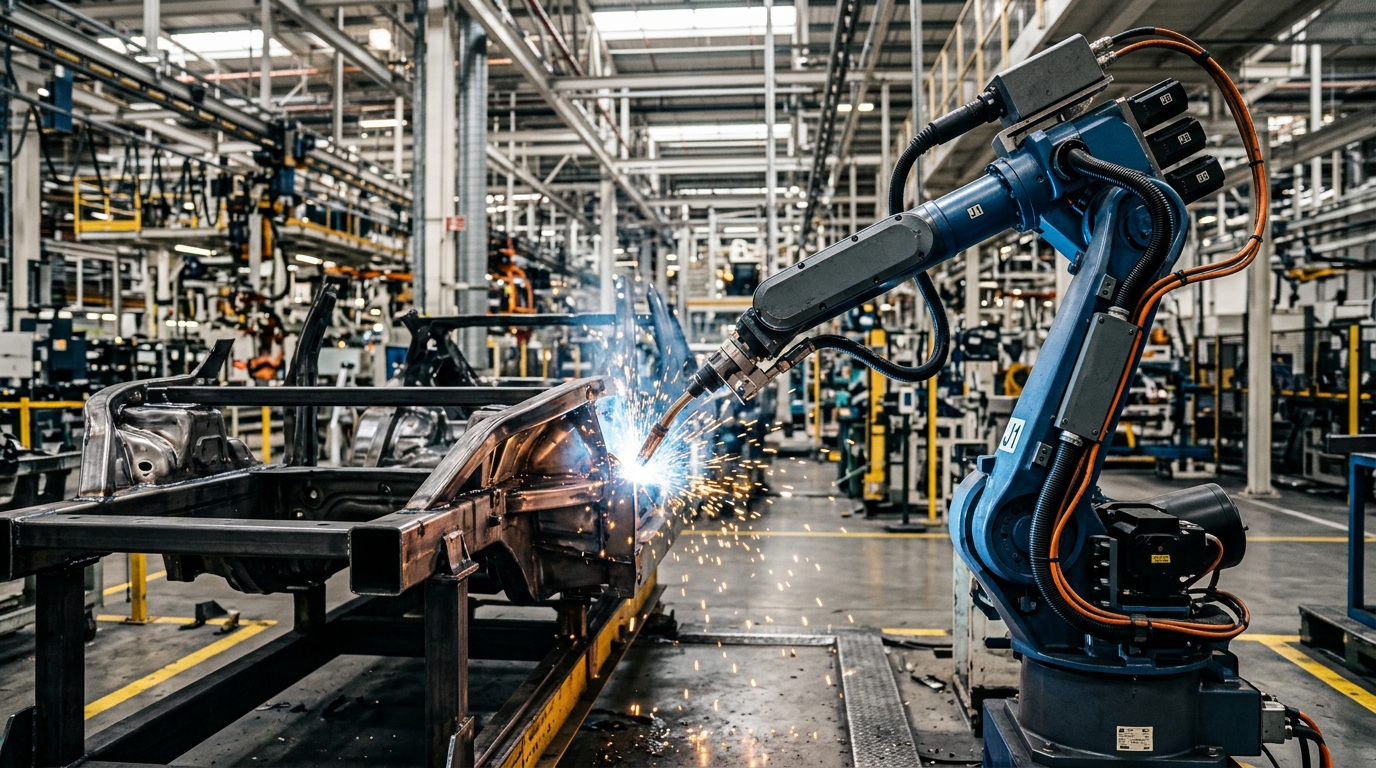
Takt Time Reduction
Down from 78s baseline on EV battery chassis trays
Sub-Millimeter Precision
Closed-loop laser triangulation seam tracking guidance
Max Dynamic Payload
Rigid heavy-duty articulated arm and gantry tooling
Defect Interception & Uptime
Zero unplanned line shutdowns across continuous 24/7 duty
Robotic Applications in Automotive
Turnkey robotic workcells, kinematic metrics, and operational architectures deployed across modern automotive manufacturing plants.
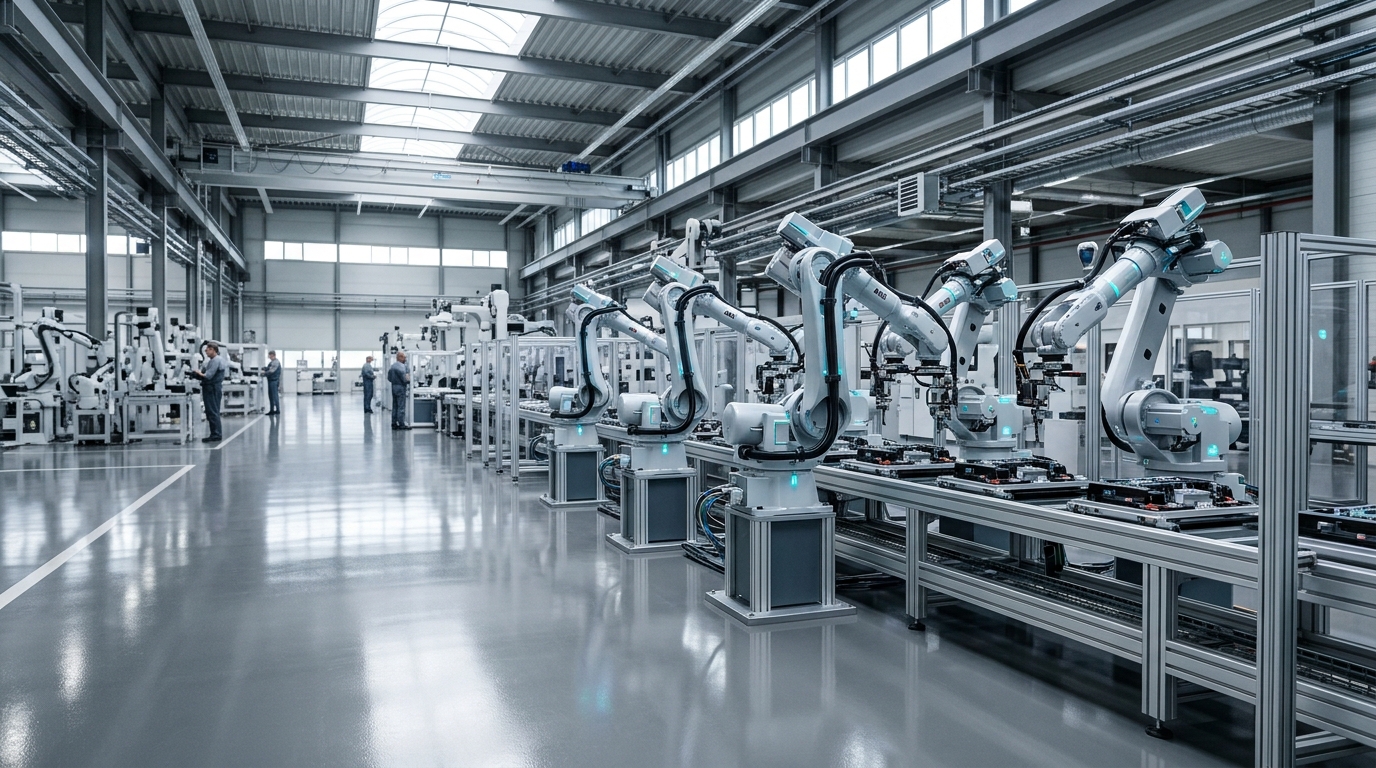
EV Battery Pack Module Assembly Cell
Automated robotic cell executing prismatic and pouch battery cell stacking, busbar laser welding, thermal paste dispensing, and high-voltage isolation testing.
Body-in-White 7th-Axis Gantry Welding
7th-axis linear track robotic spot welding and fiber laser seam joining for automotive body-in-white (BIW) framing and high-strength aluminum door apertures.
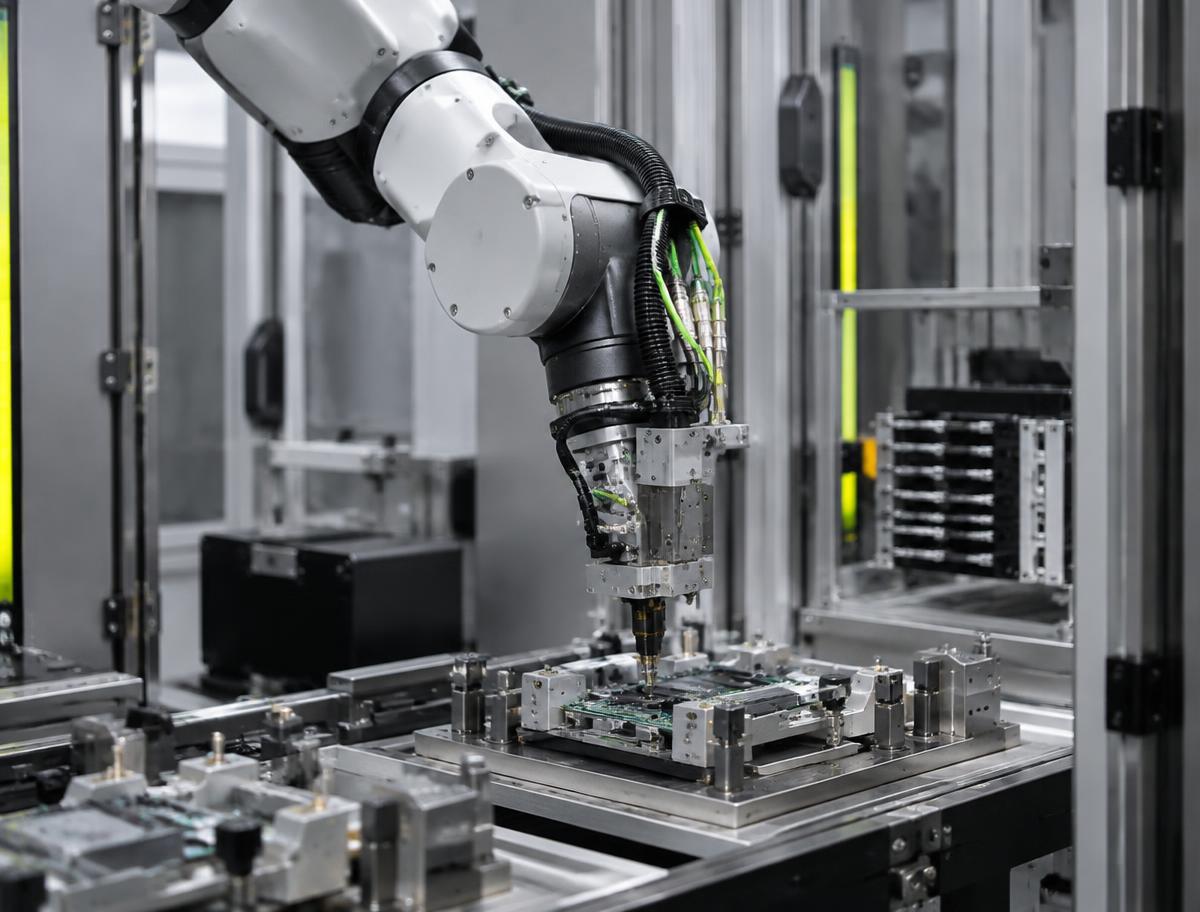
Powertrain & Gearbox Articulated Handling
High-torque articulated handling arms automating engine decking, electric drive unit (EDU) stator-rotor insertion, and transmission pallet transfer.
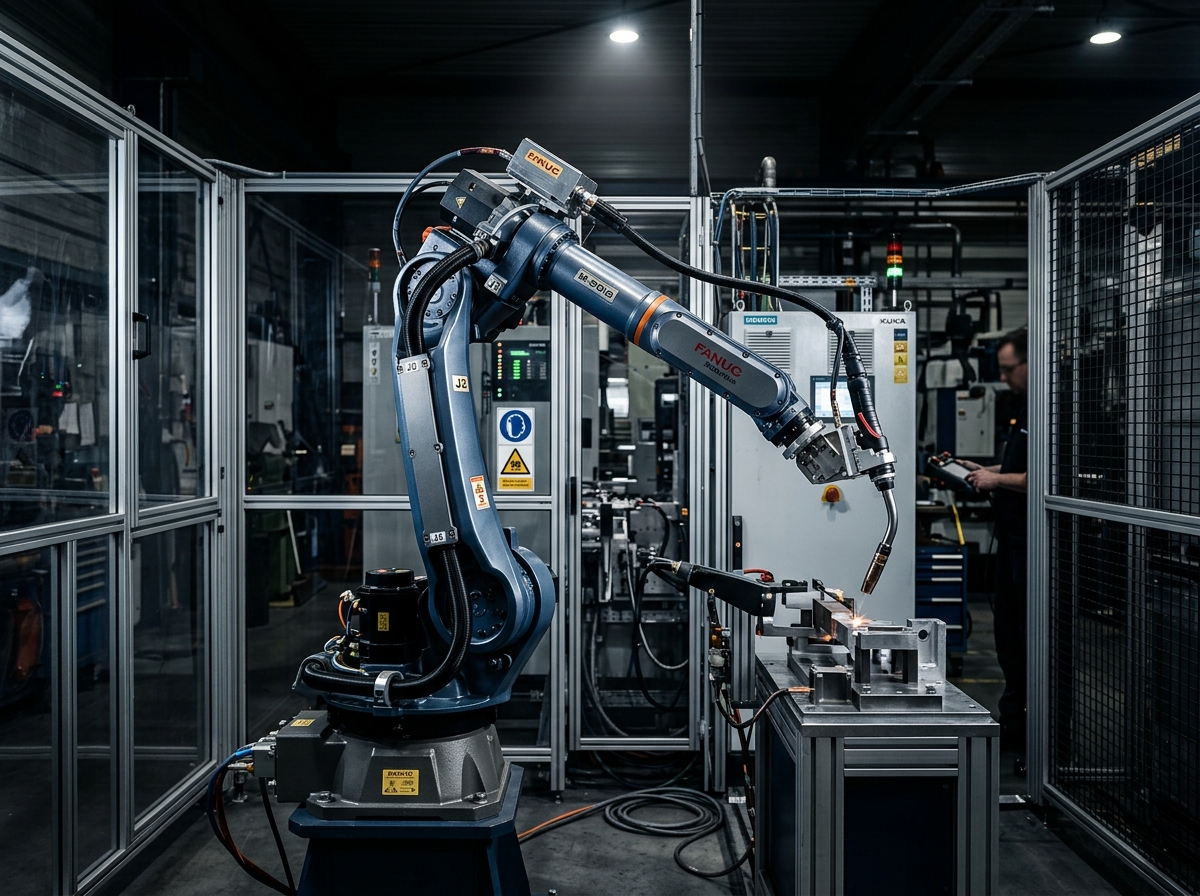
Dual-Gripper CNC Machine Tending Cell
Turnkey robotic tending cell loading and unloading high-tonnage stamping presses and multi-axis CNC milling centers with pneumatic zero-point fixtures.
Select Your Automotive Automation Requirement
Toggle between core automation processes to inspect matching kinematic models, payload capacities, cycle times, and directly download engineering CAD files.
INDUS-BAT-K150 (7-DOF)
Engineered specifically for prismatic cell stacking, busbar tightening, and high-voltage module casing insertion with constant 6-DOF force/torque regulation.
Automotive Automation Use Cases
Every production task has specific mechanical shock profiles, positioning tolerances, sensing architectures, and functional safety constraints. Explore detailed engineering breakdowns for each verified operation.
Body-in-White High-Duty Spot Welding Cell
Rapid gun closure forces (>4.5 kN) induce cyclic bending moments on robot wrist gearheads, causing gear tooth fatigue.
High-payload 6-Axis Articulated Robot (210 kg payload, 2.7m reach) with integrated servo gun.
Continuous resistance spot welding of high-strength galvanized steel stampings on multi-model chassis lines; harsh spatter and high magnetic field environment.
EV Battery Pack Prismatic Cell Module Decking
Manual battery module insertion risks high-voltage shock and thermal runaway; requires sub-millimeter positioning inside tight aluminum pack trays.
Articulated robot with compliance-assisted servo gripper and secondary overhead 3D vision guidance.
Insertion of 40 kg prismatic lithium-ion battery modules into extruded chassis trays with thermal interface material (TIM) dispensing in clean assembly area.
High-Speed Busbar Copper-to-Aluminum Laser Welding
High thermal conductivity of copper and formation of brittle intermetallic phases requires microsecond beam position accuracy.
Dual-axis high-speed galvo scanning head mounted on 6-axis precision robotic arm with vision seam tracking.
Scanning laser beam welding of 120+ electrical busbar contacts per battery pack under active argon gas shielding.
Automated Robotic Door Gap & Flush Metrology
Manual gap gauges on final automotive lines are subjective, slow, and fail to record 100% vehicle traceability.
Coordinated dual 6-axis collaborative robots tracking moving conveyor via encoder synchronization.
Continuous 3D optical profilometry of door, hood, and trunk shut lines on moving assembly skillet conveyors.
Windshield & Panoramic Roof Urethane Bead Dispensing
Variations in robot path speed cause polyurethane bead necking or ballooning, causing water leaks in finished vehicles.
Articulated robot with precision servo-driven volumetric dispensing pump and 2D vision bead inspector.
Extrusion of high-viscosity structural adhesive along 3D contoured automotive glass perimeter prior to robot chassis decking.
Engine & Inverter Housing High-Payload CNC Tending
Heavy cast aluminum transmission and inverter housings generate extreme shock during fast chuck loading, damaging robot wrists.
Floor-mounted 6-axis robot with IP67 washdown wrist and dual pneumatic/servo rotary gripper.
Loading and unloading 35 kg rough castings into horizontal machining centers with coolant splashing and metal chips.
Automotive Underbody PVC Seam Sealing
Inverted overhead robot positioning requires high wrist agility and zero grease dripping over bare automotive sheet metal.
Inverted pedestal-mounted 6-axis robot with specialized hollow-wrist cable management.
Underbody robotic application of PVC mastic to seal sheet metal joints against road salt corrosion and acoustic noise.
Heavy-Payload (1,500 kg) AMR EV Battery Pack Intralogistics
Traditional roller conveyors divide plant floor space, preventing agile changes to mixed-model electric vehicle lines.
Dual-differential drive Autonomous Mobile Robot (AMR) with integrated electric scissor-lift deck.
Autonomous transport of 1,200 kg assembled battery packs across 400 meters of shared forklift and pedestrian factory aisles.
Automated Instrument Panel (Cockpit) Insertion
Cockpit assembly is heavy (65 kg) and must be threaded through vehicle door openings with less than 15mm clearance.
High-payload articulated robot equipped with specialized 7th-axis extended reach tooling and 3D guidance.
Gripping pre-assembled instrument panel from kitting cart and inserting it through side door aperture into vehicle cabin.
Automotive Roof Seam Laser Brazing
Visible cosmetic roof seams demand perfectly smooth joint lines with zero spatter, eliminating roof ditch trim strips.
High-accuracy articulated 6-axis robot with wire feed unit, laser optics, and tactile seam tracking roller.
Continuous laser brazing of galvanized roof panel to side body panel using copper-silicon (CuSi3) filler wire.
Electric Drive Unit (EDU) Transmission Bearing Press-Fit
Electric vehicle high-speed gearboxes (>18,000 RPM) require bearing preloads controlled to within ±5 microns.
Servo-electric press actuator mounted on rigid C-frame cell with automated robotic part shuttle.
Pressing tapered roller bearing outer races into electric vehicle aluminum gearbox housings with simultaneous load-displacement signature logging.
High-Speed Tandem Stamping Press Part Transfer
Heavy mechanical stamping presses running at 15 strokes/minute require rapid part extraction without die collision.
Crossbar transfer robot with lightweight carbon fiber booms and pneumatic vacuum suction cups.
Extraction of 15 kg stamped automotive hood and door outer panels from stamping dies and transfer to next press station.
Manufacturing Challenges & Robotic Solutions
Comparing conventional production bottlenecks against deterministic multi-axis robotic automation.
Manufacturing Hurdles in Modern Automotive Plants
Automotive assembly lines operate at takt times under 60 seconds. Mechanical drivetrains must endure continuous high-payload spot welding and rapid acceleration without thermal drift or joint backlash.
- High continuous mechanical shock from spot-welding guns and heavy sheet metal handling
- Stringent safety regulations for shared human-robot zones along final trim and chassis dress
- Complex thermal management required inside high-density EV battery module assembly
- Rigorous quality auditing requiring continuous torque and position data logging
Where Robotic Automation Excels
Articulated industrial robots coupled with zero-backlash reducers deliver repeatable welding bead quality, micro-precision adhesive dispensing, and automated heavy door and chassis decking.
- Heavy payload handling up to 300kg with repeatable positioning within ±0.04mm
- Synchronized dual-arm coordination for complex frame manipulation
- Automated mobile robots (AMRs) feeding sub-assemblies directly to line-side stations
- Deterministic fieldbus integration directly into automotive plant DCS/MES networks
Accelerate Automotive Automation
Access our specialized kinematics sizing tools, discuss payload vs cycle takt trade-offs, and receive 3D CAD space-claim models verified for this manufacturing discipline.
Connected Ecosystem
Other Manufacturing Sectors
Related Industrial Sectors
- Electronics
Sub-micron repeatability and cleanroom-compliant automation for high-density electronic assemblies.
- Manufacturing
Rugged robotic automation engineered for high-uptime machine tending and harsh factory environments.
- Warehousing
High-density dynamic automation transforming modern distribution centers and fulfillment hubs.