Warehousing Robotics
Automated storage and retrieval (ASRS), case picking, sorting, and buffer management.
Pick Velocity
Continuous high-speed delta kitting and carton packing
AMR Fleet Payload
Heavy pallet autonomous transit between dock and ASRS
Sorting Accuracy
3D vision barcode and dimension classification
Fleet Availability
Continuous automatic fast inductive opportunity charging
Robotic Applications in Warehousing
Turnkey robotic workcells, kinematic metrics, and operational architectures deployed across modern warehousing manufacturing plants.
Autonomous Mobile Robots (AMRs) Intralogistics
Autonomous LiDAR-guided mobile robots coordinating pallet transit, tote haulage, and dynamic line-side replenishments.
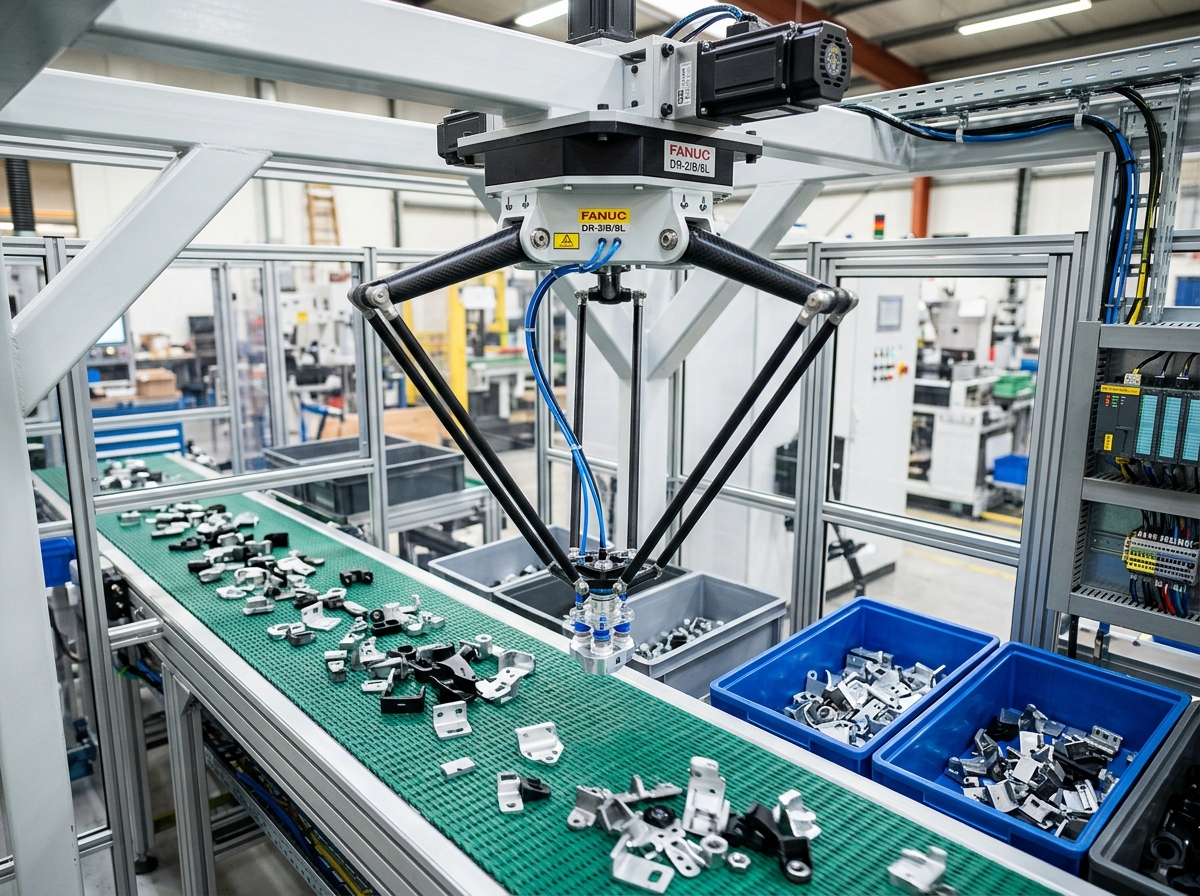
High-Speed Delta Carton Pick & Packing
Parallel delta manipulators executing visual tracking, conveyor belt sync, and dynamic carton packing of diverse SKUs.
Select Your Warehousing Automation Requirement
Toggle between core automation processes to inspect matching kinematic models, payload capacities, cycle times, and directly download engineering CAD files.
INDUS-AMR-1200
Heavy pallet autonomous transit vehicle equipped with 360-degree LiDAR safety curtains and dynamic slam re-routing.
Warehousing Automation Use Cases
Every production task has specific mechanical shock profiles, positioning tolerances, sensing architectures, and functional safety constraints. Explore detailed engineering breakdowns for each verified operation.
Mixed-SKU Vision-Guided Inbound Depalletizing
Unloading non-uniform pallets with random carton sizes, tilted boxes, and shifting shrinkwrap causes manual back injuries.
High-payload articulated robot (180 kg) equipped with multi-zone vacuum suction grid and 3D time-of-flight vision.
Continuous singulation of cartons from random incoming mixed pallets and placing them onto sorting induction conveyors.
Autonomous Pallet Jack AMR for Cross-Docking
Manned forklift traffic in cross-dock terminals creates high collision risks and severe labor shortage bottlenecks.
Autonomous mobile pallet jack with electric steering drive, dual load forks, and 360° safety scanning.
Picking standard GMA/EUR pallets (up to 1,200 kg) directly from floor drop zones and moving across dynamic terminal docks.
High-Speed Mini-Load ASRS Storage Shuttle
High-bay warehousing requires extracting 50 kg totes at accelerations exceeding 5 m/s² without mechanical slippage or tilt.
Rail-guided robotic storage crane with bidirectional telescopic finger shuttle table.
High-density tote storage racks up to 24 meters high with narrow aisles in e-commerce fulfillment fulfillment hubs.
AI-Driven Piece Picking from Compartment Totes
E-commerce orders consist of millions of unpredictable individual items (bottles, boxes, tubes, blister packs) requiring reliable grasping.
High-speed collaborative or industrial articulated robot with smart adaptive multi-suction cup end-effector.
Picking items from inbound compartment totes and placing into order shipping cartons at picking stations.
Mixed-Case Automated Palletizing with Stability Optimization
Building store-friendly mixed pallets where heavy beverage cartons, fragile chips, and odd-sized boxes must form stable stacks.
4-axis high-speed palletizing robot equipped with bottom-support servo squeeze clamp gripper.
Sequential stacking of incoming random carton stream onto pallet with automatic stretch-wrapping in logistics DC.
High-Speed Parcel Singulation & Cross-Belt Sorter Induction
Parcels arriving in jumbled clusters must be separated into single-file flow with exact spacing before reaching high-speed sorting loops.
Multi-belt skewed roller matrix conveyor synchronized with high-speed overhead delta picking robots.
Transforming bulk parcel dumps into single-file flow on high-velocity parcel sortation lines (up to 3 m/s).
-30°C Deep-Freeze Automated Pallet Storage AMR
Human workers can only spend 30 minutes in -30°C cold storage before hypothermia risks; standard batteries and grease freeze solid.
Heavy-duty low-temperature AMR with heated battery enclosure, thermal insulated chassis, and studded polyurethane tires.
Continuous pallet transport inside commercial frozen food cold-chain distribution center at -30°C ambient temperature.
Cubic High-Density Grid Robot Fleet (AutoStore Type)
Maximizing storage density in urban fulfillment centers with low ceiling heights where traditional ASRS cannot fit.
Compact 4-wheel grid climbing robot with internal 4-axis hoisting cable mechanism.
Robots riding atop aluminum grid rail matrix, digging and retrieving stacked bins to deliver to workstation ports.
Automated Empty Tote Destacking & Infeed Feeder
Stacked plastic warehouse totes nest tightly together; vacuum suction alone cannot overcome vacuum interlock between bins.
Vertical Cartesian destacking gantry with mechanical edge-release wedge latch fingers.
Destacking 20-high stacks of nested plastic shipping totes and placing them onto fulfillment picking conveyors.
High-Reach Narrow Aisle (VNA) Automated Forklift
Operating manual reach trucks in narrow aisles (1.7m) at 12-meter lift heights requires extreme operator skill and risks rack impact.
Driverless Automated Guided Forklift with turret rotating fork head and magnetic wire/LiDAR aisle guidance.
Autonomous pallet insertion and retrieval in Very Narrow Aisle (VNA) high-bay storage racks up to 14 meters high.
High-Speed Robotic Corrugated Carton Erection & Sealing
Corrugated cardboard blank warpage and varying humidity cause vacuum cup mis-picks and carton flap jam failures.
High-speed 4-axis SCARA/Cartesian mechanism with dual vacuum suction cup arrays and servo flap tuckers.
Pulling flat cardboard blanks from magazine, erecting into 3D box, folding bottom flaps, and applying hot-melt adhesive.
Ultra-Fast (3,600 PPH) Servo Crank Carton Divert Pusher
Pneumatic diverter cylinders slam into parcels, damaging fragile products and suffering high seal failure rates under 24/7 duty.
All-electric servo crank mechanism with progressive S-curve velocity profiling.
Diverting parcels off main sorting belt onto designated packing branch conveyors at 2 m/s line speed.
Autonomous Shipping Container & Semi-Trailer Loader
Loading 53-foot shipping trailers manually in summer heat / winter cold is grueling, slow, and causes frequent product drops.
Compact mobile tracked/wheeled vehicle equipped with high-reach telescopic arm and vacuum carton gripper.
Autonomous driving into shipping semi-trailers, building stacked floor-loaded cartons wall-by-wall from conveyor feed.
Manufacturing Challenges & Robotic Solutions
Comparing conventional production bottlenecks against deterministic multi-axis robotic automation.
Fulfillment Pressures in High-Velocity Warehouses
Managing thousands of unpredictable SKUs, fluctuating peak seasons, and narrow warehouse aisles requires flexible mobile and stationary robotic platforms that integrate directly into Warehouse Management Systems (WMS).
- Unpredictable SKU packaging dimensions, weights, and fragile surfaces
- Narrow aisles and high rack vertical storage limiting manual reach
- Seasonal peak spikes requiring rapid scaling without proportional headcount growth
- Stringent safety needs when operating alongside human pickers in aisle zones
Intelligent Warehouse Automation
Deploying autonomous mobile robots, automated pallet shuttles, and vision-guided piece-picking arms creates high-density, lights-out storage capable of continuous 24/7 fulfillment.
- Dynamic AMR fleets navigating narrow rack corridors via LiDAR SLAM
- AI vision-guided suction arms picking unstructured items directly from bins
- High-density automated shuttles maximizing cube storage volume by up to 60%
- Seamless API bridges to enterprise WMS and ERP inventory databases
Accelerate Warehousing Automation
Access our specialized kinematics sizing tools, discuss payload vs cycle takt trade-offs, and receive 3D CAD space-claim models verified for this manufacturing discipline.
Connected Ecosystem
Other Manufacturing Sectors
Related Industrial Sectors
- Automotive
High-precision robotics meeting the extreme uptime and sub-millimeter tolerances of modern EV & automotive production.
- Electronics
Sub-micron repeatability and cleanroom-compliant automation for high-density electronic assemblies.
- Manufacturing
Rugged robotic automation engineered for high-uptime machine tending and harsh factory environments.