Medical Devices and Healthcare Robotics
Surgical robotic arms, orthopedic implant polishing, stent laser micromachining, dialyzer assembly, and wearable pump testing.
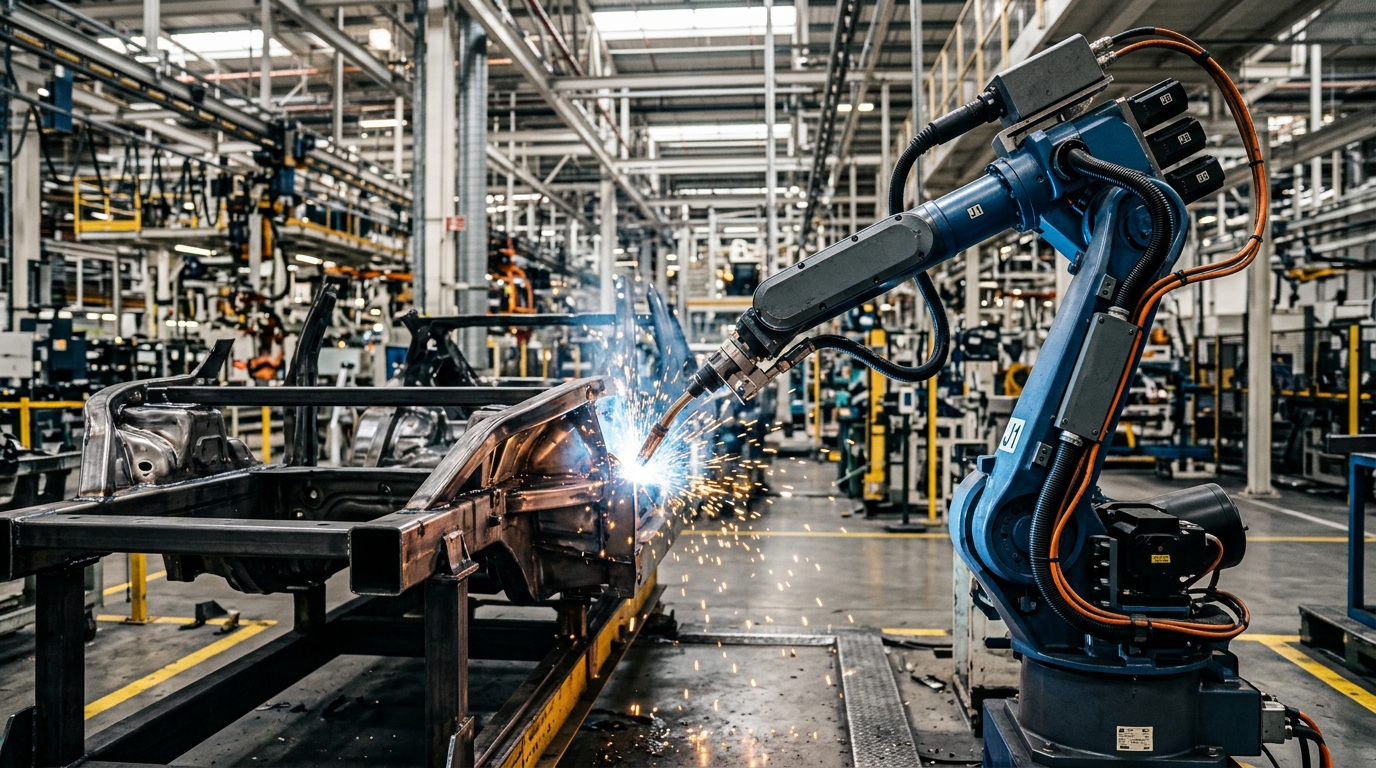
Takt Time Reduction
Down from 78s baseline on EV battery chassis trays
Sub-Millimeter Precision
Closed-loop laser triangulation seam tracking guidance
Max Dynamic Payload
Rigid heavy-duty articulated arm and gantry tooling
Defect Interception & Uptime
Zero unplanned line shutdowns across continuous 24/7 duty
Robotic Applications in Medical Devices and Healthcare
Turnkey robotic workcells, kinematic metrics, and operational architectures deployed across modern medical devices and healthcare manufacturing plants.
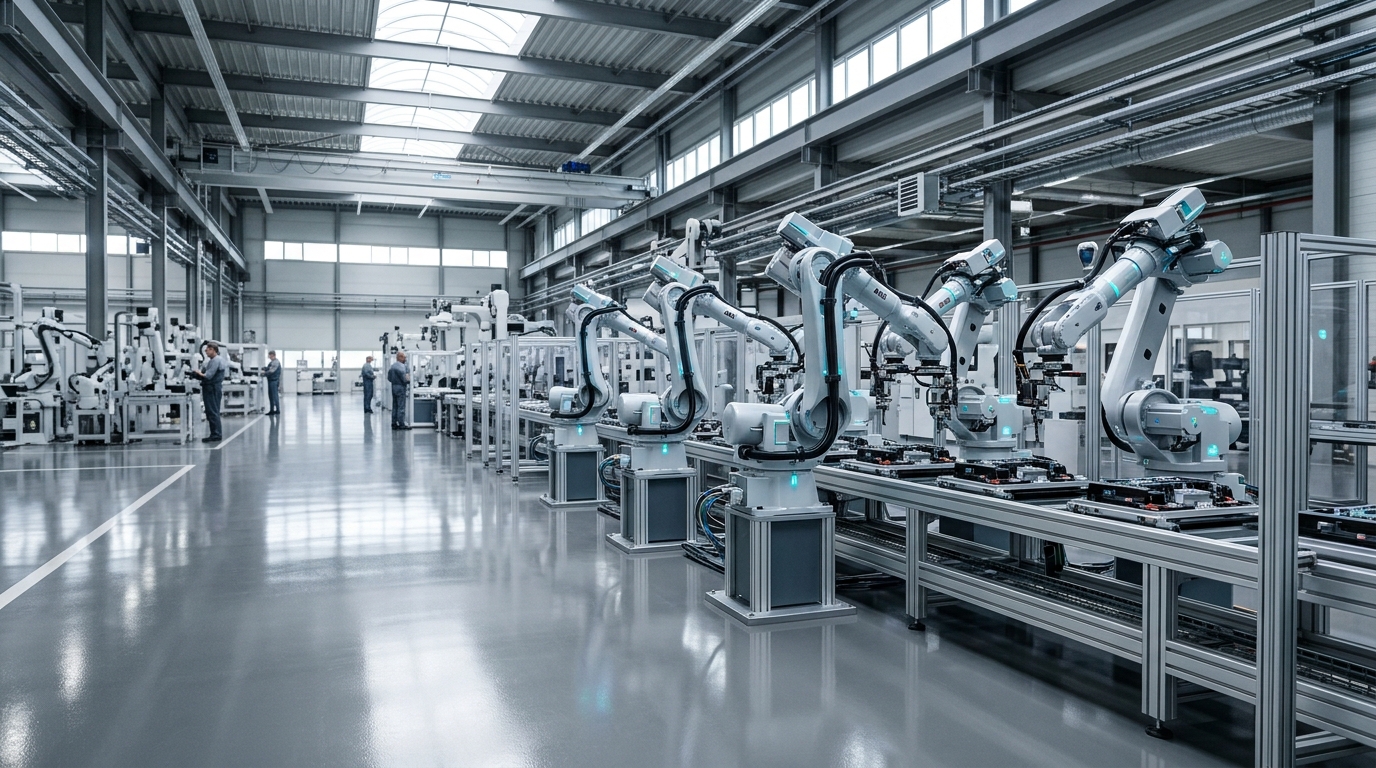
EV Battery Pack Module Assembly Cell
Automated robotic cell executing prismatic and pouch battery cell stacking, busbar laser welding, thermal paste dispensing, and high-voltage isolation testing.
Body-in-White 7th-Axis Gantry Welding
7th-axis linear track robotic spot welding and fiber laser seam joining for automotive body-in-white (BIW) framing and high-strength aluminum door apertures.
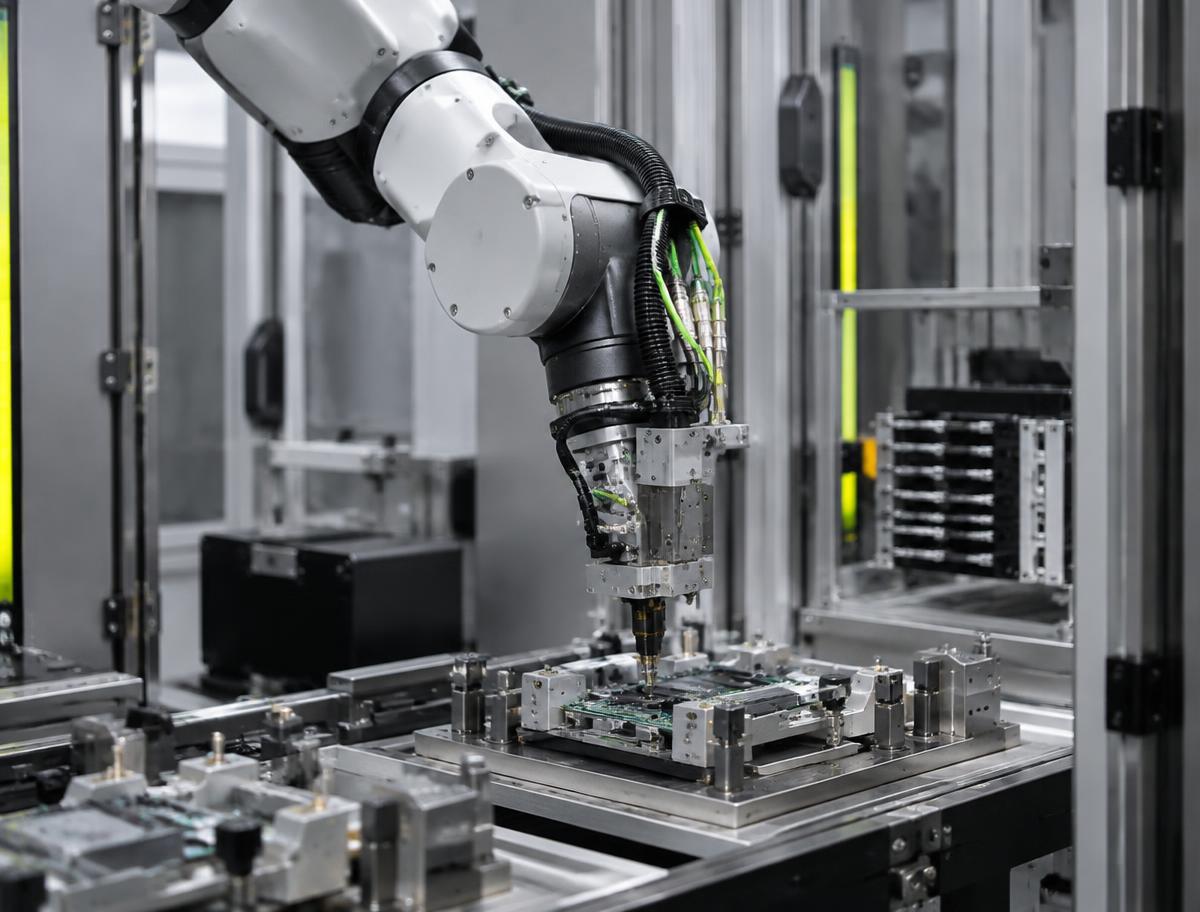
Powertrain & Gearbox Articulated Handling
High-torque articulated handling arms automating engine decking, electric drive unit (EDU) stator-rotor insertion, and transmission pallet transfer.
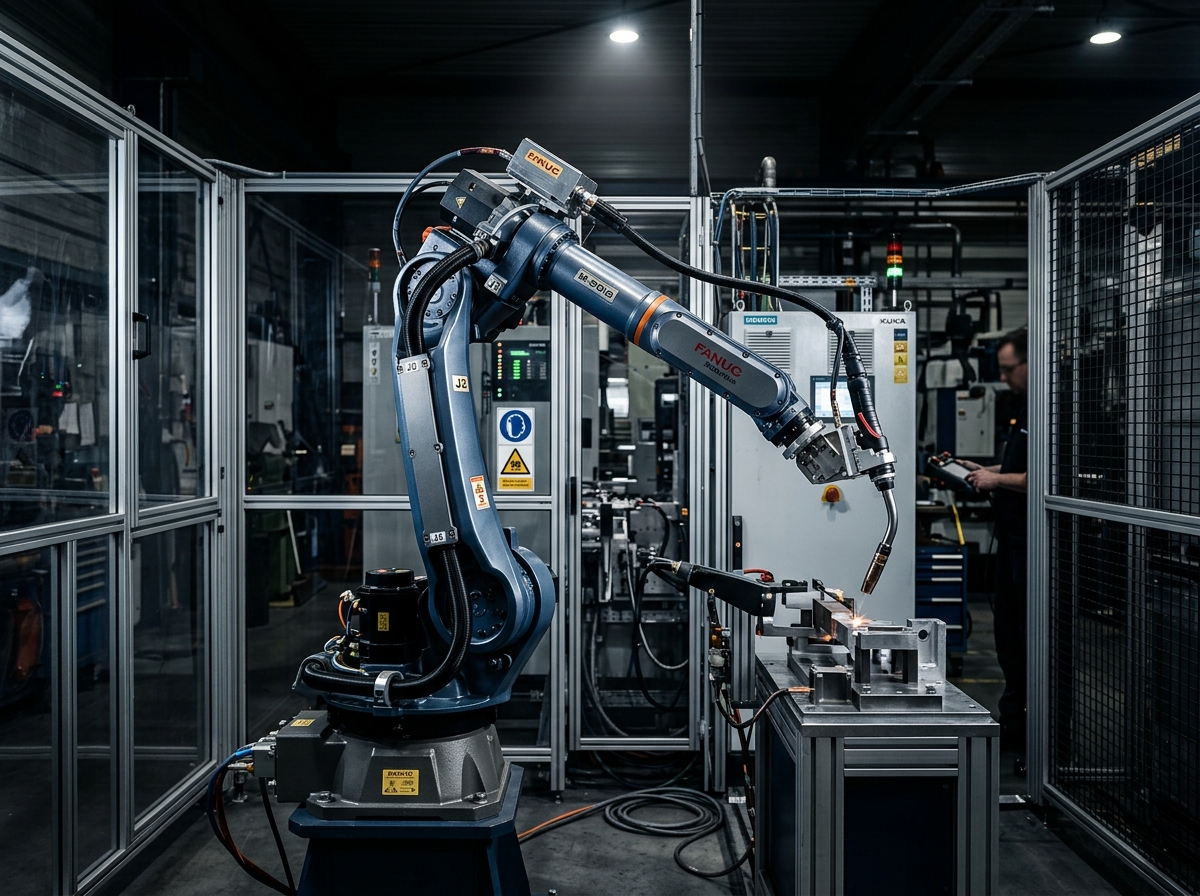
Dual-Gripper CNC Machine Tending Cell
Turnkey robotic tending cell loading and unloading high-tonnage stamping presses and multi-axis CNC milling centers with pneumatic zero-point fixtures.
Select Your Medical Devices and Healthcare Automation Requirement
Toggle between core automation processes to inspect matching kinematic models, payload capacities, cycle times, and directly download engineering CAD files.
INDUS-BAT-K150 (7-DOF)
Engineered specifically for prismatic cell stacking, busbar tightening, and high-voltage module casing insertion with constant 6-DOF force/torque regulation.
Medical Devices and Healthcare Automation Use Cases
Every production task has specific mechanical shock profiles, positioning tolerances, sensing architectures, and functional safety constraints. Explore detailed engineering breakdowns for each verified operation.
Minimally Invasive Multi-DoF Laparoscopic Surgical Tool Wrist
Laparoscopic instruments require 7 degrees of freedom within an 8mm diameter shaft without cable stretch or backlash.
Multi-axis patient-side robotic cart slave manipulator controlled by surgeon master tele-operation console.
Micro-cable driven articulation of surgical needle drivers and shears inside patient abdominal cavity during robotic surgery.
Cobalt-Chrome Knee Implant Femoral Component Robotic Polishing
Cobalt-chromium-molybdenum (CoCrMo) knee implants have complex dual-radius curves that wear out human polisher shoulders.
Articulated robot holding the implant against stationary abrasive wheels with 6-axis force control.
Multi-stage abrasive belt and buffing wheel mirror finishing of cast orthopedic knee implants to Ra < 0.02 µm.
Femtosecond Laser Micromachining of Nitinol Cardiovascular Stents
Standard fiber lasers melt nitinol tubing (strut width 60 µm), creating micro-cracks and dross that cause blood clots.
High-precision direct-drive rotary air-bearing collet synchronized with linear direct-drive stage under ultrashort pulse laser.
Rotary cutting of intricate diamond mesh strut patterns into 2mm diameter nickel-titanium (nitinol) memory alloy tubes.
Micro-Catheter Multi-Filament Precision Braiding & Pulling
Steerable neurovascular catheters require stainless micro-wires braided over PTFE core with exact pitch to prevent kinking in brain vessels.
Dual servo-driven caterpillar puller synchronized with 16-carrier rotary braiding machine.
Continuous pulling of 16-wire braided composite tube through heated extrusion dies at controlled tension.
Hemodialysis Dialyzer Hollow-Fiber Bundle Automated Insertion
Hemodialyzers contain 10,000 microscopic semi-permeable hollow fibers that fold or crush if pushed with uneven force.
Multi-axis servo winding and linear pusher mechanism with pneumatic suction bundling shroud.
Bundling, wrapping, and inserting 10,000 hollow fibers into clear polycarbonate dialyzer filter housings in cleanroom.
High-Speed Automated Insulin Pen Injector Multi-Part Assembly
Insulin pen dose selector gears must be assembled with exact torque to prevent dose delivery failures in diabetic patients.
High-speed precision rotary indexing dial with integrated Cartesian pick-and-place servo inserters.
12-station rotary indexing machine assembling 8 precision plastic injection molded parts and springs at 60 pens/minute.
Dental Implant Titanium Abutment 5-Axis Micro-Milling Tending
Patient-customized titanium dental abutments require individual part loading and micro-machining within 10 microns.
Collaborative 6-axis cleanroom robot mounted on machine front with pneumatic collet gripper.
Robotic transfer of custom titanium blanks into high-precision 5-axis dental milling machines.
Wearable Continuous Glucose Monitor (CGM) Laser Plastic Welding
Hermetic sealing of wearable body sensors containing electronics and batteries cannot use ultrasonic vibration or solvent glue.
High-speed galvo scanning laser head coupled to servo clamping nest in ISO Class 7 cleanroom.
Quasi-simultaneous laser contour welding of transparent top housing to dark lower casing of wearable sensor patch.
6-DoF Robotic Radiotherapy Patient Positioning Couch
Targeting cancer tumors with high-energy radiation requires sub-millimeter patient positioning compensation for breathing motion.
6-DoF parallel Stewart platform or articulated robotic pedestal supporting patient table up to 250 kg.
6-axis spatial positioning and pitch/roll tilt compensation of patient carbon-fiber couch under linear accelerator (LINAC).
High-Volume Clinical Laboratory Blood Tube Robotic Decapper & Sorter
Clinical reference labs process 20,000 patient blood tubes daily; manual decapping exposes technicians to repetitive strain and biohazards.
High-speed Cartesian gantry picking arm with dual rotary-linear decapping servo heads.
Barcode identification, centrifugation balancing, motorized rubber cap twisting/decapping, and sorting into analyzer racks.
Cardiac Pacemaker Titanium Enclosure Laser Seam Welding & Terminal Crimp
Pacemaker hermetic titanium cases must remain 100% leak-proof for 15+ years inside the human body environment.
Precision multi-axis micro-positioning stage inside dry argon glovebox (H2O and O2 < 1 ppm).
Pulsed Nd:YAG laser welding of grade 1 titanium pacemaker halves and precision micro-crimping of lead terminals.
Cleanroom Robotic In-Mold Labware Pipette Tip Racking
Plastic pipette tips (10 µL to 1,000 µL) molded in 64-cavity injection molds must be racked in 96-well boxes in <6 seconds.
Side-entry high-speed Cartesian robot with lightweight carbon-fiber extraction arm.
Side-entry high-speed robot entering mold opening, vacuum gripping 64 freshly molded pipette tips, and depositing into 96-well racks.
Manufacturing Challenges & Robotic Solutions
Comparing conventional production bottlenecks against deterministic multi-axis robotic automation.
Medical Devices and Healthcare Automation Hurdles
Demanding environmental conditions, high-speed cycle times, and precision limits dictate deterministic robotics.
- Strict ISO 13485 quality management requiring 100% force and dimensional validation of every implant
- Micro-scale delicate components (nitinol stents, intravascular catheters) vulnerable to micro-crimping deformation
- Extreme pose stability requirements in surgical robotics where tremor or backlash could be life-threatening
- Cleanroom assembly environments requiring biocompatible, non-shedding, and sterilizable robotic materials
Robotic Automation Potential
High-stiffness mechanical transmission, multi-axis sensory feedback, and real-time motion control.
- Zero-cogging slotless motors providing smooth, tremor-free haptic feedback in surgical master consoles
- Sub-miniature zero-backlash strain-wave reducers enabling dexterous multi-DoF laparoscopic wrists
- Femtosecond laser micromachining systems cutting complex nitinol stent struts with zero heat-affected zone
Accelerate Medical Devices and Healthcare Automation
Access our specialized kinematics sizing tools, discuss payload vs cycle takt trade-offs, and receive 3D CAD space-claim models verified for this manufacturing discipline.
Connected Ecosystem
Other Manufacturing Sectors
Related Industrial Sectors
- Automotive
High-precision robotics meeting the extreme uptime and sub-millimeter tolerances of modern EV & automotive production.
- Electronics
Sub-micron repeatability and cleanroom-compliant automation for high-density electronic assemblies.
- Manufacturing
Rugged robotic automation engineered for high-uptime machine tending and harsh factory environments.