Agriculture and Agricultural Technology Robotics
Autonomous vineyard pruning, selective strawberry picking, AI laser weed eradication, automated cow milking, and greenhouse seeding.
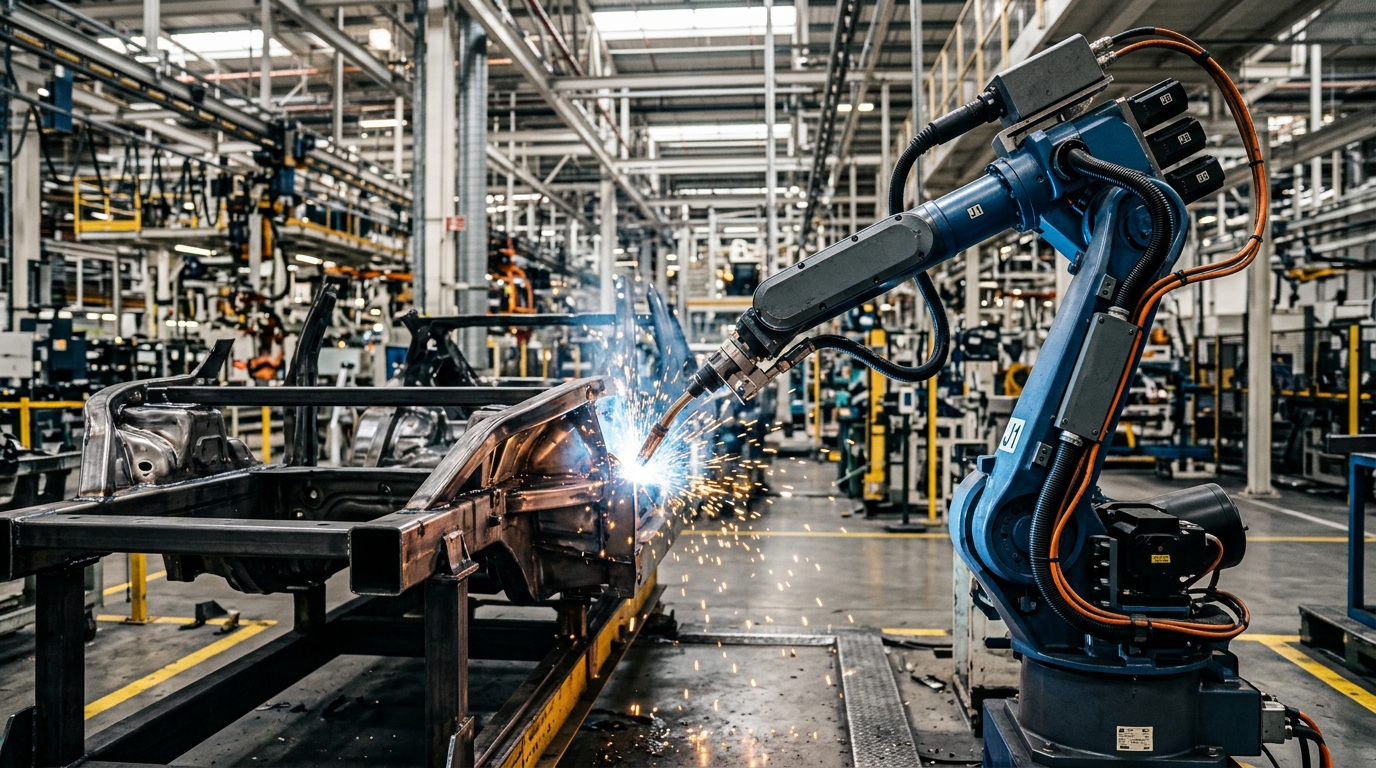
Takt Time Reduction
Down from 78s baseline on EV battery chassis trays
Sub-Millimeter Precision
Closed-loop laser triangulation seam tracking guidance
Max Dynamic Payload
Rigid heavy-duty articulated arm and gantry tooling
Defect Interception & Uptime
Zero unplanned line shutdowns across continuous 24/7 duty
Robotic Applications in Agriculture and Agricultural Technology
Turnkey robotic workcells, kinematic metrics, and operational architectures deployed across modern agriculture and agricultural technology manufacturing plants.
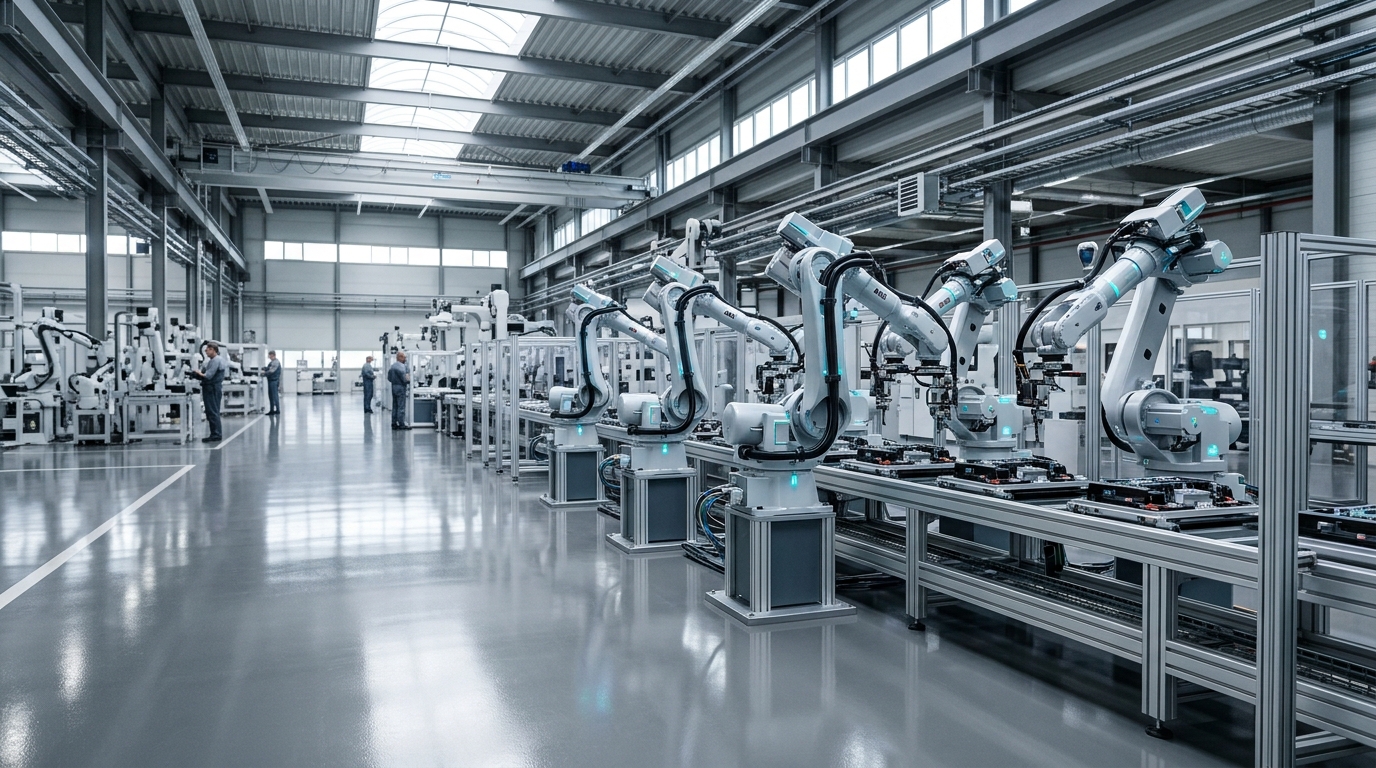
EV Battery Pack Module Assembly Cell
Automated robotic cell executing prismatic and pouch battery cell stacking, busbar laser welding, thermal paste dispensing, and high-voltage isolation testing.
Body-in-White 7th-Axis Gantry Welding
7th-axis linear track robotic spot welding and fiber laser seam joining for automotive body-in-white (BIW) framing and high-strength aluminum door apertures.
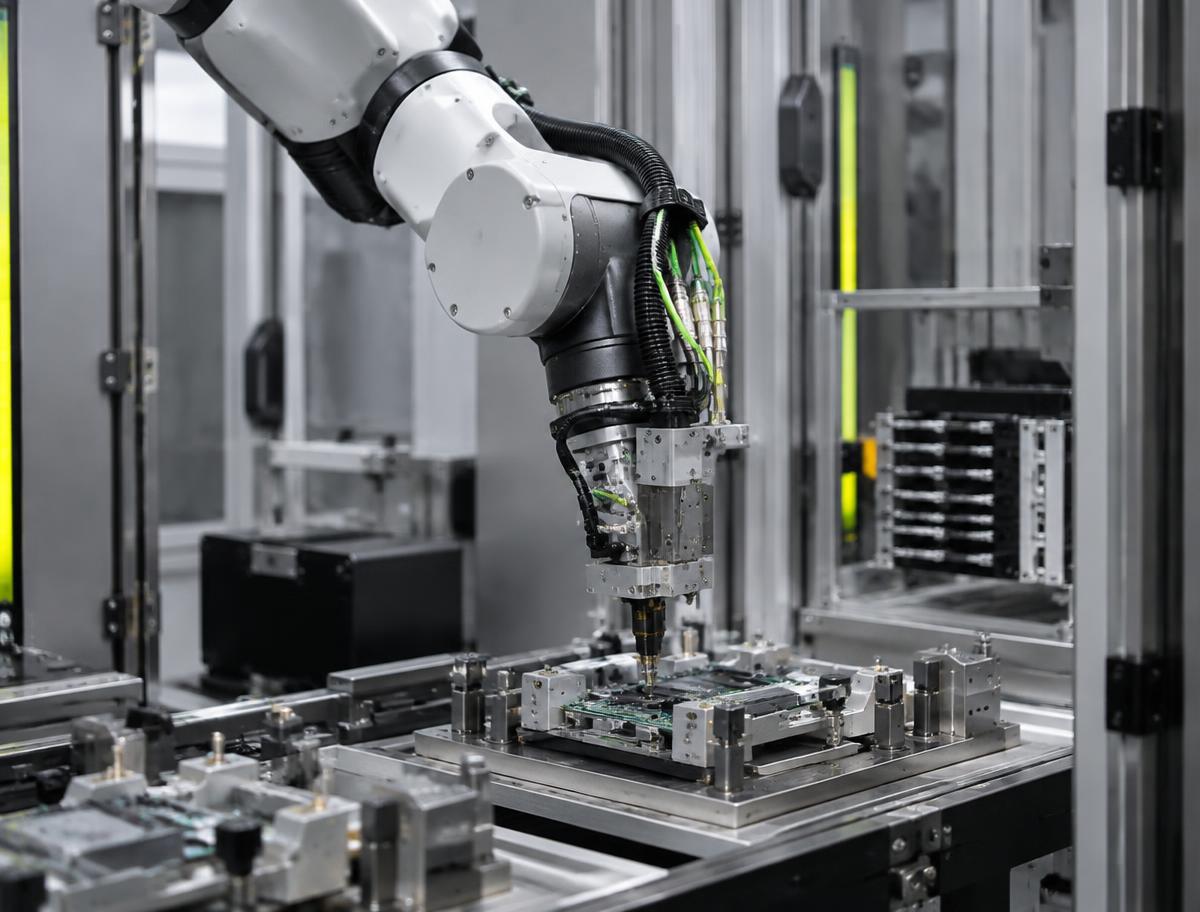
Powertrain & Gearbox Articulated Handling
High-torque articulated handling arms automating engine decking, electric drive unit (EDU) stator-rotor insertion, and transmission pallet transfer.
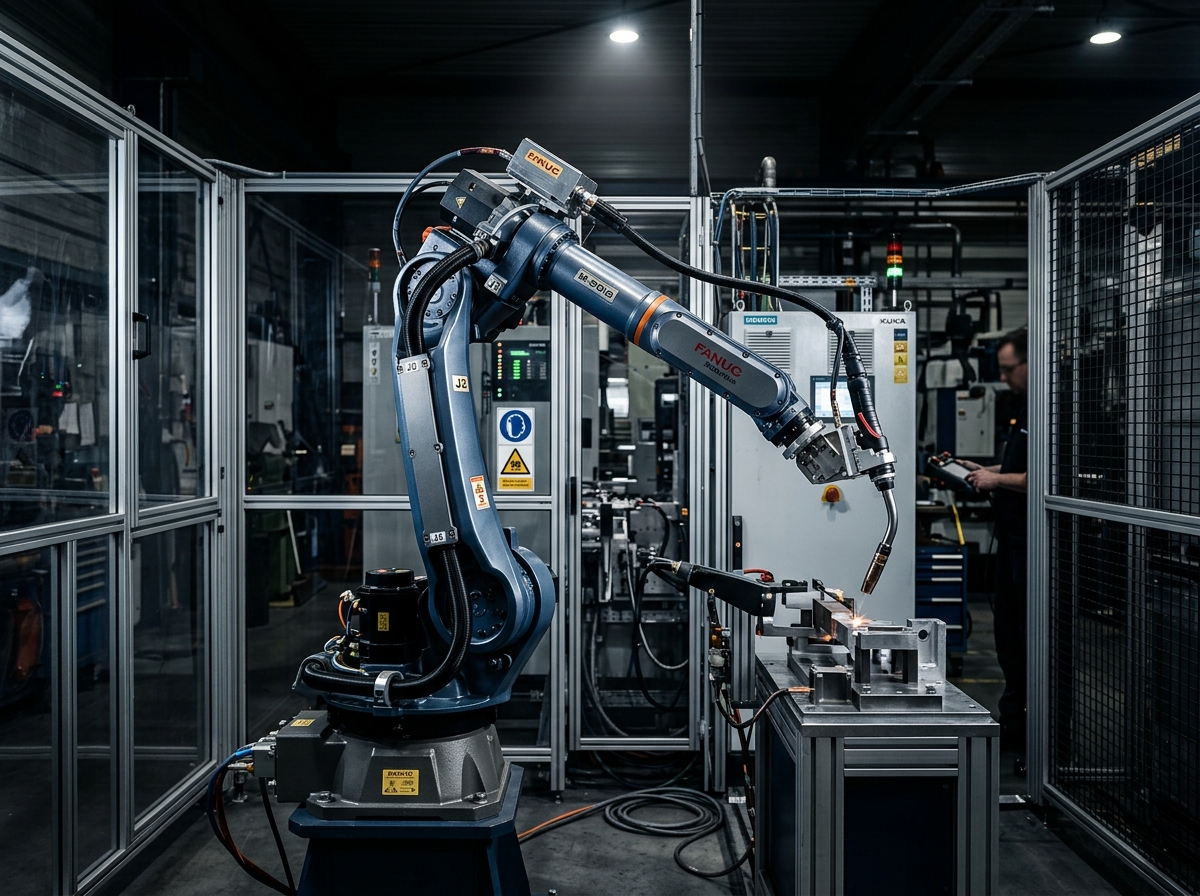
Dual-Gripper CNC Machine Tending Cell
Turnkey robotic tending cell loading and unloading high-tonnage stamping presses and multi-axis CNC milling centers with pneumatic zero-point fixtures.
Select Your Agriculture and Agricultural Technology Automation Requirement
Toggle between core automation processes to inspect matching kinematic models, payload capacities, cycle times, and directly download engineering CAD files.
INDUS-BAT-K150 (7-DOF)
Engineered specifically for prismatic cell stacking, busbar tightening, and high-voltage module casing insertion with constant 6-DOF force/torque regulation.
Agriculture and Agricultural Technology Automation Use Cases
Every production task has specific mechanical shock profiles, positioning tolerances, sensing architectures, and functional safety constraints. Explore detailed engineering breakdowns for each verified operation.
Autonomous Greenhouse Strawberry Selective Harvesting Rover
Strawberries bruise easily and ripen unevenly across plants; severe labor shortages cause millions in field crop spoilage.
Autonomous narrow-chassis mobile rover equipped with dual 6-axis collaborative harvesting arms and soft silicone grippers.
Navigating greenhouse raised gutters, identifying ripe red berries hiding beneath leaves, and harvesting without touching stem.
AI-Powered Sub-Millimeter Laser Weed Eradication Rover
Chemical herbicides contaminate groundwater and create resistant superweeds; manual hand weeding costs $1,500/acre.
High-clearance 4-wheel drive field rover carrying 12 independent high-speed galvo laser targeting pods.
Autonomous tractor or rover moving across commercial vegetable fields, shooting weeds with pulsed CO2 lasers.
Autonomous Vineyard Winter Pruning & Cane Cutting Rover
Dormant winter pruning of wine grapes requires experienced viticulture decisions; winter weather causes severe labor scarcity.
Tracked or 4-wheel steerable crawler robot with articulated 6-axis arm carrying hydraulic/servo pruning shears.
Navigating muddy, terraced hillside vineyard rows and making precise pruning cuts on dormant woody grape canes.
Voluntary Milking System (VMS) Robotic Cow Teat Attachment
Dairy cows arrive voluntarily 24/7; attaching teat cups to moving cow udders requires gentle, rapid spatial tracking.
Heavy articulated hydraulic or stainless servo arm mounted under dairy stall with optical teat tracking camera.
Washing, laser locating, and attaching 4 individual milking cups to cow teats in washdown dairy barn stall.
Multi-Arm Tree Fruit Harvesting Rig for Commercial Orchards
Picking tree fruit (apples, pears, peaches) from tall canopies requires hazardous ladder climbing and manual labor.
Tractor-towed autonomous platform equipped with 4 articulated arms and soft vacuum silicone suction cups.
Moving down orchard canopy tree rows, reaching into leaf canopy, twisting fruit from spur, and funneling into bin.
Vertical Farm High-Speed Hydroponic Seedling Transplanter
Moving germinated lettuce seedlings from dense 288-cell germination trays into grow channels without root tear.
High-speed 4-axis Cartesian or Delta robot equipped with needle-finger root-plug extraction gripper.
High-cadence robotic picking of rockwool seedling plugs and planting into automated vertical NFT hydroponic channels.
Targeted Micro-Dose Crop Spraying Autonomous Drone / Rover
Broadcast spraying wastes 80% of fungicide and pesticide on bare soil between plants, causing chemical runoff.
Autonomous field rover with high-speed PWM solenoid spray nozzles and motorized spray boom.
Traveling field rows at 8 km/h, spraying micro-droplets of fungicide solely onto infected leaf clusters.
Confined-Space Grain Silo & Bin Cleaning Crawling Robot
Entering grain silos to break crusted grain bridges causes dozens of fatal grain entrapment and suffocation incidents annually.
Explosion-proof (ATEX Zone 20) tracked crawling robot with high-torque front crushing auger screw.
Magnetic or tracked robot climbing down internal steel grain bin walls and breaking compacted grain bridges with rotating auger.
High-Speed Agaricus Mushroom Vision Harvesting & Stem Trimming
Fresh button mushrooms double in size every 24 hours in dark humid rooms (18°C, 90% RH); picking requires 24/7 night coverage.
Mobile vertical lift gantry robot with 4-axis picking arm, pneumatic cup, and rotary root knife.
Navigating vertical shelving racks in dark mushroom houses, selecting mature caps, twisting, and trimming root peat.
Adaptive 3D Laser-Contour Sheep Shearing Robotic Manipulator
Manual sheep shearing is grueling seasonal labor; unskilled shearers accidentally nick and cut animal skin folds.
Lightweight articulated robot with capacitive skin proximity sensing cutter head and active force compliance.
Contour-following shearing comb removing wool fleece from live sheep held in comfortable ergonomic hammock cradle.
Autonomous Swine Barn Slatted Floor Pressure Washing Robot
Washing pig housing pens between herds involves ammonia fumes, manure biohazards, and high-pressure hose fatigue.
Heavy-duty waterproof tracked rover carrying articulating high-pressure washing nozzle boom with hose reel tether.
Autonomous navigation through manure-covered concrete slatted pens, blasting 200 bar water jets to remove bio-crust.
Heavy Forestry Timber Harvester Felling & Delimbing Head
Felling, delimbing, and bucking 60-foot pine trees under dynamic tree-fall forces requires extreme hydraulic-servo torque.
Heavy articulated boom harvester head mounted on 25-ton tracked forestry excavator.
Grabbing standing tree trunk, felling with hydraulic saw bar, delimbing branches, and feeding log through measuring rollers.
Manufacturing Challenges & Robotic Solutions
Comparing conventional production bottlenecks against deterministic multi-axis robotic automation.
Agriculture and Agricultural Technology Automation Hurdles
Demanding environmental conditions, high-speed cycle times, and precision limits dictate deterministic robotics.
- Outdoor mud, dust, rain, and UV radiation requiring IP67 sealed drivetrains and corrosion-proof coatings
- Variable outdoor lighting (bright glare, deep leaf shadows) challenging computer vision segmentation
- Delicate biological produce (ripe berries, tomatoes, lettuce) bruised easily by standard mechanical grippers
- Uneven terrain and steep vineyard slopes causing wheel slippage and roll-over risks in mobile rovers
Robotic Automation Potential
High-stiffness mechanical transmission, multi-axis sensory feedback, and real-time motion control.
- High-efficiency planetary wheel drives powered by 48V DC battery buses with regenerative braking on slopes
- AI multispectral vision recognizing ripeness grades and directing micro-laser weed eradication pulses
- Soft pneumatic silicone gripper fingers mimicking human hand picking for soft fruit harvesting
Accelerate Agriculture and Agricultural Technology Automation
Access our specialized kinematics sizing tools, discuss payload vs cycle takt trade-offs, and receive 3D CAD space-claim models verified for this manufacturing discipline.
Connected Ecosystem
Other Manufacturing Sectors
Related Industrial Sectors
- Automotive
High-precision robotics meeting the extreme uptime and sub-millimeter tolerances of modern EV & automotive production.
- Electronics
Sub-micron repeatability and cleanroom-compliant automation for high-density electronic assemblies.
- Manufacturing
Rugged robotic automation engineered for high-uptime machine tending and harsh factory environments.