Construction and Building Materials Robotics
On-site 3D house concrete printing, automated masonry bricklaying, rebar tying, dry-wall sanding, and timber prefabrication.
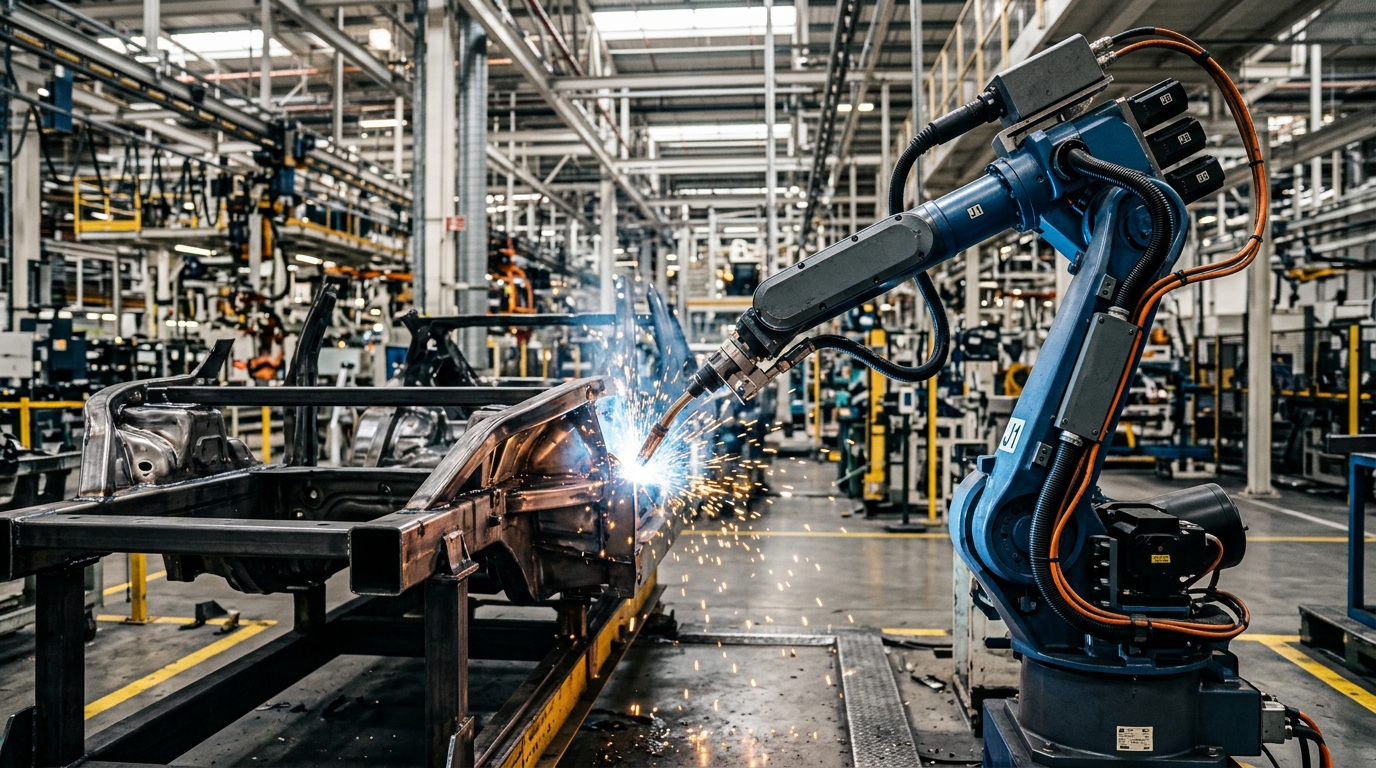
Takt Time Reduction
Down from 78s baseline on EV battery chassis trays
Sub-Millimeter Precision
Closed-loop laser triangulation seam tracking guidance
Max Dynamic Payload
Rigid heavy-duty articulated arm and gantry tooling
Defect Interception & Uptime
Zero unplanned line shutdowns across continuous 24/7 duty
Robotic Applications in Construction and Building Materials
Turnkey robotic workcells, kinematic metrics, and operational architectures deployed across modern construction and building materials manufacturing plants.
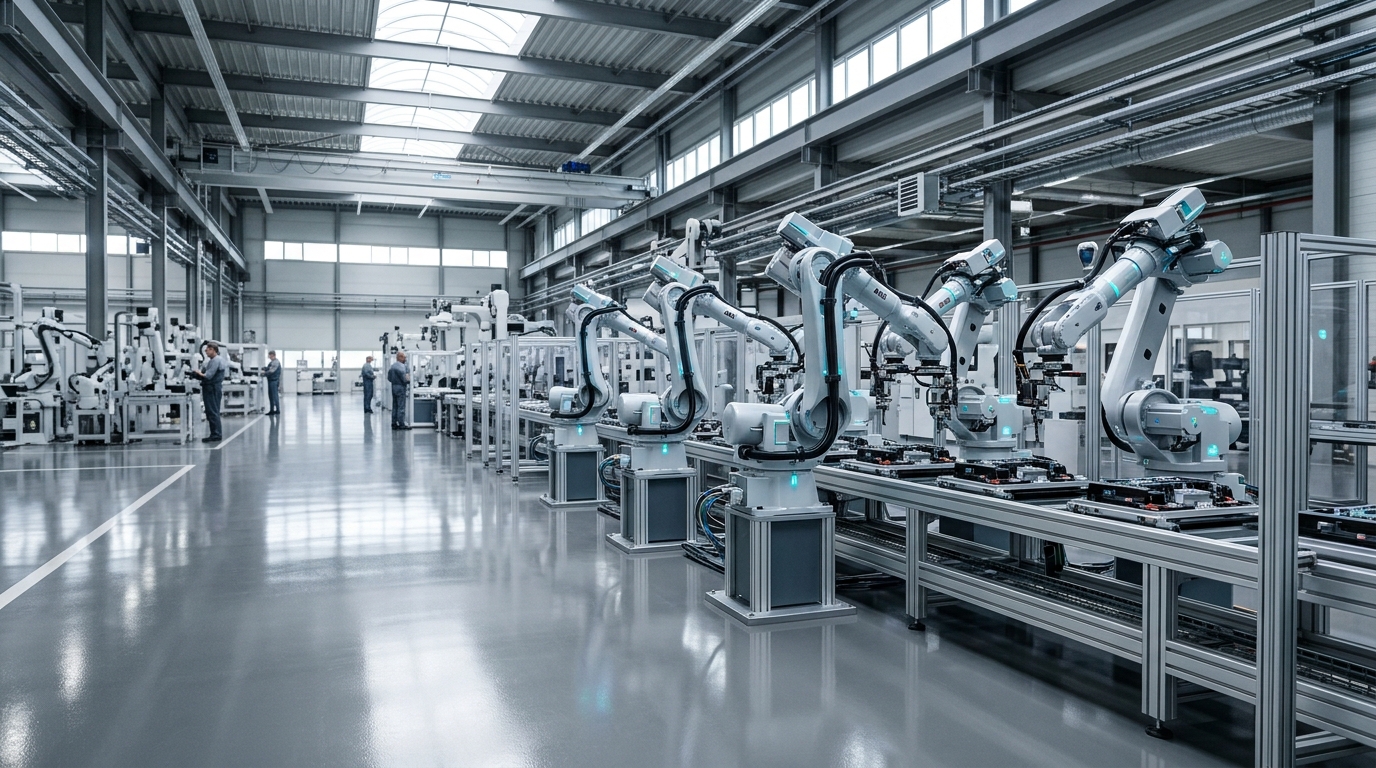
EV Battery Pack Module Assembly Cell
Automated robotic cell executing prismatic and pouch battery cell stacking, busbar laser welding, thermal paste dispensing, and high-voltage isolation testing.
Body-in-White 7th-Axis Gantry Welding
7th-axis linear track robotic spot welding and fiber laser seam joining for automotive body-in-white (BIW) framing and high-strength aluminum door apertures.
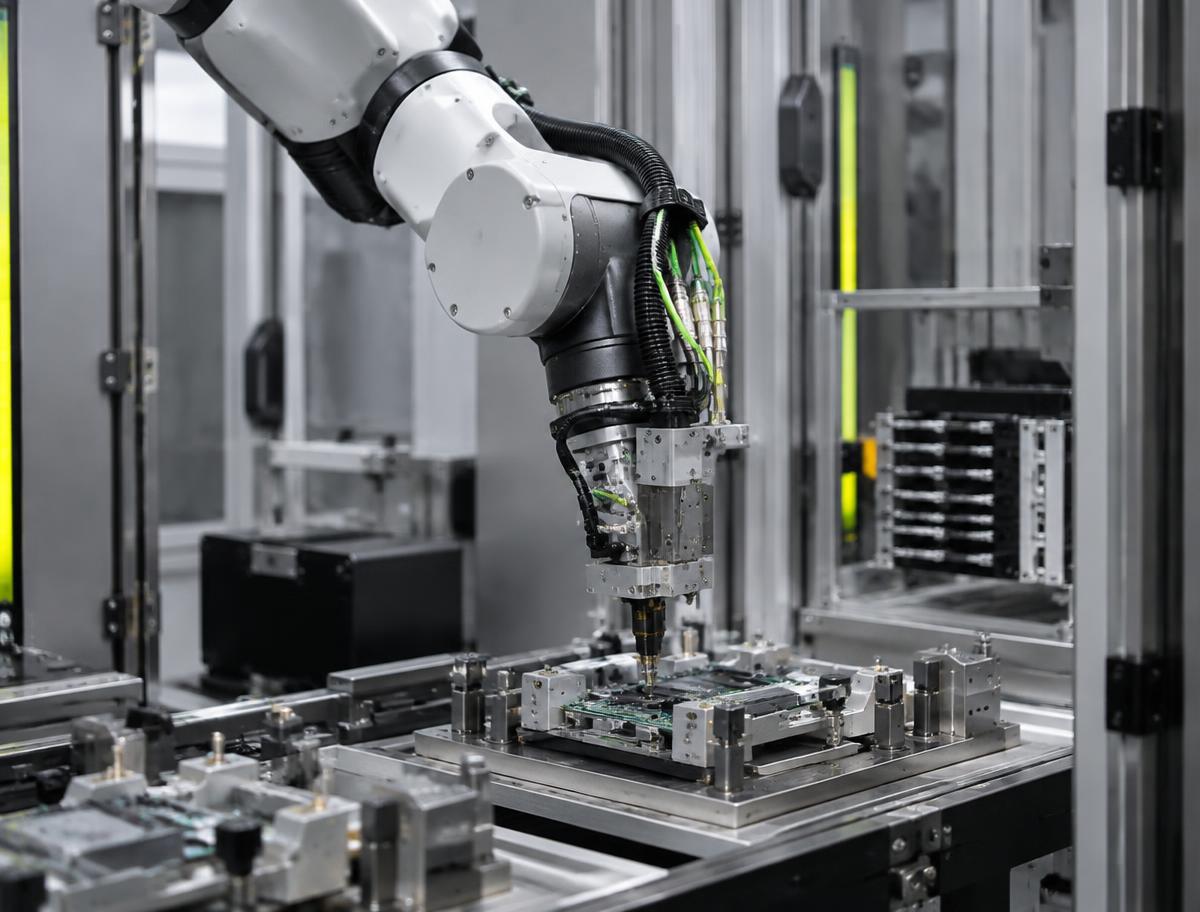
Powertrain & Gearbox Articulated Handling
High-torque articulated handling arms automating engine decking, electric drive unit (EDU) stator-rotor insertion, and transmission pallet transfer.
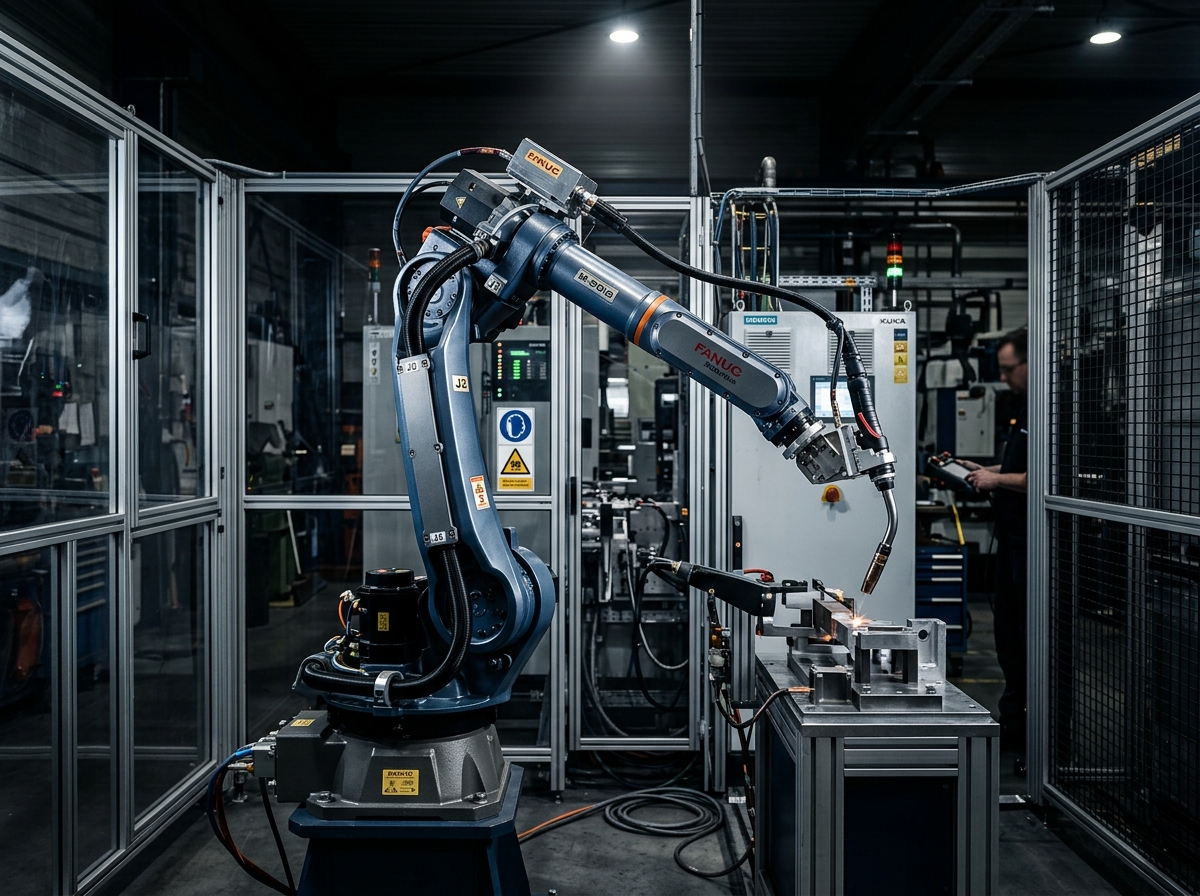
Dual-Gripper CNC Machine Tending Cell
Turnkey robotic tending cell loading and unloading high-tonnage stamping presses and multi-axis CNC milling centers with pneumatic zero-point fixtures.
Select Your Construction and Building Materials Automation Requirement
Toggle between core automation processes to inspect matching kinematic models, payload capacities, cycle times, and directly download engineering CAD files.
INDUS-BAT-K150 (7-DOF)
Engineered specifically for prismatic cell stacking, busbar tightening, and high-voltage module casing insertion with constant 6-DOF force/torque regulation.
Construction and Building Materials Automation Use Cases
Every production task has specific mechanical shock profiles, positioning tolerances, sensing architectures, and functional safety constraints. Explore detailed engineering breakdowns for each verified operation.
On-Site Large-Scale 3D Concrete Architectural Printing
Traditional masonry and concrete formwork requires weeks of skilled carpentry labor and creates massive wood waste.
Large-scale portable modular gantry (15m x 15m x 6m) or long-reach articulated robot arm with continuous mortar nozzle.
Continuous extrusion of fiber-reinforced thixotropic mortar along perimeter wall paths on open outdoor construction site.
Autonomous Bridge Deck Rebar Tying Rover
Manual rebar tying requires workers to bend over for 10 hours daily, tying 30,000 intersections on hot bridge decks.
Tracked or 4-wheel field rover with downward-facing robotic tying arm and steel wire coil spool.
Autonomous navigation across crisscrossed steel rebar grid, locating intersections, and applying wire twist ties.
Autonomous Mobile Masonry Bricklaying Robot (SAM / Hadrian Style)
Severe shortage of skilled bricklayers delays commercial building construction; bricks weigh 3-5 kg each.
Long-reach telescopic boom (up to 12m) mounted on self-leveling mobile truck chassis.
Applying mortar bed and placing standard clay/concrete bricks along exterior architectural wall profiles.
Autonomous Mobile Drywall Taping & Sanding Robot
Drywall mudding and overhead ceiling sanding produces toxic gypsum dust clouds and causes chronic shoulder strain.
Omnidirectional mobile platform equipped with vertical scissor mast and 6-axis collaborative arm with vacuum sander.
Navigating commercial interior building corridors, applying joint compound, and sanding drywall seams to Level 5 finish.
Mass Timber Cross-Laminated (CLT) 6-Axis Joinery Machining
Massive glulam and CLT architectural timber beams (up to 20 meters long, 2 tons) require complex dovetail joints and conduit holes.
High-rail gantry robot with 15 kW heavy wood-milling spindle and 24-station automatic tool changer.
Heavy 6-axis robotic milling, drilling, and chain mortising of massive structural timber beams on 30-meter bed.
High-Rise Glass Curtain Wall Façade Installation Robot
Lifting 400 kg architectural glass panels 50 stories high under gusty wind conditions risks glass shattering and fatal falls.
Floor-anchored mobile crane robot with multi-pad vacuum glass gripper and 6-axis fine micro-adjustment head.
Manipulating heavy architectural insulated glass units (IGUs) from floor opening and bolting onto exterior building brackets.
Autonomous Concrete Floor Troweling & Power Floating Robot
Timing concrete power troweling requires working through night hours; human workers cannot achieve ultra-flat FF/FL floor numbers.
Twin-rotor power trowel modified with electric servo steering, planetary blade pitch actuators, and LiDAR navigation.
Autonomous floating and burnishing of wet concrete slab floors in commercial warehouses to achieve Superflat FF > 100.
Remote-Controlled Electric Hydraulic Demolition Robot (Brokk Style)
Interior demolition of concrete columns and stairwells risks structural collapse and heavy falling debris on human workers.
Compact tracked rubber crawler carrying three-piece articulated boom with hydraulic breaker hammer or concrete crusher.
Breaking reinforced concrete and shearing steel beams inside confined building basements and tunnel shafts.
Robotic Tunnel Boring Shotcrete Concrete Spraying Boom
Manual shotcrete spraying in newly blasted tunnels exposes miners to rockfalls, noxious rebound dust, and tunnel cave-ins.
Heavy articulated telescopic boom mounted on 4-wheel drive underground mining truck with robotic oscillating nozzle head.
Continuous high-velocity spraying of wet-mix fiber concrete (25 m³/hour) onto newly excavated tunnel rock vault.
Precast Concrete Automated Magnetic Shuttering Placement
Manual placement of heavy steel magnetic edge formwork on 50-meter precast concrete casting beds is slow and heavy.
Overhead gantry robot traversing 60-meter precast concrete bed with high-power switchable magnetic gripper.
Reading architectural CAD files, picking steel magnetic edge shutters, and placing them onto steel casting pallet.
Autonomous Utility-Scale Solar Farm Pile Driving Machine
Utility solar projects require driving 500,000 galvanized steel H-piles across desert terrain with exact plumb and elevation.
Tracked crawler pile driver equipped with autonomous mast alignment kinematics and RTK-GPS auto-steering.
Autonomous GPS navigation across uneven desert ground, positioning steel pile, and driving to exact refusal depth with hydraulic hammer.
Autonomous Asphalt Road Pavement Crack Identification & Sealing
Sealing highway cracks manually requires walking on active highways behind hot 200°C asphalt mastic kettles.
Trailer-towed articulated robotic arm mounted behind asphalt heating kettle with specialized hot sealant extrusion nozzle.
Continuous driving at 5 km/h, identifying asphalt road cracks, blowing compressed air, and extruding hot rubberized asphalt sealant.
Manufacturing Challenges & Robotic Solutions
Comparing conventional production bottlenecks against deterministic multi-axis robotic automation.
Construction and Building Materials Automation Hurdles
Demanding environmental conditions, high-speed cycle times, and precision limits dictate deterministic robotics.
- Unstructured mud and outdoor gravel ground conditions causing mobile chassis tipping and calibration loss
- Continuous abrasive silica dust and cement slurry causing premature wear in mechanical linear slides and seals
- Extreme reach and cantilevered bending moments in large gantry concrete 3D printers (>12 meters span)
- Stringent outdoor occupational safety standards (OSHA / EN 13000) for shared human-machinery job sites
Robotic Automation Potential
High-stiffness mechanical transmission, multi-axis sensory feedback, and real-time motion control.
- High-torque RV reducers providing high torsional rigidity on long-reach construction crane arms
- Continuous displacement progressive cavity pumps dispensing thixotropic 3D printing mortar without slump
- Vision-guided rebar tying robots scanning and tying 1,000 intersections per hour on bridge decks
Accelerate Construction and Building Materials Automation
Access our specialized kinematics sizing tools, discuss payload vs cycle takt trade-offs, and receive 3D CAD space-claim models verified for this manufacturing discipline.
Connected Ecosystem
Other Manufacturing Sectors
Related Industrial Sectors
- Automotive
High-precision robotics meeting the extreme uptime and sub-millimeter tolerances of modern EV & automotive production.
- Electronics
Sub-micron repeatability and cleanroom-compliant automation for high-density electronic assemblies.
- Manufacturing
Rugged robotic automation engineered for high-uptime machine tending and harsh factory environments.