Education, Research and Laboratories Robotics
High-throughput chemical screening, synchrotron sample positioning, cryo-EM grid autoloading, autonomous reaction synthesis, and open robotics research.
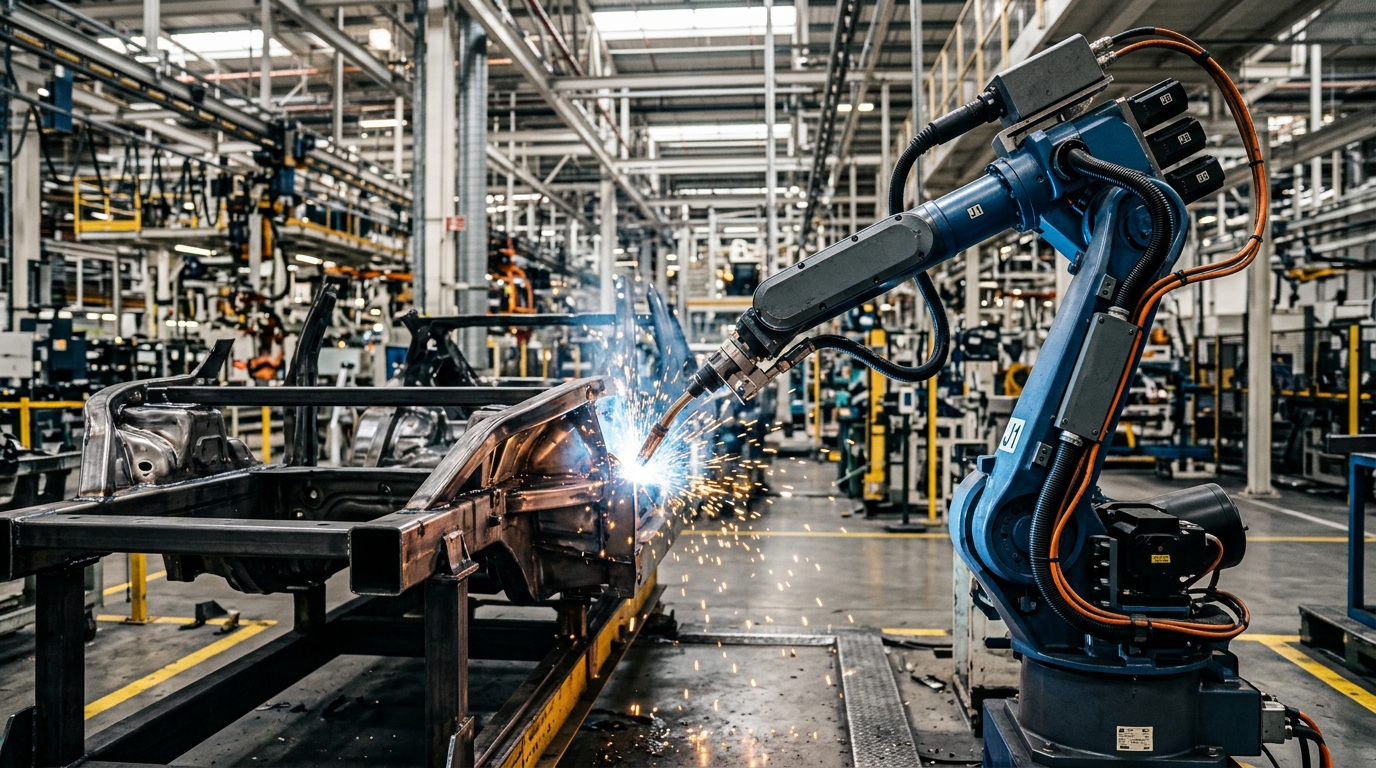
Takt Time Reduction
Down from 78s baseline on EV battery chassis trays
Sub-Millimeter Precision
Closed-loop laser triangulation seam tracking guidance
Max Dynamic Payload
Rigid heavy-duty articulated arm and gantry tooling
Defect Interception & Uptime
Zero unplanned line shutdowns across continuous 24/7 duty
Robotic Applications in Education, Research and Laboratories
Turnkey robotic workcells, kinematic metrics, and operational architectures deployed across modern education, research and laboratories manufacturing plants.
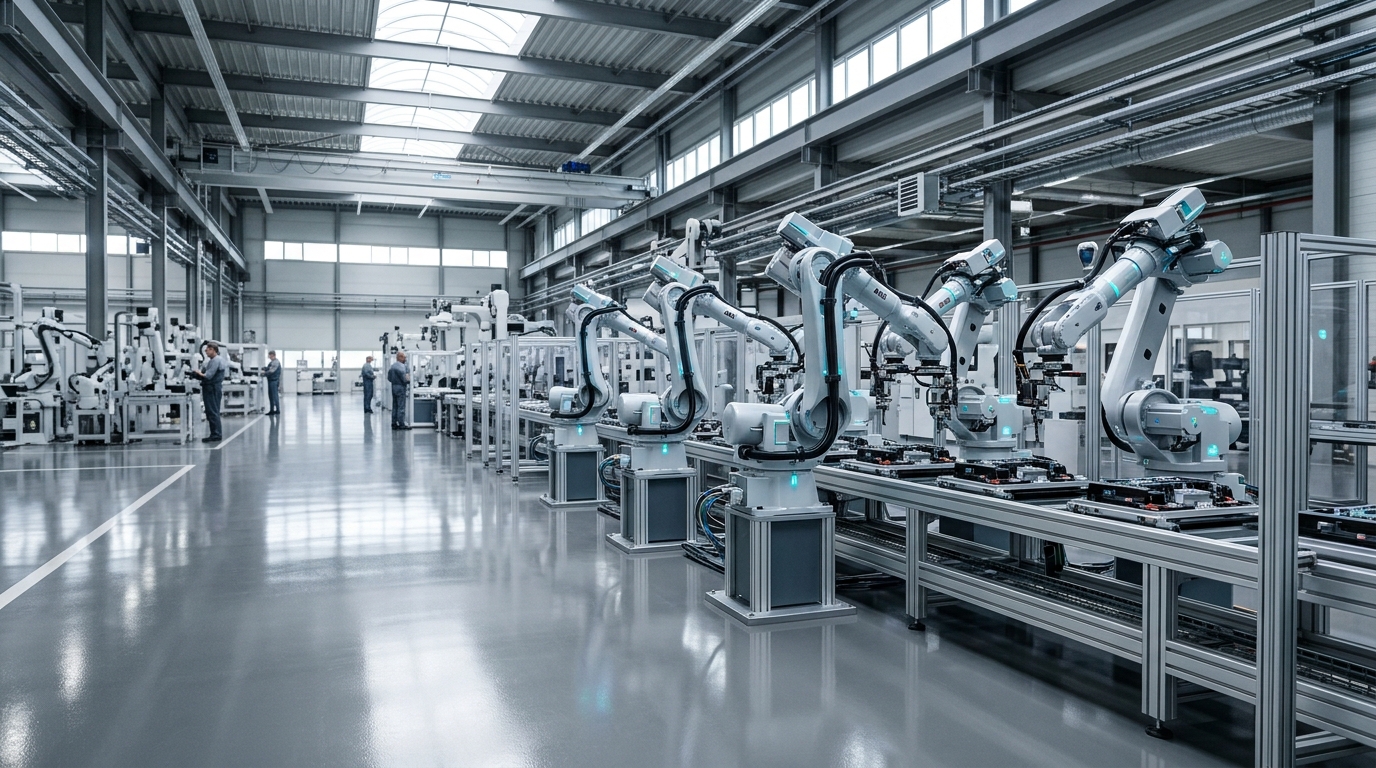
EV Battery Pack Module Assembly Cell
Automated robotic cell executing prismatic and pouch battery cell stacking, busbar laser welding, thermal paste dispensing, and high-voltage isolation testing.
Body-in-White 7th-Axis Gantry Welding
7th-axis linear track robotic spot welding and fiber laser seam joining for automotive body-in-white (BIW) framing and high-strength aluminum door apertures.
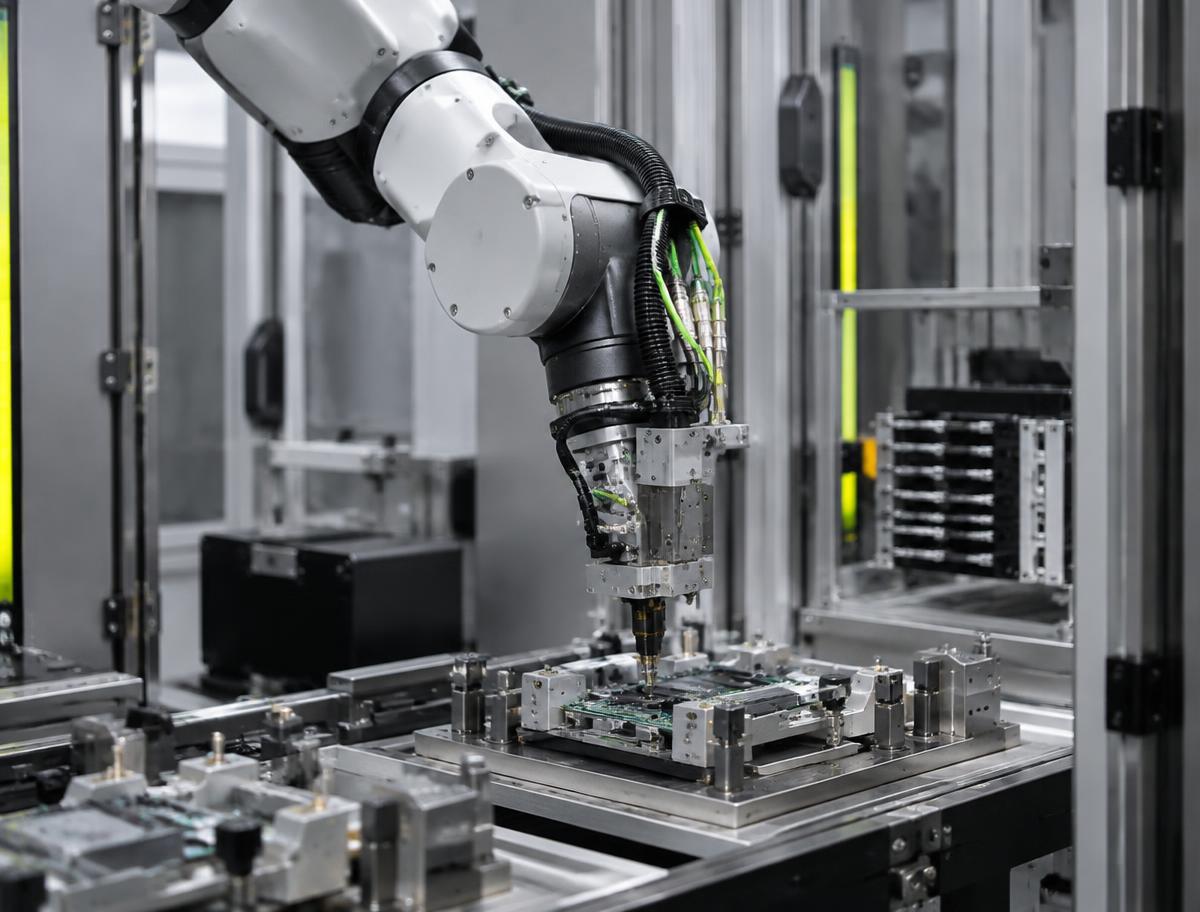
Powertrain & Gearbox Articulated Handling
High-torque articulated handling arms automating engine decking, electric drive unit (EDU) stator-rotor insertion, and transmission pallet transfer.
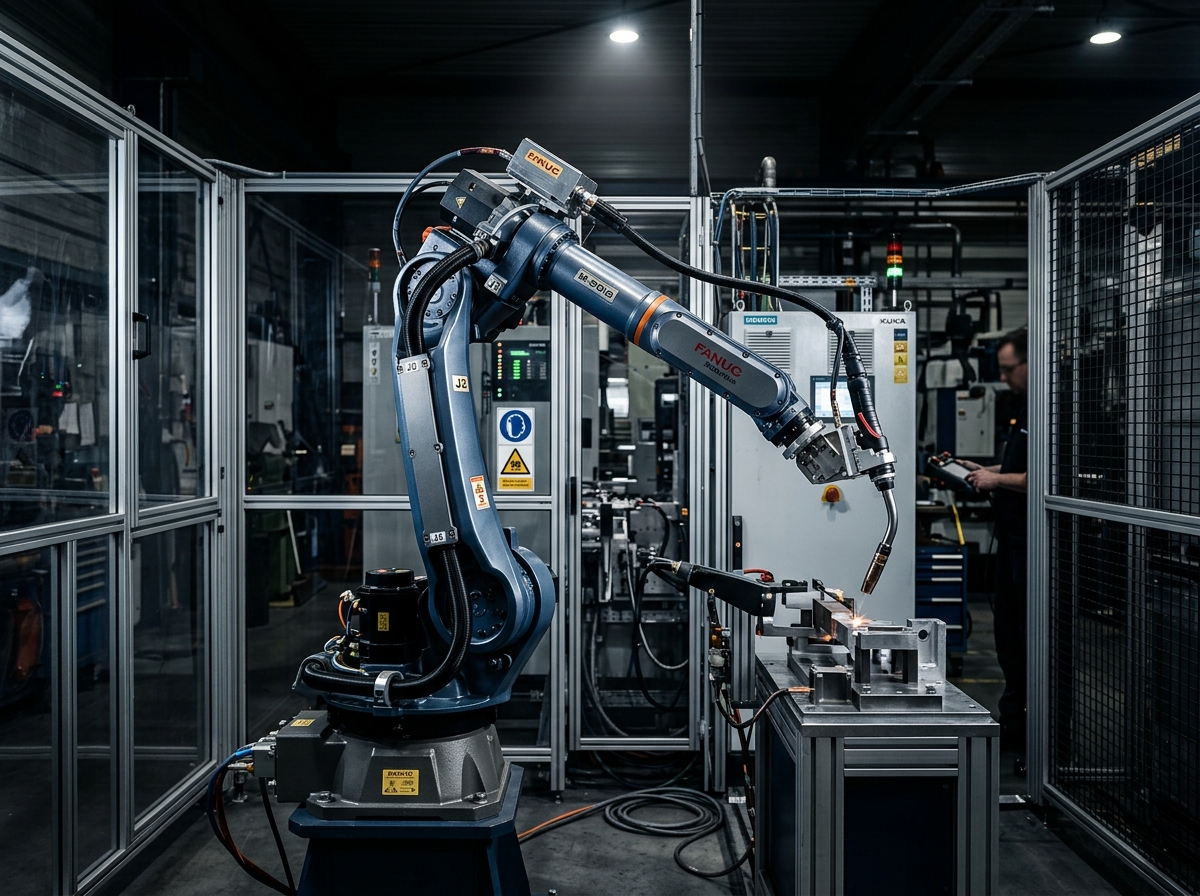
Dual-Gripper CNC Machine Tending Cell
Turnkey robotic tending cell loading and unloading high-tonnage stamping presses and multi-axis CNC milling centers with pneumatic zero-point fixtures.
Select Your Education, Research and Laboratories Automation Requirement
Toggle between core automation processes to inspect matching kinematic models, payload capacities, cycle times, and directly download engineering CAD files.
INDUS-BAT-K150 (7-DOF)
Engineered specifically for prismatic cell stacking, busbar tightening, and high-voltage module casing insertion with constant 6-DOF force/torque regulation.
Education, Research and Laboratories Automation Use Cases
Every production task has specific mechanical shock profiles, positioning tolerances, sensing architectures, and functional safety constraints. Explore detailed engineering breakdowns for each verified operation.
Automated High-Throughput Compound Screening & Liquid Handling
Manual pipetting into 384-well and 1536-well microplates causes repetitive strain, meniscus volume variability, and cross-contamination in drug discovery.
High-Precision 3-Axis Cartesian Pipetting Gantry with 96/384-channel automated fluidic head and plate transport SCARA arm.
Continuous aspirating and dispensing of nanoliter to microliter volumes across thousands of microplate wells in temperature-controlled bio-enclosure.
Synchrotron Radiation Beamline Sub-Micron Sample Positioning Stage
Focusing high-flux synchrotron X-ray beams onto protein microcrystals (<10 µm) requires positioning stability under intense radiation without mechanical backlash.
6-Axis Precision Hexapod (Stewart Platform) or compact robotic arm with radiation-hardened components.
6-DOF sample cryo-pin alignment inside ultra-high vacuum (UHV 10^-9 mbar) and 100 K cryogenic stream under ionizing X-ray radiation.
Automated Microfluidic Organ-on-Chip Cell Culture & Perfusion System
Maintaining physiologically relevant pulsatile shear stress and nutrient perfusion across multi-organ microfluidic biochips requires pulseless nanoliter pumping.
Multi-Channel Micro-Perfusion Robot with motorized syringe pumps and automated chip carousel stage.
Long-term (30+ day) continuous sterile cell media perfusion, automated drug injection, and live confocal fluorescence imaging.
Cryo-Electron Microscopy (Cryo-EM) Vitrified Grid Autoloader
Cryo-EM specimens vitrified in liquid nitrogen (-196°C) are fragile (3 mm grid, 50 nm carbon film); mechanical shock or frost formation ruins expensive microscopy time.
Cryogenic Cartesian Manipulator Arm with high-vacuum magnetic transfer rod and compliant cold-gripper.
Transferring frozen grid cassettes between cryo-storage dewar and transmission electron microscope high-vacuum column.
Robotic Chemical Synthesis & Autonomous Reaction Optimization Workcell
Exploring multi-dimensional chemical reaction spaces (catalysts, ligands, temperatures, solvents) manually is slow and consumes excessive rare reagents.
Closed-Loop Collaborative Robot Arm tending parallel heated/pressurized batch reactors and analytical chromatography carousels.
Automated dosing of solid/liquid reagents into continuous flow micro-reactors, inline HPLC/MS analysis, and AI-driven reaction parameter optimization.
Open-Architecture 7-DOF Research Manipulator with Impedance Control
Commercial industrial robots use closed proprietary controllers that prevent researchers from implementing custom low-level torque, impedance, and AI policies.
7-DOF Anthropomorphic Collaborative Robot Arm with open-source ROS 2, Python, and C++ direct joint-torque API.
Robotics research laboratories developing reinforcement learning, human-robot interaction, and force-sensitive teleoperation algorithms.
Cleanroom Semiconductor Wafer Metrology & AFM Tip Automation
Nanoscale defect characterization on 300 mm silicon wafers requires precise Atomic Force Microscopy (AFM) without surface particulate contamination.
Dual-Arm Cleanroom SCARA / Articulated Robot with Bernoulli non-contact vacuum end-effector.
Transferring patterned wafers from FOUP pods to vacuum chucks and automated sub-nanometer AFM cantilever probe exchange in ISO Class 3 cleanroom.
Radiopharmaceutical Hot-Cell Automated Isotope Dispensing
Dispensing short-lived radioactive therapeutic isotopes (e.g., Lutetium-177, Actinium-225) poses severe gamma/beta radiation hazards to radiopharmacists.
Compact 6-Axis Radiation-Tolerant Articulated Arm with remote motor drive electronics located outside lead shielding.
Remote vial uncapping, syringe aspiration, radioactivity dose calibrator verification, and lead container crimping inside 75 mm lead hot cells.
Automated High-Speed Centrifuge & Analytical Balance Tube Tending
Imbalanced centrifuge rotors cause catastrophic high-speed vibration failures, while manual tare weighing of hundreds of tubes is prone to transcription errors.
Benchtop Collaborative Robot Arm with adaptive dual-finger servo gripper and overhead vision.
Automated 0.1 mg tare weighing of sample falcon tubes, symmetric rotor bucket loading, and post-spin supernatant extraction.
Automated Bioreactor Aseptic In-Line Sampling & Spectrometry
Manual syringe sampling of mammalian cell culture bioreactors risks introducing microbial contamination that destroys 2-week bioprocess batches.
Sterile Cartesian Sampling Station with motorized pinch valves and flow-through spectrophotometer cell.
Aseptic valve actuating, dead-volume purging, sample collection into chilled vials, and automated optical density (OD600) measurement.
Robotic High-Field NMR (Nuclear Magnetic Resonance) Tube Loader
Inserting delicate 5 mm glass NMR sample tubes into high-field superconducting magnets (900 MHz) requires vibration-free vertical alignment.
Non-Magnetic Gantry Arm equipped with pneumatic vacuum suction pick and pneumatic spinner depth gauge.
Continuous unattended loading of 96 sample tubes from cooled carousels into magnet bore under 21 Tesla stray magnetic fields.
Aerodynamic Wind Tunnel Model 6-DOF Dynamic Sting Positioning
Testing aircraft and missile scale models in transonic/supersonic wind tunnels requires measuring aerodynamic forces across dynamic angles of attack under extreme aerodynamic buffeting.
Heavy-Duty Arc-Sector Robotic Manipulator with internal water-cooled strain-gauge balance sting.
High-rigidity multi-axis positioning of model sting balance in Mach 0.2 to 2.5 airstreams with violent aerodynamic flutter.
Manufacturing Challenges & Robotic Solutions
Comparing conventional production bottlenecks against deterministic multi-axis robotic automation.
Education, Research and Laboratories Automation Hurdles
Demanding environmental conditions, high-speed cycle times, and precision limits dictate deterministic robotics.
- Sub-micron and nanometer-scale jitter in optical microscopy and synchrotron radiation beamlines
- Extreme chemical resistance to organic solvents, strong acids, and radioactive radioisotopes
- Need for open API interfaces (ROS 2, EtherCAT, gRPC) allowing researchers to inject custom controllers
- Ultra-low particulate generation conforming to ISO Class 3/4 cleanroom standards for microfluidics
Robotic Automation Potential
High-stiffness mechanical transmission, multi-axis sensory feedback, and real-time motion control.
- Zero-backlash strain-wave reducers and direct-drive torque motors for high-fidelity torque/impedance control
- Piezoelectric and linear motor positioning stages achieving nanometer-scale stepping resolution
- Liquid handling gantry robots dispensing nanoliter droplets with micro-solenoid valves and optical level sensing
Accelerate Education, Research and Laboratories Automation
Access our specialized kinematics sizing tools, discuss payload vs cycle takt trade-offs, and receive 3D CAD space-claim models verified for this manufacturing discipline.
Connected Ecosystem
Other Manufacturing Sectors
Related Industrial Sectors
- Automotive
High-precision robotics meeting the extreme uptime and sub-millimeter tolerances of modern EV & automotive production.
- Electronics
Sub-micron repeatability and cleanroom-compliant automation for high-density electronic assemblies.
- Manufacturing
Rugged robotic automation engineered for high-uptime machine tending and harsh factory environments.