Energy and Utilities Robotics
Subsea pipeline inspection, nuclear hot-cell manipulation, autonomous wind turbine blade repair, solar panel cleaning rovers, and switchyard monitoring.
Takt Time Reduction
Down from 78s baseline on EV battery chassis trays
Sub-Millimeter Precision
Closed-loop laser triangulation seam tracking guidance
Max Dynamic Payload
Rigid heavy-duty articulated arm and gantry tooling
Defect Interception & Uptime
Zero unplanned line shutdowns across continuous 24/7 duty
Robotic Applications in Energy and Utilities
Turnkey robotic workcells, kinematic metrics, and operational architectures deployed across modern energy and utilities manufacturing plants.
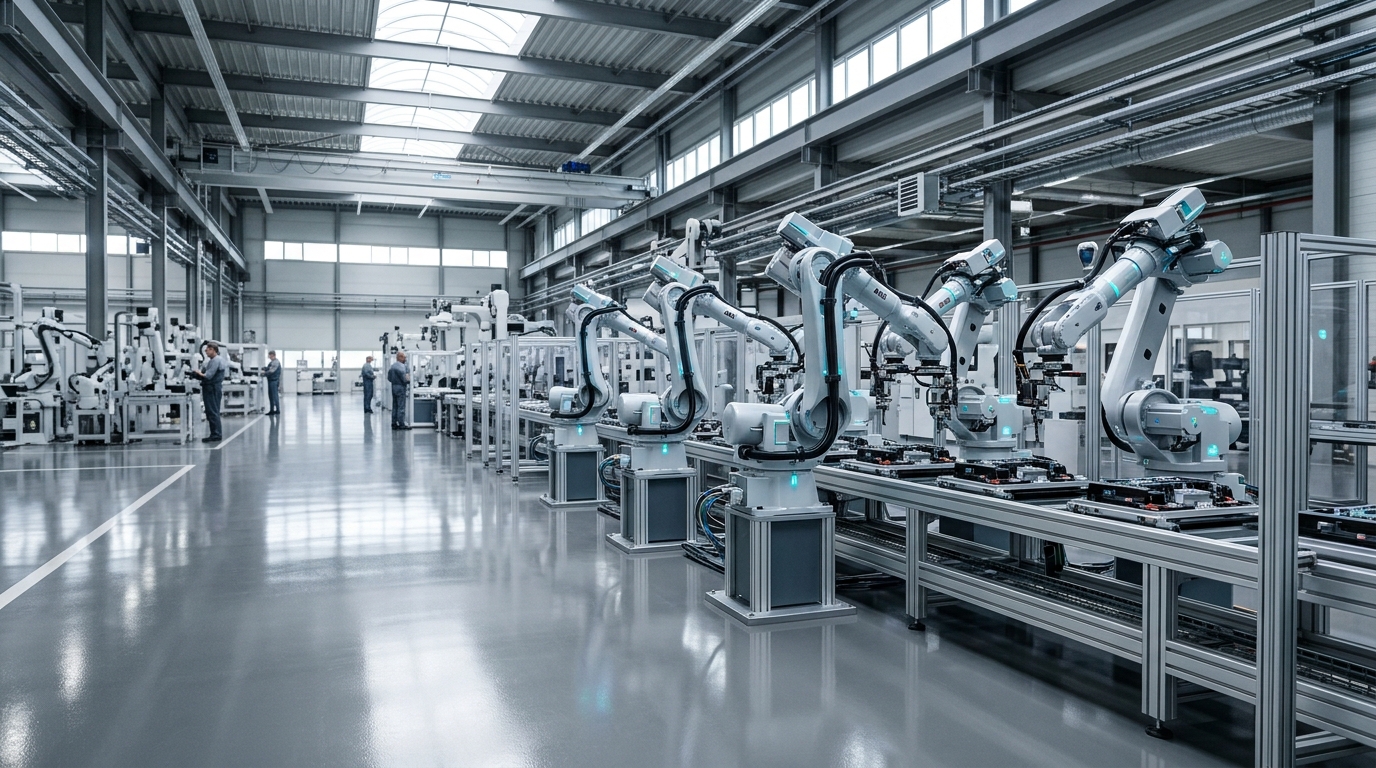
EV Battery Pack Module Assembly Cell
Automated robotic cell executing prismatic and pouch battery cell stacking, busbar laser welding, thermal paste dispensing, and high-voltage isolation testing.
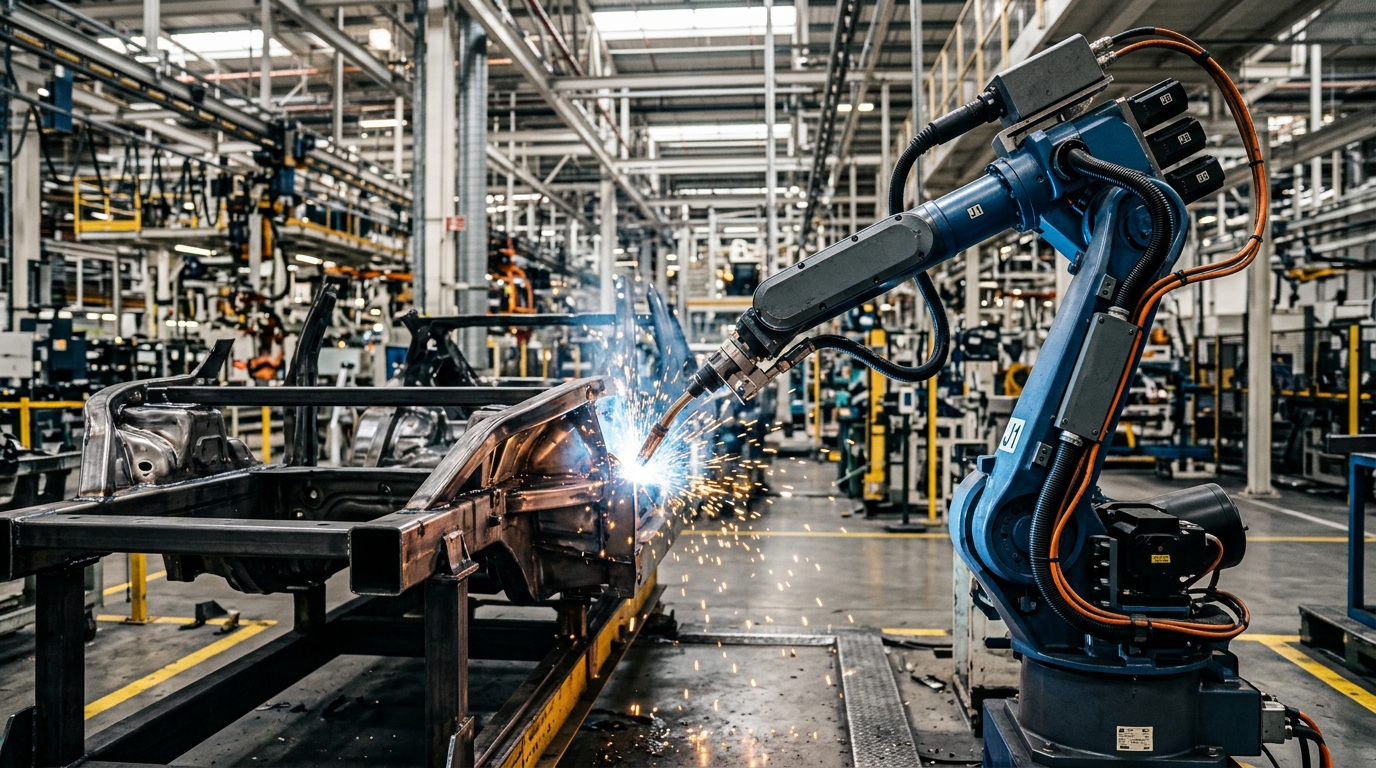
Body-in-White 7th-Axis Gantry Welding
7th-axis linear track robotic spot welding and fiber laser seam joining for automotive body-in-white (BIW) framing and high-strength aluminum door apertures.
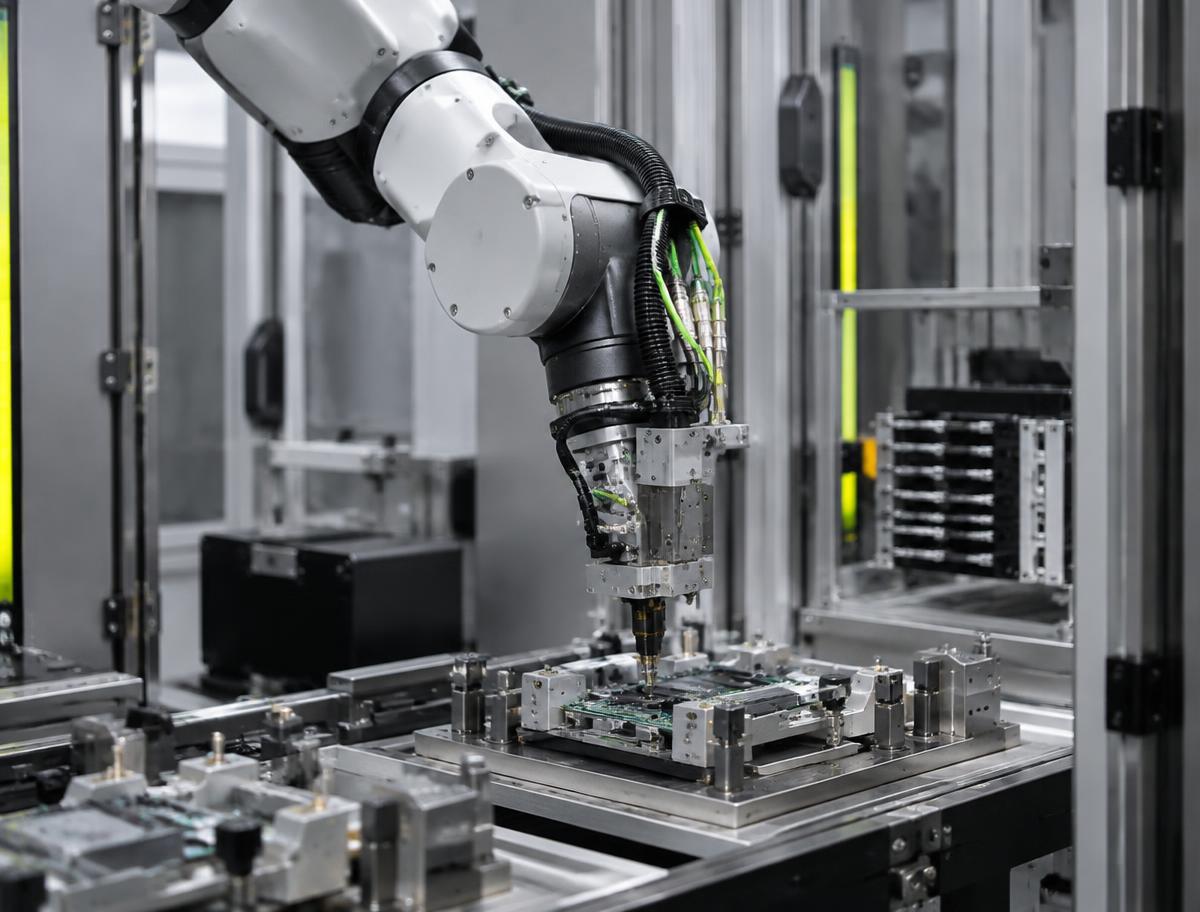
Powertrain & Gearbox Articulated Handling
High-torque articulated handling arms automating engine decking, electric drive unit (EDU) stator-rotor insertion, and transmission pallet transfer.
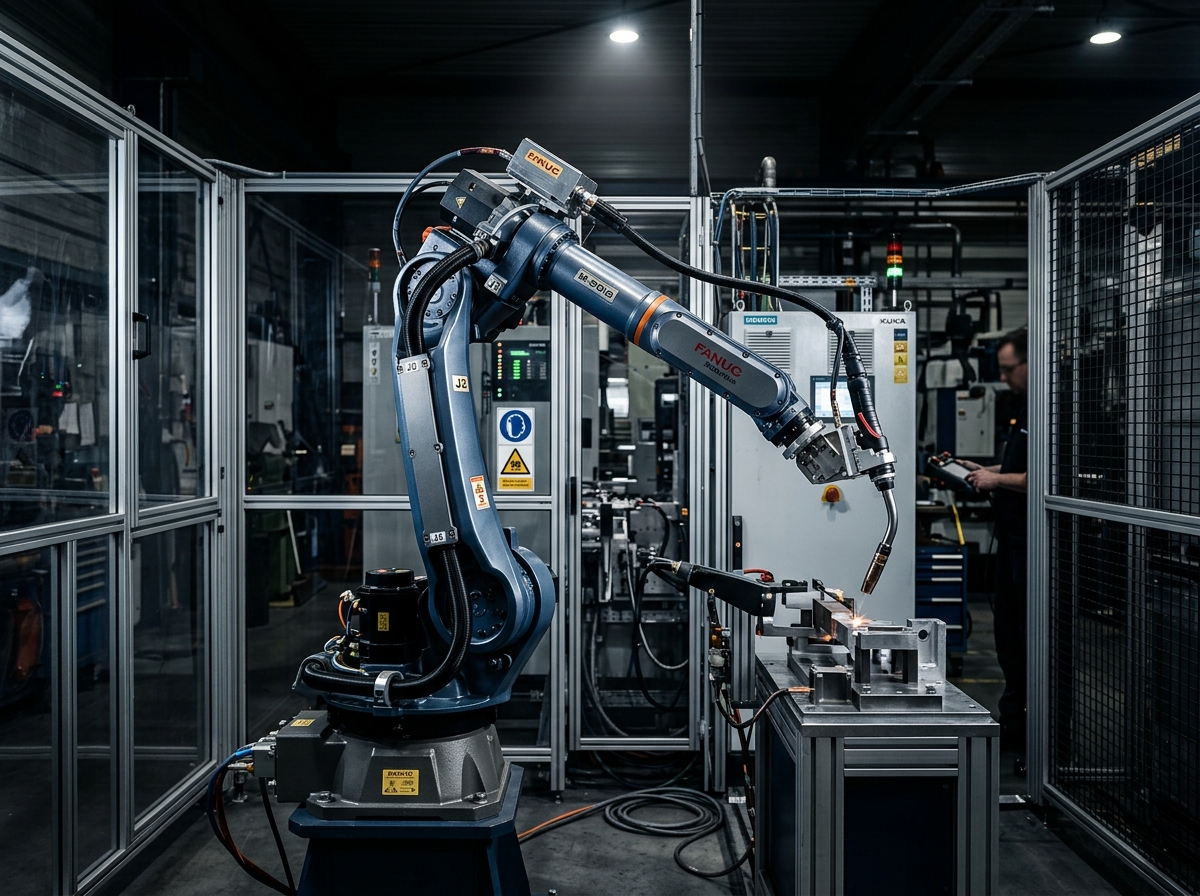
Dual-Gripper CNC Machine Tending Cell
Turnkey robotic tending cell loading and unloading high-tonnage stamping presses and multi-axis CNC milling centers with pneumatic zero-point fixtures.
Select Your Energy and Utilities Automation Requirement
Toggle between core automation processes to inspect matching kinematic models, payload capacities, cycle times, and directly download engineering CAD files.
INDUS-BAT-K150 (7-DOF)
Engineered specifically for prismatic cell stacking, busbar tightening, and high-voltage module casing insertion with constant 6-DOF force/torque regulation.
Energy and Utilities Automation Use Cases
Every production task has specific mechanical shock profiles, positioning tolerances, sensing architectures, and functional safety constraints. Explore detailed engineering breakdowns for each verified operation.
Autonomous Wind Turbine Blade Leading-Edge Repair Crawler
Rain droplet and hail impact erodes wind turbine blade leading edges, degrading aerodynamic efficiency by up to 12%.
Vacuum-adhesion rope-tethered climbing robot equipped with 3-axis mini robotic arm and automated UV resin dispenser.
Climbing vertical 80-meter composite turbine blades at 100m hub height, sanding damaged polyurethane tape, and applying UV resin.
Radiation-Hardened Nuclear Hot-Cell Tele-Robotic Manipulator
Spent nuclear fuel rods emit lethal gamma radiation fields (>100 Gy/hour) that destroy standard silicon microcontrollers in minutes.
Bilateral master-slave tele-manipulator with radiation-hardened resolvers and external drive electronics cabinet outside cell.
Handling, cutting, and containerizing spent nuclear fuel rods and isotope targets inside heavy lead-shielded hot cell.
Waterless Desert Utility-Scale Solar Panel Cleaning Robot
Dust and sand accumulation in desert solar farms reduces energy generation by up to 35%; water is scarce and expensive.
Lightweight track-straddling rover with rotating spiral microfiber brush and vacuum dust suction fan.
Autonomous navigation across 2-kilometer rows of photovoltaic solar panels at 20° tilt, cleaning dust at night with rotating microfiber brush.
Deep-Sea Hydrocarbon Pipeline Ultrasonic & MFL Inspection Crawler
Internal pipe wall corrosion and stress cracking 2,000 meters underwater can cause catastrophic offshore oil spills.
In-line inspection (PIG) robot with articulating drive pods, Magnetic Flux Leakage (MFL) magnets, and ultrasonic sensor rings.
Autonomous crawling inside subsea oil & gas steel pipelines under 200 bar hydrostatic pressure and flammable gas.
500 kV High-Voltage Transmission Line De-Icing & Inspection Robot
Ice loading on high-voltage transmission cables causes power line galloping and tower collapse; line inspection is hazardous by helicopter.
Dual-motorized grooved pulley carriage with articulating joint arm and high-torque ice-crushing rotary rollers.
Rolling along energized 500 kV transmission power cables in winter, crushing ice, and scanning conductor strand fractures.
Nuclear Reactor Core Underwater Remote Operated Inspection Vehicle
Inspecting control rod guide tubes and core shroud welds inside 20-meter deep borated reactor coolant water during refueling outages.
Miniature ROV equipped with four magnetic thrusters, high-radiation camera, and eddy-current probe arm.
Submerged navigation inside nuclear reactor pressure vessel filled with 60°C borated water under high gamma radiation.
Autonomous Electric Substation & Switchyard Security Patrol Rover
Loose electrical busbar connections in 400 kV substations overheat and cause catastrophic transformer fires if unmonitored.
All-terrain 4-wheel drive rover with PTZ thermal/optical camera mast and acoustic partial discharge sensor.
Autonomous 24/7 patrol of high-voltage outdoor electrical substations under all weather conditions, scanning equipment with thermal FLIR.
ITER Fusion Reactor Divertor Cassette Remote Handling System
Tungsten divertor cassette units inside experimental fusion reactors (ITER) weigh 10 tons and become activated by 14 MeV neutrons.
Heavy articulated remote-handling boom crane with multi-axis hydraulic/servo end-effector.
Extracting 10-ton tungsten divertor cassettes through narrow vacuum vessel ports with sub-millimeter trajectory clearance.
Offshore Wind Turbine Tower Flange Automated Bolt Tensioner
Offshore wind towers contain 1,200 heavy M48 bolts per tower; manual hydraulic torque tightening is slow and hazardous in rolling seas.
Magnetic wheel crawler robot with integrated 1,500 bar multi-stud hydraulic bolt tensioning tool.
Autonomous magnetic crawler traversing internal tower ring flange, locking hydraulic tensioner onto M48 studs, and stretching to 850 kN.
Ultra-High Temperature (300°C) Geothermal Wellhead Valve Actuator
Geothermal steam at 300°C containing corrosive hydrogen sulfide (H2S) burns standard motor insulation and melts electronics.
High-temperature electric servo actuator with thermal heat pipe cooling and ceramic insulated brushless motor.
Emergency closing and throttling of high-pressure geothermal steam isolation valves (250 bar, 300°C) at wellhead.
-162°C Liquefied Natural Gas (LNG) Cryogenic Valve Servo Actuator
Liquid natural gas at -162°C causes standard actuator metals to become brittle and freezes standard greases into solid rock.
Electro-mechanical quarter-turn actuator with stainless steel extension bonnet and dry-lubricated planetary gearbox.
Quarter-turn throttling and emergency trip shutoff of cryogenic ball valves on LNG carrier ships and regasification terminals.
Autonomous Inspection Rover for Underground High-Voltage Cable Tunnels
City power cables run through miles of cramped underground tunnels with stagnant air, standing water, and high-voltage risks.
Tracked amphibious rover or monorail suspended robot carrying gas sensors, thermal imager, and LiDAR.
Patrolling 20 kilometers of urban underground cable tunnels, detecting oil leaks from fluid-filled 132 kV cables and gas accumulation.
Manufacturing Challenges & Robotic Solutions
Comparing conventional production bottlenecks against deterministic multi-axis robotic automation.
Energy and Utilities Automation Hurdles
Demanding environmental conditions, high-speed cycle times, and precision limits dictate deterministic robotics.
- High-voltage electromagnetic fields (EMF) and corona discharge inducing noise in encoder digital communications
- Radiation exposure in nuclear reactor containment causing semiconductor gate breakdown and optics browning
- Extreme offshore marine corrosion (ISO 12944 C5M) and subsea hydrostatic water pressure
- Climbing vertical composite wind turbine blades under turbulent 12 m/s wind gusts at 100m hub heights
Robotic Automation Potential
High-stiffness mechanical transmission, multi-axis sensory feedback, and real-time motion control.
- Radiation-tolerant resolvers and solid MoS2 lubricated strain-wave reducers for nuclear hot cells
- Autonomous suction-crawler robots inspecting and sanding offshore wind turbine leading edge erosion
- Waterless microfiber roller autonomous rovers cleaning utility-scale desert solar arrays at night
Accelerate Energy and Utilities Automation
Access our specialized kinematics sizing tools, discuss payload vs cycle takt trade-offs, and receive 3D CAD space-claim models verified for this manufacturing discipline.
Connected Ecosystem
Other Manufacturing Sectors
Related Industrial Sectors
- Automotive
High-precision robotics meeting the extreme uptime and sub-millimeter tolerances of modern EV & automotive production.
- Electronics
Sub-micron repeatability and cleanroom-compliant automation for high-density electronic assemblies.
- Manufacturing
Rugged robotic automation engineered for high-uptime machine tending and harsh factory environments.