Food and Beverage Processing Robotics
High-speed delta robot picking, meat portioning, robotic bakery de-panning, bottle packing, and washdown palletizing.
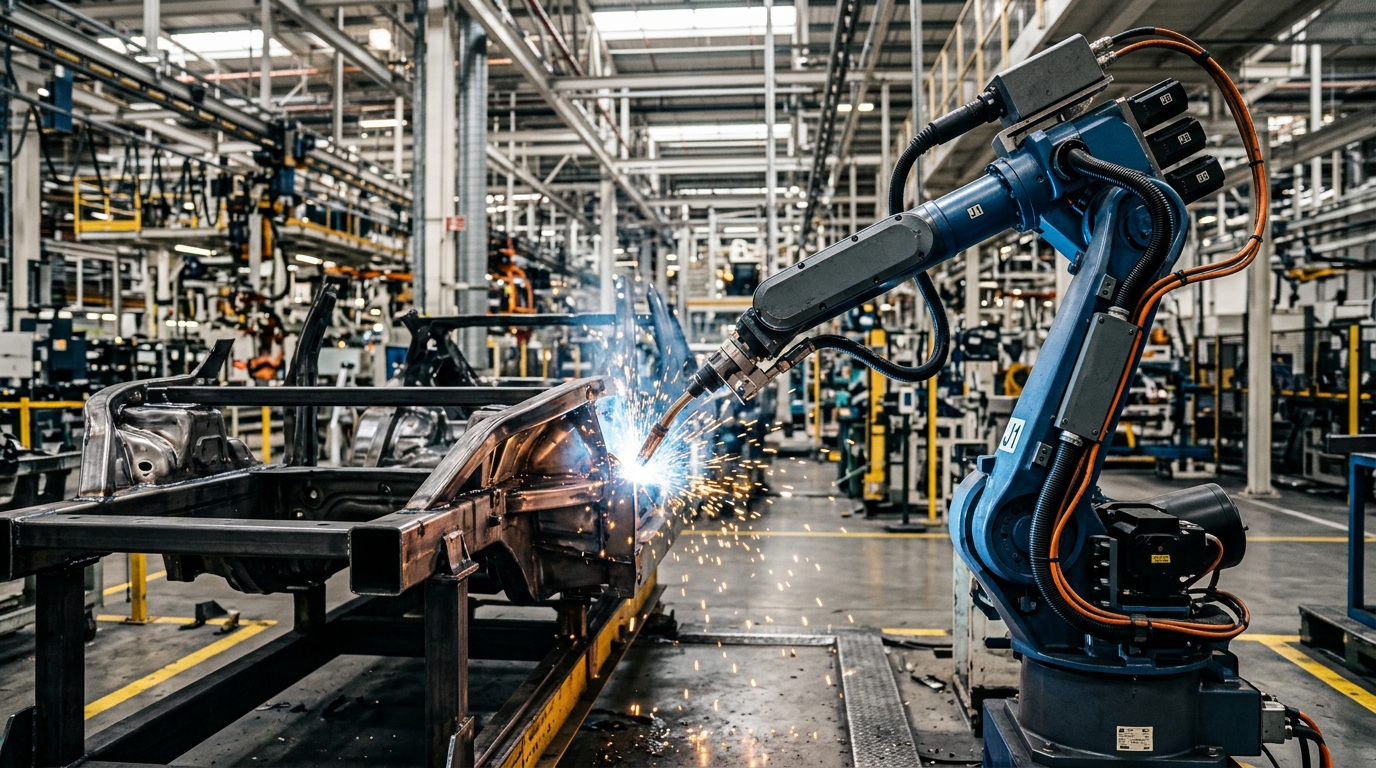
Takt Time Reduction
Down from 78s baseline on EV battery chassis trays
Sub-Millimeter Precision
Closed-loop laser triangulation seam tracking guidance
Max Dynamic Payload
Rigid heavy-duty articulated arm and gantry tooling
Defect Interception & Uptime
Zero unplanned line shutdowns across continuous 24/7 duty
Robotic Applications in Food and Beverage Processing
Turnkey robotic workcells, kinematic metrics, and operational architectures deployed across modern food and beverage processing manufacturing plants.
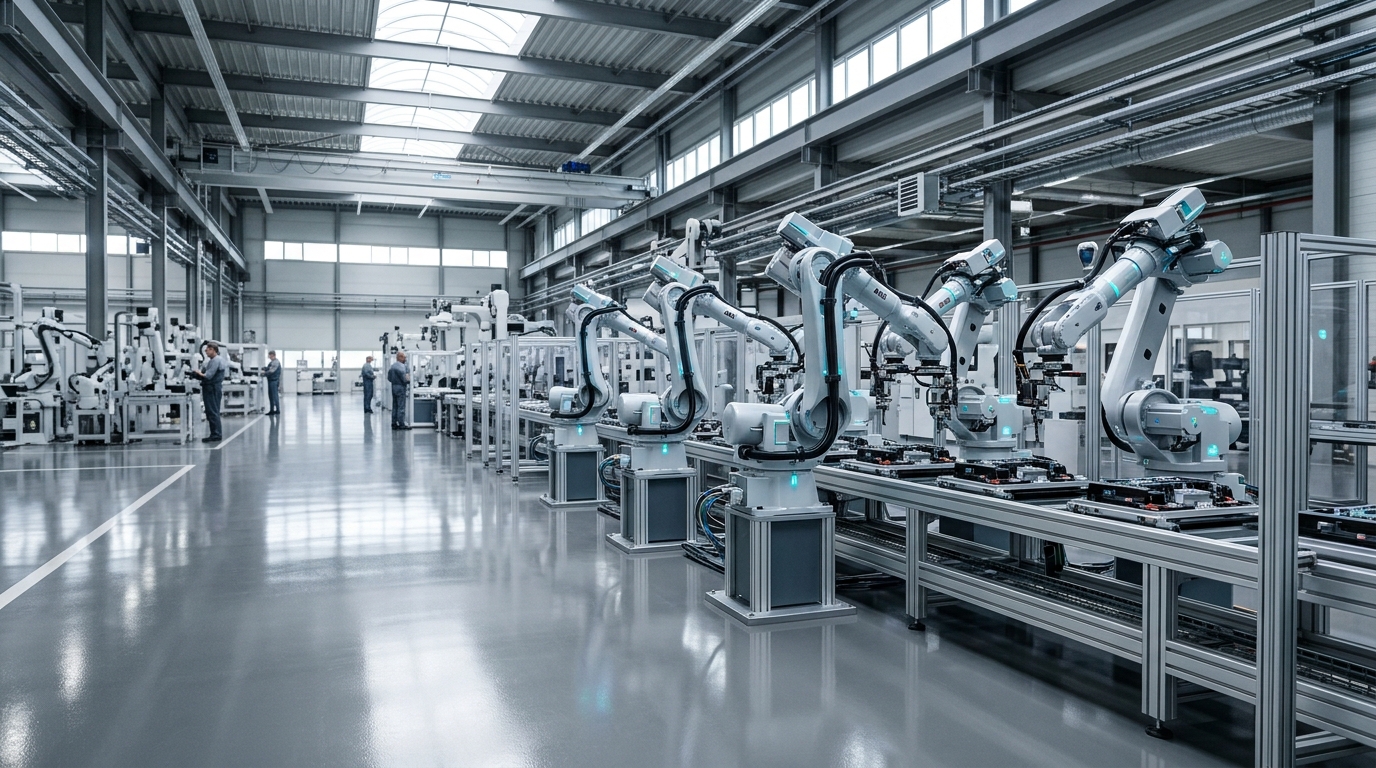
EV Battery Pack Module Assembly Cell
Automated robotic cell executing prismatic and pouch battery cell stacking, busbar laser welding, thermal paste dispensing, and high-voltage isolation testing.
Body-in-White 7th-Axis Gantry Welding
7th-axis linear track robotic spot welding and fiber laser seam joining for automotive body-in-white (BIW) framing and high-strength aluminum door apertures.
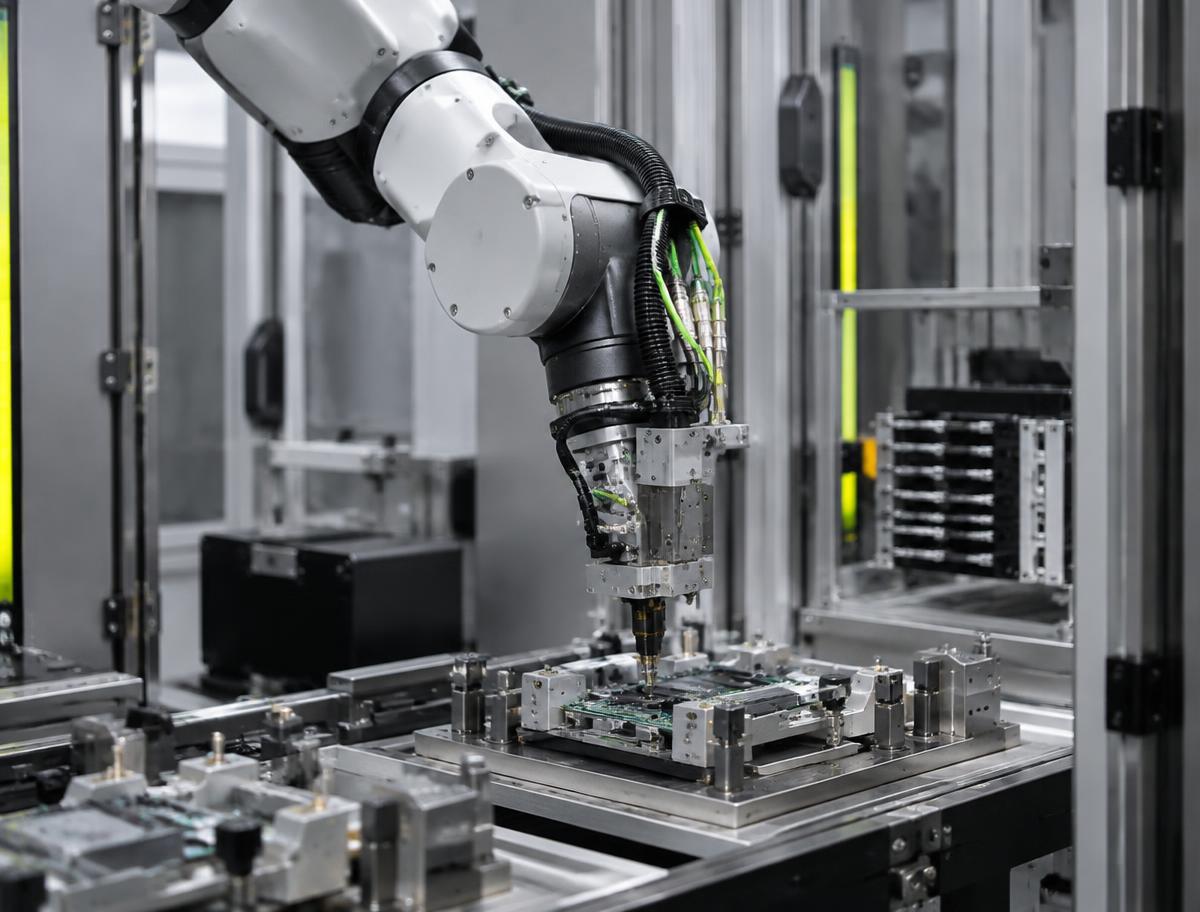
Powertrain & Gearbox Articulated Handling
High-torque articulated handling arms automating engine decking, electric drive unit (EDU) stator-rotor insertion, and transmission pallet transfer.
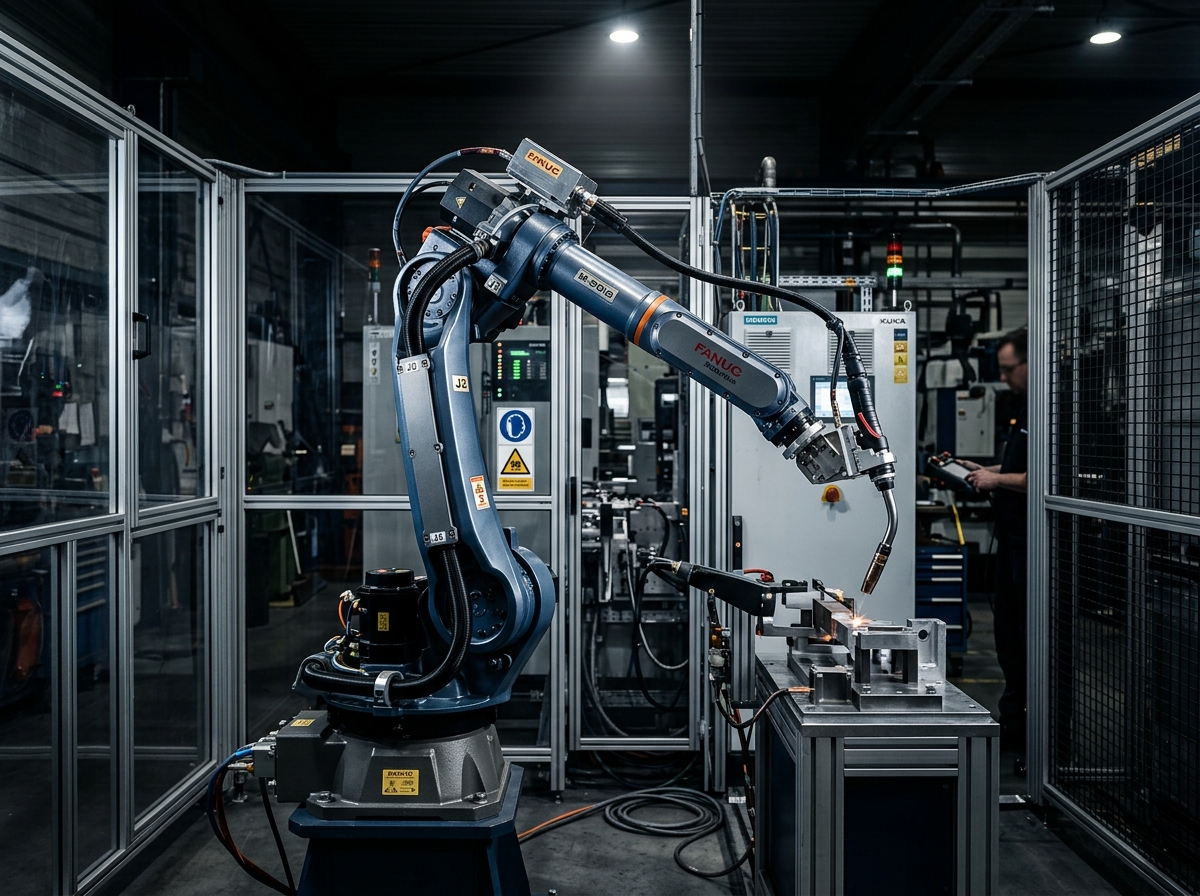
Dual-Gripper CNC Machine Tending Cell
Turnkey robotic tending cell loading and unloading high-tonnage stamping presses and multi-axis CNC milling centers with pneumatic zero-point fixtures.
Select Your Food and Beverage Processing Automation Requirement
Toggle between core automation processes to inspect matching kinematic models, payload capacities, cycle times, and directly download engineering CAD files.
INDUS-BAT-K150 (7-DOF)
Engineered specifically for prismatic cell stacking, busbar tightening, and high-voltage module casing insertion with constant 6-DOF force/torque regulation.
Food and Beverage Processing Automation Use Cases
Every production task has specific mechanical shock profiles, positioning tolerances, sensing architectures, and functional safety constraints. Explore detailed engineering breakdowns for each verified operation.
High-Speed (150 PPM) Delta Robot Chocolate Blister Packaging
Delicate chocolates arriving randomly oriented on cooling belts must be picked without marking glossy surface finish.
Parallel kinematic 4-axis Delta robot with lightweight carbon fiber arms and food-grade silicone suction cups.
Continuous vision tracking of unstructured chocolates on sanitary blue conveyor belt and placing into thermoformed blister trays.
Robotic 3D Vision Ultrasonic Cheese & Meat Slicing
Natural cheese blocks have irregular densities and shapes; fixed-width slicing yields variable package weights violating retail trade laws.
High-rigidity articulated robot arm equipped with ultrasonic titanium cutting horn and laser scanner.
3D laser surface profiling of irregular cheese blocks and cutting exact fixed-weight wedges with 20 kHz vibrating titanium blade.
High-Temperature Robotic Bakery Bread Pan De-Panning
Baking pans exiting ovens at 220°C cause severe burns for human operators; suction cups degrade rapidly under dry heat.
4-axis articulated or gantry robot equipped with high-temperature silicone suction array and pan clamp shaker.
Lifting baked bread loaves out of hot baking pans and placing onto cooling conveyors at 60 loaves per minute.
Vision-Guided Robotic Poultry Front-Half Deboning
Natural biological variations in chicken carcass dimensions make fixed mechanical knives cut into bone, contaminating meat with bone fragments.
Dual-arm stainless steel washdown robots operating coordinated adaptive cutting knives.
Continuous 3D X-ray bone detection and robotic filleting of breast meat from cold poultry carcasses in 4°C wet room.
High-Speed Robotic Beverage Bottle Case Packing
Glass beverage bottles arriving on multi-lane conveyors must be packed into 24-count cardboard cases without clashing or chipping.
Heavy-payload articulated robot or 2-axis gantry with multi-bottle pneumatic gripper tool.
Simultaneous gripping of 24 glass bottles via inflatable pneumatic neck grippers and gentle placement into corrugated cases.
End-of-Line Washdown Palletizing in Chilled Meat Packing
Cold, humid meat processing packaging rooms (4°C, 95% RH) cause electrical condensation and corrosion in standard palletizers.
IP67/IP69K protected 4-axis palletizing robot with stainless steel base mounting and food-grade grease.
Stacking 25 kg wet corrugated meat boxes onto wooden pallets with daily evening chemical washdown.
Robotic 3D Cake Custom Icing & Laser Writing
Custom celebration cake decorating is highly skilled and slow; bakeries cannot scale customized personalized messaging.
Compact collaborative robot arm with multi-nozzle food-grade servo extrusion pump.
Dispensing decorative buttercream borders and writing personalized laser-scanned text on fresh bakery cakes.
High-Speed Sausage Casing Linking & Smoking Stick Hanging
Fresh stuffed collagen sausage links exiting high-speed extruders at 2,000 links/minute break if transferred with jerk.
High-speed servo synchronized rotary looper mechanism with robotic stick transfer shuttle.
Looping continuous sausage string onto stainless steel smoking smokehouse sticks with synchronized high-speed hooks.
Robotic Fragile Waffle Cone Sleeving & Carton Insertion
Crisp waffle ice cream cones are brittle and easily crack under mechanical gripper clamping pressures.
High-speed Delta robot equipped with soft pneumatically actuated silicone finger gripper.
Picking baked waffle cones from cooling carousel, placing into paper sleeves, and packing into multi-pack cartons.
Robotic High-Pressure Pure Waterjet Salmon Fillet Trimming
Fish fillets have irregular brown fat lines and pin bones; mechanical knives smear flesh and create ragged edges.
High-speed 2-axis Cartesian robot over conveyor with dual ultra-high pressure pure water cutting nozzles.
Trimming belly flap fat and defect dark meat from fresh salmon fillets using pure sterile waterjet at 3,000 bar.
Robotic Gouda Cheese Wheel Wax Dipping & Inversion
Dipping 12 kg Gouda cheese wheels into 85°C molten protective wax requires even coating thickness without air pockets.
Articulated robot with heat-resistant dual clamp gripper and integrated rotary wrist roll.
Robotic grip, dipping half-wheel into molten wax bath, drying, inverting, and dipping opposing half on continuous line.
High-Speed Robotic Fresh Apple Optical Grading & Tray Pack
Bruised apples rot in transit; traditional roller sorters cannot inspect the stem-end and calyx areas where defects hide.
Array of 4 Delta robots over fruit roller infeed lane with soft vacuum suction bellows.
Rotating fruit in front of 3D multi-spectral cameras and picking into retail pulp trays based on color and blemish grade.
Heavy Stainless Beer Keg Robotic De-Palletizing & Washing Tending
Full 50-liter beer kegs weigh 62 kg and have wet slippery rims; manual handling causes severe spinal injuries in breweries.
Heavy articulated industrial robot (150 kg payload) equipped with hydraulic/servo external rim clamping jaws.
Gripping 62 kg stainless kegs from returned pallet stacks, orienting spear downward, and loading onto automated caustic washing carousel.
Manufacturing Challenges & Robotic Solutions
Comparing conventional production bottlenecks against deterministic multi-axis robotic automation.
Food and Beverage Processing Automation Hurdles
Demanding environmental conditions, high-speed cycle times, and precision limits dictate deterministic robotics.
- Caustic and acidic cleaning chemicals (chlorinated alkaline, peracetic acid) corroding standard aluminum housings
- Fragile, non-rigid natural food items (berries, fish fillets, dough) easily bruised by mechanical gripping
- Extreme packaging speeds (up to 150 picks per minute on delta robot packaging lines)
- Strict hygiene regulations prohibiting any horizontal pooling surfaces or exposed bolt threads where listeria can harbor
Robotic Automation Potential
High-stiffness mechanical transmission, multi-axis sensory feedback, and real-time motion control.
- Electropolished 316L stainless steel planetary gearboxes with IP69K seals and FDA Viton gaskets
- Soft-pneumatic adaptive silicone grippers mimicking human fingers for gentle fruit handling
- 3D color and hyperspectral vision sorting detecting foreign contaminants and product defects on moving belts
Accelerate Food and Beverage Processing Automation
Access our specialized kinematics sizing tools, discuss payload vs cycle takt trade-offs, and receive 3D CAD space-claim models verified for this manufacturing discipline.
Connected Ecosystem
Other Manufacturing Sectors
Related Industrial Sectors
- Automotive
High-precision robotics meeting the extreme uptime and sub-millimeter tolerances of modern EV & automotive production.
- Electronics
Sub-micron repeatability and cleanroom-compliant automation for high-density electronic assemblies.
- Manufacturing
Rugged robotic automation engineered for high-uptime machine tending and harsh factory environments.