Humanoid, Service and Mobile Robotics Robotics
Bipedal humanoid locomotion, dexterous robotic hands, high-payload AMR drive pods, dynamic quadrupeds, surgical avatars, and powered exoskeletons.
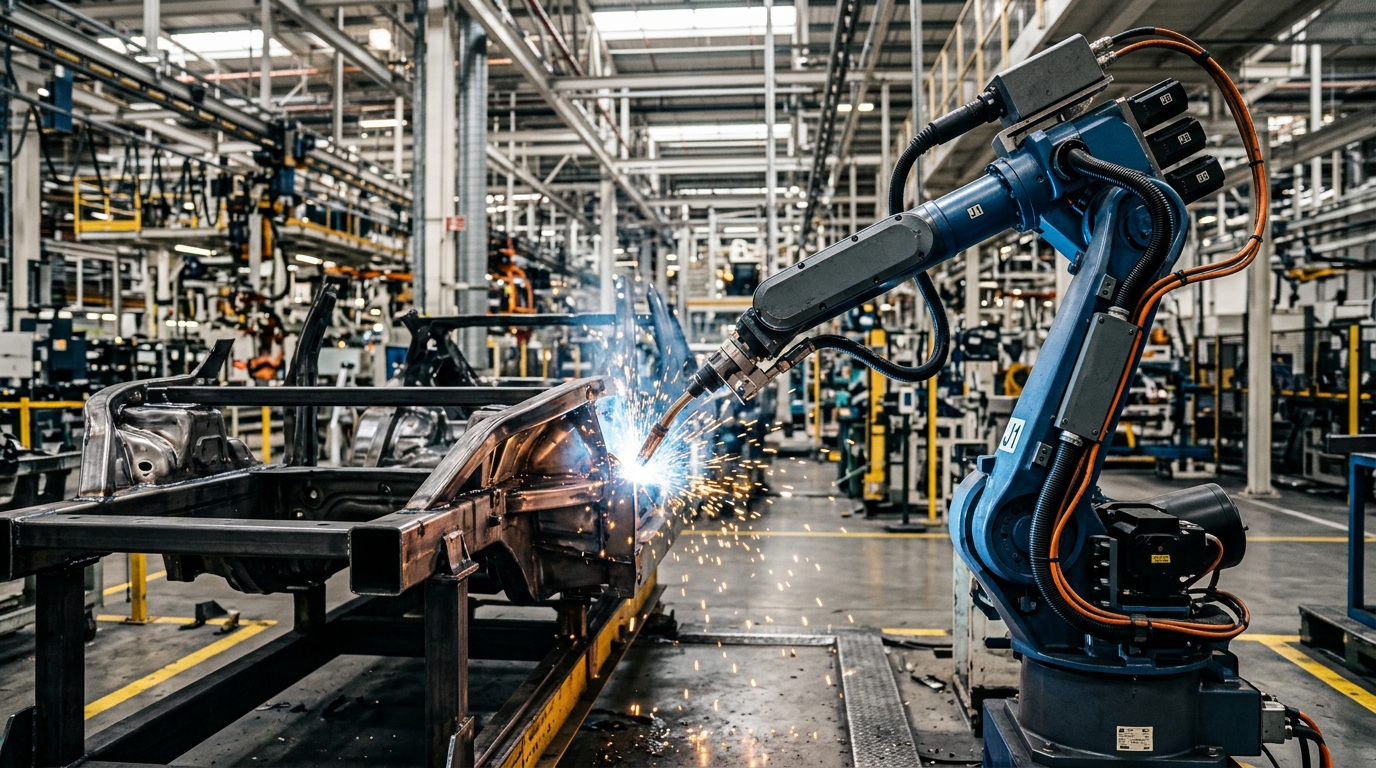
Takt Time Reduction
Down from 78s baseline on EV battery chassis trays
Sub-Millimeter Precision
Closed-loop laser triangulation seam tracking guidance
Max Dynamic Payload
Rigid heavy-duty articulated arm and gantry tooling
Defect Interception & Uptime
Zero unplanned line shutdowns across continuous 24/7 duty
Robotic Applications in Humanoid, Service and Mobile Robotics
Turnkey robotic workcells, kinematic metrics, and operational architectures deployed across modern humanoid, service and mobile robotics manufacturing plants.
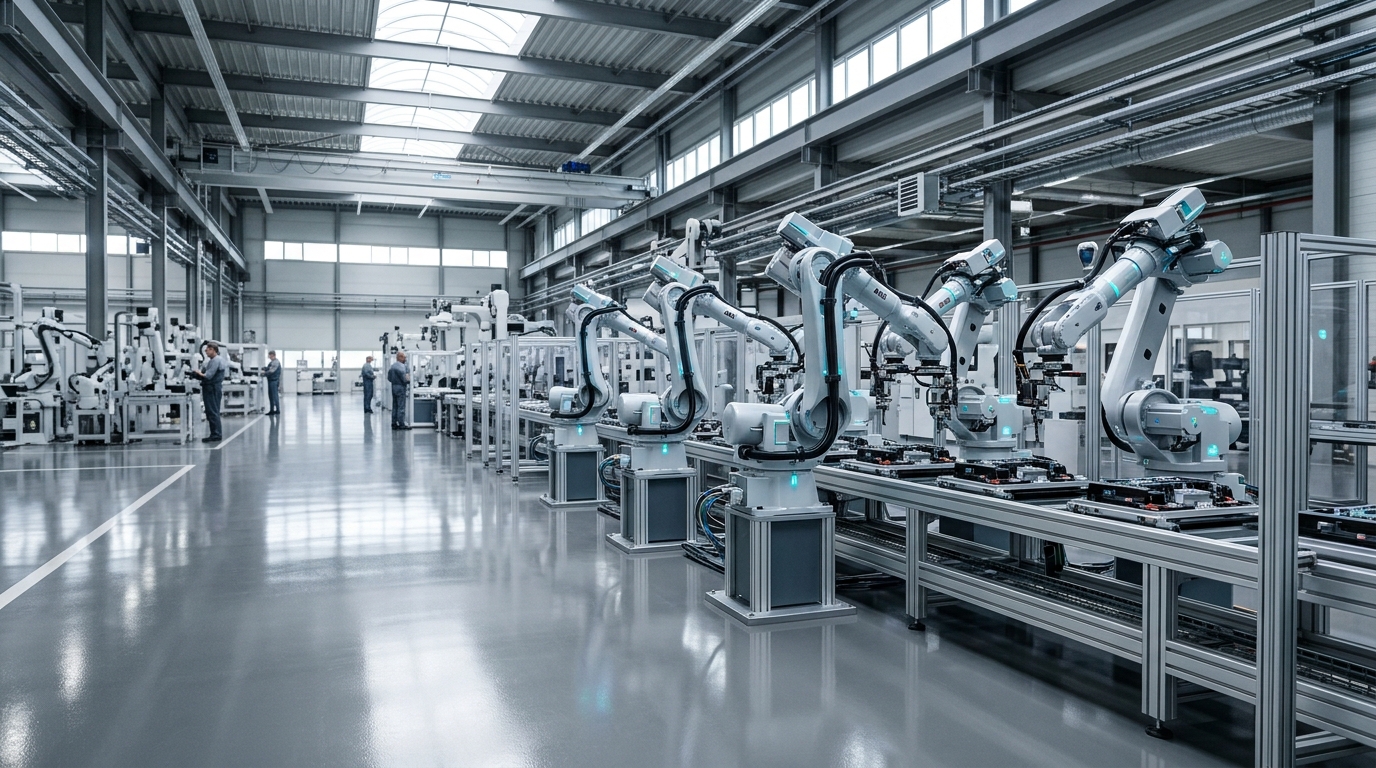
EV Battery Pack Module Assembly Cell
Automated robotic cell executing prismatic and pouch battery cell stacking, busbar laser welding, thermal paste dispensing, and high-voltage isolation testing.
Body-in-White 7th-Axis Gantry Welding
7th-axis linear track robotic spot welding and fiber laser seam joining for automotive body-in-white (BIW) framing and high-strength aluminum door apertures.
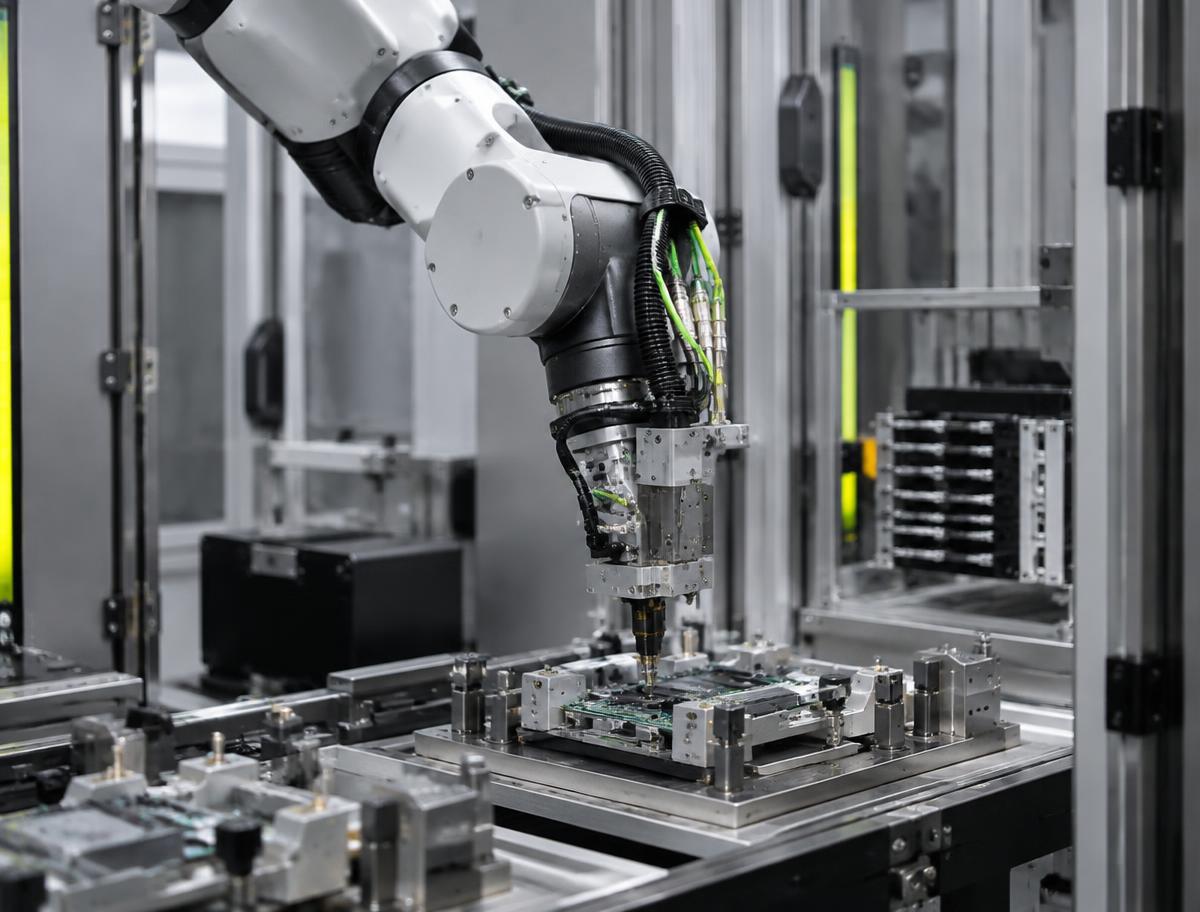
Powertrain & Gearbox Articulated Handling
High-torque articulated handling arms automating engine decking, electric drive unit (EDU) stator-rotor insertion, and transmission pallet transfer.
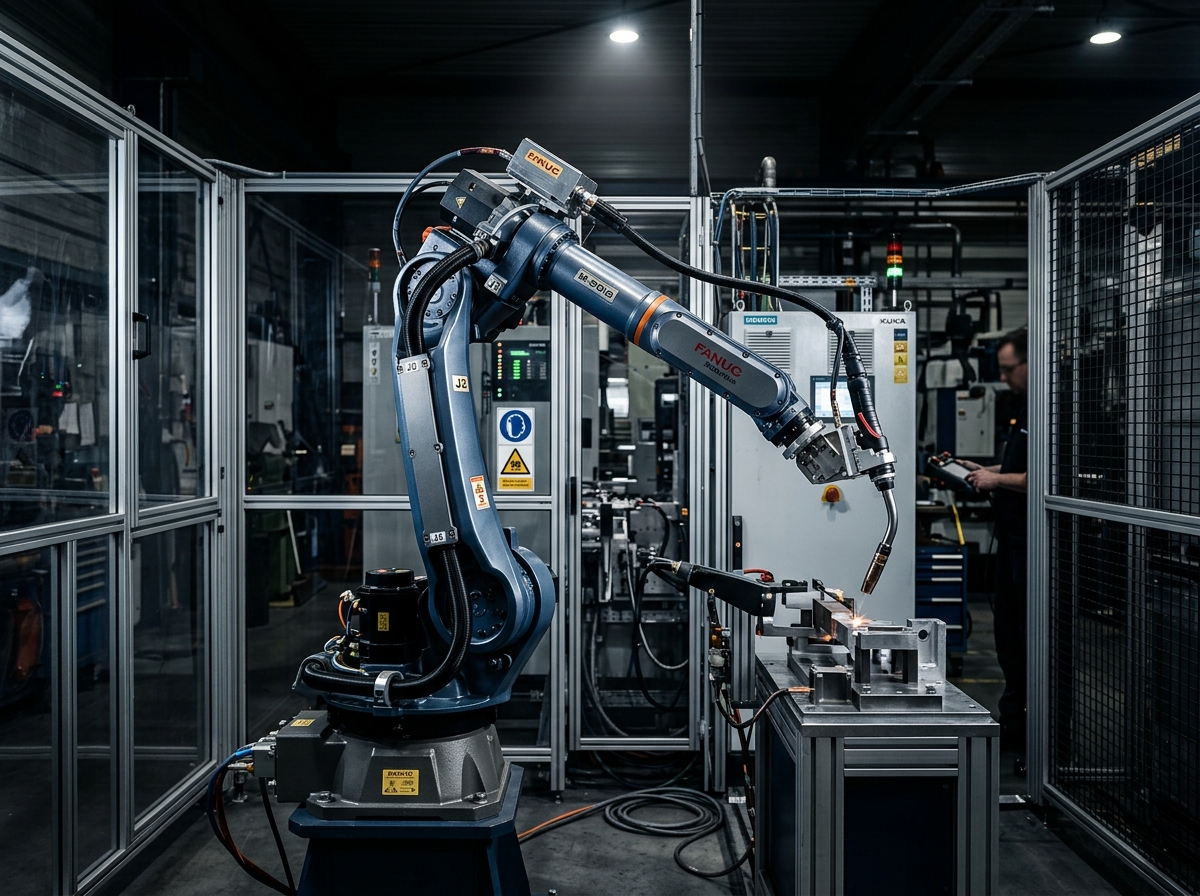
Dual-Gripper CNC Machine Tending Cell
Turnkey robotic tending cell loading and unloading high-tonnage stamping presses and multi-axis CNC milling centers with pneumatic zero-point fixtures.
Select Your Humanoid, Service and Mobile Robotics Automation Requirement
Toggle between core automation processes to inspect matching kinematic models, payload capacities, cycle times, and directly download engineering CAD files.
INDUS-BAT-K150 (7-DOF)
Engineered specifically for prismatic cell stacking, busbar tightening, and high-voltage module casing insertion with constant 6-DOF force/torque regulation.
Humanoid, Service and Mobile Robotics Automation Use Cases
Every production task has specific mechanical shock profiles, positioning tolerances, sensing architectures, and functional safety constraints. Explore detailed engineering breakdowns for each verified operation.
Bipedal Humanoid Hip & Knee High-Torque Quasi-Direct Drive (QDD) Joint
Traditional high-reduction gearboxes have excessive inertia and poor backdrivability, causing joint gear teeth to shear upon foot heel strike impact.
Full-Scale Bipedal Humanoid Robot (175 cm height, 75 kg weight) with 12 leg degrees-of-freedom.
Continuous bipedal dynamic locomotion, stair climbing, squatting, and carrying 20 kg payloads in industrial warehouse environments.
Humanoid Dexterous 5-Finger Hand Underactuated Tendon Manipulation
Standard parallel grippers cannot manipulate everyday asymmetric human tools (screwdrivers, spray bottles, scissors) or fragile soft objects.
5-Finger Anthropomorphic Hand with 16 to 20 degrees of freedom driven by micro-servos and high-tensile UHMWPE tendons.
Anthropomorphic grasping, in-hand tool reorientation, and fine assembly of industrial components with variable geometry.
Autonomous Mobile Robot (AMR) High-Payload Dual-Differential Drive Pod
Heavy payload AMRs (1,000-1,500 kg) experience high radial and axial wheel hub loads during sharp in-place turning, wearing out steering gears.
Heavy-Duty Low-Profile AMR Chassis equipped with dual steerable differential drive wheel pods.
Continuous omnidirectional warehouse and factory floor navigation, towing pallets over expansion joints and ramps.
Quadruped Robot Dynamic Trotting & High-Jump Actuator Module
Dynamic quadruped maneuvers (trotting, running, backflips) induce extreme instantaneous torque spikes and landing shock waves.
12-DOF Quadrupedal Robotic Dog (35 kg chassis weight) with 3 modular actuators per leg.
All-terrain outdoor inspection, traversing rubble, stairs, mud, and steep embankments under harsh weather conditions.
Hospital Patient Transfer & Nursing Assistance Collaborative Robot
Healthcare nursing staff suffer high rates of lower back musculoskeletal disc herniation from manually lifting and transferring immobile bedridden patients.
Dual-Arm Wheeled Service Robot with padded ergonomic lifting arms and omnidirectional mecanum base.
Safe physical cradling, lifting, and transferring 120 kg patients between hospital bed and wheelchair in quiet patient rooms.
Commercial Floor Scrubbing AMR with High-Capacity Water Extraction
Commercial airports and logistics hubs have vast floor areas (100,000+ m²) requiring continuous cleaning without leaving slick wet spots that cause slip-and-fall claims.
Heavy-Duty Commercial Autonomous Scrubber with dual counter-rotating disc brushes and parabolic rear vacuum squeegee.
Autonomous scrubbing, detergent dispensing, and squeegee vacuum water recovery in crowded airports, shopping centers, and convention centers.
Humanoid Torso & Waist 3-DOF Dynamic Stabilization Joint
Rapid bimanual lifting and arm swinging introduces angular momentum imbalances that destabilize the bipedal base and cause foot slip.
Compact 3-DOF Parallel-Kinematic or Coaxial Waist Mechanism inside humanoid torso core.
3-DOF pitch, roll, and yaw torso articulation balancing the upper body during high-payload asymmetric lifting tasks.
High-Voltage Electrical Substation Autonomous Quadruped Inspection
High-voltage switchyards (up to 500 kV) present severe electromagnetic interference (EMI) and flashover arc hazards to human inspection crews.
Ruggedized Quadrupedal Robot equipped with pan-tilt-zoom visual/thermal/acoustic corona discharge sensor payload.
Autonomous patrol over gravel terrain, ascending stairs, and inspecting transformer bushings, disconnect switches, and SF6 gas levels.
Autonomous Retail Shelf-Scanning & RFID Inventory Auditing Robot
Out-of-stock items and misplaced inventory cost retailers up to 4% in lost sales annually, while manual barcode auditing is slow and inaccurate.
Tall Vertical-Tower Autonomous Mobile Robot with omnidirectional base and multi-level optical sensor mast.
Navigating busy retail aisles, scanning 3 m tall shelf faces with multi-camera arrays and RFID antennas, and flagging missing price tags.
Autonomous Sidewalk Last-Mile Delivery Rover Curb & Ramp Traversal
Last-mile courier delivery accounts for over 50% of total package shipping costs and suffers from urban delivery van street congestion.
6-Wheeled Rocker-Bogie Autonomous Mobile Rover with all-wheel drive and motorized articulated front suspension.
Autonomous sidewalk and crosswalk navigation, climbing 15 cm street curbs, traversing tactile paving, and unlocking secure parcel hatches.
Teleoperated Surgical Humanoid Avatar with Low-Latency Haptic Reflection
Remote expert surgical intervention in rural or battlefield triage centers requires zero-latency teleoperation and bi-directional force reflection.
Dual-Arm Anthropomorphic Surgical Manipulator with 7-DOF arms and micro-wrist laparoscopic end-effectors.
Remote robotic laparoscopy and wound debridement operated by surgeon wearing haptic gloves via high-bandwidth 5G private slice.
Collaborative Bimanual Mobile Manipulator for CNC Machine Tool Loading
Automating CNC machine loading with stationary robots blocks human operator access and requires expensive fixed floor space.
Dual 7-DOF Collaborative Arms mounted on an Autonomous Mobile Base with integrated air blow gun and dual chuck grippers.
Autonomous mobile navigation between multiple CNC mills, opening machine doors, swapping raw billets and finished parts, and blowing chips.
Humanoid Ankle 2-DOF Parallel Linkage with Ground Reaction Dissipation
Humanoid ankles endure simultaneous high roll and pitch moments when landing on uneven stones or stairs, causing mechanical backlash and instability.
Dual Pushrod Parallel Linkage driven by two linear roller screws or high-torque rotary actuators located up in the calf.
2-DOF pitch-roll parallel linkage orienting foot sole flat against inclined ground surfaces during high-cadence walking.
Industrial Powered Exoskeleton Lower-Limb & Lumbar Lift Assistance
Logistics and baggage workers lifting 25 kg boxes repetitively suffer debilitating L5/S1 spinal compressive stress and disc wear.
Wearable Lower-Limb and Hip Exoskeleton with bilateral hip actuators and passive knee energy-storage springs.
Active motor-assisted lifting, bending, and walking assistance worn by workers in parcel hubs and aircraft baggage holds.
Manufacturing Challenges & Robotic Solutions
Comparing conventional production bottlenecks against deterministic multi-axis robotic automation.
Humanoid, Service and Mobile Robotics Automation Hurdles
Demanding environmental conditions, high-speed cycle times, and precision limits dictate deterministic robotics.
- Ground impact shock loads (up to 10g during running and jumping) causing gear tooth fracture in traditional reducers
- Stringent weight and volumetric power density constraints (exceeding 40 Nm/kg joint torque density)
- Thermal dissipation inside tightly sealed robotic limbs during continuous dynamic walking gait cycles
- Sub-millisecond whole-body balance and impedance control loop synchronization over real-time buses
Robotic Automation Potential
High-stiffness mechanical transmission, multi-axis sensory feedback, and real-time motion control.
- Quasi-direct-drive (QDD) planetary actuators offering high backdrivability and dynamic transparency
- Ultra-flat strain-wave reducers with integrated dual absolute encoders and torque sensor arrays
- Brushless frameless torque motors with high slot fill factors and neodymium permanent magnets
Accelerate Humanoid, Service and Mobile Robotics Automation
Access our specialized kinematics sizing tools, discuss payload vs cycle takt trade-offs, and receive 3D CAD space-claim models verified for this manufacturing discipline.
Connected Ecosystem
Other Manufacturing Sectors
Related Industrial Sectors
- Automotive
High-precision robotics meeting the extreme uptime and sub-millimeter tolerances of modern EV & automotive production.
- Electronics
Sub-micron repeatability and cleanroom-compliant automation for high-density electronic assemblies.
- Manufacturing
Rugged robotic automation engineered for high-uptime machine tending and harsh factory environments.