Metal Fabrication and Machining Robotics
Heavy forging manipulation, robotic CNC mill tending, plasma plate bevel cutting, deburring, and casting deflashing.
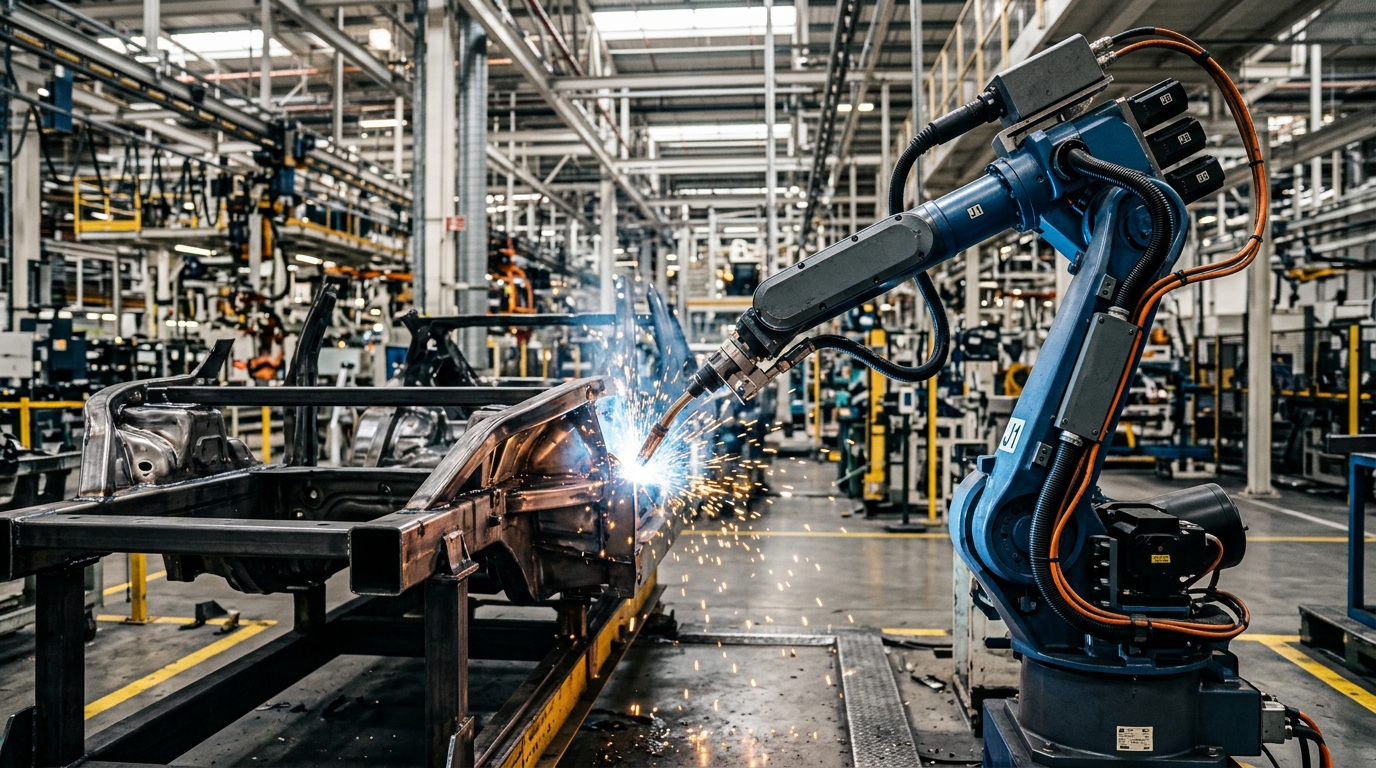
Takt Time Reduction
Down from 78s baseline on EV battery chassis trays
Sub-Millimeter Precision
Closed-loop laser triangulation seam tracking guidance
Max Dynamic Payload
Rigid heavy-duty articulated arm and gantry tooling
Defect Interception & Uptime
Zero unplanned line shutdowns across continuous 24/7 duty
Robotic Applications in Metal Fabrication and Machining
Turnkey robotic workcells, kinematic metrics, and operational architectures deployed across modern metal fabrication and machining manufacturing plants.
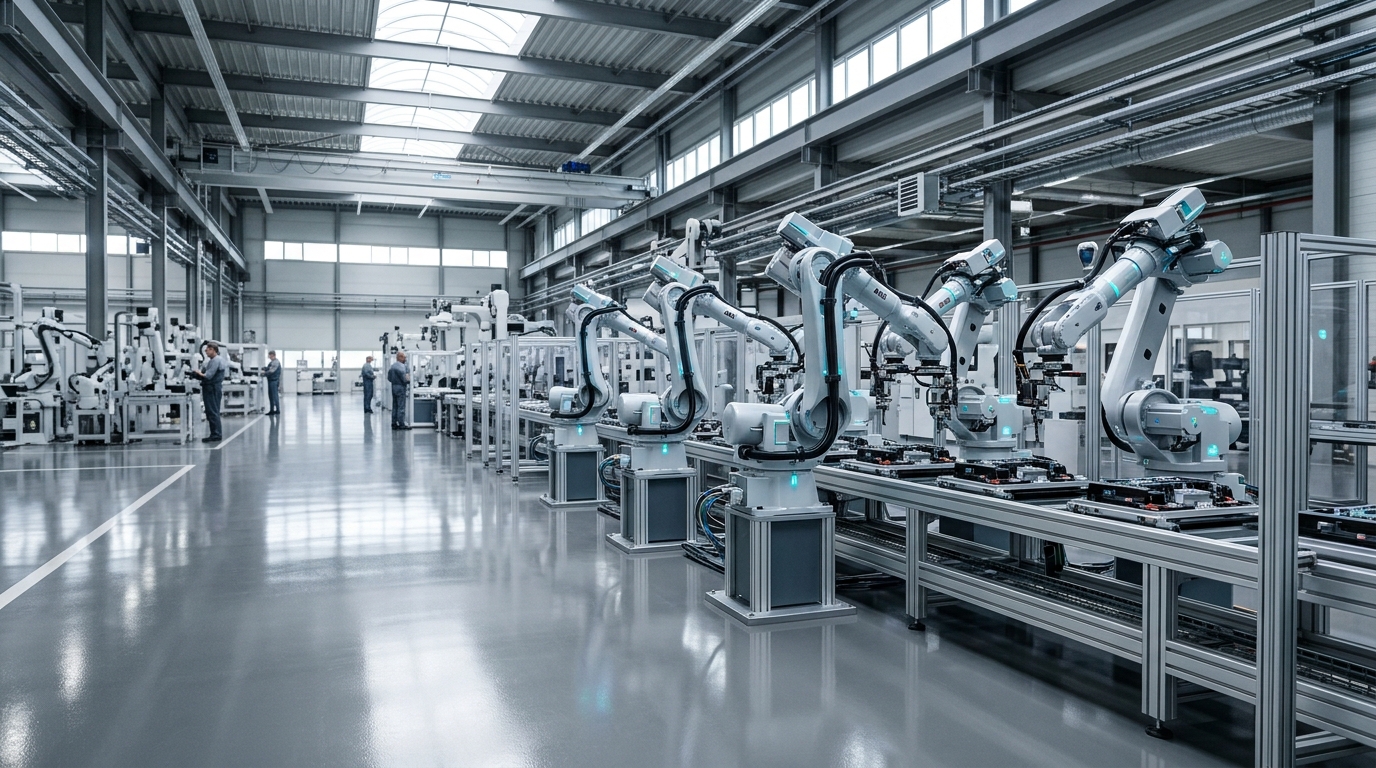
EV Battery Pack Module Assembly Cell
Automated robotic cell executing prismatic and pouch battery cell stacking, busbar laser welding, thermal paste dispensing, and high-voltage isolation testing.
Body-in-White 7th-Axis Gantry Welding
7th-axis linear track robotic spot welding and fiber laser seam joining for automotive body-in-white (BIW) framing and high-strength aluminum door apertures.
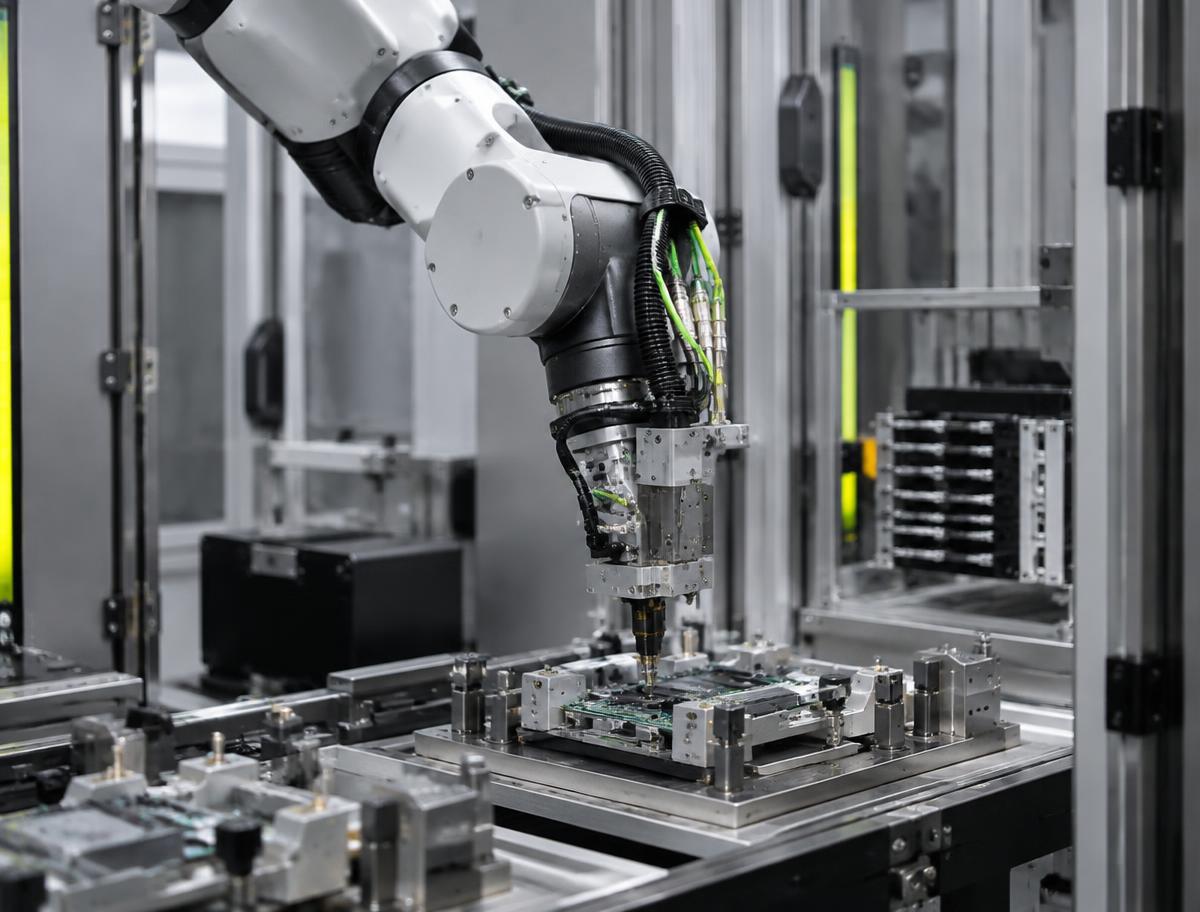
Powertrain & Gearbox Articulated Handling
High-torque articulated handling arms automating engine decking, electric drive unit (EDU) stator-rotor insertion, and transmission pallet transfer.
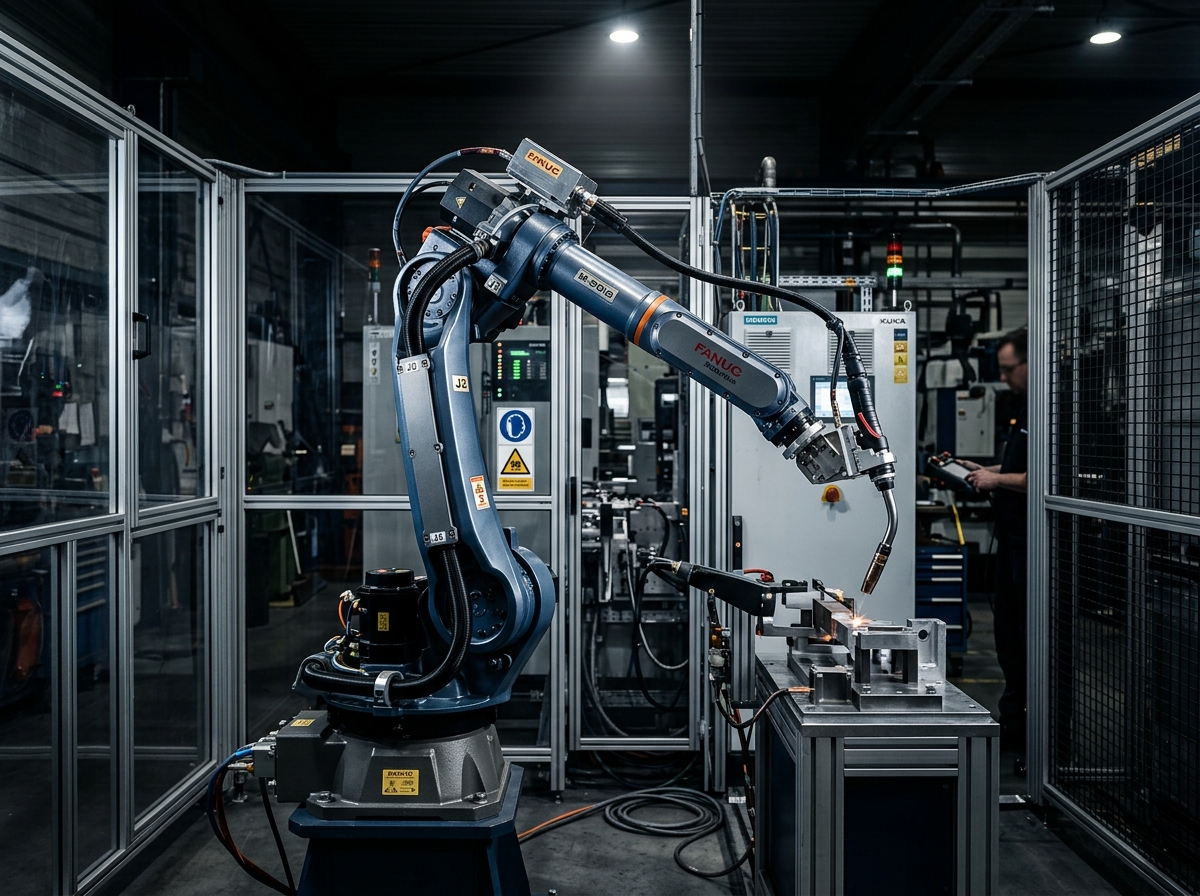
Dual-Gripper CNC Machine Tending Cell
Turnkey robotic tending cell loading and unloading high-tonnage stamping presses and multi-axis CNC milling centers with pneumatic zero-point fixtures.
Select Your Metal Fabrication and Machining Automation Requirement
Toggle between core automation processes to inspect matching kinematic models, payload capacities, cycle times, and directly download engineering CAD files.
INDUS-BAT-K150 (7-DOF)
Engineered specifically for prismatic cell stacking, busbar tightening, and high-voltage module casing insertion with constant 6-DOF force/torque regulation.
Metal Fabrication and Machining Automation Use Cases
Every production task has specific mechanical shock profiles, positioning tolerances, sensing architectures, and functional safety constraints. Explore detailed engineering breakdowns for each verified operation.
Hot Forging Die Press Automated Robotic Transfer
Transferring 1,100°C red-hot steel billets into high-tonnage forging presses causes severe thermal shock and operator radiant heat hazards.
Heavy articulated robot (500 kg payload) equipped with water-cooled heat-shielded pneumatic tongs.
Billet extraction from induction furnace, descaling spray, and placement into 2,500-ton forging die under heavy vibration.
Robotic Grinding & Deflashing of Heavy Cast Iron Engine Blocks
Heavy casting parting line flash and risers vary by up to 8mm, causing tool gouging or incomplete deflashing with rigid robots.
Rigid articulated robot with active 1D/3D force-controlled tool spindle head.
High-power abrasive diamond wheel grinding of gray iron casting parting seams in enclosed foundry booth.
High-Definition Robotic Plasma Pipe & Plate Bevel Cutting
Heavy structural steel weldments require accurate weld preparation bevels (V, Y, K profiles) along 3D intersecting pipe contours.
6-axis articulated robot with plasma cutting torch and coordinated rotary pipe turning chuck.
Plasma arc cutting of 30mm thick carbon steel structural pipes and pressure vessel domes with fume extraction.
Direct Laser Metal Deposition (LMD) Shaft Remanufacturing
Worn industrial pump and turbine shafts require localized metallurgical cladding without inducing deep thermal distortion.
Articulated robot guiding co-axial powder laser cladding head synchronized with CNC turning lathe.
Laser powder cladding of Stellite / Inconel superalloy onto worn bearing journals of rotating steel shafts.
Robotic Tandem Press Brake Sheet Metal Bending
Large sheet metal parts (up to 4 meters, 120 kg) droop and whip during press brake bending, requiring coordinated robot tracking.
Heavy-payload articulated robot on floor track with active sheet-following kinematic software.
Lifting steel plate, aligning against backgauges, and actively supporting the sheet upward during hydraulic ram downward stroke.
Pressure Vessel Circumferential Seam Submerged Arc Welding
Welding 80mm thick pressure vessel shell seams requires multi-layer submerged arc welding over 48 continuous hours without stop.
Heavy welding column and boom manipulator with motorized seam tracking slide and motorized turning rolls.
Heavy SAW welding head depositing wire and granular flux into deep narrow-gap weld prep on rotating pressure vessel shell.
5-Axis Abrasive Waterjet Cutting of Armored Ballistic Steel
Thermal cutting of armored steel (ARMOX 500) creates a heat-affected zone that destroys ballistic hardness along cut edges.
Precision 5-axis abrasive waterjet gantry with taper-compensating cutting head.
Abrasive waterjet cutting with 4,000 bar ultra-high pressure water and garnet abrasive slurry cutting 60mm armor plate.
Linear Friction Welding of Dissimilar Metal Structural Nodes
Joining aluminum to steel structural nodes in spaceframes cannot be achieved via fusion welding due to intermetallic cracking.
High-tonnage hydraulic or high-frequency eccentric servo press cell with robotic workpiece loader.
Linear oscillation (50 Hz, 3mm amplitude) of aluminum lug under 40 kN forge force against stationary steel plate.
6-Axis Robotic Fiber Laser Structural Tube Profiling
Complex fish-mouth miter joints and slot geometries on round and rectangular structural tubing require multi-axis 3D laser reach.
Articulated robot with laser cutting head integrated with multi-chuck rotary tube infeed lathe.
Laser cutting of complex interlocking mortise-and-tenon tabs on structural steel box beams.
Robotic Automotive Crankshaft Induction Hardening & Quench
Engine crankshaft bearing journals require hardened surface layers (58 HRC) to depth of 3mm while keeping core tough and uncracked.
6-axis robot with specialized ceramic insulated gripper and secondary non-conductive wrist shroud.
Robotic placement of crankshaft into multi-turn induction coil, 900°C heating in 4 seconds, followed by high-pressure polymer quench.
Robotic Sand Casting Mold Core Direct Machining
Custom sand mold cores for large pump impellers have weeks of pattern tooling lead times; direct robotic milling eliminates tooling.
High-reach articulated robot on 7th-axis slide equipped with 10 kW high-speed milling spindle.
Milling complex internal runner cavities directly into bonded silica sand core blocks using high-speed router tooling.
Wire Arc Additive Manufacturing (WAAM) of Large Titanium Aerospace Ribs
Milling 200 kg aerospace titanium bulkheads from 2,000 kg forged billets wastes 90% of raw titanium as scrap chips (buy-to-fly ratio 10:1).
High-precision 6-axis robot synchronized with 2-axis tilt-rotary positioner table.
Robotic deposition of titanium Ti-6Al-4V wire using Cold Metal Transfer (CMT) arc welding in inert argon purge tent.
Automated Sheet Metal Punching & Laser Combination Cell Tending
Manual handling of sharp, oily sheet metal blanks into CNC punch presses risks severe lacerations and drops.
Cartesian loading gantry with pneumatic sheet separator peelers and part-sorting multi-cup gripper.
Magnetic and vacuum suction destacking of raw 2.5m x 1.25m steel sheets and sorting of micro-joint punched parts.
Manufacturing Challenges & Robotic Solutions
Comparing conventional production bottlenecks against deterministic multi-axis robotic automation.
Metal Fabrication and Machining Automation Hurdles
Demanding environmental conditions, high-speed cycle times, and precision limits dictate deterministic robotics.
- Hot forging and casting transfer shock (>5G) during part extraction and drop-table loading
- Metal chip contamination and corrosive synthetic coolants eroding standard polyurethane seals
- Extreme tool chatter in robotic milling degrading surface finish and tool insert life
- Dynamic thermal growth of large steel weldments creating joint fit-up gaps exceeding 3mm
Robotic Automation Potential
High-stiffness mechanical transmission, multi-axis sensory feedback, and real-time motion control.
- RV cycloidal reducers providing massive torsional stiffness for vibration-free milling
- Active pneumatic/servo compliance heads maintaining constant contact force during casting grinding
- High-payload manipulators transferring white-hot 1,100°C forgings without operator risk
Accelerate Metal Fabrication and Machining Automation
Access our specialized kinematics sizing tools, discuss payload vs cycle takt trade-offs, and receive 3D CAD space-claim models verified for this manufacturing discipline.
Connected Ecosystem
Other Manufacturing Sectors
Related Industrial Sectors
- Automotive
High-precision robotics meeting the extreme uptime and sub-millimeter tolerances of modern EV & automotive production.
- Electronics
Sub-micron repeatability and cleanroom-compliant automation for high-density electronic assemblies.
- Manufacturing
Rugged robotic automation engineered for high-uptime machine tending and harsh factory environments.