Mining and Heavy Industries Robotics
Autonomous underground LHD haulage, mill liner bolt replacement, conveyor inspection, robotic blast hole priming, and smelter furnace tending.
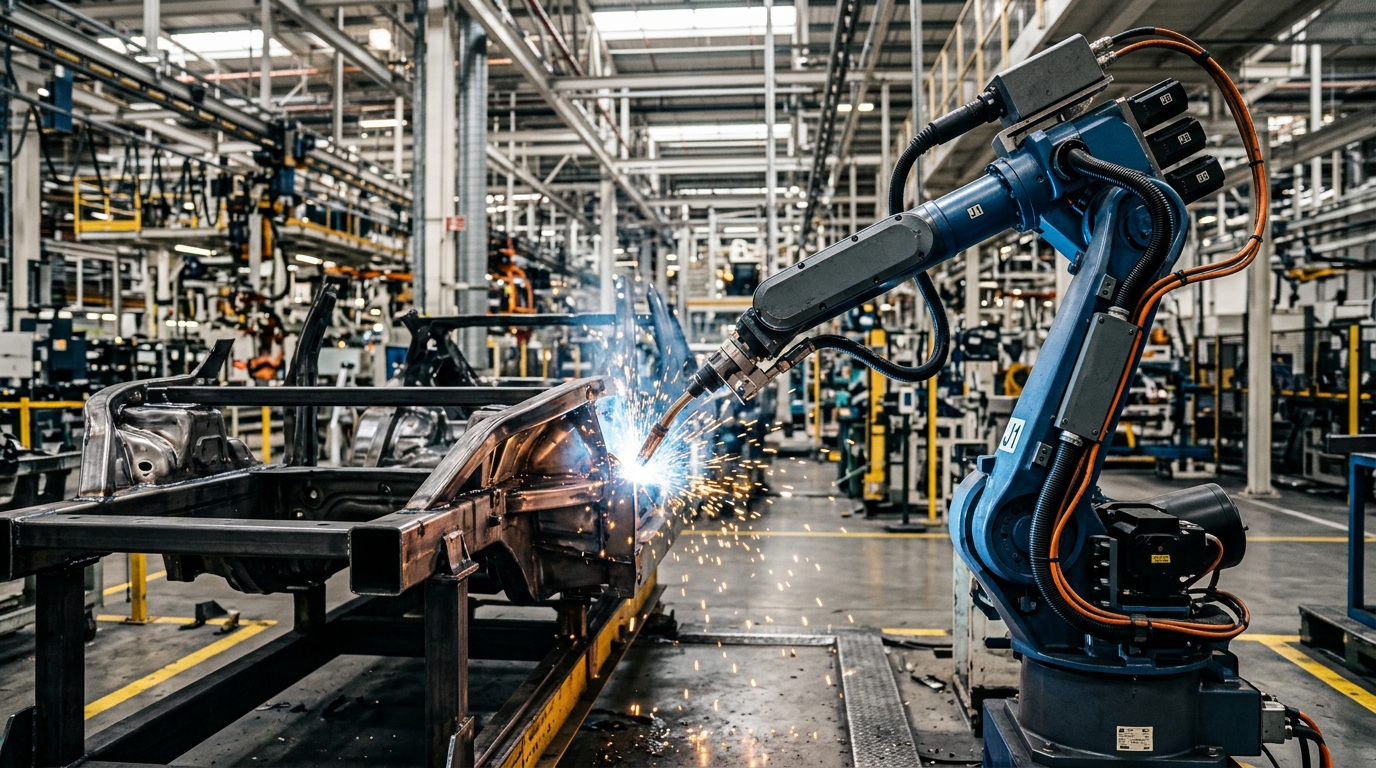
Takt Time Reduction
Down from 78s baseline on EV battery chassis trays
Sub-Millimeter Precision
Closed-loop laser triangulation seam tracking guidance
Max Dynamic Payload
Rigid heavy-duty articulated arm and gantry tooling
Defect Interception & Uptime
Zero unplanned line shutdowns across continuous 24/7 duty
Robotic Applications in Mining and Heavy Industries
Turnkey robotic workcells, kinematic metrics, and operational architectures deployed across modern mining and heavy industries manufacturing plants.
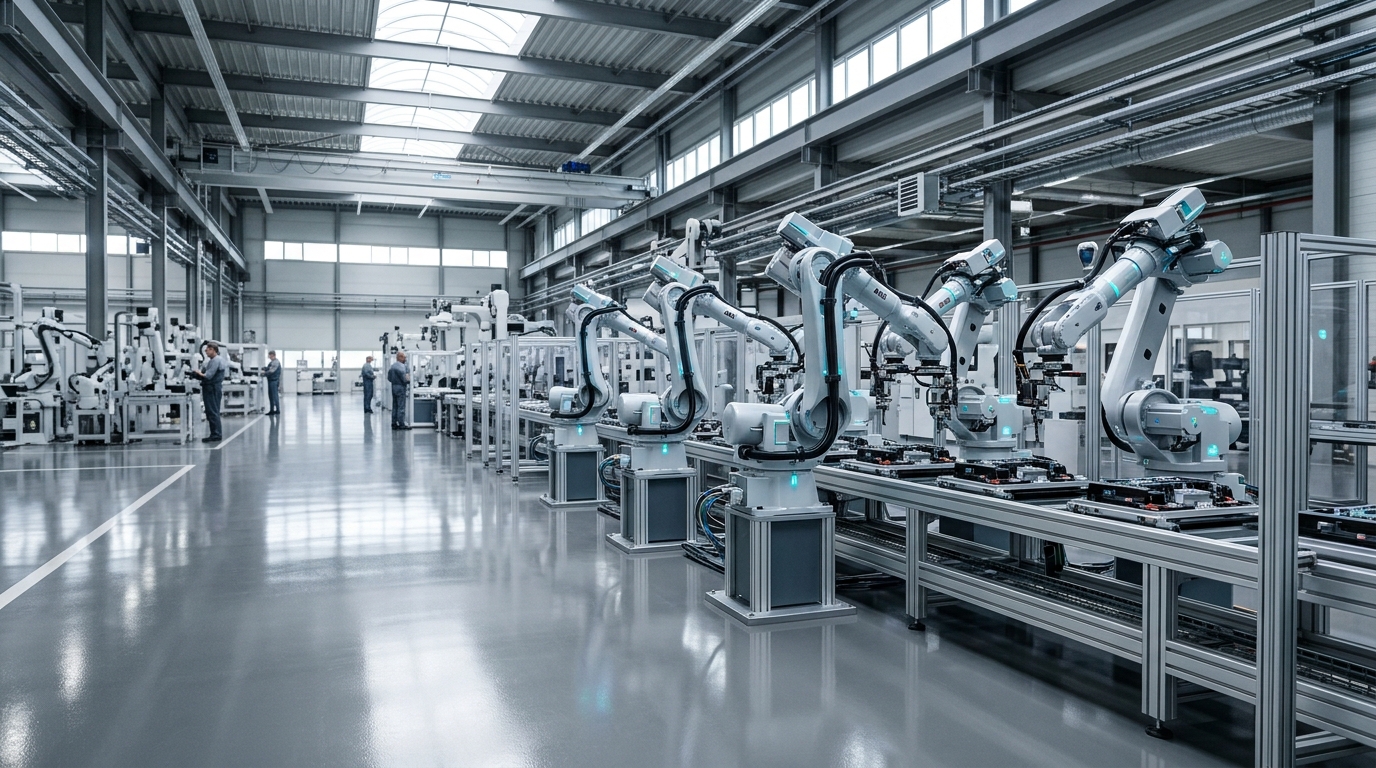
EV Battery Pack Module Assembly Cell
Automated robotic cell executing prismatic and pouch battery cell stacking, busbar laser welding, thermal paste dispensing, and high-voltage isolation testing.
Body-in-White 7th-Axis Gantry Welding
7th-axis linear track robotic spot welding and fiber laser seam joining for automotive body-in-white (BIW) framing and high-strength aluminum door apertures.
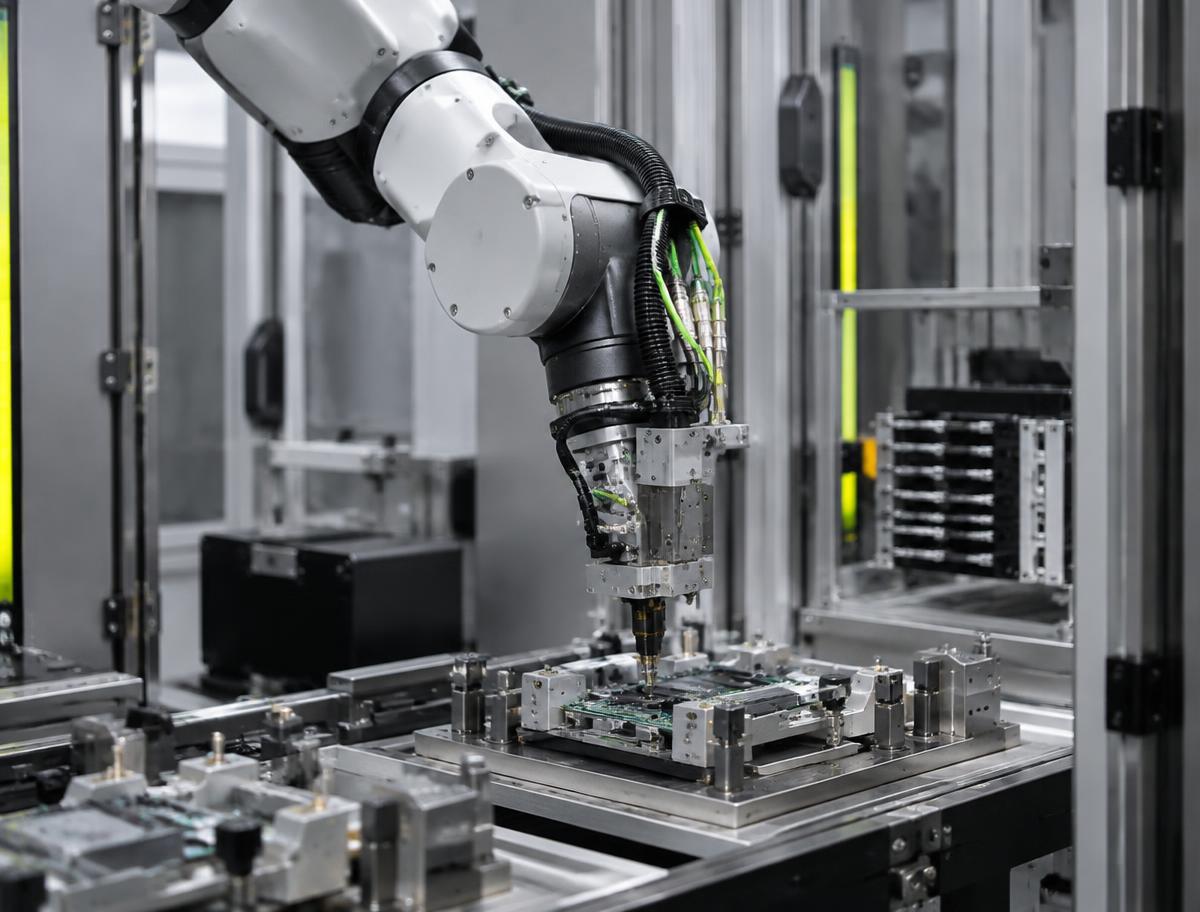
Powertrain & Gearbox Articulated Handling
High-torque articulated handling arms automating engine decking, electric drive unit (EDU) stator-rotor insertion, and transmission pallet transfer.
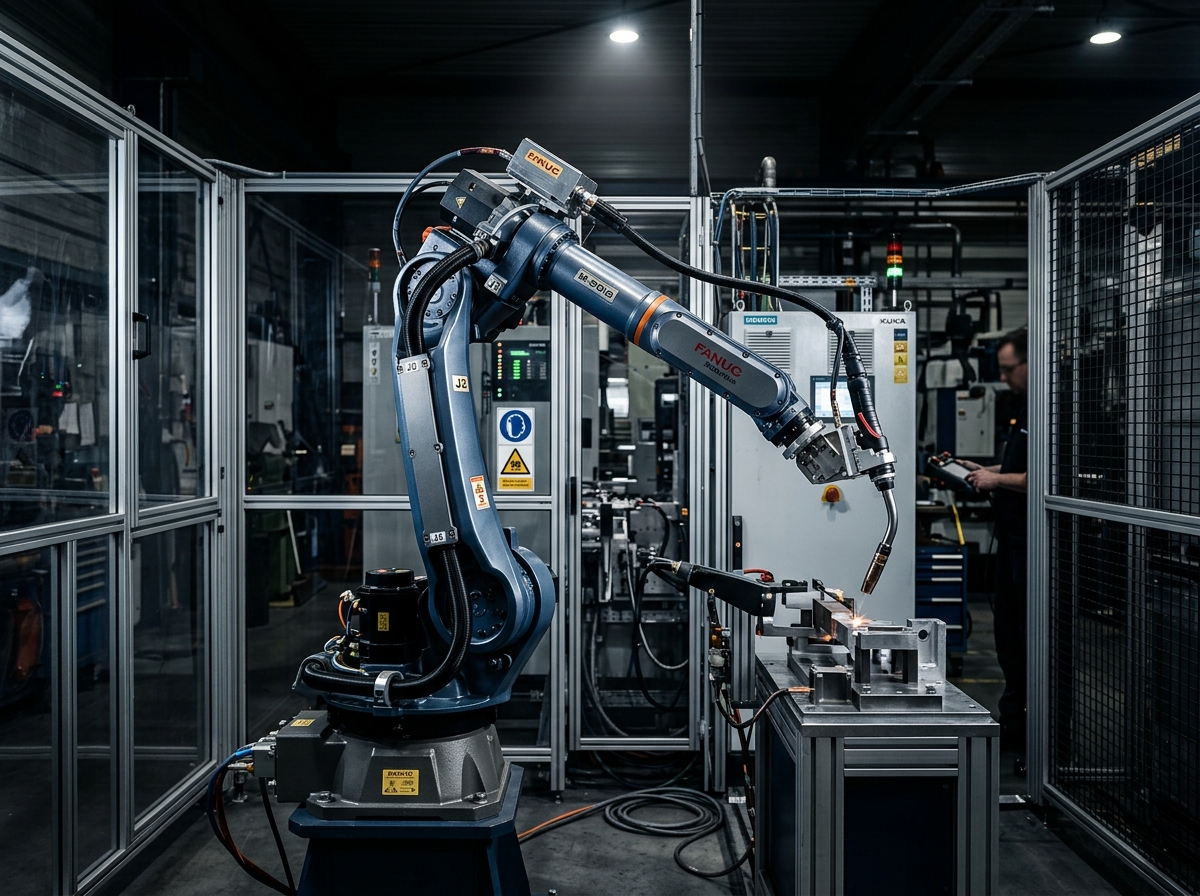
Dual-Gripper CNC Machine Tending Cell
Turnkey robotic tending cell loading and unloading high-tonnage stamping presses and multi-axis CNC milling centers with pneumatic zero-point fixtures.
Select Your Mining and Heavy Industries Automation Requirement
Toggle between core automation processes to inspect matching kinematic models, payload capacities, cycle times, and directly download engineering CAD files.
INDUS-BAT-K150 (7-DOF)
Engineered specifically for prismatic cell stacking, busbar tightening, and high-voltage module casing insertion with constant 6-DOF force/torque regulation.
Mining and Heavy Industries Automation Use Cases
Every production task has specific mechanical shock profiles, positioning tolerances, sensing architectures, and functional safety constraints. Explore detailed engineering breakdowns for each verified operation.
Autonomous Underground LHD (Load-Haul-Dump) Mucking
Underground stopes expose human operators to rockfall hazards, toxic blasting fumes (NOx, CO), and extreme vibration.
Heavy Articulated Diesel-Electric Underground Loader with hydraulic/electromechanical drive steering.
Autonomous loading of 14-tonne fragmented rock piles into drift haulage trucks in unventilated, unlit, GPS-denied tunnels.
Robotic SAG & Ball Mill Liner Bolt Torquing & Handling
Relining semi-autogenous grinding (SAG) mills requires handling 800 kg cast steel liners inside a confined tumbling drum with high risk of crushing injuries.
Telescopic Mill Liner Handler Crane Arm paired with external 6-Axis Bolt Torquing Manipulator.
Positioning replacement liners inside the mill drum and high-torque hydraulic/electric bolt tensioning from the drum exterior.
Overland Conveyor Idler Acoustic & Thermal Inspection Crawler
Seized conveyor idler bearings generate frictional heat that ignites rubber belts, causing catastrophic fires along 15 km transport lines.
Suspended Monorail Climbing Robot or Wheeled Track-Mounted Robotic Rover with pan-tilt sensor turret.
Continuous autonomous patrol along elevated conveyor stringers in remote desert or sub-zero mountain environments.
Robotic Blast Hole Explosive Priming & Stemming Tending
Manual insertion of non-electric boosters and electronic detonators into deep blast holes exposes workers to flyrock, heat, and toxic fumes.
Heavy-duty truck-mounted 6-Axis Articulated Arm equipped with specialized non-sparking brass detonator end-effector.
Autonomous hole collar detection, depth measurement, booster/detonator tether placement, and bulk emulsion hose guiding on open-pit benches.
Robotic Slag Skimming & Drossing in Smelting Furnaces
Molten copper/aluminum slag skimming exposes operators to 1,200°C radiant heat, splashing liquid metal, and sulfur dioxide (SO2) fumes.
Heavy-Duty Foundry Manipulator (600 kg payload) equipped with water-cooled refractory stainless steel paddle tool.
Continuous skimming of oxidized slag layer from furnace surface and clearing tap-holes in pyrometallurgical smelters.
Autonomous Blast Hole Drill Rig Rod Handling & Threading
Manual handling of 300 kg drill steel rods and breakout tongs causes severe hand-crush amputations and spinal injuries on drill rigs.
Hydraulic-Electric Articulated Rod Carousel Arm with hydraulic clamping gripper and breakout wrench.
Automatic loading, alignment, and threading of drill pipes into mast carousel under heavy mud and vibration on open-pit drill rigs.
Underground Continuous Miner Autonomous Horizon Tracking
Cutting into rock roof or floor stone dilutes coal seam quality, causes cutter pick wear, and risks methane gas spark ignition.
Tracked Continuous Miner with automated drum elevation and dual-axis cutter boom.
Navigating continuous miner cutting drum along thin undulating coal seams in low-seam underground room-and-pillar operations.
Autonomous Rope Shovel & Dragline Boom Structural NDT Crawler
Fatigue cracking in giant 100 m mining dragline lattice booms causes catastrophic structural collapses, but manual inspection requires dangerous rope rigging.
Magnetic-Tracked Climbing Crawler Robot equipped with phased array ultrasonic testing (PAUT) probe.
Autonomous climbing across tubular steel boom chords at 40 m heights in high winds and magnetic field interference.
Robotic Geological Drill Core Tray Hyperspectral Scanning & Logging
Manual geological core logging is slow, subjective, and creates massive backlogs during mineral exploration drilling campaigns.
Cartesian Core Handling Gantry paired with 6-Axis Articulated Sensor Positioning Arm.
Unloading core trays, continuous high-resolution scanning (RGB, SWIR, LWIR, XRF), automated fracture frequency logging, and re-stacking.
Autonomous Tunnel Boring Machine (TBM) Precast Segment Erector
Positioning 6-tonne precast concrete lining segments inside a pressurized, wet tunnel boring shield has severe pinch-point hazards.
Heavy-Duty Ring-Mounted Hydraulic Erector Manipulator with vacuum suction plate and multi-pin mechanical clamp.
Picking precast segment from feeder car, 6-DOF alignment with previously placed ring, and driving dowel pins under wet mud conditions.
Robotic In-Situ Bucket Wheel Reclaimer Teeth Wear Hardfacing
Abrasive iron ore and coal wear down bucket excavator cutting teeth; replacing and hardfacing manually in open yards causes extended stacker downtime.
Portable All-Weather 6-Axis Robot mounted on mobile magnetic clamping base with plasma hardfacing torch.
Autonomous 3D profile measurement of worn teeth, trajectory calculation, and automated plasma transferred arc (PTA) cladding on outdoor machines.
Autonomous Tailing Pond Bathymetry & Water Slurry Sampling USV
Mining tailing dams contain caustic chemical slurries and unstable quicksand embankments where human boat sampling is perilous.
Twin-Hull Autonomous Surface Vessel (USV) with electric azimuth thrusters and automated multi-bottle water sampler.
Autonomous surface navigation, bathymetric sonar profiling, and winch-lowered water/sludge sampling down to 40 m depths.
Manufacturing Challenges & Robotic Solutions
Comparing conventional production bottlenecks against deterministic multi-axis robotic automation.
Mining and Heavy Industries Automation Hurdles
Demanding environmental conditions, high-speed cycle times, and precision limits dictate deterministic robotics.
- Shock overloads exceeding 500% during bucket mucking and rock breaker impact vibration
- Extreme abrasive slurry and silica dust ingress requiring multi-stage labyrinth seals and IP68 ratings
- Absence of GPS subterranean navigation requiring high-accuracy LiDAR odometry and radar SLAM
- ATEX/IECEx hazardous environment explosion-proofing in presence of coal dust and methane gas (firedamp)
Robotic Automation Potential
High-stiffness mechanical transmission, multi-axis sensory feedback, and real-time motion control.
- High-shock-capacity RV and cycloidal gearboxes surviving rock breaker reactive loads without tooth shearing
- Heavy-payload (500-1,000 kg) articulated arms for remote mill liner replacement inside SAG/ball mills
- Autonomous mobile inspection robots patrolling thousands of meters of overland belt conveyors
Accelerate Mining and Heavy Industries Automation
Access our specialized kinematics sizing tools, discuss payload vs cycle takt trade-offs, and receive 3D CAD space-claim models verified for this manufacturing discipline.
Connected Ecosystem
Other Manufacturing Sectors
Related Industrial Sectors
- Automotive
High-precision robotics meeting the extreme uptime and sub-millimeter tolerances of modern EV & automotive production.
- Electronics
Sub-micron repeatability and cleanroom-compliant automation for high-density electronic assemblies.
- Manufacturing
Rugged robotic automation engineered for high-uptime machine tending and harsh factory environments.