Pharmaceuticals and Life Sciences Robotics
Aseptic vial filling inside isolators, cytotoxic compounding, high-throughput screening, and serialized blister cartoning.
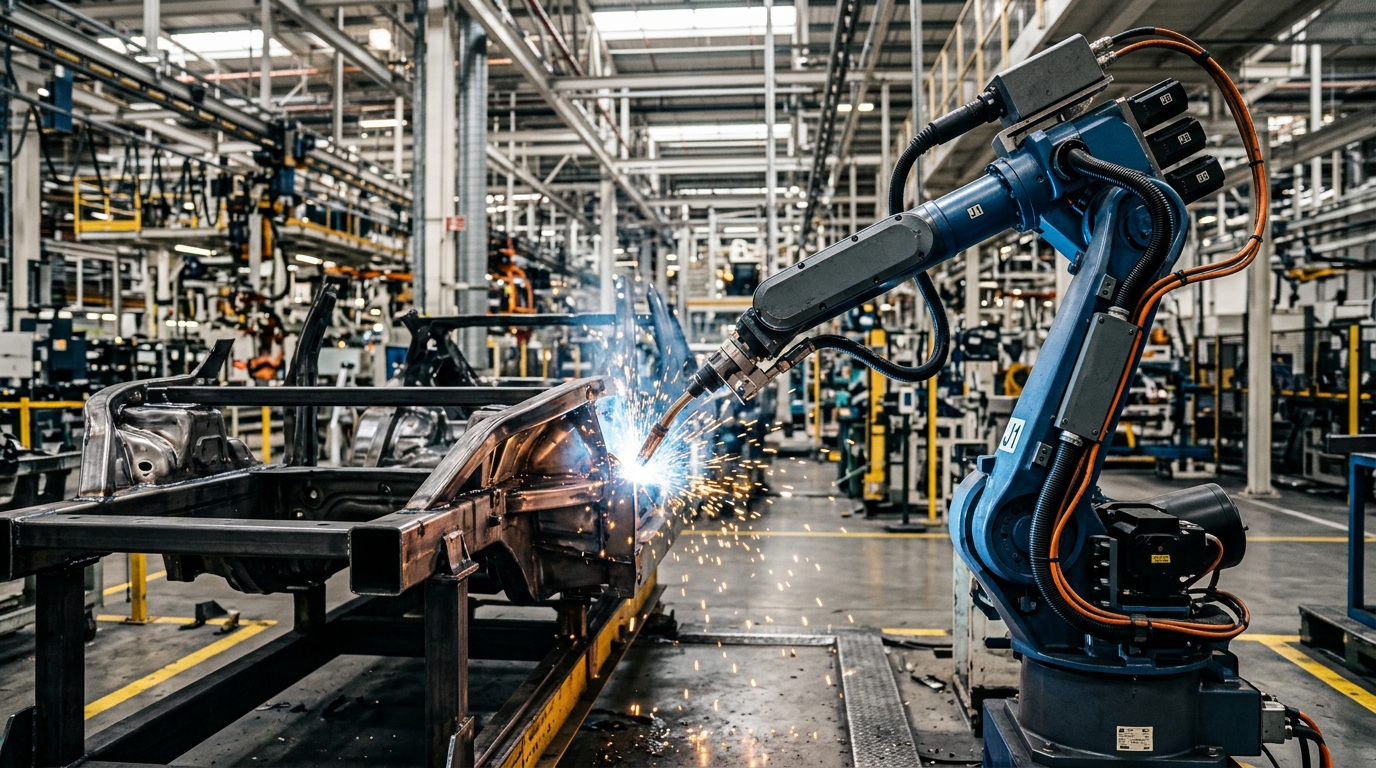
Takt Time Reduction
Down from 78s baseline on EV battery chassis trays
Sub-Millimeter Precision
Closed-loop laser triangulation seam tracking guidance
Max Dynamic Payload
Rigid heavy-duty articulated arm and gantry tooling
Defect Interception & Uptime
Zero unplanned line shutdowns across continuous 24/7 duty
Robotic Applications in Pharmaceuticals and Life Sciences
Turnkey robotic workcells, kinematic metrics, and operational architectures deployed across modern pharmaceuticals and life sciences manufacturing plants.
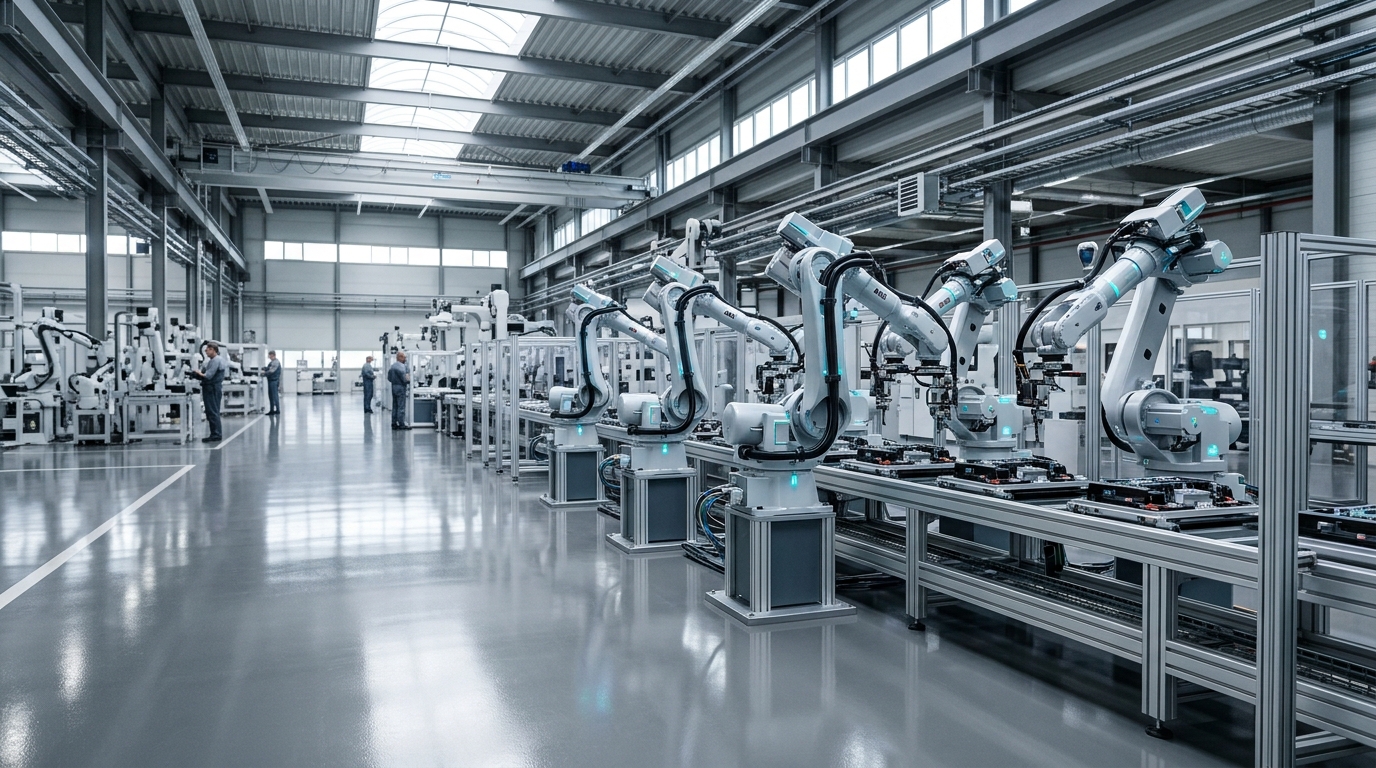
EV Battery Pack Module Assembly Cell
Automated robotic cell executing prismatic and pouch battery cell stacking, busbar laser welding, thermal paste dispensing, and high-voltage isolation testing.
Body-in-White 7th-Axis Gantry Welding
7th-axis linear track robotic spot welding and fiber laser seam joining for automotive body-in-white (BIW) framing and high-strength aluminum door apertures.
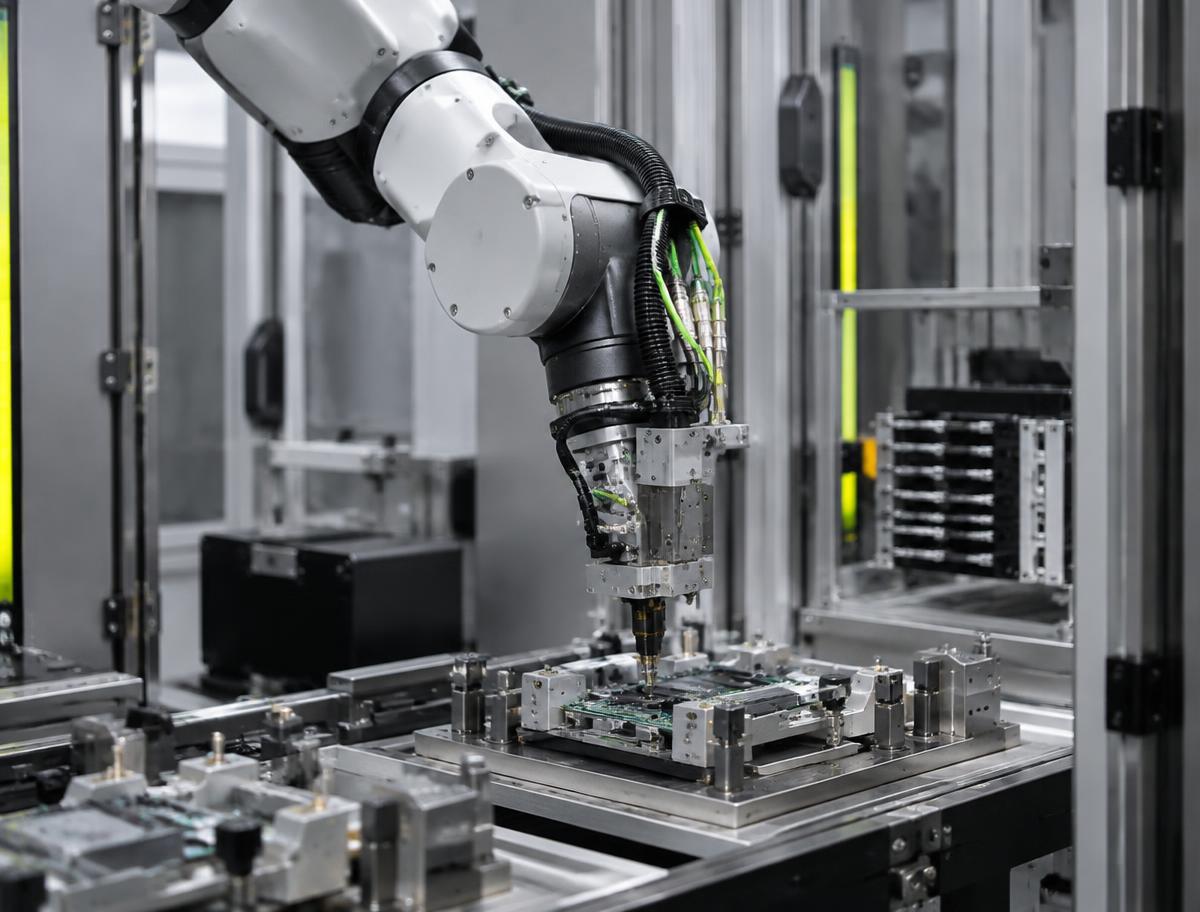
Powertrain & Gearbox Articulated Handling
High-torque articulated handling arms automating engine decking, electric drive unit (EDU) stator-rotor insertion, and transmission pallet transfer.
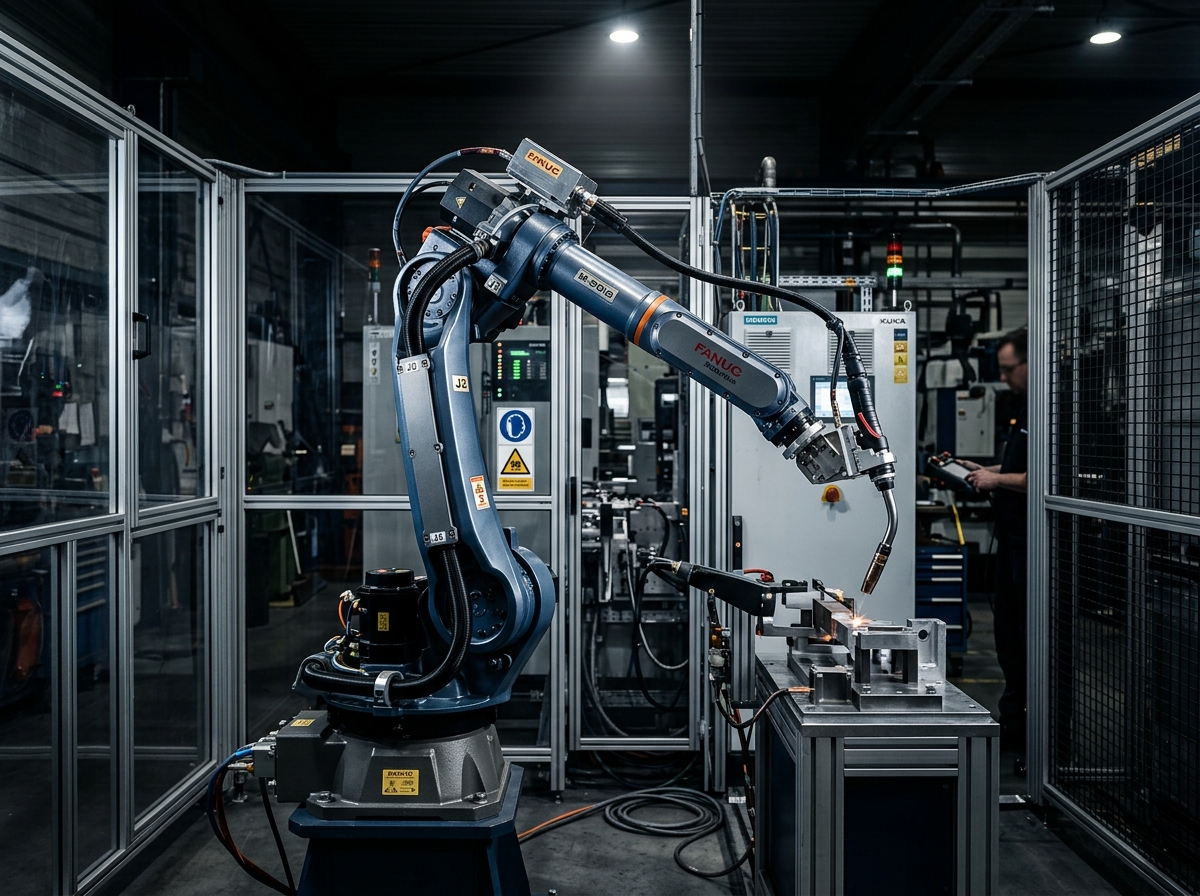
Dual-Gripper CNC Machine Tending Cell
Turnkey robotic tending cell loading and unloading high-tonnage stamping presses and multi-axis CNC milling centers with pneumatic zero-point fixtures.
Select Your Pharmaceuticals and Life Sciences Automation Requirement
Toggle between core automation processes to inspect matching kinematic models, payload capacities, cycle times, and directly download engineering CAD files.
INDUS-BAT-K150 (7-DOF)
Engineered specifically for prismatic cell stacking, busbar tightening, and high-voltage module casing insertion with constant 6-DOF force/torque regulation.
Pharmaceuticals and Life Sciences Automation Use Cases
Every production task has specific mechanical shock profiles, positioning tolerances, sensing architectures, and functional safety constraints. Explore detailed engineering breakdowns for each verified operation.
Aseptic Vial Filling & Stoppering Inside VHP Isolator
Human intervention inside Grade A aseptic isolators is the leading source of microbial batch contamination.
Hermetically sealed 6-axis cleanroom robot with mirror-polished stainless steel casing and VHP-resistant seals.
Continuous tare-weighing, peristaltic/piston filling, and elastomer stoppering of glass vials inside hermetic VHP isolator.
Robotic Hazardous Cytotoxic Oncology Drug Compounding
Manual reconstitution of toxic chemotherapy medications exposes hospital pharmacists to carcinogenic aerosol vapors.
Dual-arm collaborative robotic system inside negative-pressure Class II Type B2 biosafety cabinet.
Automated reconstitution of lyophilized cytotoxic powders with sterile diluents and transfer into patient IV bags.
Automated High-Speed Visual Inspection of Liquid Ampoules
Human visual inspection for glass shards, fibers, and precipitate particles in liquid injectables suffers from eye fatigue.
Continuous rotary dial starwheel with direct-drive servo spin stations and multi-angle high-speed cameras.
Spinning glass ampoules at 4,000 RPM, braking abruptly, and capturing 20 sequential camera frames of moving liquid particles.
High-Throughput Drug Discovery Microplate Robotic Screening
Screening chemical libraries of 500,000 compounds against disease targets requires 24/7 liquid pipetting across 1536-well plates.
High-speed articulated robot mounted on linear track servicing multiple automated bio-analytical instruments.
Moving 384-well and 1536-well microplates between liquid handlers, incubators, plate readers, and automated freezers.
Pharmaceutical Blister Pack Track & Trace Serialization
Global anti-counterfeit laws (DSCSA, EU FMD) require unique 2D Datamatrix serialization and tamper-evident sealing at 300 packs/min.
Continuous belt tracking servo transfer station with multi-camera inspection and high-speed reject gate.
Laser coding serialized numbers on folding cartons, vision verification, and automated aggregation into shipping bundles.
Automated Freeze-Dryer (Lyophilizer) Shelf Loading System
Loading thousands of partially stoppered vials onto cold lyophilizer shelves (-50°C) without human touch or vial tip-overs.
Sanitary push-pull linear mechanism equipped with magnetic-coupling rodless actuator traversing isolator wall.
Continuous row-by-row pushing of thousands of vials onto freeze-dryer shelves under Grade A laminar air flow.
Micro-Dosing of Active Pharmaceutical Powders (API)
Dry powder inhaler (DPI) formulations require micro-dosing of potent powders (1 to 20 mg) with ±2% precision.
Multi-axis indexing carrousel with micro-dosing vacuum pins and piezoceramic tapping compactors.
Aseptic vacuum compaction dosing of micronized drug powders into dry powder inhaler blisters under dry air (RH < 20%).
-196°C Liquid Nitrogen Automated Biobank Sample Retrieval
Human operators searching for cryovials in -196°C liquid nitrogen vapor risk severe frostbite and induce thermal warm-up in adjacent samples.
Robotic gantry operating inside insulated dry-air airlock above liquid nitrogen immersion chamber.
Autonomous robotic retrieval of individual 2mL cryovials from liquid nitrogen cryo-storage tanks without warming surrounding rack.
Ultra-High Speed (100,000 CPH) Capsule 100% Checkweighing
Statistical batch sampling can miss individual under-filled capsules, risking ineffective patient medication.
Multi-channel rotary starwheel with 24 individual electromagnetic force restoration (EMFR) balances.
Individual weighing of hard gelatin capsules on multi-channel vibrating weigh pans at high production speeds.
Automated Sterile Bioreactor Sampling & PAT Analytics
Manual sampling of cell culture bioreactors risks contaminating multi-week monoclonal antibody fermentation runs.
Cleanroom robotic fluidic manifold with sterile pinch valves and automated sample refrigeration shuttle.
Automated aseptic extraction of 5 mL culture samples from 2,000-liter bioreactor and delivery to HPLC and cell counters.
Pre-Filled Syringe Tub Un-Nesting & Needle Capping
Glass pre-filled syringe barrels can chip or break during high-speed extraction from 100-count honeycomb nest tubs.
High-accuracy cleanroom articulated robot with custom 100-nozzle compliant vacuum comb end-effector.
Robotic vacuum gripping of 100 syringe barrels simultaneously from sterile nest tubs and feeding into filling line.
Autonomous VHP Decontamination Pass-Through Chamber Robot
Transferring supplies between Grade C cleanroom and Grade A isolator requires 45-minute VHP cycle without material degradation.
Fully sealed 316L stainless steel SCARA robot with internal fluoropolymer cable conduits.
Robotic manipulation of component trays inside rapid transfer chamber during 30% H2O2 vapor sterilization cycle.
Manufacturing Challenges & Robotic Solutions
Comparing conventional production bottlenecks against deterministic multi-axis robotic automation.
Pharmaceuticals and Life Sciences Automation Hurdles
Demanding environmental conditions, high-speed cycle times, and precision limits dictate deterministic robotics.
- Corrosive Vaporized Hydrogen Peroxide (VHP) sterilizing gas degrading standard elastomers, seals, and anodized aluminum
- Stringent cleanroom Class A / ISO Class 4 requirements prohibiting particle shed or air turbulence
- Mandatory FDA 21 CFR Part 11 audit logging of every motion profile, position setpoint, and error event
- Zero margin for liquid fill volume errors in high-potency cytotoxic oncology vials
Robotic Automation Potential
High-stiffness mechanical transmission, multi-axis sensory feedback, and real-time motion control.
- Mirror-polished 316L stainless steel robot arms with positive internal air pressure and fluoropolymer seals
- Servo rotary piston pumps dispensing liquid doses down to 0.1 mL with ±0.5% gravimetric accuracy
- Automated optical particle inspection machines spinning vials at 4,000 RPM with high-speed camera verification
Accelerate Pharmaceuticals and Life Sciences Automation
Access our specialized kinematics sizing tools, discuss payload vs cycle takt trade-offs, and receive 3D CAD space-claim models verified for this manufacturing discipline.
Connected Ecosystem
Other Manufacturing Sectors
Related Industrial Sectors
- Automotive
High-precision robotics meeting the extreme uptime and sub-millimeter tolerances of modern EV & automotive production.
- Electronics
Sub-micron repeatability and cleanroom-compliant automation for high-density electronic assemblies.
- Manufacturing
Rugged robotic automation engineered for high-uptime machine tending and harsh factory environments.