Plastics and Rubber Manufacturing Robotics
Injection molding machine part extraction, in-mold decoration (IMD), ultrasonic plastic welding, and tire rubber extrusion handling.
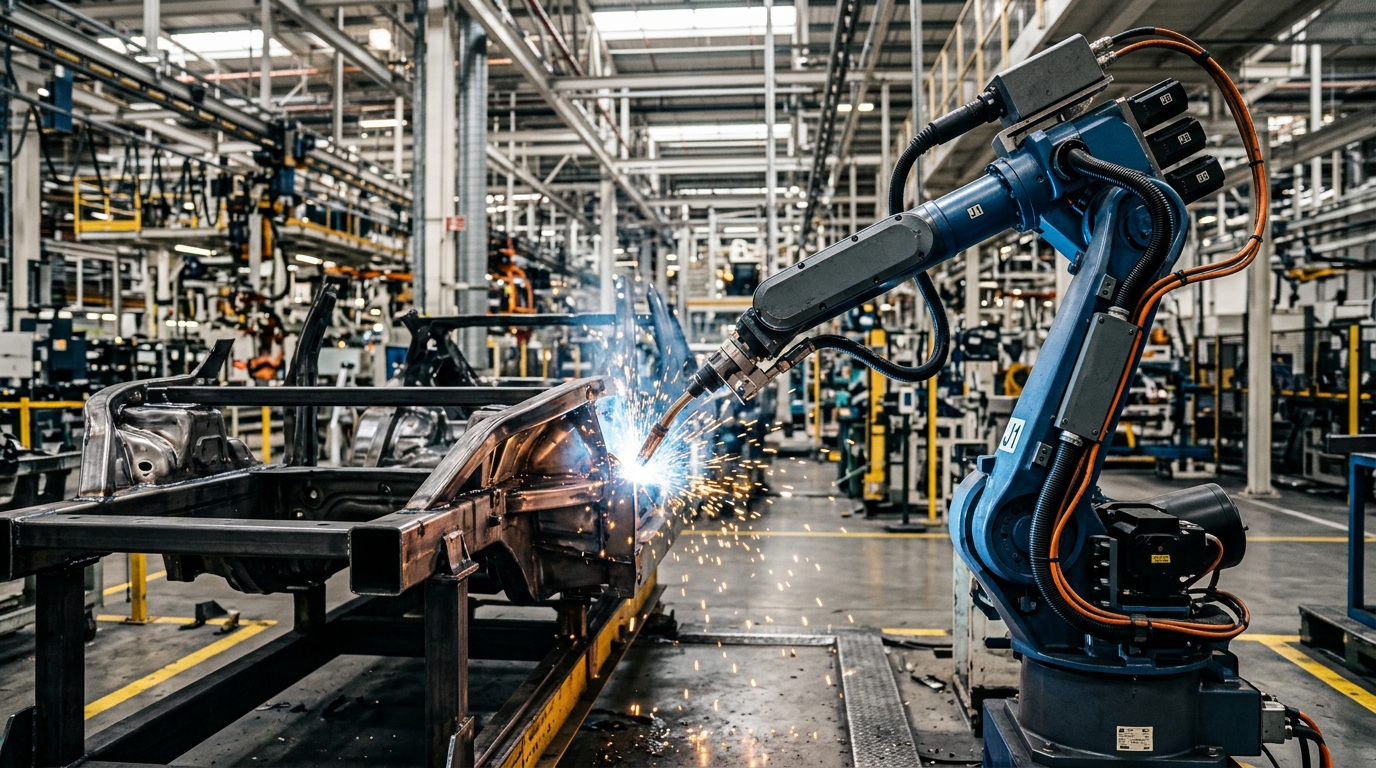
Takt Time Reduction
Down from 78s baseline on EV battery chassis trays
Sub-Millimeter Precision
Closed-loop laser triangulation seam tracking guidance
Max Dynamic Payload
Rigid heavy-duty articulated arm and gantry tooling
Defect Interception & Uptime
Zero unplanned line shutdowns across continuous 24/7 duty
Robotic Applications in Plastics and Rubber Manufacturing
Turnkey robotic workcells, kinematic metrics, and operational architectures deployed across modern plastics and rubber manufacturing manufacturing plants.
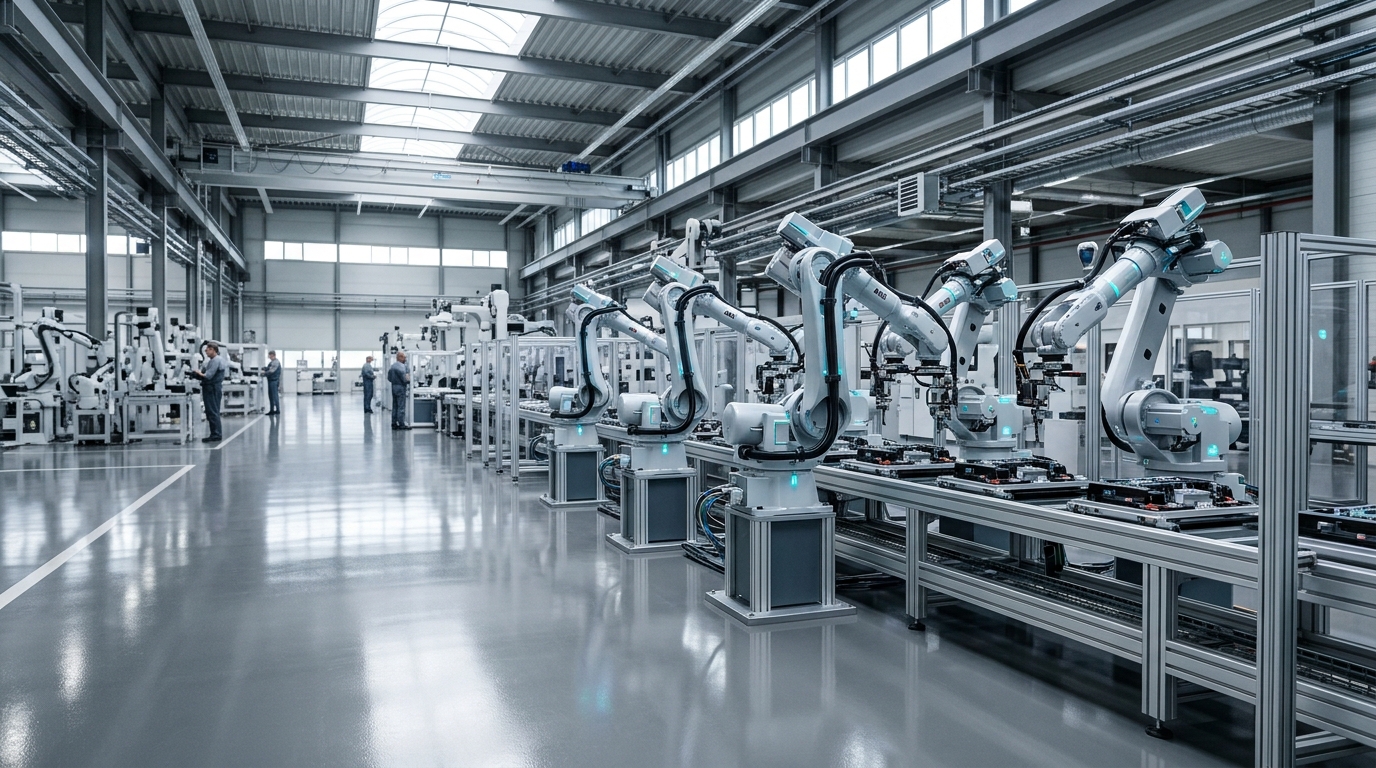
EV Battery Pack Module Assembly Cell
Automated robotic cell executing prismatic and pouch battery cell stacking, busbar laser welding, thermal paste dispensing, and high-voltage isolation testing.
Body-in-White 7th-Axis Gantry Welding
7th-axis linear track robotic spot welding and fiber laser seam joining for automotive body-in-white (BIW) framing and high-strength aluminum door apertures.
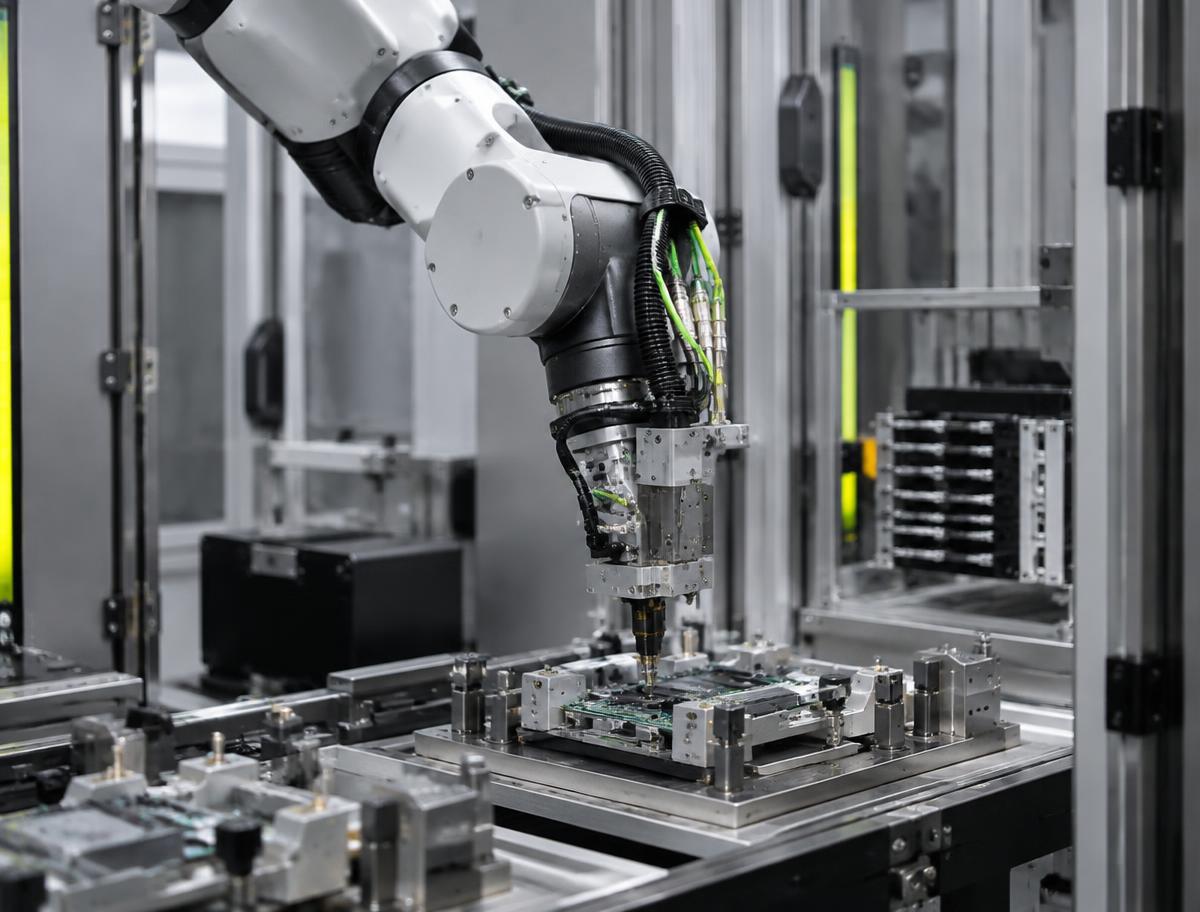
Powertrain & Gearbox Articulated Handling
High-torque articulated handling arms automating engine decking, electric drive unit (EDU) stator-rotor insertion, and transmission pallet transfer.
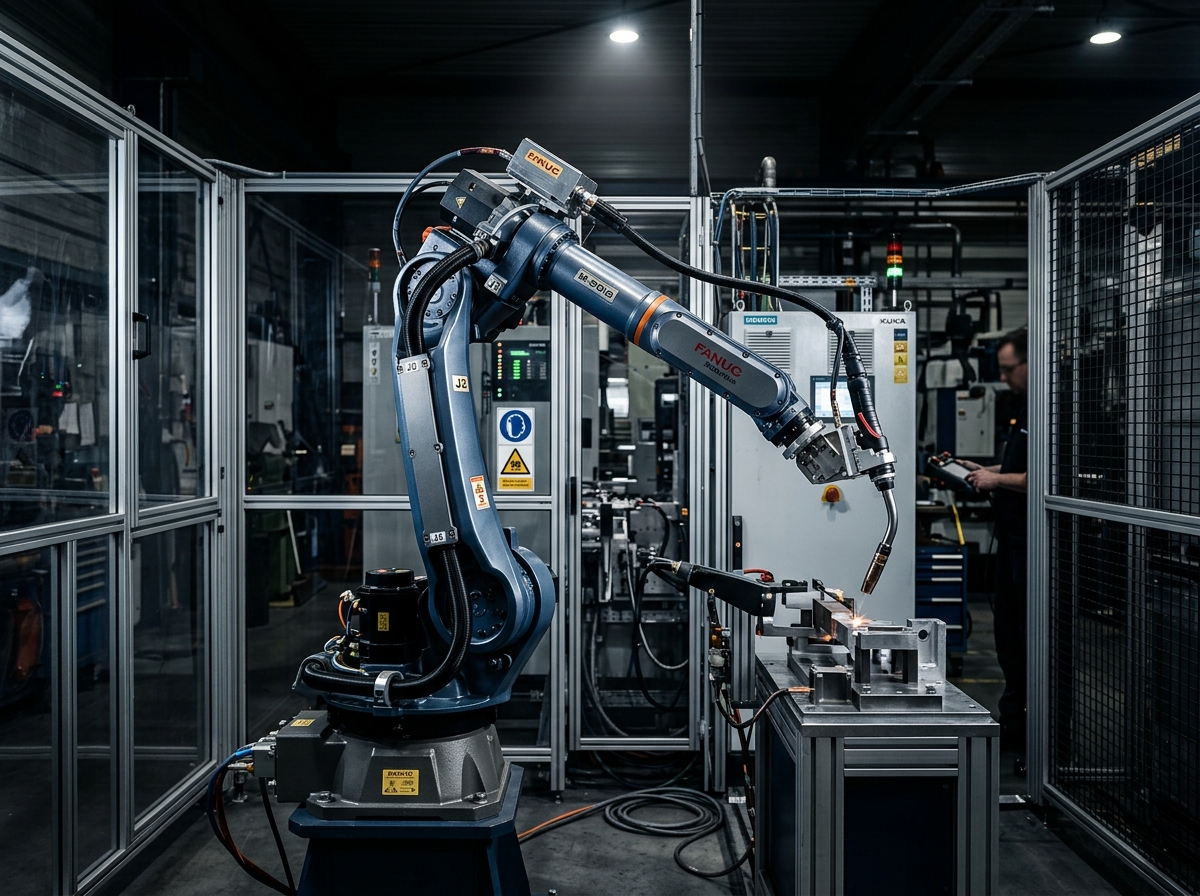
Dual-Gripper CNC Machine Tending Cell
Turnkey robotic tending cell loading and unloading high-tonnage stamping presses and multi-axis CNC milling centers with pneumatic zero-point fixtures.
Select Your Plastics and Rubber Manufacturing Automation Requirement
Toggle between core automation processes to inspect matching kinematic models, payload capacities, cycle times, and directly download engineering CAD files.
INDUS-BAT-K150 (7-DOF)
Engineered specifically for prismatic cell stacking, busbar tightening, and high-voltage module casing insertion with constant 6-DOF force/torque regulation.
Plastics and Rubber Manufacturing Automation Use Cases
Every production task has specific mechanical shock profiles, positioning tolerances, sensing architectures, and functional safety constraints. Explore detailed engineering breakdowns for each verified operation.
Ultra-Fast (0.4s Take-Out) In-Mold Labeling (IML) for Thin-Wall Tubs
Thin-wall food tub injection molds (wall thickness 0.4mm) cool rapidly; robot mold entry must be under 0.5s to prevent short shots.
High-speed side-entry linear Cartesian robot with carbon fiber extraction arms and high-voltage static charging heads.
Simultaneous electrostatic label placement into 8-cavity mold and vacuum take-out of freshly molded polypropylene tubs.
Automated Automotive Bumper Ultrasonic Degating & Punching
Large automotive bumper fascias (1.8m long) require precise trimming of injection sprues and parking sensor holes without paint stress cracks.
6-axis articulated robot with ultrasonic cutting knife and pneumatic clamping nest.
Robotic ultrasonic knife cutting of heavy runner gates and punching 6 ultrasonic parking sensor holes in polypropylene bumpers.
Tire Manufacturing Green Rubber Tread Strip Robotic Handling
Unvulcanized 'green' rubber tread strips are hot, sticky, and deform permanently if handled with uneven tension.
High-payload articulated robot equipped with multi-segment needle gripper bar and low-tack silicone pads.
Picking extruded green rubber tread strips (2.5 meters long, 45° angled bias cut) from cooling line and loading into book racks.
Robotic Brass Threaded Bushing Insert Loading in Injection Mold
Placing 16 hot brass threaded inserts into an active 300°C mold requires exact alignment to avoid mold clamp crushing.
Top-entry 3-axis Cartesian or 6-axis articulated robot with specialized heat-resistant expanding core pins.
Picking 16 threaded brass inserts from bowl feeder, heating, and placing onto mold core pins before injection cycle.
5-Axis High-Speed CNC Routing of Heavy Thermoformed Enclosures
Thermoformed heavy-gauge plastic sheets (ABS, HDPE) distort during cooling; rigid trim paths cause uneven wall thickness edges.
High-accuracy articulated robot with 24,000 RPM water-cooled routing spindle and perimeter vacuum fixture.
5-axis robotic trimming of perimeter flange and cutouts on heavy thermoformed industrial equipment covers.
Rotational Molding Heavy Tank De-Molding & Foam Filling
Large 1,000-liter polyethylene water tanks shrink tightly onto rotational mold aluminum cores, requiring massive extraction force.
Heavy-duty articulated robot (300 kg payload) equipped with high-force mechanical expanding gripper mandrel.
Robotic vacuum and mechanical hook extraction of hot polyethylene tanks (120°C) from rotomold clamshells.
Extrusion Blow Molding Bottle Take-Out & Inline Leak Testing
Blow-molded HDPE motor oil bottles can have microscopic pinholes in handle pinch seams, causing catastrophic shelf leaks.
High-speed servo take-out shuttle with integrated rotary neck deflashing knives and pressure testing heads.
Robotic extraction of 4 bottles from continuous extrusion blow molder, deflashing tail scrap, and high-speed pressure decay testing.
Resin Transfer Molding (RTM) Preform Robotic Net-Shape Placement
Carbon fiber dry textile preforms must be laid into complex heated RTM molds without fiber wrinkling or bridging in tight corners.
Articulated robot with reconfigurable needle gripper matrix and tactile roller compaction head.
Draping multilayer dry carbon fiber preforms into aerospace structural RTM mold tool heated to 120°C.
Robotic Hot-Plate & Vibration Welding of Automotive Intake Manifolds
Internal acoustic baffles inside polyamide (nylon) engine intake manifolds must withstand 3.5 bar turbo boost pressure without burst.
Articulated robot servicing dedicated servo-driven hot-plate or linear vibration welding press.
Robotic part handling, automated hot-plate platen melting (240°C), and servo-controlled joint compression.
Liquid Silicone Rubber (LSR) Automated Gasket Micro-Dispensing
Smartphone and watch IP68 seals require elastomeric silicone gaskets dispensed into 0.5mm micro-grooves without air voids.
High-precision benchtop Cartesian robot with progressive cavity micro-pump dispensing head.
Precision 2-part mixing and dispensing of reactive liquid silicone rubber along intricate 3D micro-perimeter.
Continuous Plastic Pipe Extrusion Line Dual-Robot Marking & Coil
High-density polyethylene (HDPE) gas pipes running continuously at 30 m/min must be marked with legal footage and coiled without line halt.
Traveling linear carriage robot synchronized with continuous extrusion puller speed.
Laser marking metric footage, OD measurement, cutting to length, and automated robotic coiler loading.
Robotic Multi-Component Polyurethane Foam Pouring for Car Seats
Automotive dual-density seating requires pouring soft comfort foam and firm side bolsters into open molds in <4 seconds.
High-speed 6-axis robot carrying 18 kg high-pressure mixing head over continuous conveyor carousel.
High-pressure dynamic mixing and robotic open-pour path distribution of polyol and isocyanate into heated aluminum molds.
Manufacturing Challenges & Robotic Solutions
Comparing conventional production bottlenecks against deterministic multi-axis robotic automation.
Plastics and Rubber Manufacturing Automation Hurdles
Demanding environmental conditions, high-speed cycle times, and precision limits dictate deterministic robotics.
- Minimizing mold open dwell time (<0.6s) to maintain maximum injection molding machine productivity
- Electrostatic discharge and label positioning drift in high-speed In-Mold Labeling (IML)
- Handling sticky, unvulcanized green rubber sheets in tire building without stretching or tearing
- High ambient thermal radiation (250°C - 350°C barrel temps) around injection nozzles and hot runner manifolds
Robotic Automation Potential
High-stiffness mechanical transmission, multi-axis sensory feedback, and real-time motion control.
- High-speed servo side-entry robots reaching accelerations >20G for sub-second IML cycles
- Static charging pinning heads electrostatically bonding polypropylene labels inside mold cavities
- Multi-axis articulated robots deburring and degating automotive plastic bumper fascias with compliance spindles
Accelerate Plastics and Rubber Manufacturing Automation
Access our specialized kinematics sizing tools, discuss payload vs cycle takt trade-offs, and receive 3D CAD space-claim models verified for this manufacturing discipline.
Connected Ecosystem
Other Manufacturing Sectors
Related Industrial Sectors
- Automotive
High-precision robotics meeting the extreme uptime and sub-millimeter tolerances of modern EV & automotive production.
- Electronics
Sub-micron repeatability and cleanroom-compliant automation for high-density electronic assemblies.
- Manufacturing
Rugged robotic automation engineered for high-uptime machine tending and harsh factory environments.