Textiles and Apparel Robotics
3D fabric ply layup, robotic ultrasonic slitting, automated sewing cells, bobbin handling, leather hide waterjet cutting, and shoe lasting.
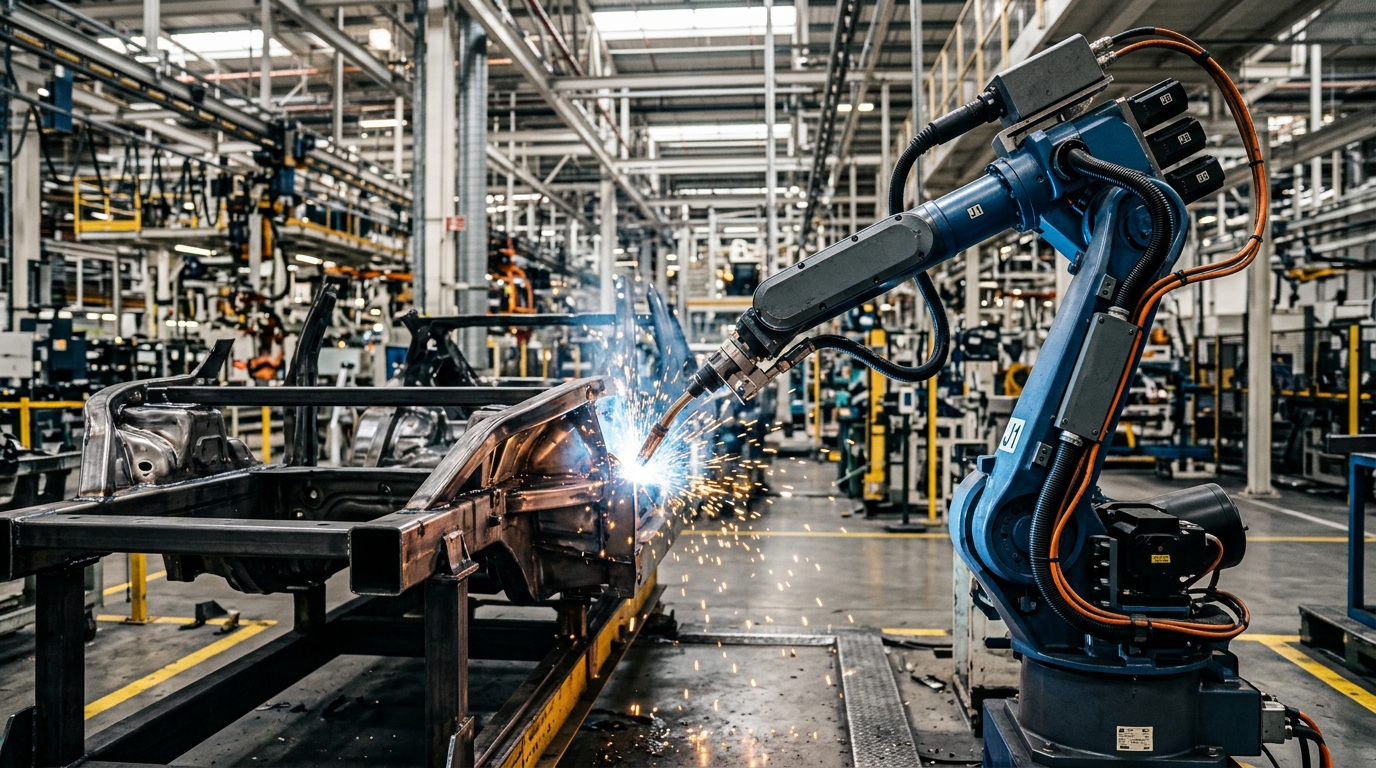
Takt Time Reduction
Down from 78s baseline on EV battery chassis trays
Sub-Millimeter Precision
Closed-loop laser triangulation seam tracking guidance
Max Dynamic Payload
Rigid heavy-duty articulated arm and gantry tooling
Defect Interception & Uptime
Zero unplanned line shutdowns across continuous 24/7 duty
Robotic Applications in Textiles and Apparel
Turnkey robotic workcells, kinematic metrics, and operational architectures deployed across modern textiles and apparel manufacturing plants.
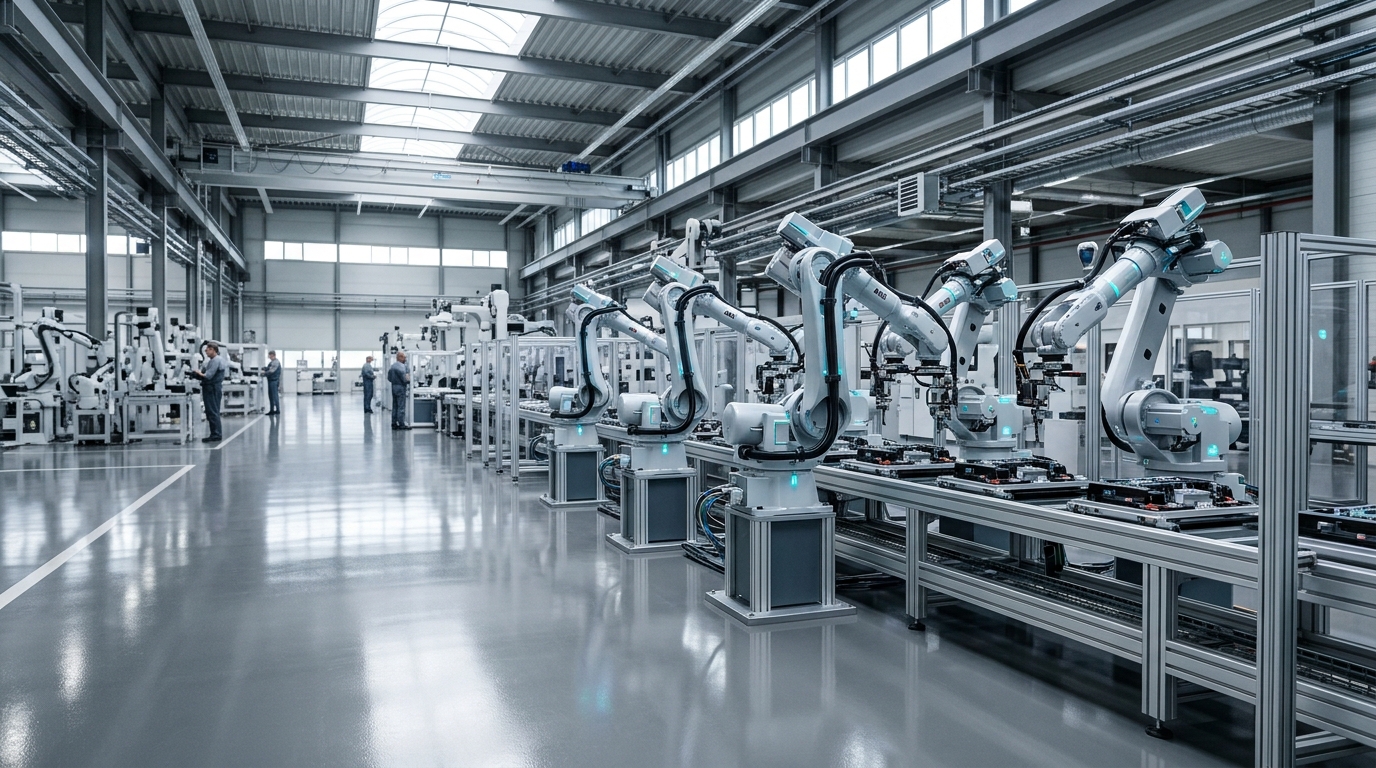
EV Battery Pack Module Assembly Cell
Automated robotic cell executing prismatic and pouch battery cell stacking, busbar laser welding, thermal paste dispensing, and high-voltage isolation testing.
Body-in-White 7th-Axis Gantry Welding
7th-axis linear track robotic spot welding and fiber laser seam joining for automotive body-in-white (BIW) framing and high-strength aluminum door apertures.
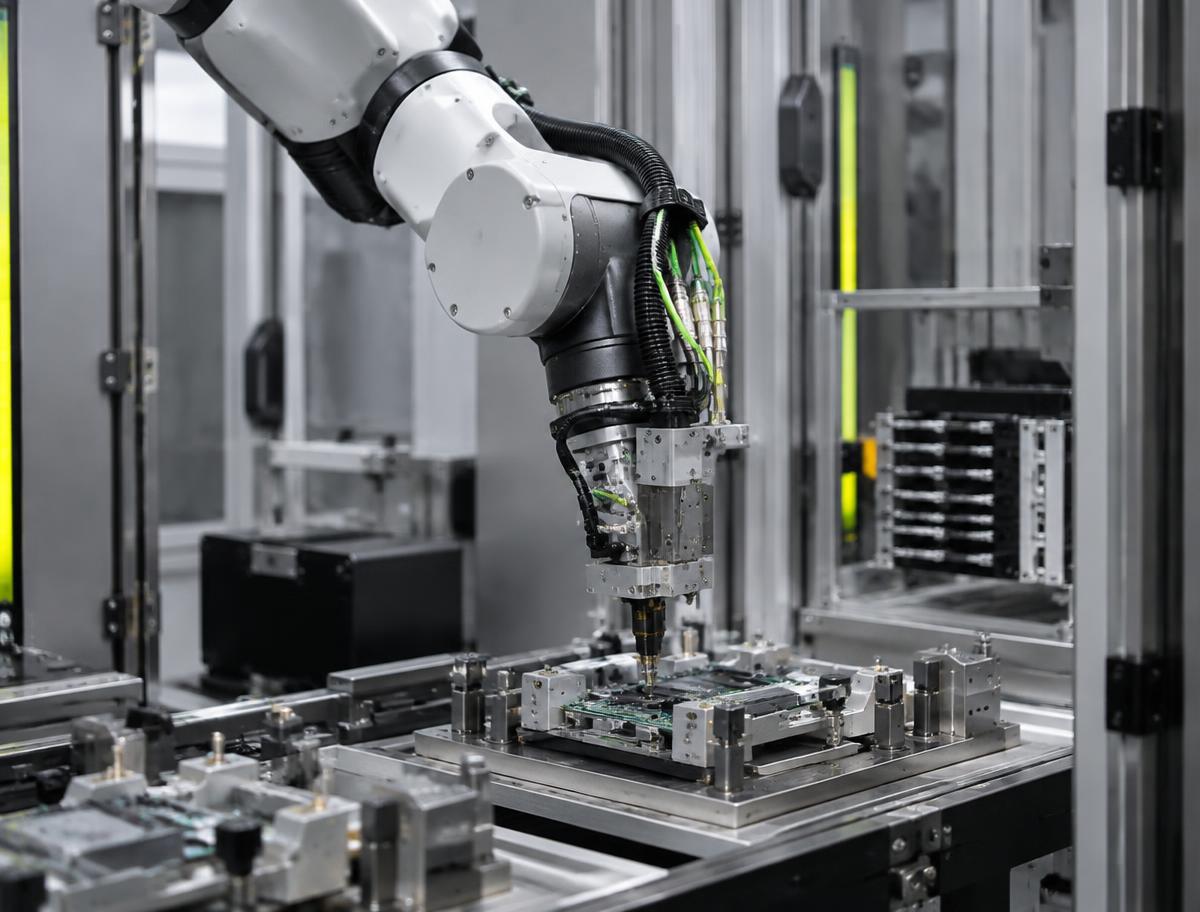
Powertrain & Gearbox Articulated Handling
High-torque articulated handling arms automating engine decking, electric drive unit (EDU) stator-rotor insertion, and transmission pallet transfer.
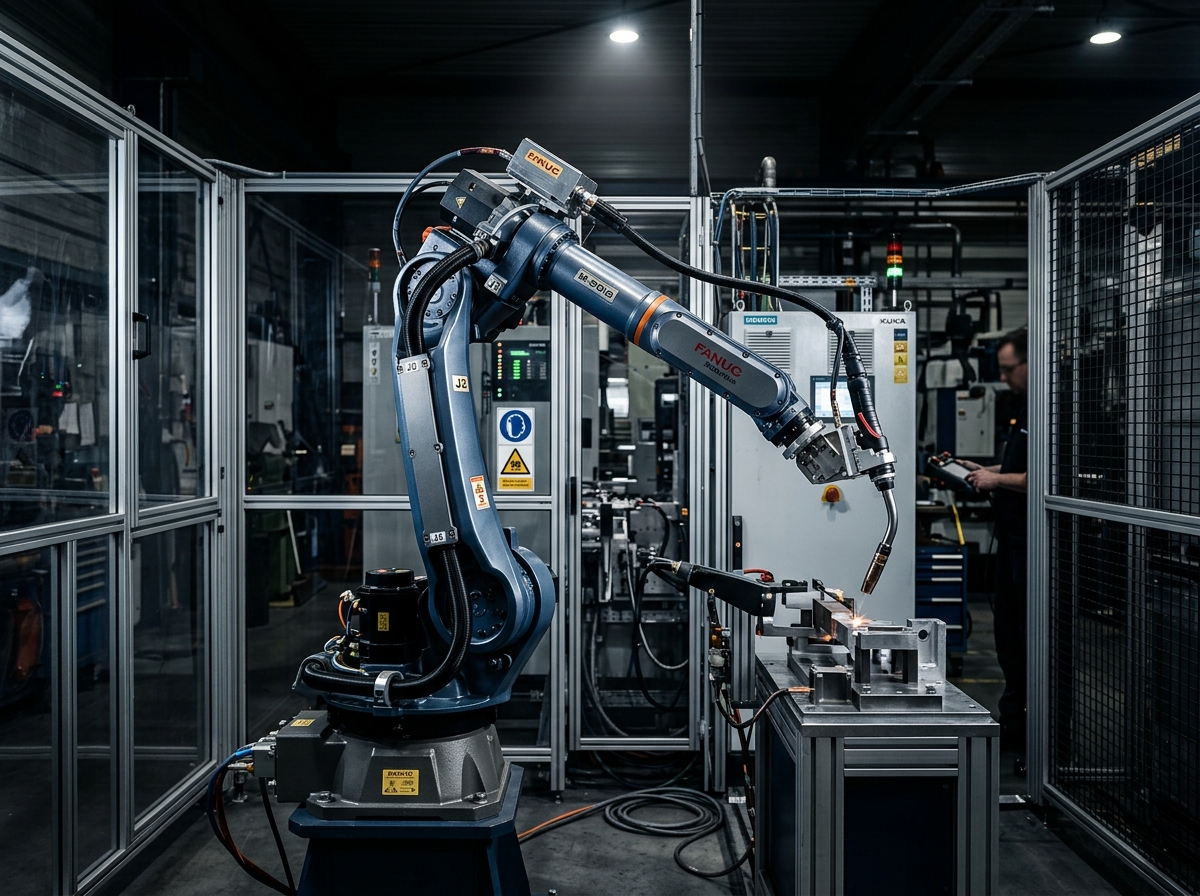
Dual-Gripper CNC Machine Tending Cell
Turnkey robotic tending cell loading and unloading high-tonnage stamping presses and multi-axis CNC milling centers with pneumatic zero-point fixtures.
Select Your Textiles and Apparel Automation Requirement
Toggle between core automation processes to inspect matching kinematic models, payload capacities, cycle times, and directly download engineering CAD files.
INDUS-BAT-K150 (7-DOF)
Engineered specifically for prismatic cell stacking, busbar tightening, and high-voltage module casing insertion with constant 6-DOF force/torque regulation.
Textiles and Apparel Automation Use Cases
Every production task has specific mechanical shock profiles, positioning tolerances, sensing architectures, and functional safety constraints. Explore detailed engineering breakdowns for each verified operation.
Automated Carbon & Glass Fiber 3D Preform Ply Layup
Manual preform layup causes fiber misalignment, wrinkles, and voids, degrading structural integrity in aerospace and automotive composite parts.
6-Axis Articulated Robot on Linear Gantry Rail with automated roller-end-effector.
Layer-by-layer placement of dry carbon/glass fabric plies onto complex curved female molds with laser ply boundary projection in cleanroom (ISO Class 8).
High-Speed Robotic Ultrasonic Fabric Slitting & Edge Sealing
Mechanical rotary blades fray synthetic fabric edges and suffer rapid dulling from abrasive technical fibers like aramid and Kevlar.
High-speed 6-Axis Articulated Robot with 35 kHz ultrasonic cutting sonotrode end-effector.
Continuous ultrasonic trimming and edge welding of multi-layered synthetic technical textiles, geotextiles, and airbag fabrics.
Robotic 3D Seam Sewing & Tensioning Cell
Automating 3D curved seams (such as automotive upholstery, leather seats, and aviation furnishings) is prone to seam puckering and skipped stitches.
6-Axis Articulated Robot equipped with pneumatic clamp gripper and real-time optical seam tracker.
Multi-axis synchronized guidance of pre-cut leather/vinyl patterns through stationary industrial long-arm lockstitch sewing head.
Automated Yarn Bobbin Doffing & Ring-Spinning AMR Transport
Manual bobbin doffing across spinning frames with thousands of spindles causes machine downtime and risks yarn filament snagging.
Autonomous Mobile Robot (AMR) with integrated dual-arm collaborative SCARA manipulator and custom expanding mandrel gripper.
Autonomous navigation down narrow 900 mm spinning mill aisles, extracting wound yarn bobbins and placing empty tube cores in 35°C, 65% RH environment.
Automated Leather Hide Defect Scanning & CNC Cutting Tending
Natural leather hides have irregular shapes, grain defects, tick bites, and thickness variations, causing up to 35% material scrap when cut manually.
High-speed Cartesian / Gantry Unloader with multi-zone matrix vacuum suction cup arrays.
High-resolution vision inspection of stretched hides, algorithmic defect nesting, and automated suction unloading of cut leather pieces.
Robotic Garment Unfolding, Inspection & Packaging System
Folding and bagging finished garments remains heavily reliant on manual labor due to unpredictability of flexible, slippery textiles.
Dual Collaborative Robot Arms equipped with hybrid soft pneumatic/friction fingertips and overhead 3D depth camera.
Picking tumbled apparel from bin, detecting corners/sleeves, spreading flat on folding board, and inserting into polybag in fulfillment center.
Corrosive Chemical Dyeing Vat Loading & Unloading Cell
Textile dyeing involves boiling acid/reactive dye baths, scalding steam, and toxic colorants hazardous to human operators.
Heavy-Payload Foundry-Grade 6-Axis Robot (IP67 body, special epoxy coating, stainless steel flange).
Submerging and extracting 80 kg yarn skein carriers into pressurized boiling liquor dyeing vessels at 130°C and pH 3-11.
Automated Circular Knitting Machine Creel Yarn Spool Replenishment
High-gauge circular knitting machines consume 96+ yarn cones simultaneously; manual replenishment requires frequent machine stops.
Rail-Mounted Overhead Cartesian Gantry with 4-Axis SCARA wrist and integrated air splicer.
Monitoring yarn cone depletion on creel towers, fetching new yarn package, and performing automated pneumatic yarn splicing.
Heavy Geotextile Roll Core Loading & Centerline Slitting
Thick non-woven needle-punched geotextile rolls weigh up to 1,200 kg; manual core insertion causes roll damage and severe pinch hazards.
Heavy-Duty Overhead Rail Crane Robot with pneumatic expanding internal mandrel boom.
Transferring wound geotextile rolls from winder, inserting steel cores, and lifting into high-density storage racks.
Robotic Shoe Upper 3D Adhesive Dispensing & Lasting
Solvent-based adhesive application on uneven athletic footwear uppers causes messy overflow, solvent emissions, and inconsistent sole bonding.
Compact 6-Axis Robot with heated micro-extrusion dispenser and integrated 3D profile scanner.
Continuous 3D micro-bead polyurethane hot-melt adhesive dispensing along asymmetric footwear lasting margins.
Automated Apparel Hanger High-Speed Induction & Sorting Rail
E-commerce apparel returns and distribution require sorting thousands of hung garments per hour with minimal garment wrinkles.
High-Speed Delta Robot (4-Axis) with specialized hook-engagement magnetic/mechanical end-effector.
High-speed picking of garment hanger hooks from staging bins and loading onto moving overhead power-and-free trolley conveyors.
Robotic Carpet Tile Ultrasonic Cutting & Matrix Stacking Cell
Heavy bitumen and PVC-backed carpet tiles generate extreme cutting blade resistance, causing uneven tile edges and pile shedding.
Dual-Gantry Ultrasonic Slitting Bridge combined with 4-Axis Palletizing Robot equipped with vacuum needle grid.
Cross-cutting and corner trimming continuous 2 m wide tufted carpet webs into 500x500 mm tiles, followed by palletizing.
Manufacturing Challenges & Robotic Solutions
Comparing conventional production bottlenecks against deterministic multi-axis robotic automation.
Textiles and Apparel Automation Hurdles
Demanding environmental conditions, high-speed cycle times, and precision limits dictate deterministic robotics.
- Dynamic deformation and slip during high-speed handling of limp textiles and porous fabrics
- Airborne textile lint and fiber dust contamination requiring sealed IP65/IP67 mechanical enclosures
- Complex 3D seam trajectories requiring coordinated multi-axis toolpathing with synchronized feed dogs
- High variance in natural materials (leather hides, wool, silk) requiring real-time visual inspection and adaptive cutting
Robotic Automation Potential
High-stiffness mechanical transmission, multi-axis sensory feedback, and real-time motion control.
- Electrostatic, Bernoulli, and needle gripping systems for damage-free single-ply fabric separation
- High-speed SCARA and Delta robots with low-backlash planetary gearboxes for high-frequency pick-and-place
- Vision-guided multi-axis robotic arms for automated 3D adhesive dispensing on footwear uppers
Accelerate Textiles and Apparel Automation
Access our specialized kinematics sizing tools, discuss payload vs cycle takt trade-offs, and receive 3D CAD space-claim models verified for this manufacturing discipline.
Connected Ecosystem
Other Manufacturing Sectors
Related Industrial Sectors
- Automotive
High-precision robotics meeting the extreme uptime and sub-millimeter tolerances of modern EV & automotive production.
- Electronics
Sub-micron repeatability and cleanroom-compliant automation for high-density electronic assemblies.
- Manufacturing
Rugged robotic automation engineered for high-uptime machine tending and harsh factory environments.