TOTAL ROBOTICS
TAXONOMY
A definitive industrial engineering classification framework preserving the formal international distinction between morphology-driven industrial manipulators and application/locomotion-driven service robots. Navigate eight core pillars through eight orthogonal discovery facets, dual-axis engineering parameter sheets, and verified physical compatibility linkages into the INDUS component catalogue.
The Eight Pillars of Modern Robotics
Each pillar represents a distinct mechanical morphology and operational domain, complete with dedicated engineering photography, governing standards, and representative types.
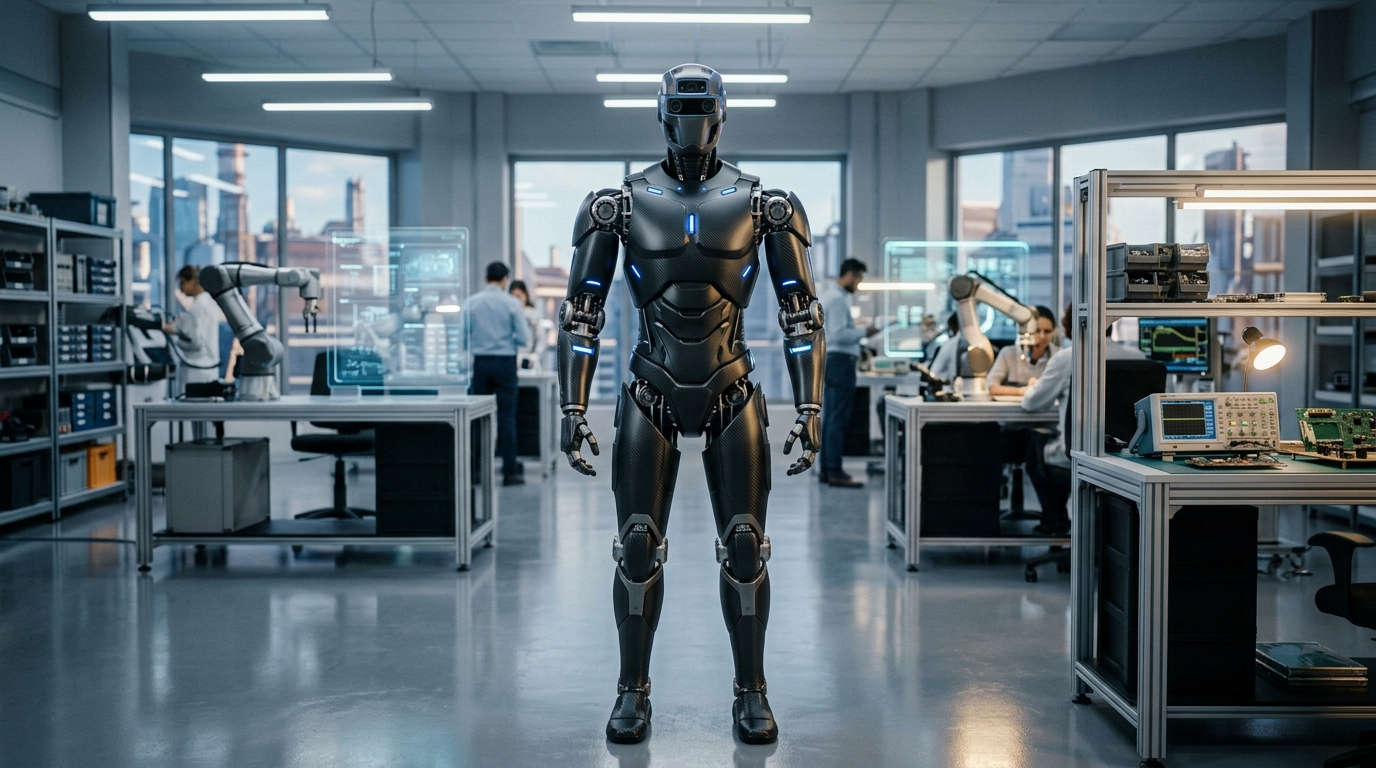
Humanoid Robots
Robots exhibiting anthropomorphic morphology comprising head, torso, multi-DoF arms, and either bipedal legs or a mobile base. Designed to operate in unstructured environments engineered for human anatomy, utilizing whole-body balance control and high-DoF dexterous manipulation.
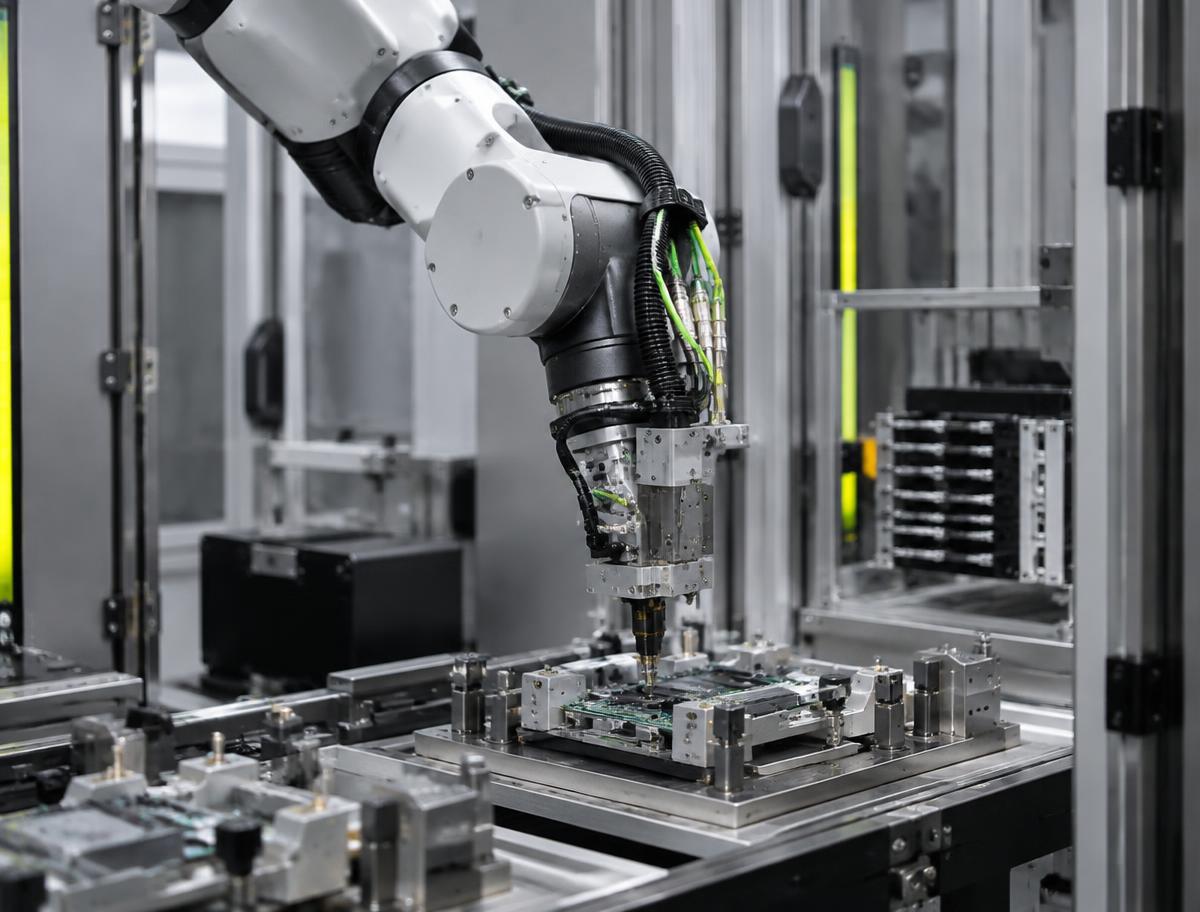
Industrial Robots
Automatically controlled, reprogrammable, multipurpose manipulators programmable in three or more axes, fixed in place or mobile, for use in industrial automation applications (ISO 8373:2021). Classified by kinematic topology into Articulated, SCARA, Cartesian/Gantry, Parallel/Delta, and Collaborative formats.
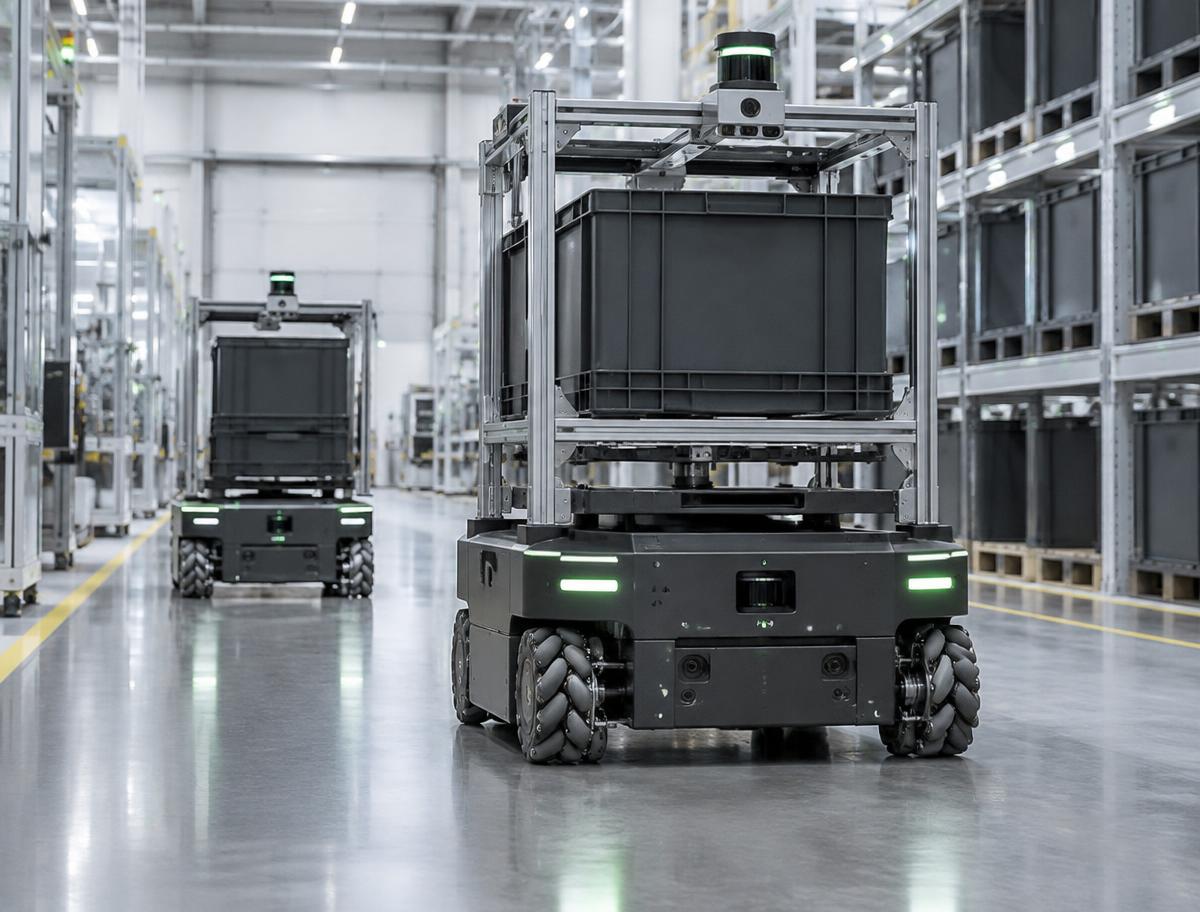
Mobile Driverless Robots
Self-propelled industrial driverless transport vehicles operating under automatic control to move materials without continuous human driver presence. Classified by guidance system (AGV with physical guides vs AMR with natural-feature SLAM) and chassis mechanics (pallet truck, counterbalance forklift, tugger, mobile manipulator).
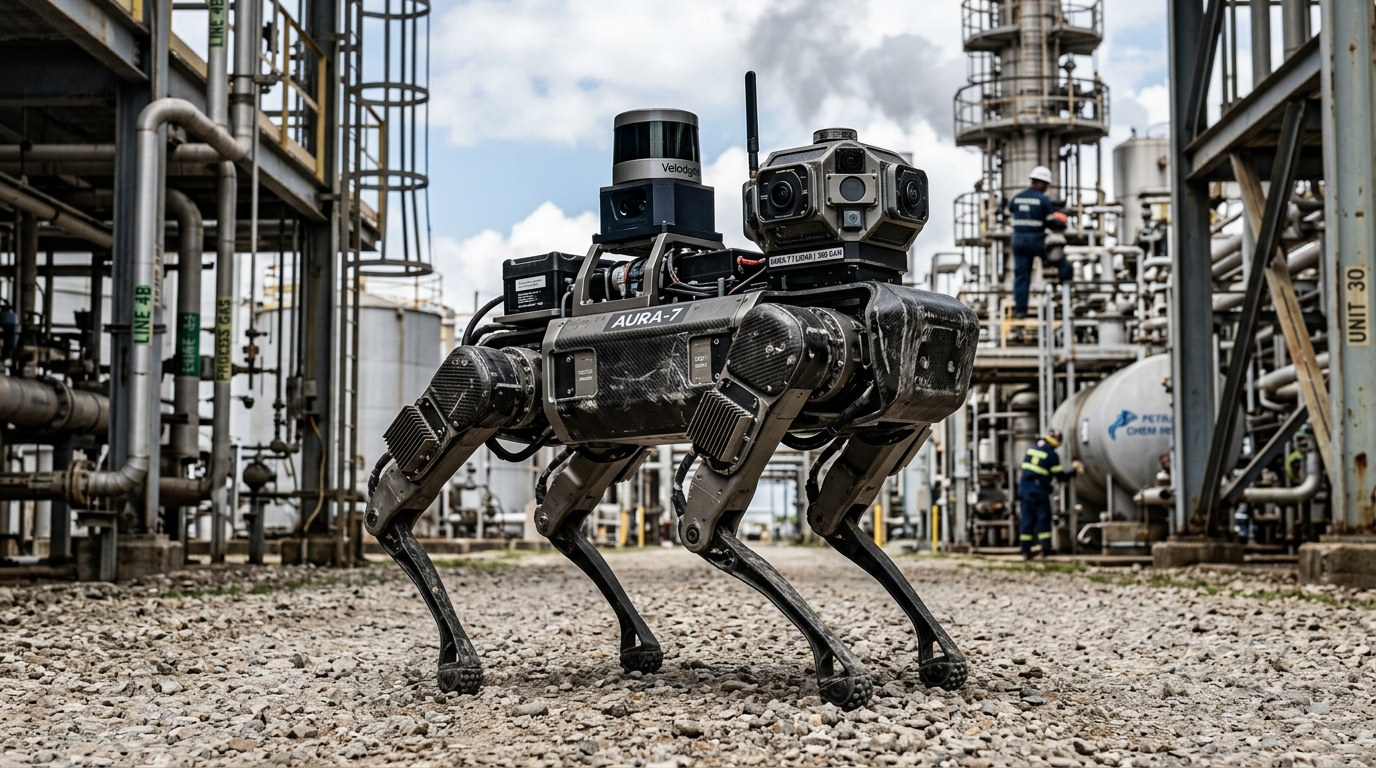
Robotic Mules and Legged/Heavy-Duty UGVs
All-terrain unmanned ground vehicles (UGVs) and legged dynamic systems engineered for unstructured, hazardous, or off-road environments inaccessible to wheeled indoor platforms. Features high-clearance suspension, continuous tracks, or multi-DoF articulated legs for traversing gravel, mud, rubble, and industrial stairs.
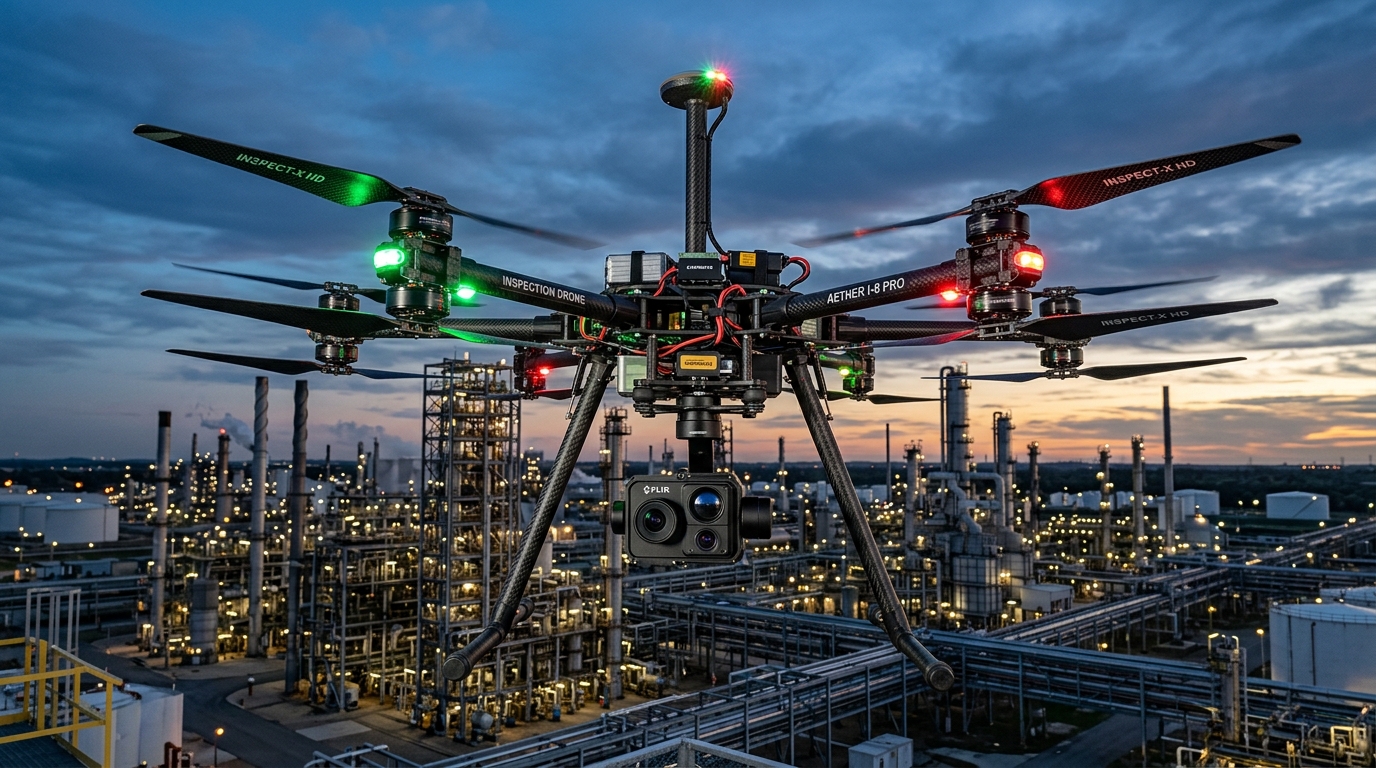
Aerial Robotics
Unmanned Aircraft Systems (UAS) and aerial robotic platforms equipped with autonomous flight controllers, collision avoidance, and specialized sensor or manipulation payloads. Operates in low-altitude airspace and GPS-denied confined industrial assets (storage tanks, boilers, bridges).
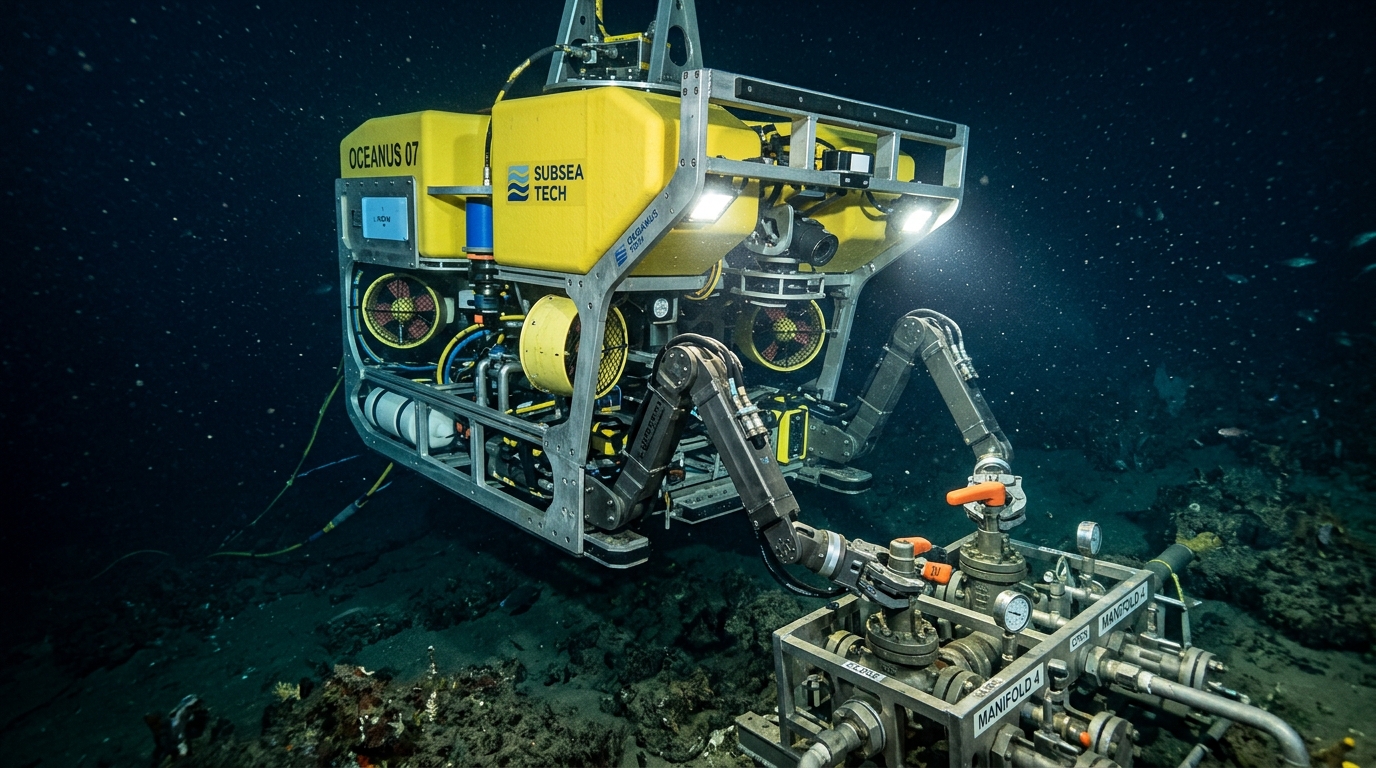
Underwater Robotics
Submersible robotic systems operating in marine, coastal, and offshore environments. Includes Remotely Operated Vehicles (ROVs) controlled via armored umbilical cables, Autonomous Underwater Vehicles (AUVs) executing pre-programmed acoustic surveys, and benthic crawling platforms equipped with subsea manipulators.
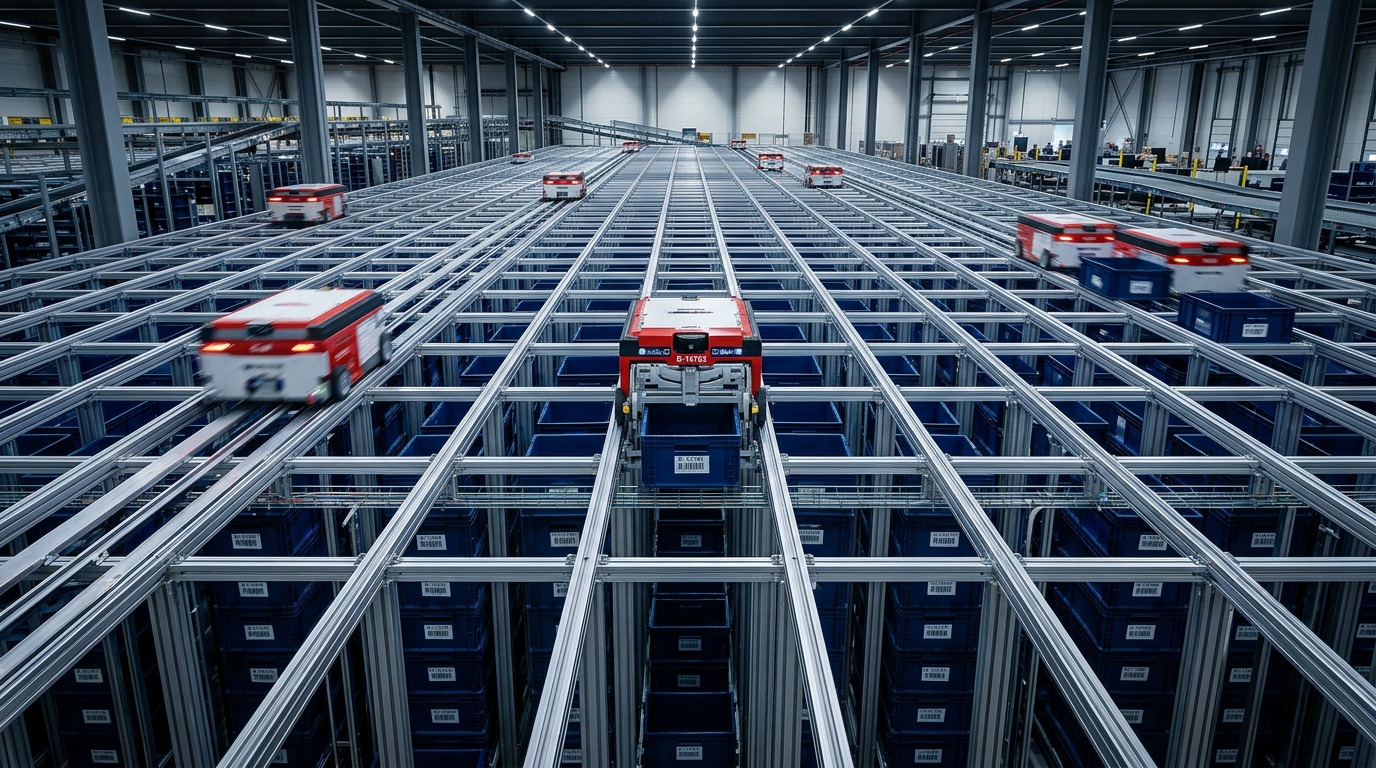
Logistics and Supply-Chain Robots
Integrated robotic and automation machinery engineered for high-density warehouse storage, item singulation, high-speed parcel sortation, and automated pallet building. Combines robotic cube grids, autonomous rail-guided shuttles, cross-belt sorters, and high-speed gantry depalletisers.
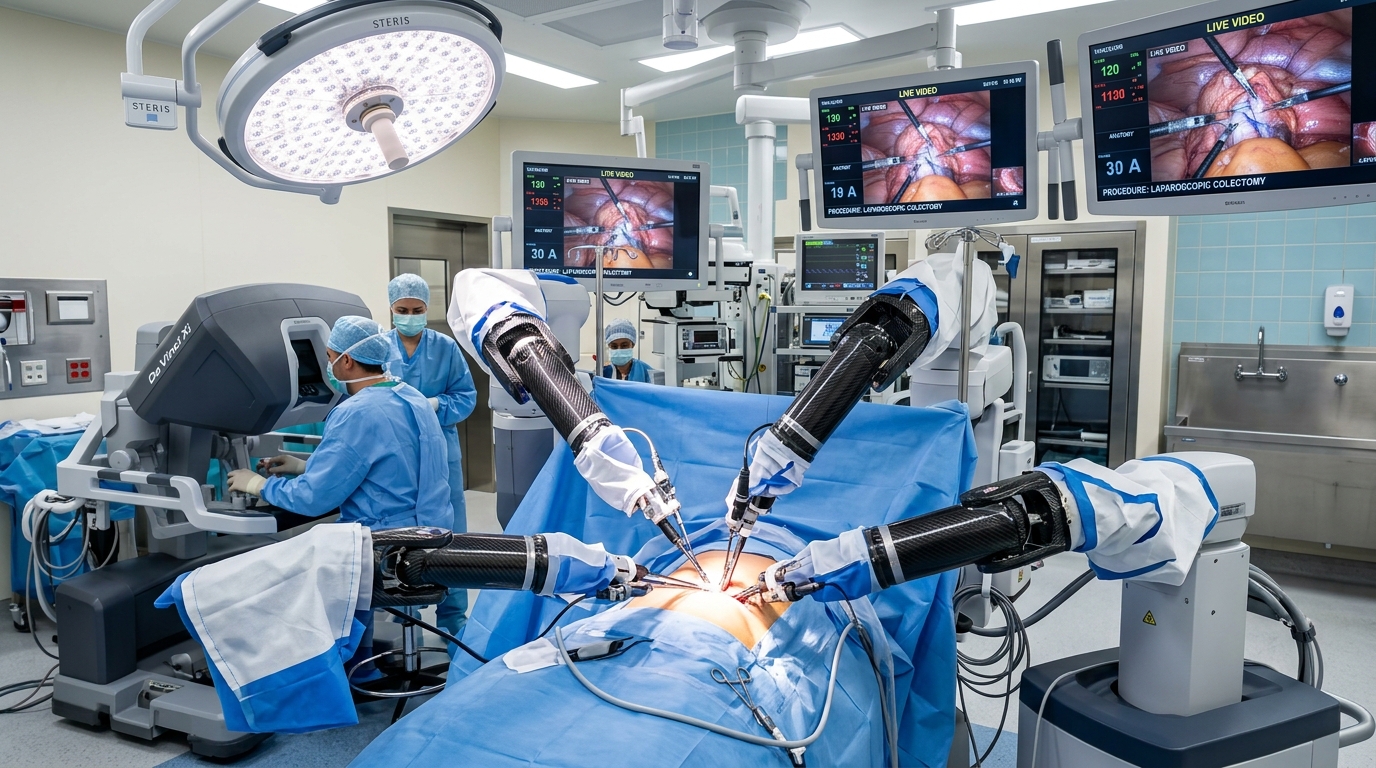
Autonomous and Specialised Mechanical Systems
Domain-specific robotic machinery engineered for highly constrained, regulated, or extreme operating environments. Encompasses precision surgical master-slave systems, agricultural crop harvesting, construction 3D concrete printing, rehabilitation exoskeletons, and laboratory liquid handling workstations.
Taxonomy Explorer & Specification Engine
Filter across 8 orthogonal dimensions, inspect dual-axis engineering parameter sheets, explore interactive component relationship graphs, or review governing ISO/IFR ground truth registers.
Bipedal Humanoid Robot
Dual-leg articulated kinematic chain with whole-body dynamic walking and bi-manual manipulation.
Wheeled Humanoid Robot
Anthropomorphic dual-arm upper torso mounted on self-balancing or omnidirectional mobile chassis.
Articulated Industrial Robot Arm (6-Axis)
Universal serial kinematic manipulator with six revolute joints delivering spherical reach.
SCARA Robot (Selective Compliance Articulated Robot Arm)
4-axis planar articulated robot arm optimized for high-speed pick-and-place and screwdriving.
Collaborative Robot Arm (Cobot)
Power and force limited articulated arm with joint torque sensors for safe cageless human teamwork.
Autonomous Mobile Robot (AMR)
Natural feature SLAM navigation mobile platform for dynamic factory and warehouse transport.
Mobile Manipulator (AMR + Articulated Arm)
Combined autonomous mobile platform with multi-axis articulated arm for untethered manipulation.
Quadruped Inspection Robot
Four-legged dynamic walking robot for autonomous inspection in complex industrial facilities.
Confined-Space Industrial Inspection Drone
Collision-resilient cage-protected multirotor for GPS-denied boilers, pipes, and tanks.
Work-Class Remotely Operated Vehicle (ROV)
Heavy subsea intervention platform with dual manipulators and hydraulic tooling skids.
Automated Storage & Retrieval Cube Grid (AS/RS)
Ultra-high-density storage grid with autonomous top-running robots retrieving nested bins.
Robotic Surgical System (Multi-Arm Laparoscopic)
Master-slave teleoperated surgical console with articulated micro-instruments for minimally invasive surgery.
Autonomous Agricultural Harvesting & Weeding Robot
All-terrain autonomous field vehicle equipped with multi-spectral vision and high-speed weed targeting.
Need Verification or Custom Robot Kinematics Sizing?
Our principal robotics engineers provide deterministic joint torque sizing, reducer inertia matching, safety cell validation (ISO 10218 / ISO 3691-4), and VDA 5050 fleet architecture review.