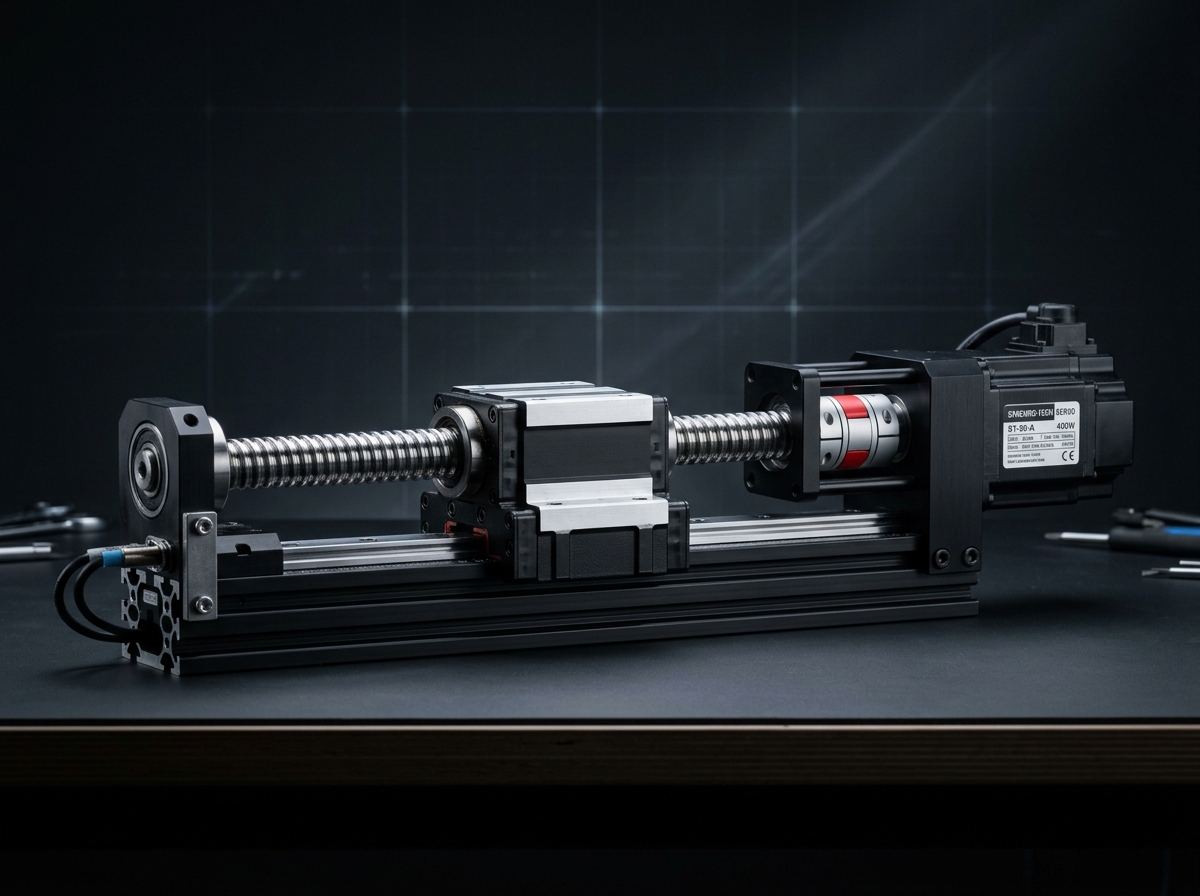
IND-ACT-LIN-200-B
Verified
Actuators
Linear Actuators
Precision guided linear motion module for controlled travel and repeatable positioning.
Effective Stroke…100 - 2500 mm
Continuous Thrus…1250 N
Peak Dynamic Thr…3100 N
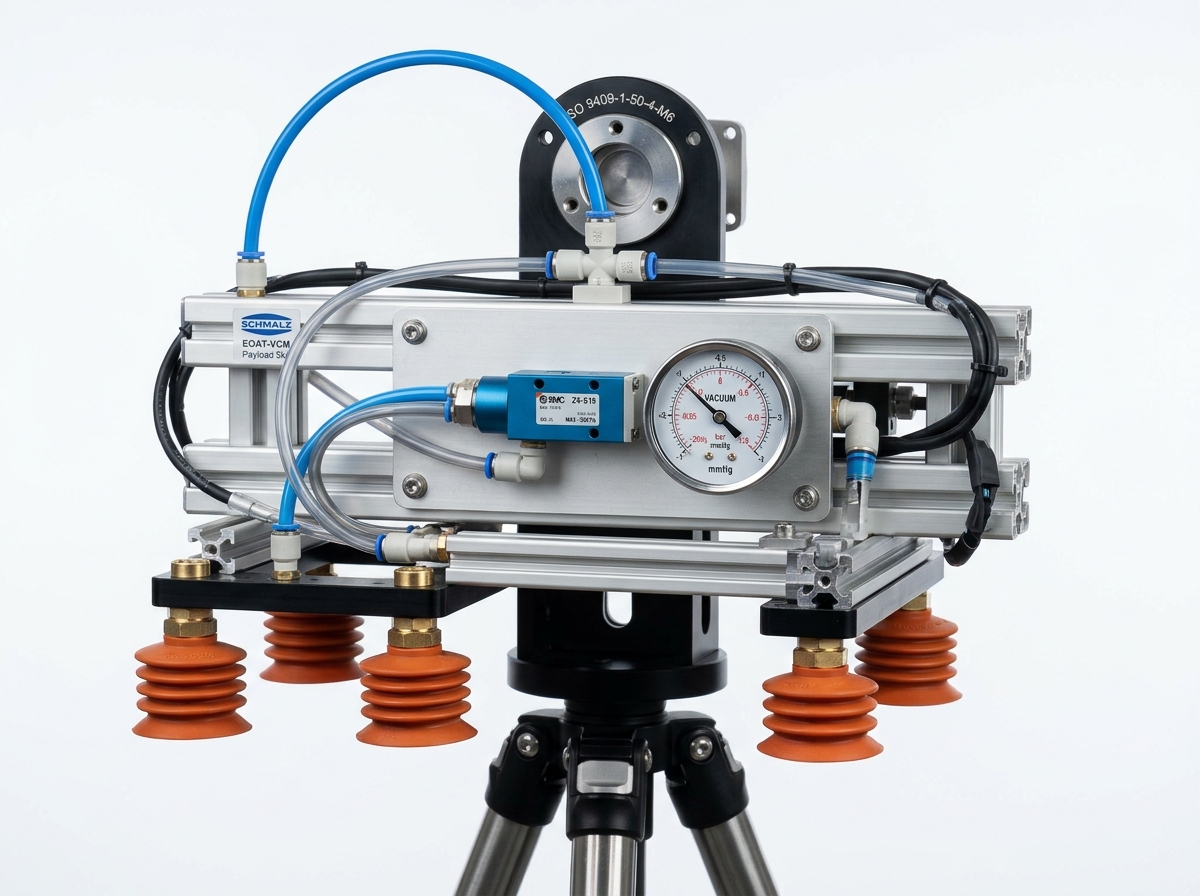
Lifts highly porous, fibrous, or air-permeable materials where vacuum suction cups fail due to air bypass.
Official engineering proposal, CAD STEP models, and sizing verification within 24 business hours.
Detailed mechatronic breakdown of Pneumatic Interlocking Needle Gripper for Porous Media, highlighting functional architecture, physical operating mechanisms, and deployment role.
Lifts highly porous, fibrous, or air-permeable materials where vacuum suction cups fail due to air bypass.
Multiple pairs of angled hardened steel needles penetrate the top layers of the porous material, locking under pneumatic pressure.
Eliminates operational failure modes related to: Needle penetration depth (0 - 12 mm), Needle diameter (1.2 - 2.0 mm).
Provides the physical contact, clamping, and process tooling interface between the robotic manipulator and the manufactured workpiece.
Calibrated workpiece clamping force, compliant passive/active centering, and pneumatic vacuum suction generation. Assigned to Robot Wrist Tooling & Workpiece Manipulation Interface.
Robot controller transmits target gripping width and calibrated force limit over IO-Link, fieldbus, or discrete 24V I/O.
Synchronized dual-finger wedge mechanisms or multi-stage Venturi vacuum ejectors translate actuator input into workpiece contact.
Current feedback, optical distance sensing, or vacuum pressure threshold sensors confirm secure part acquisition before robot arm motion begins.
Higher force-to-weight ratio and low initial cost, but lacks intermediate finger positioning, force programmability, and energy efficiency.
Instantaneous grip for sheet metal without custom jaws, but only works on ferromagnetic metals and can attract grinding chips/debris.
Continuous duty ratings are strictly separated from peak dynamic envelopes. All parameters reflect verified laboratory data traceable to ISO 9409-1 (Mechanical Interfaces) · ISO 14539 (Object Handling).
| Parameter | Specification Value | Unit | Notes & Test Conditions |
|---|---|---|---|
Needle Penetration Verified | Adjustable 0.5 - 15 mm | mm | Audited per Non-Woven Handling Test Methodology INDA WSP 130 |
Needle Count Verified | 8 - 32 needles per module | N | Audited per Non-Woven Handling Test Methodology INDA WSP 130 |
Holding Force Verified | Up to 150 N in foam | N | Audited per Non-Woven Handling Test Methodology INDA WSP 130 |
System Interface Compatibility Standard | Pneumatic 4 - 6 bar clean air | Standard | Supported physical and electronic mating connections |
Select a verified physical variant below to inspect continuous ratings, peak torque/force envelopes, and dimension comparisons.
Every application below reflects documented load capabilities, thermal equilibrium boundaries, and kinematics integration for Pneumatic Interlocking Needle Gripper for Porous Media.
Environment: Automated production facilities and manufacturing cells
Demanding precision positioning and repeatability requirements under high-duty continuous operation.
Provides calibrated Pneumatic Interlocking Needle Gripper for Porous Media performance adhering strictly to ISO 9409-1 (Mechanical Interfaces) · ISO 14539 (Object Handling).
Environment: Automated production facilities and manufacturing cells
Demanding precision positioning and repeatability requirements under high-duty continuous operation.
Provides calibrated Pneumatic Interlocking Needle Gripper for Porous Media performance adhering strictly to ISO 9409-1 (Mechanical Interfaces) · ISO 14539 (Object Handling).
Environment: Automated production facilities and manufacturing cells
Demanding precision positioning and repeatability requirements under high-duty continuous operation.
Provides calibrated Pneumatic Interlocking Needle Gripper for Porous Media performance adhering strictly to ISO 9409-1 (Mechanical Interfaces) · ISO 14539 (Object Handling).
Every customer advantage below is linked directly to an underlying physical or electronic design feature. Operating boundaries and verification conditions are explicitly declared.
Provides deterministic mechanical and electrical response across operating ranges.
Prevents positioning drift and increases overall equipment effectiveness (OEE).
Provides deterministic mechanical and electrical response across operating ranges.
Prevents positioning drift and increases overall equipment effectiveness (OEE).
Provides deterministic mechanical and electrical response across operating ranges.
Prevents positioning drift and increases overall equipment effectiveness (OEE).
Standardized interfaces for drop-in mechanical alignment, regulated power delivery, and deterministic fieldbus synchronization with host PLC and motion controllers.
Pneumatic 4 - 6 bar clean air
Universal mounting in horizontal, vertical, or inverted orientations with precision dowel hole alignment.
48V DC Regulated Bus (24V–56V range)
Integrated field-oriented control or compatible with standard industrial AC/DC servo inverters.
Cycle Time ≤ 1.0 ms (Jitter < 1 µs)
Supports cyclic synchronized position (CSP), velocity (CSV), and torque (CST) operating modes.
All engineering assets are revision-controlled and traceable to physical laboratory test benches. Request calibrated files directly from our engineering desk without broken links.
IND-EE-NEEDLE-POROUS-GRIPPER_ASSEMBLY.STEPAudited Lab Specification
Accurate C.G. Matrix
Official Documentation
Precision guided linear motion module for controlled travel and repeatable positioning.
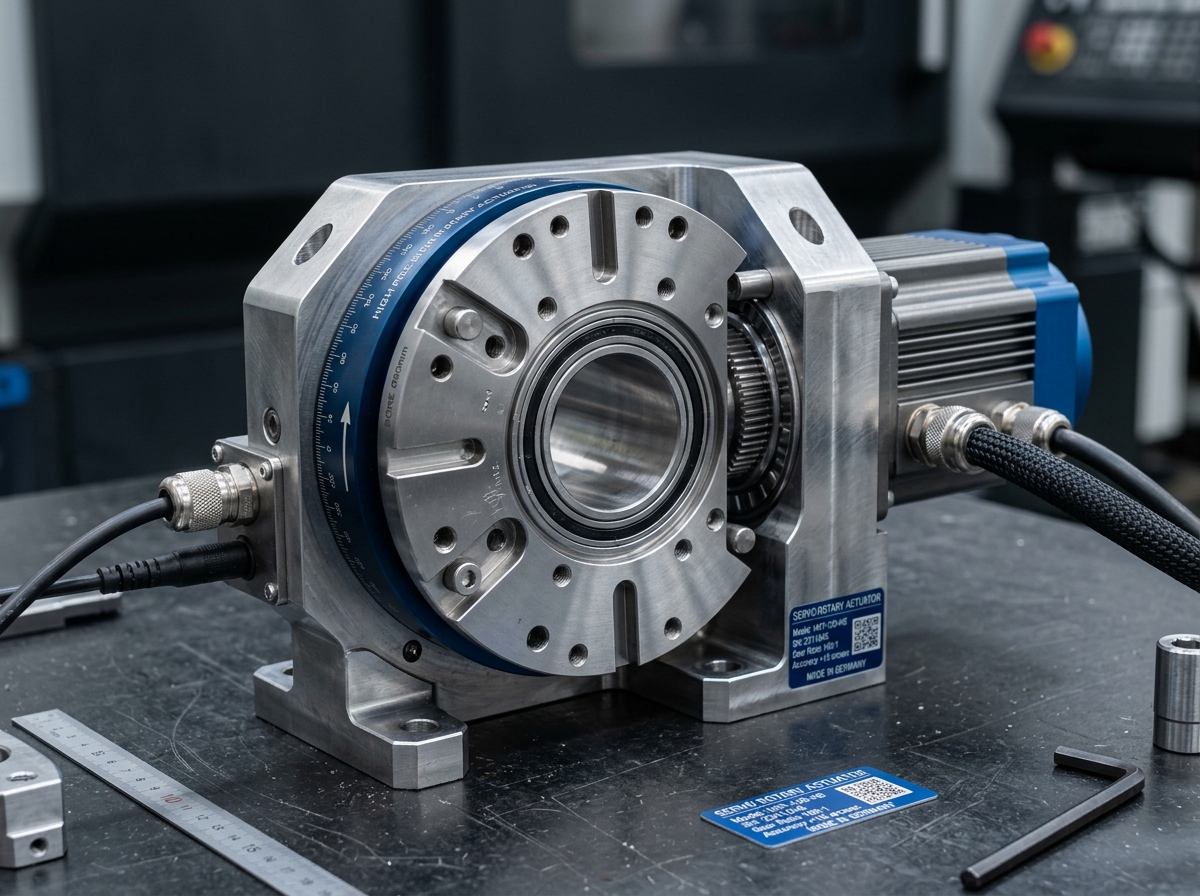
High-torque rotary actuation module with zero-backlash gearing for joint articulation.
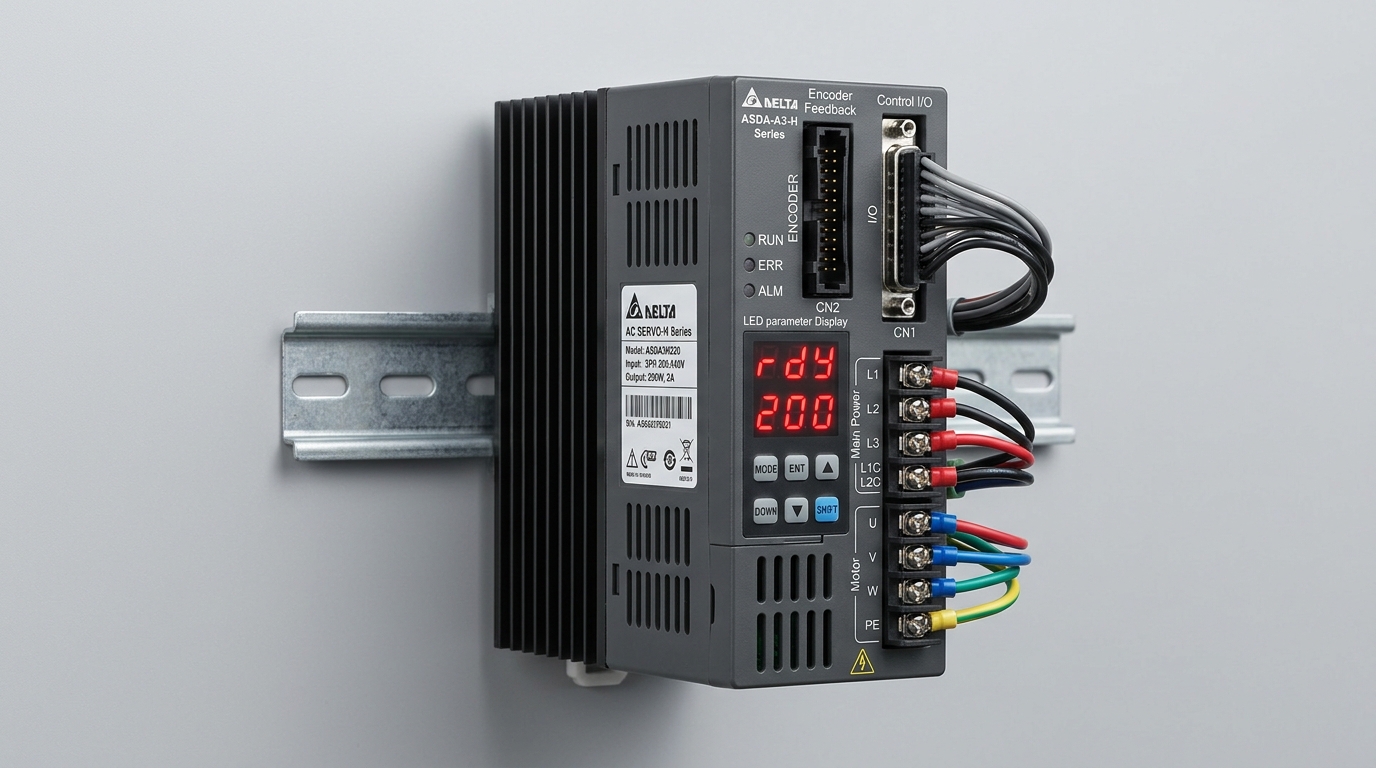
Compact multi-axis digital servo amplifier regulating current, velocity, and position loops.
Direct answers to common engineering questions regarding sizing verification, mechanical tolerances, fieldbus integration, and documentation for Pneumatic Interlocking Needle Gripper for Porous Media.
Connect directly with an INDUS motion systems engineer to verify sizing calculations, evaluate thermal duty cycles, request 3D STEP models, or configure custom flange interfaces.
• Official NDA protected technical evaluation
• 24 business hours standard proposal response
• Factory direct engineering support & CAD integration