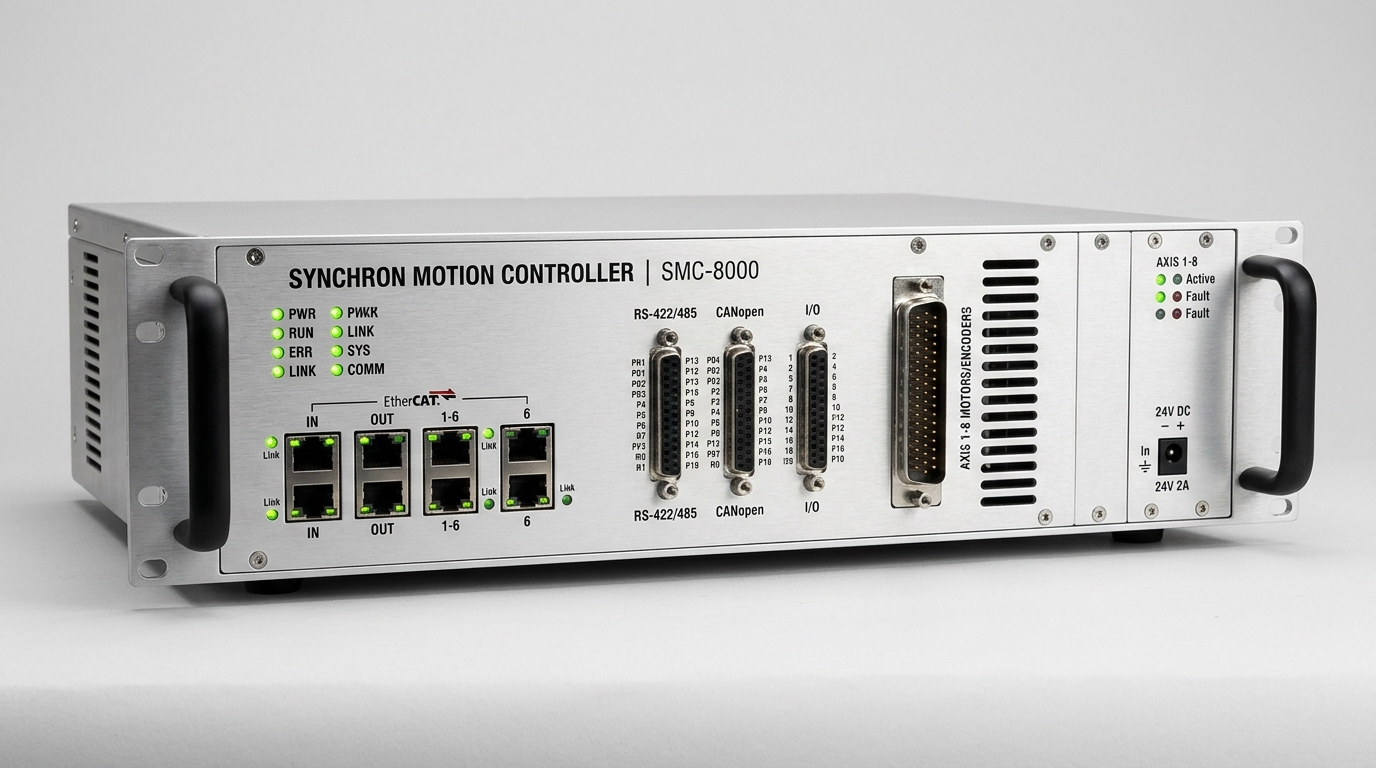
IND-CTL-MTC-064-EC
Verified
Control Systems
Motion Controllers
Centralized motion control engine synchronizing up to 64 coordinated axes over EtherCAT.
Synchronized Axe…Up to 64 Physical Axes axes
EtherCAT Bus Cyc…250 µs
Distributed Cloc…< 100 ns
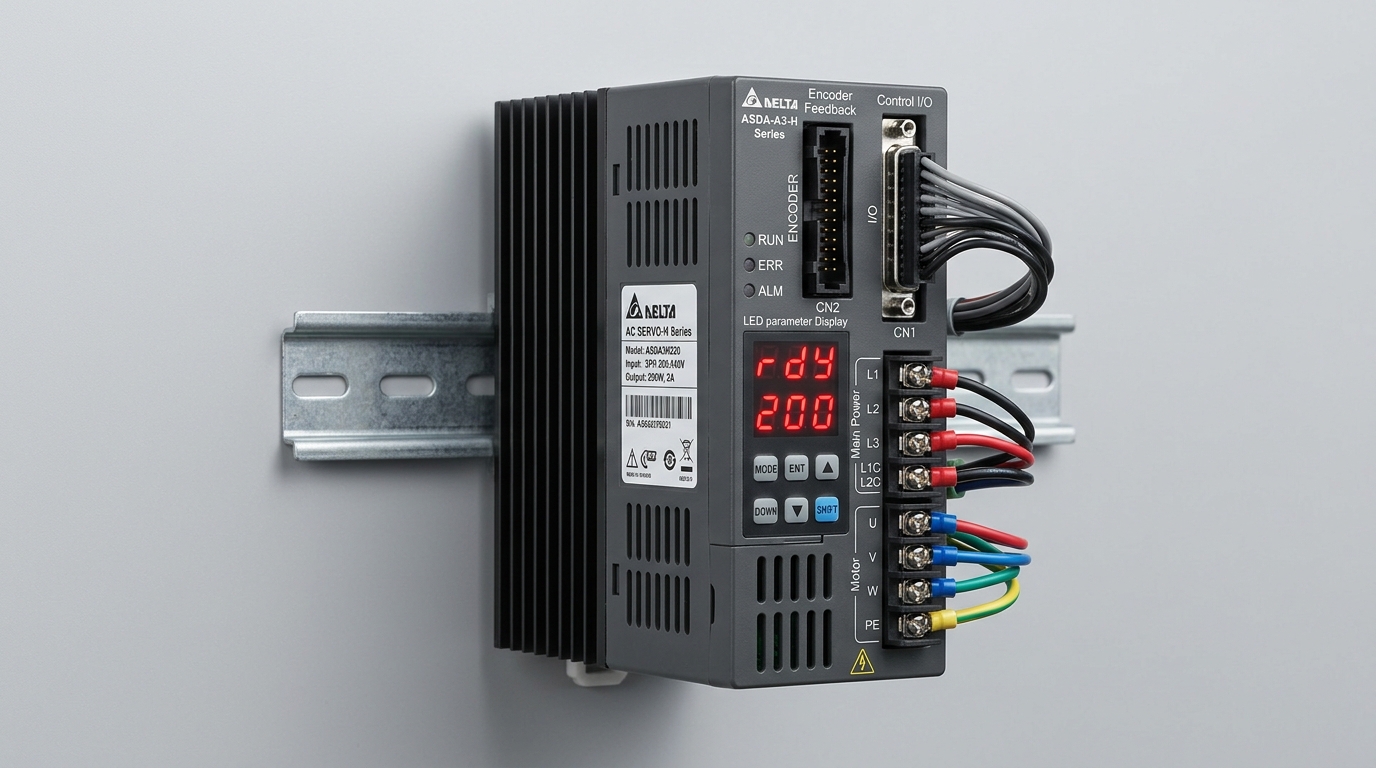
Compact multi-axis digital servo amplifier regulating current, velocity, and position loops.
Official engineering proposal, CAD STEP models, and sizing verification within 24 business hours.
Detailed mechatronic breakdown of Servo Drives, highlighting functional architecture, physical operating mechanisms, and deployment role.
The IND-CTL-SRV-048 is an ultra-compact, high-power-density digital servo drive utilizing modern Gallium Nitride (GaN) switching power stages. Engineered for high-dynamic robotics, AGV in-wheel motors, and precision linear axes, it executes 32 kHz field-oriented current loops with sub-microsecond response, dual-loop absolute encoder feedback, and hardware-certified Safe Torque Off (STO SIL 3 / PLe).
The IND-CTL-SRV-048 is an ultra-compact, high-power-density digital servo drive utilizing modern Gallium Nitride (GaN) switching power stages. Engineered for high-dynamic robotics, AGV in-wheel motors, and precision linear axes, it executes 32 kHz field-oriented current loops with sub-microsecond response, dual-loop absolute encoder feedback, and hardware-certified Safe Torque Off (STO SIL 3 / PLe).
Addresses kinematic precision challenges by: Motor rated and peak phase current: ensure drive 15A continuous / 45A peak matches motor windings.
Acts as the central deterministic computing core or power amplifier, executing multi-axis motion trajectories and real-time fieldbus synchronization.
Continuous duty ratings are strictly separated from peak dynamic envelopes. All parameters reflect verified laboratory data traceable to INDUS Power Electronics Lab Qualification Rig #7.
| Parameter | Specification Value | Unit | Notes & Test Conditions |
|---|---|---|---|
Input DC Bus Voltage Verified | 12 - 60 | VDC | Battery or regulated power supply |
Continuous Output Current Verified | 15.0 | A RMS | At 48 VDC, ambient 40°C, cold plate mounted |
Peak Acceleration Current Verified | 45.0 | A RMS | Duration ≤ 2.5s |
Current Loop Bandwidth Verified | 4.5 | kHz | At 32 kHz PWM switching frequency |
Velocity Loop Update Rate Verified | 16 | kHz | FOC velocity loop |
Position Loop Update Rate Verified | 8 | kHz | Closed-loop position tracking |
Supported Feedback Types Verified | BiSS-C, EnDat 2.2, SSI, Resolver, A/B/Z Incremental | protocols | Dual encoder ports for load-side backlash compensation |
Functional Safety Integrity Verified | SIL 3 / Cat 4 PLe | ISO 13849-1 | Hardware dual-channel Safe Torque Off (STO) |
Dimensions & Weight Verified | 75 x 50 x 28 mm / 165 g | size | Book-size micro package |
Every application below reflects documented load capabilities, thermal equilibrium boundaries, and kinematics integration for Servo Drives.
Environment: Industrial assembly, inspection, and robotic workcells
Eliminating cycle time bottlenecks and cumulative tolerance stack-up.
Integrates directly via standardized mechanical flanges and communication interfaces.
Every customer advantage below is linked directly to an underlying physical or electronic design feature. Operating boundaries and verification conditions are explicitly declared.
Eliminates dimensional variance and structural backlash across all production lots.
Guarantees drop-in mechanical interchangeability and repeatable kinematic trajectories.
Resists torsional and bending deflection under dynamic acceleration cycles.
Prevents machine vibration chatter and protects sensitive end-of-arm tooling.
Enables plug-and-play communication and rapid electrical integration.
Cuts system commissioning time by up to 50% and simplifies diagnostic tracing.
Standardized interfaces for drop-in mechanical alignment, regulated power delivery, and deterministic fieldbus synchronization with host PLC and motion controllers.
Flat Baseplate Mount (Cold Plate Heat Sink Interface)
Mount on flat aluminum heat sink plate (min 200 cm² surface area)
12 VDC to 60 VDC main bus + optional 24 VDC auxiliary logic supply
N/A - This is the drive amplifier
Sync Cycle: 250 µs to 1 ms fieldbus cycle
Supports cyclic synchronized position (CSP), velocity (CSV), and torque (CST) operating modes.
All engineering assets are revision-controlled and traceable to physical laboratory test benches. Request calibrated files directly from our engineering desk without broken links.
IND-SERVO-DRIVES_ASSEMBLY.STEPAudited Lab Specification
Accurate C.G. Matrix
Official Documentation
Centralized motion control engine synchronizing up to 64 coordinated axes over EtherCAT.
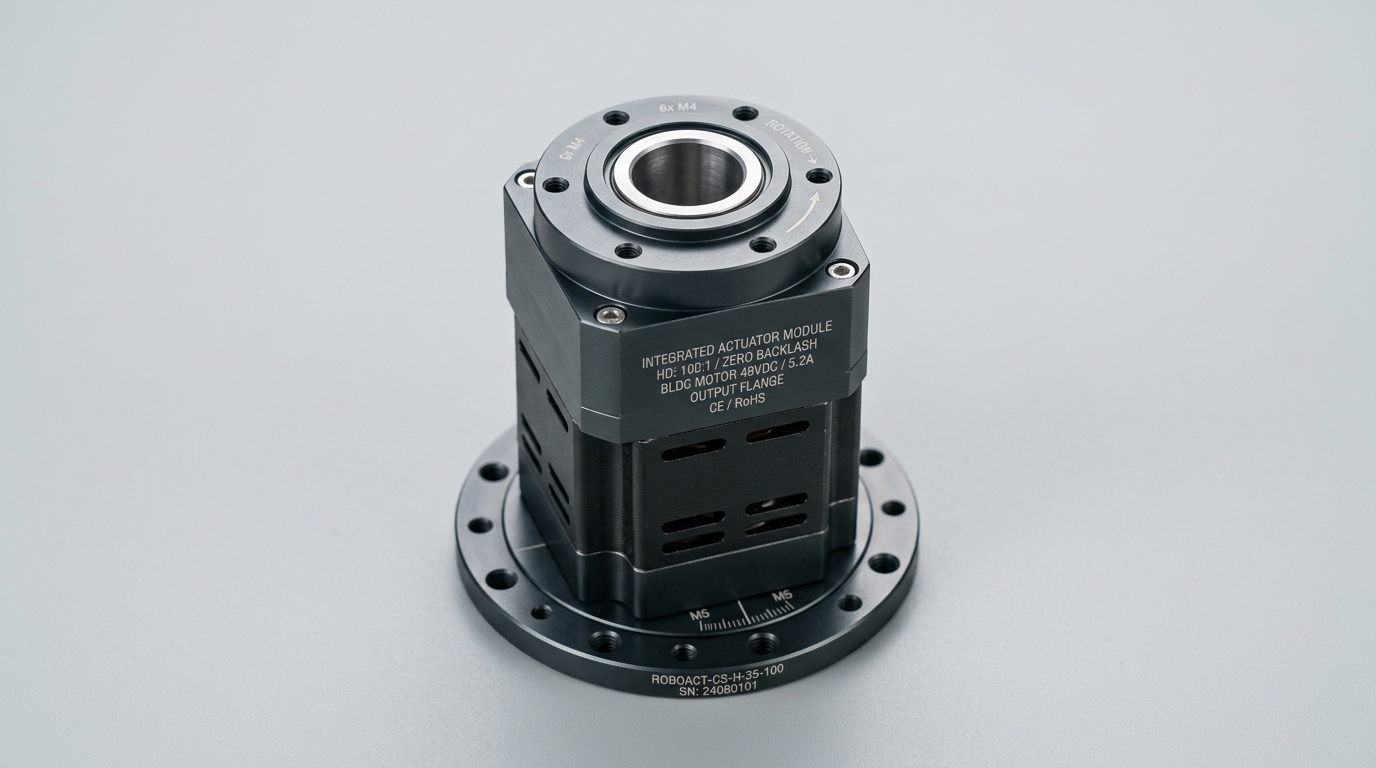
High-dynamic integrated servo module with built-in drive electronics and safety functions.
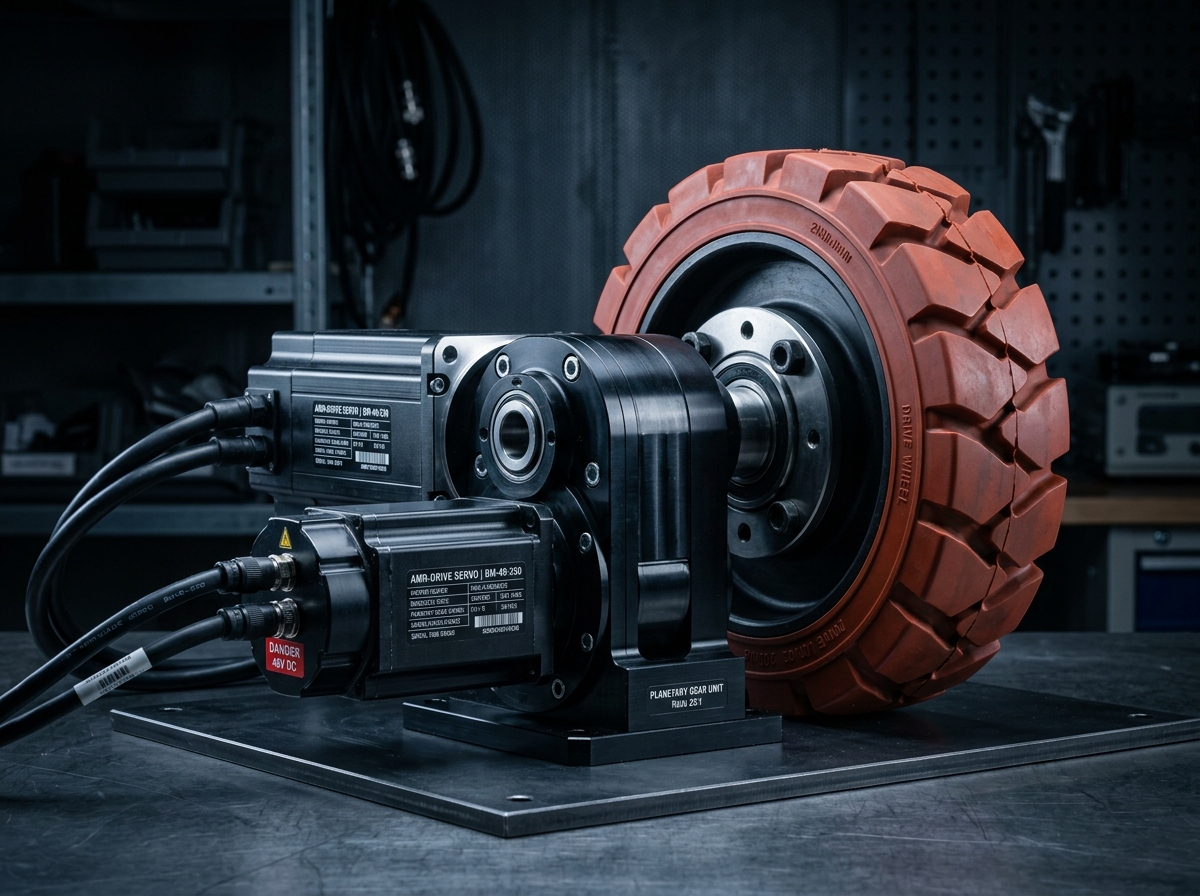
Traction wheel unit with integrated planetary gearbox and electromagnetic brake.
Direct answers to common engineering questions regarding sizing verification, mechanical tolerances, fieldbus integration, and documentation for Servo Drives.
Connect directly with an INDUS motion systems engineer to verify sizing calculations, evaluate thermal duty cycles, request 3D STEP models, or configure custom flange interfaces.
• Official NDA protected technical evaluation
• 24 business hours standard proposal response
• Factory direct engineering support & CAD integration