Intelligent Linear Actuator
Closed-loop guided linear displacement with embedded servo drive and absolute stroke feedback.

Precision motion, integrated feedback, and configurable control for robotic joints and automated machinery.
Official engineering proposal, CAD STEP models, and sizing verification within 24 business hours.
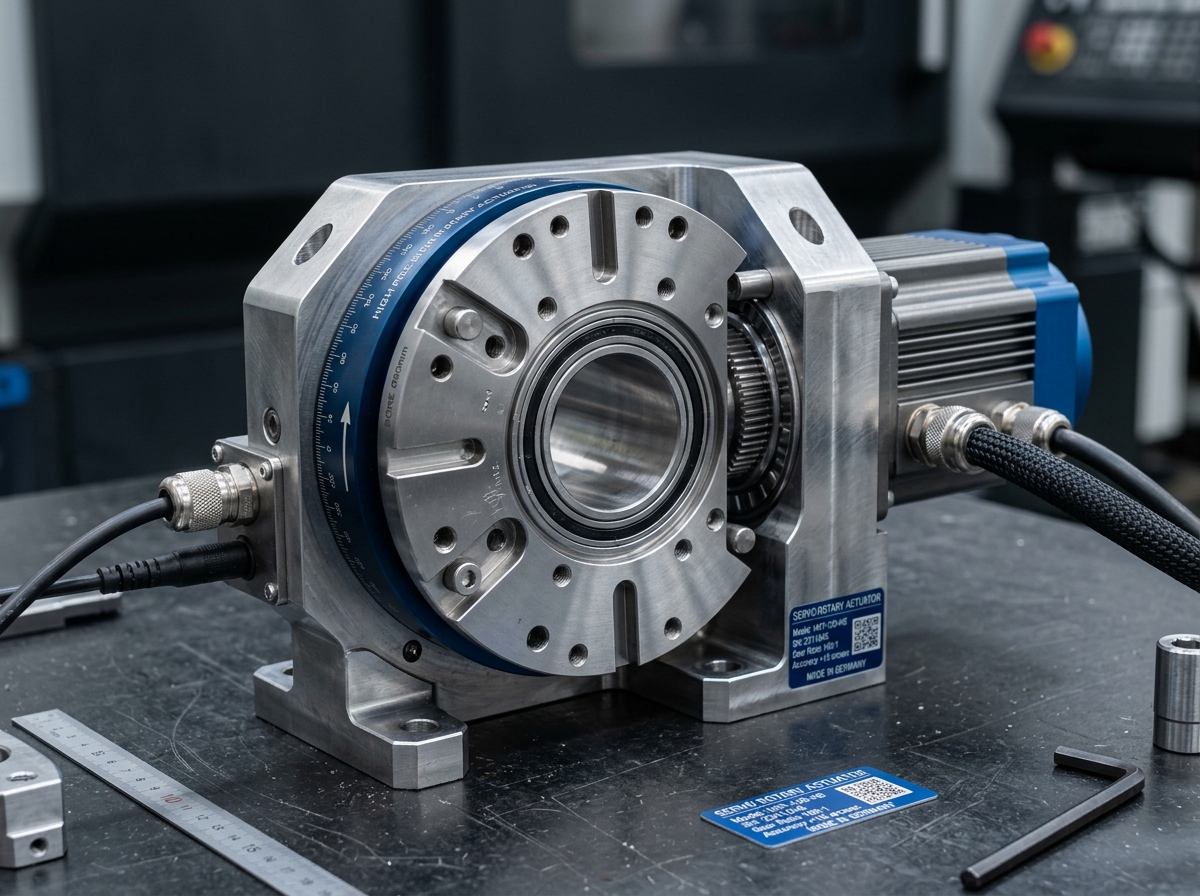
Detailed mechatronic breakdown of Intelligent Rotary Actuator, highlighting functional architecture, physical operating mechanisms, and deployment role.
The INDUS Intelligent Rotary Actuator (IND-IRA series) eliminates separate gearboxes, external servo drives, and lengthy motor cables by packaging a frameless permanent-magnet synchronous motor, a high-rigidity strain-wave gearhead, an embedded DSP motor drive, and dual absolute position encoders into an all-in-one rotary joint module. Built-in current and temperature monitoring enables real-time thermal protection and mechanical anomaly detection under 24/7 industrial duty.
The INDUS Intelligent Rotary Actuator combines a high-flux permanent-magnet synchronous motor, a zero-backlash strain-wave gearhead, dual 19-bit absolute position encoders, and an integrated 48V DC field-oriented servo drive into a single hermetically sealed IP65 joint. Real-time telemetry provides motor current, thermal tracking, and error diagnostics directly over EtherCAT or CANopen.
Addresses kinematic precision challenges by: Verify continuous RMS joint torque against thermal limit.
Serves as the high-precision torque-multiplication and motion-conversion core at robot joints, turntable positioners, and precision linear slides.
Packages brushless servomotor, zero-backlash harmonic reducer, dual absolute 19-bit optical encoders, and integrated 48V DC FOC drive into an IP65 mechatronic package.
10-pole neodymium rotor, low-cogging concentrated stator windings
High continuous power density with minimal thermal gradient
Torsional backlash < 1.0 arcmin, reduction ratios 50:1 to 160:1
Torque multiplication with near-zero lost motion for precise joint indexing
19-bit single-turn output side + 17-bit motor shaft side
Enables direct load position feedback and torsional wind-up compensation
Space-vector PWM, 20 kHz switching frequency, 15A continuous / 40A peak
Eliminates external cabinet drive space and EMI radiating cabling
Cascaded current (20 kHz), velocity (5 kHz), and position (1 kHz) loops
Deterministic motion tracking with dynamic anti-vibration notch filters
Calibrated winding thermistors and MOSFET temperature sensors with automatic derating
Prevents insulation breakdown and premature mechanical failure
EtherCAT (CoE) CiA 402 or CANopen DS402 with <1 ms jitter
Seamless cyclic synchronous position (CSP) integration with Beckhoff, Omron, and CODESYS controllers
24V DC failsafe electromagnetic brake with zero-power gravity holding
Prevents arm droop on emergency stop or primary power interruption
Real-time DSP drive vector telemetry, dual-encoder tracking error, and thermal equilibrium monitoring.
Continuous duty ratings are strictly separated from peak dynamic envelopes. All parameters reflect verified laboratory data traceable to INDUS Mechatronics Dynamic Bench ISO 230-2 Calibrated.
| Parameter | Specification Value | Unit | Notes & Test Conditions |
|---|---|---|---|
Rated Continuous Torque Continuous | 070: 35 · 090: 85 · 115: 175 · 142: 280 | Nm | At 25°C ambient, S1 continuous duty, motor winding ≤ 105°C |
Peak Acceleration Torque Peak | 070: 90 · 090: 210 · 115: 420 · 142: 700 | Nm | Duration ≤ 1.0 sec, duty factor ≤ 10% |
Rated Output Speed Continuous | 070: 45 · 090: 35 · 115: 30 · 142: 25 | rpm | At 48V DC nominal bus supply voltage |
Maximum Output Speed Peak | 070: 90 · 090: 70 · 115: 60 · 142: 50 | rpm | Intermittent duty at max inverter commutation frequency |
Positioning Repeatability Nominal | 070: ±15 · 090: ±12 · 115: ±10 · 142: ±10 | arcsec | ISO 230-2 bilateral repeatability on optical encoder bench |
Gearhead Backlash Nominal | 070: < 1.0 · 090: < 1.0 · 115: < 0.8 · 142: < 0.8 | arcmin | At ±3% of rated torque applied to output shaft |
Nominal DC Bus Voltage Nominal | 070: 48 · 090: 48 · 115: 48 · 142: 48 | V DC | Permissible range 24V to 56V DC |
Rated Continuous Current Continuous | 070: 6.5 · 090: 11.0 · 115: 18.5 · 142: 26.0 | A rms | Sine-wave vector commutation at 20 kHz PWM |
Allowable Radial Load (Fr) Envelope | 070: 1800 · 090: 3200 · 115: 5400 · 142: 8200 | N | Applied at midpoint of output flange, L10h bearing life ≥ 20,000h |
Allowable Axial Load (Fa) Envelope | 070: 1400 · 090: 2600 · 115: 4500 · 142: 6800 | N | Static axial thrust limit |
Ingress Protection (IP) Nominal | 070: IP65 · 090: IP65 · 115: IP65 · 142: IP65 | Rating | IEC 60529 dust tight and protected against water jets |
Maximum Commutation Speed Verified | 50 – 90 | rpm | Intermittent duty at max inverter frequency |
Mechanical Gear Backlash Verified | < 1.0 | arcmin | At ±3% rated torque applied to output shaft |
Operating DC Bus Voltage Verified | 48 | V DC | Continuous regulated DC supply |
Ingress Protection Rating Verified | IP65 | Rating | Sealed connector configuration |
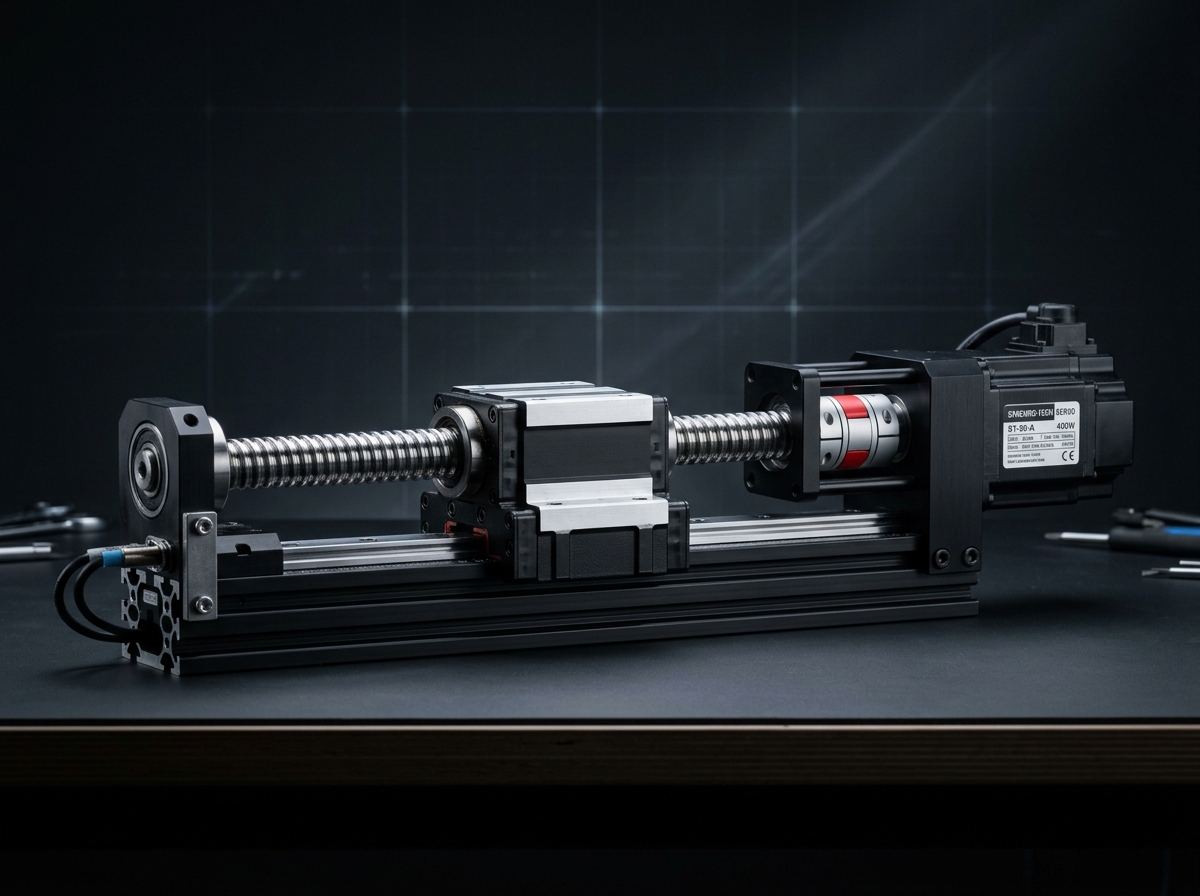
Select a verified physical variant below to inspect continuous ratings, peak torque/force envelopes, and dimension comparisons.
Every application below reflects documented load capabilities, thermal equilibrium boundaries, and kinematics integration for Intelligent Rotary Actuator.
Environment: Automated Electronics Assembly & Screwdriving Workcell (Clean indoor shopfloor, 15°C to 30°C).
Excessive joint backlash, heavy distal arm inertia, and multi-conductor wire routing bottlenecks inside articulating collaborative robot arms.
Combines frameless brushless motor, zero-backlash harmonic drive, dual 19-bit absolute encoders, and DSP servo drive into a compact hollow-shaft joint module with deterministic 1ms EtherCAT CSP control.
Environment: Metal Cutting & Machining Center (Oil mist, metal chips, ambient vibrations, IP65 enclosure).
Backlash wear, station indexing delays, and machining chatter on worm-gear CNC tool changers.
Direct-drive harmonic gearing provides zero-backlash torque transmission with high torsional rigidity, enabling rapid 90° indexing in under 180 ms.
Environment: High-Speed Pharmaceutical Bottling Line (Cleanroom Grade B / washdown fringe, 18°C to 25°C).
Thermal drift, rotational jitter, and encoder synchronization lag causing blurred barcode and defect detection on high-speed bottling carousels.
Low-cogging permanent-magnet rotor paired with 19-bit optical encoder delivers ultra-smooth sub-rpm velocity stability and zero-jitter camera trigger synchronization.
Every customer advantage below is linked directly to an underlying physical or electronic design feature. Operating boundaries and verification conditions are explicitly declared.
Directly measures gearhead output deflection and dynamic torsional wind-up under varying payload.
Maintains ±10 arcsec positional repeatability, preventing cumulative kinematic drift and reducing scrap in precision assembly.
Eliminates gear teeth clearance and reversal deadband during high-speed directional changes.
Enables smooth micro-stepping and vibration-free motion tracking during continuous contouring and dispensing paths.
Eliminates long motor power and feedback wiring, executing 20 kHz current loops directly adjacent to motor windings.
Shrinks machine electrical cabinet footprint by 80%, cuts cabling harness mass by 70%, and minimizes electromagnetic interference (EMI).
Continuously monitors winding thermistors and MOSFET temperatures, applying graceful algorithmic current derating.
Prevents catastrophic motor burnout and unexpected mid-shift shutdowns during hot summer production runs.
Yields high continuous torque-to-weight ratio (up to 25.9 Nm/kg) with minimal rotor inertia.
Allows higher joint acceleration without motor overheating, directly shortening cycle time in pick-and-place tasks.
Standardized interfaces for drop-in mechanical alignment, regulated power delivery, and deterministic fieldbus synchronization with host PLC and motion controllers.
ISO 9409-1 Robot Tool Flange Compatible
Any mounting orientation (horizontal, vertical, inverted). Gravity holding brake optional.
48V DC nominal (allowable 24V – 56V DC)
Integrated on-board field-oriented vector controller
Sync Cycle: < 1.0 ms deterministic sync
Supports cyclic synchronized position (CSP), velocity (CSV), and torque (CST) operating modes.
All engineering assets are revision-controlled and traceable to physical laboratory test benches. Request calibrated files directly from our engineering desk without broken links.
IND-IRA-SERIES_ASSEMBLY.STEPAudited Lab Specification
Accurate C.G. Matrix
Official Documentation
Direct answers to common engineering questions regarding sizing verification, mechanical tolerances, fieldbus integration, and documentation for Intelligent Rotary Actuator.
Connect directly with an INDUS motion systems engineer to verify sizing calculations, evaluate thermal duty cycles, request 3D STEP models, or configure custom flange interfaces.
• Official NDA protected technical evaluation
• 24 business hours standard proposal response
• Factory direct engineering support & CAD integration