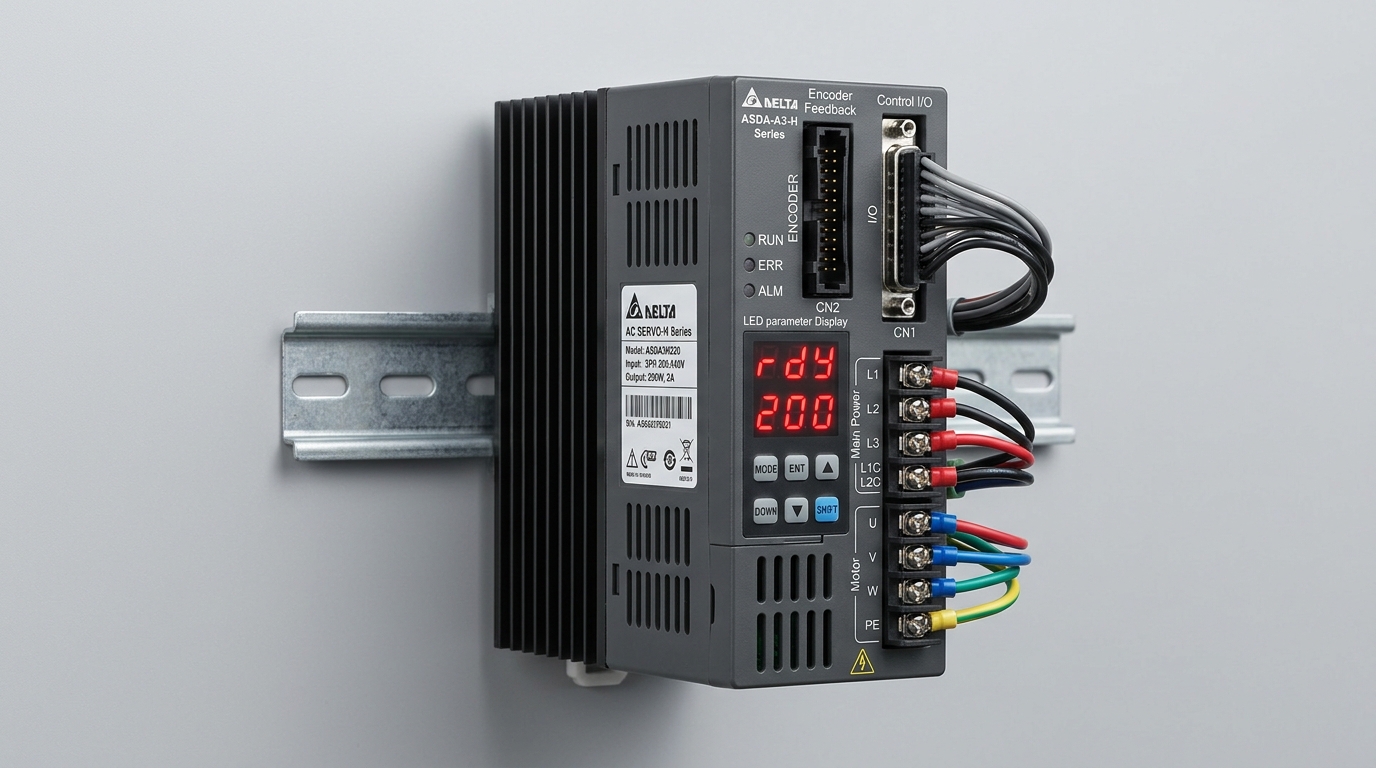
IND-CTL-SRV-048-GN
Verified
Control Systems
Servo Drives
Compact multi-axis digital servo amplifier regulating current, velocity, and position loops.
Input DC Bus Vol…12 - 60 VDC
Continuous Outpu…15.0 A RMS
Peak Acceleratio…45.0 A RMS
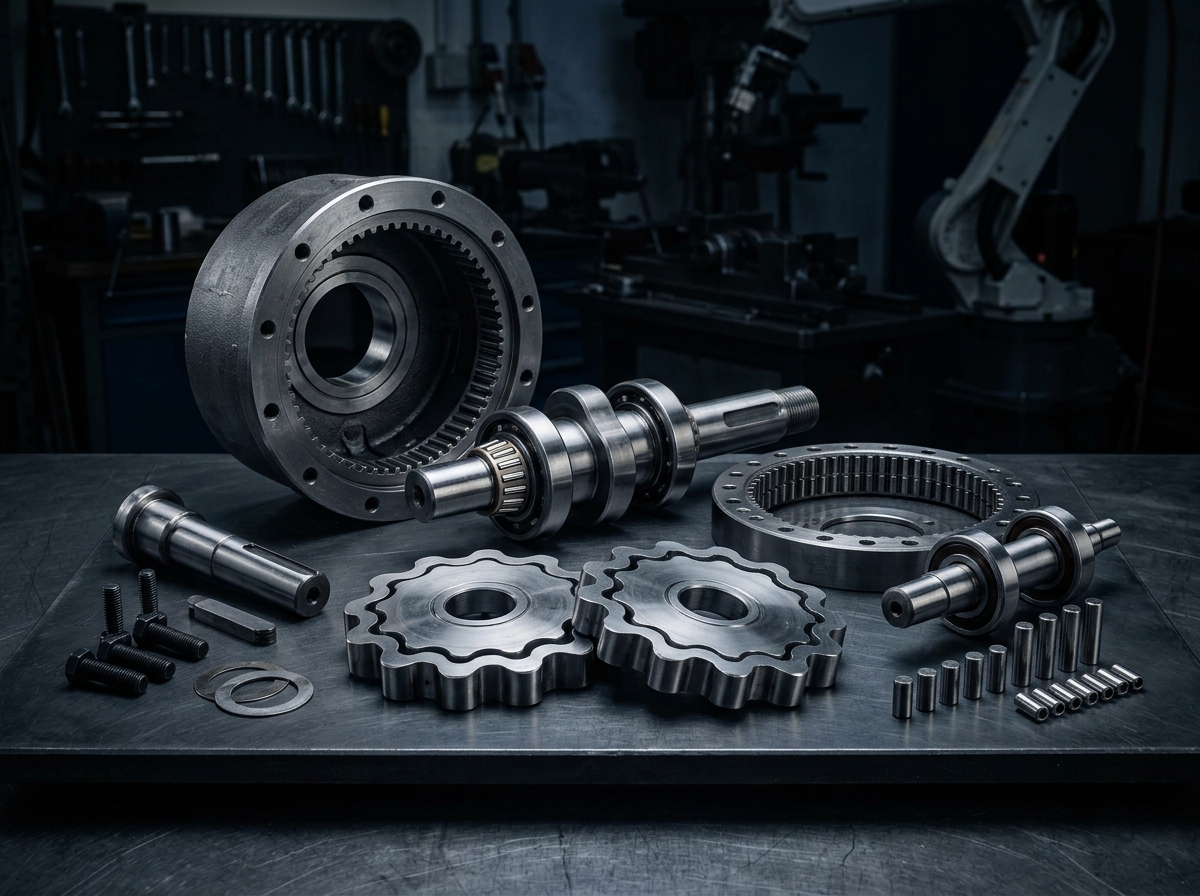
Stable inertia matching against high mechanical load ratios on machine tool feed axes and industrial robot arms.
Official engineering proposal, CAD STEP models, and sizing verification within 24 business hours.
Detailed mechatronic breakdown of Medium-Inertia High-Torque Servomotor, highlighting functional architecture, physical operating mechanisms, and deployment role.
Stable inertia matching against high mechanical load ratios on machine tool feed axes and industrial robot arms.
Distributed winding PMSM delivering smooth torque output with thermal time constant over 45 minutes.
Eliminates operational failure modes related to: Load-to-rotor inertia ratio (<5:1), Continuous thermal rating.
Serves as the high-precision torque-multiplication and motion-conversion core at robot joints, turntable positioners, and precision linear slides.
Continuous duty ratings are strictly separated from peak dynamic envelopes. All parameters reflect verified laboratory data traceable to IEC 60034 / UL 1004 / ISO 13849.
| Parameter | Specification Value | Unit | Notes & Test Conditions |
|---|---|---|---|
Rated Power Verified | 1.5kW - 15kW | kW | Audited per DIN EN 60034-2-1 Motor Efficiency Benchmarking |
Rated Speed Verified | 2,000 - 3,000 RPM | rpm | Audited per DIN EN 60034-2-1 Motor Efficiency Benchmarking |
Peak Torque Verified | 14 - 180 Nm | Nm | Audited per DIN EN 60034-2-1 Motor Efficiency Benchmarking |
Inertia Verified | 4.2 - 68 kg·cm² | kg | Audited per DIN EN 60034-2-1 Motor Efficiency Benchmarking |
System Interface Compatibility Standard | 400V 3-phase AC drives; Resolver and optical feedback | Standard | Supported physical and electronic mating connections |
Select a verified physical variant below to inspect continuous ratings, peak torque/force envelopes, and dimension comparisons.
Every application below reflects documented load capabilities, thermal equilibrium boundaries, and kinematics integration for Medium-Inertia High-Torque Servomotor.
Environment: Automated production facilities and manufacturing cells
Demanding precision positioning and repeatability requirements under high-duty continuous operation.
Provides calibrated Medium-Inertia High-Torque Servomotor performance adhering strictly to IEC 60034 / UL 1004 / ISO 13849.
Environment: Automated production facilities and manufacturing cells
Demanding precision positioning and repeatability requirements under high-duty continuous operation.
Provides calibrated Medium-Inertia High-Torque Servomotor performance adhering strictly to IEC 60034 / UL 1004 / ISO 13849.
Environment: Automated production facilities and manufacturing cells
Demanding precision positioning and repeatability requirements under high-duty continuous operation.
Provides calibrated Medium-Inertia High-Torque Servomotor performance adhering strictly to IEC 60034 / UL 1004 / ISO 13849.
Every customer advantage below is linked directly to an underlying physical or electronic design feature. Operating boundaries and verification conditions are explicitly declared.
Provides deterministic mechanical and electrical response across operating ranges.
Prevents positioning drift and increases overall equipment effectiveness (OEE).
Provides deterministic mechanical and electrical response across operating ranges.
Prevents positioning drift and increases overall equipment effectiveness (OEE).
Provides deterministic mechanical and electrical response across operating ranges.
Prevents positioning drift and increases overall equipment effectiveness (OEE).
Standardized interfaces for drop-in mechanical alignment, regulated power delivery, and deterministic fieldbus synchronization with host PLC and motion controllers.
400V 3-phase AC drives
Universal mounting in horizontal, vertical, or inverted orientations with precision dowel hole alignment.
48V DC Regulated Bus (24V–56V range)
Integrated field-oriented control or compatible with standard industrial AC/DC servo inverters.
Cycle Time ≤ 1.0 ms (Jitter < 1 µs)
Supports cyclic synchronized position (CSP), velocity (CSV), and torque (CST) operating modes.
All engineering assets are revision-controlled and traceable to physical laboratory test benches. Request calibrated files directly from our engineering desk without broken links.
IND-MOT-PMSM-MED-INERTIA_ASSEMBLY.STEPAudited Lab Specification
Accurate C.G. Matrix
Official Documentation
Compact multi-axis digital servo amplifier regulating current, velocity, and position loops.
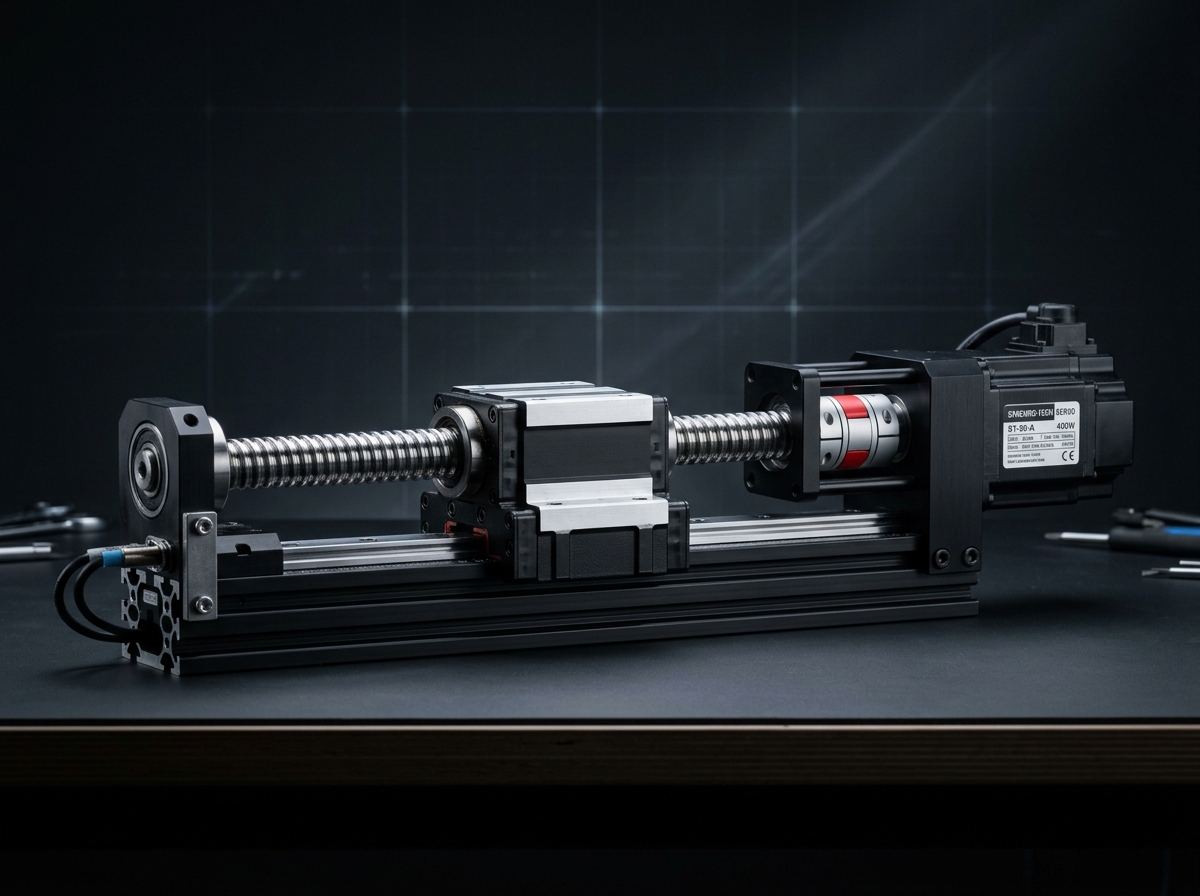
Precision guided linear motion module for controlled travel and repeatable positioning.
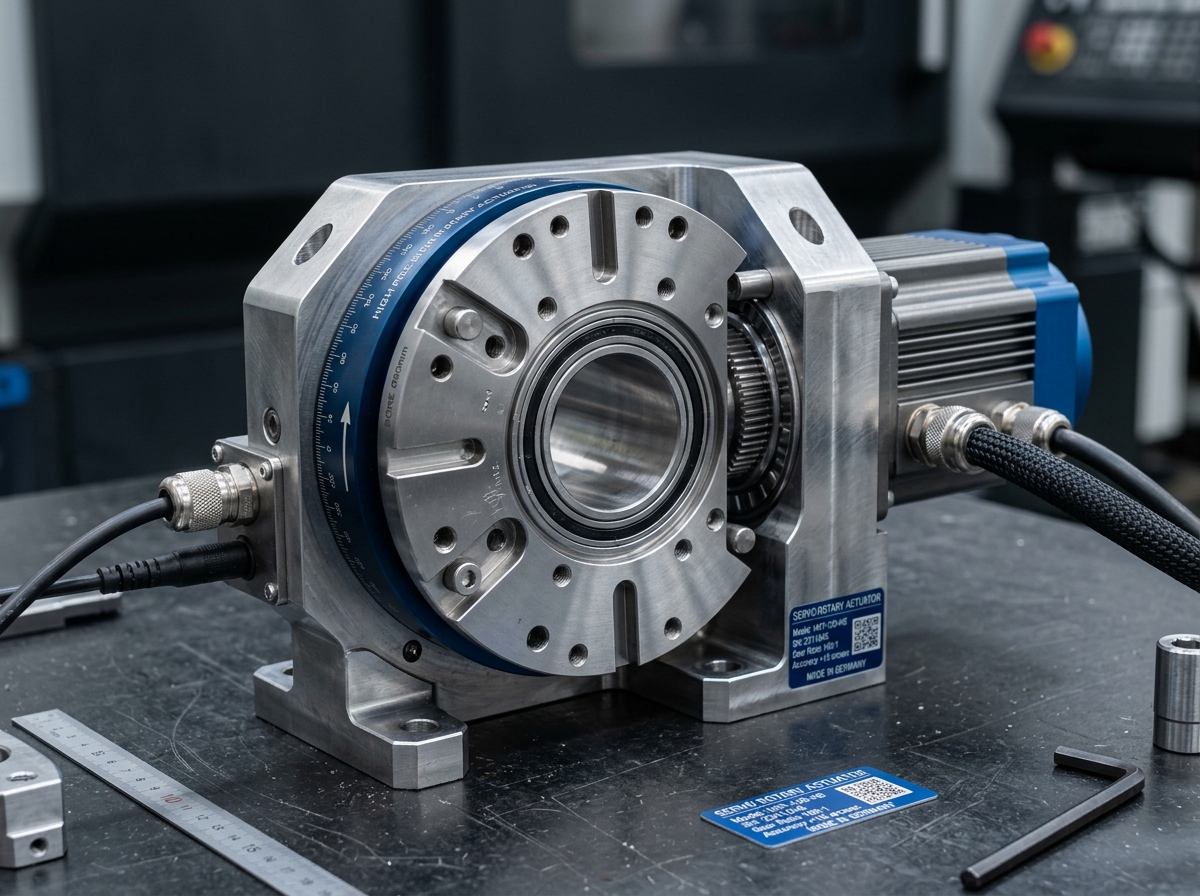
High-torque rotary actuation module with zero-backlash gearing for joint articulation.
Direct answers to common engineering questions regarding sizing verification, mechanical tolerances, fieldbus integration, and documentation for Medium-Inertia High-Torque Servomotor.
Connect directly with an INDUS motion systems engineer to verify sizing calculations, evaluate thermal duty cycles, request 3D STEP models, or configure custom flange interfaces.
• Official NDA protected technical evaluation
• 24 business hours standard proposal response
• Factory direct engineering support & CAD integration