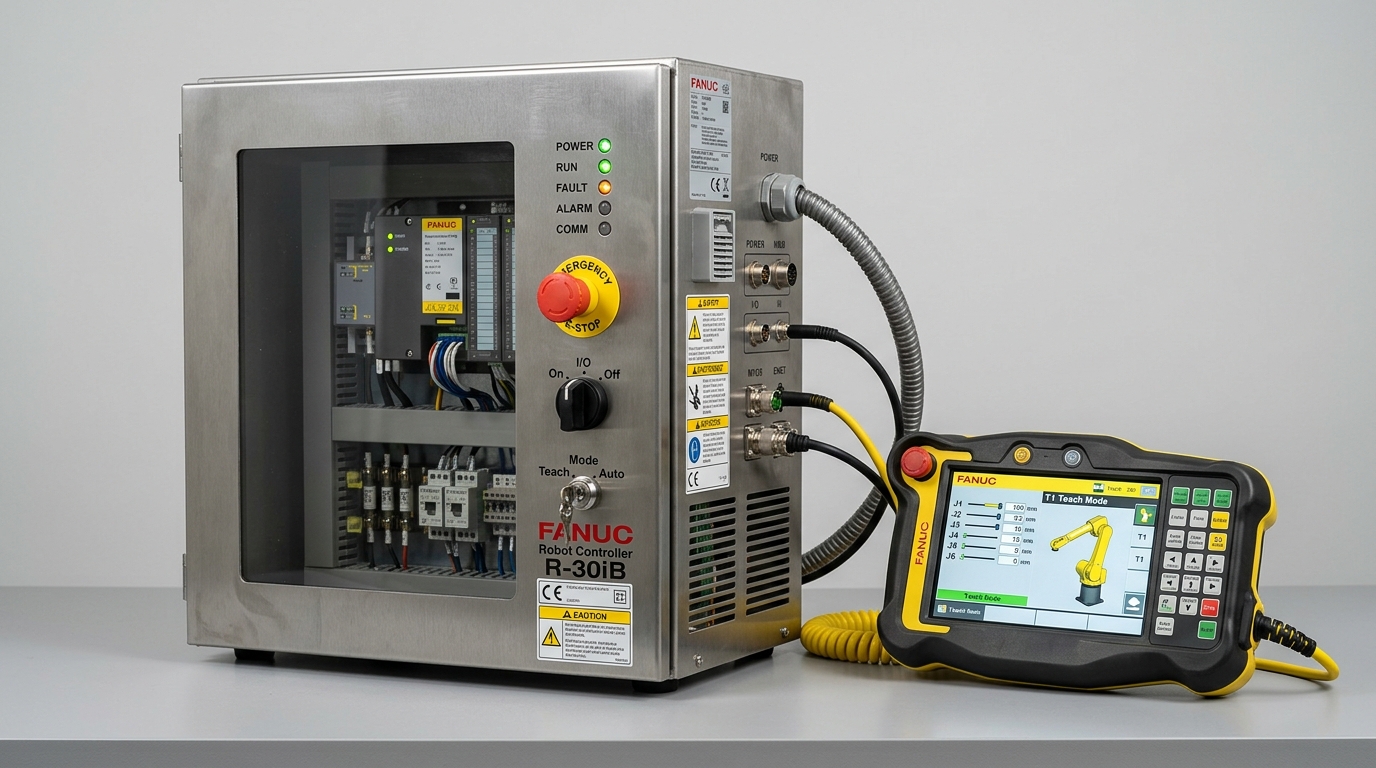
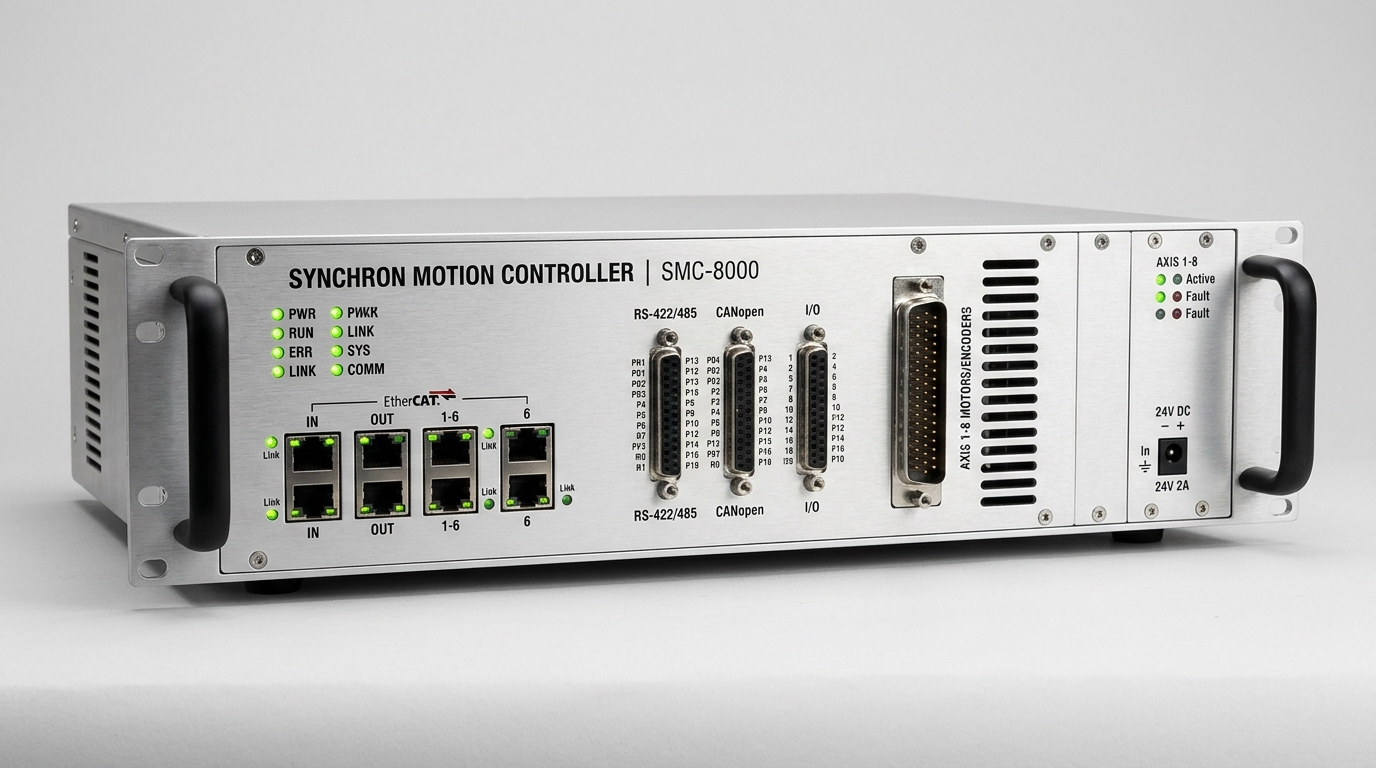
High-Performance Industrial PC (IPC) Robot Controller
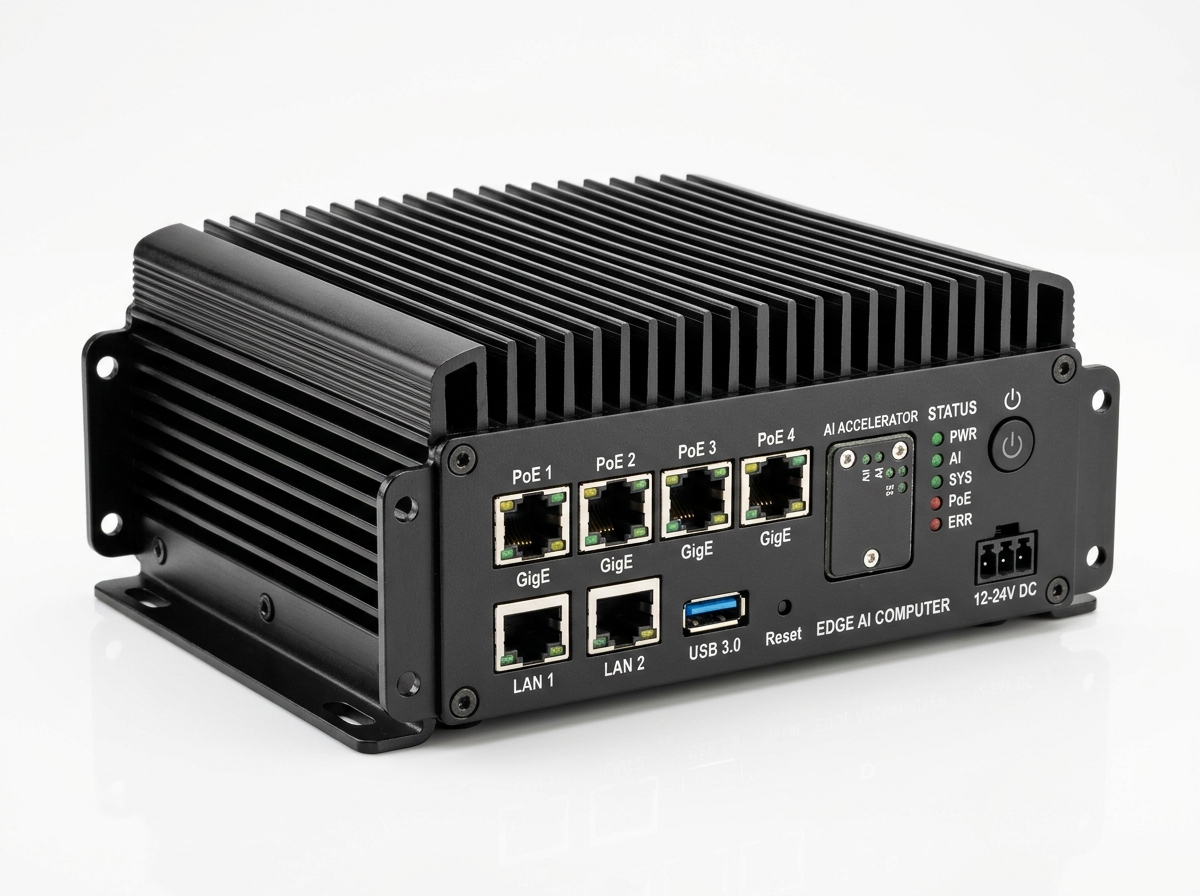
Central real-time kinematic coordination and high-level edge telemetry computation inside a fanless industrial chassis.
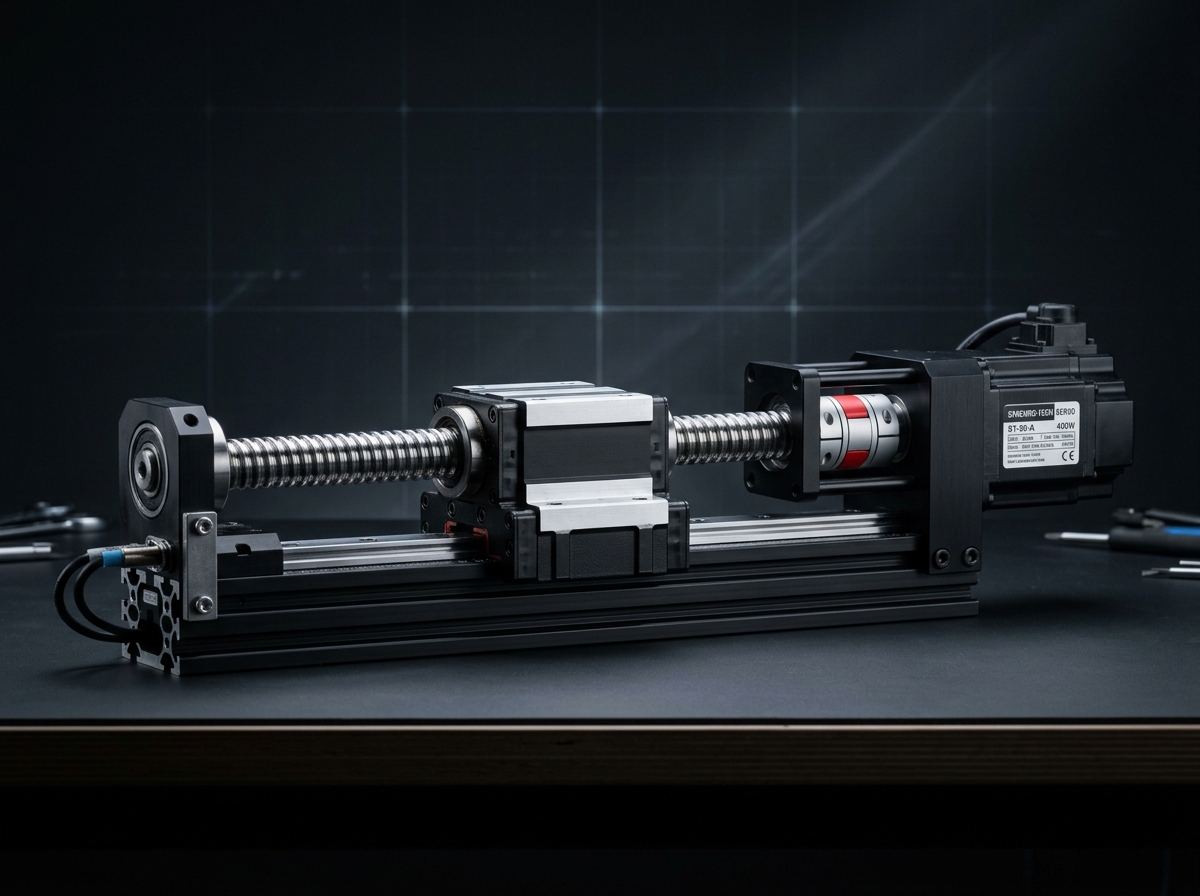
Deterministic motion controllers, real-time industrial PCs, robot teach pendants, and multi-axis kinematic interpolators.
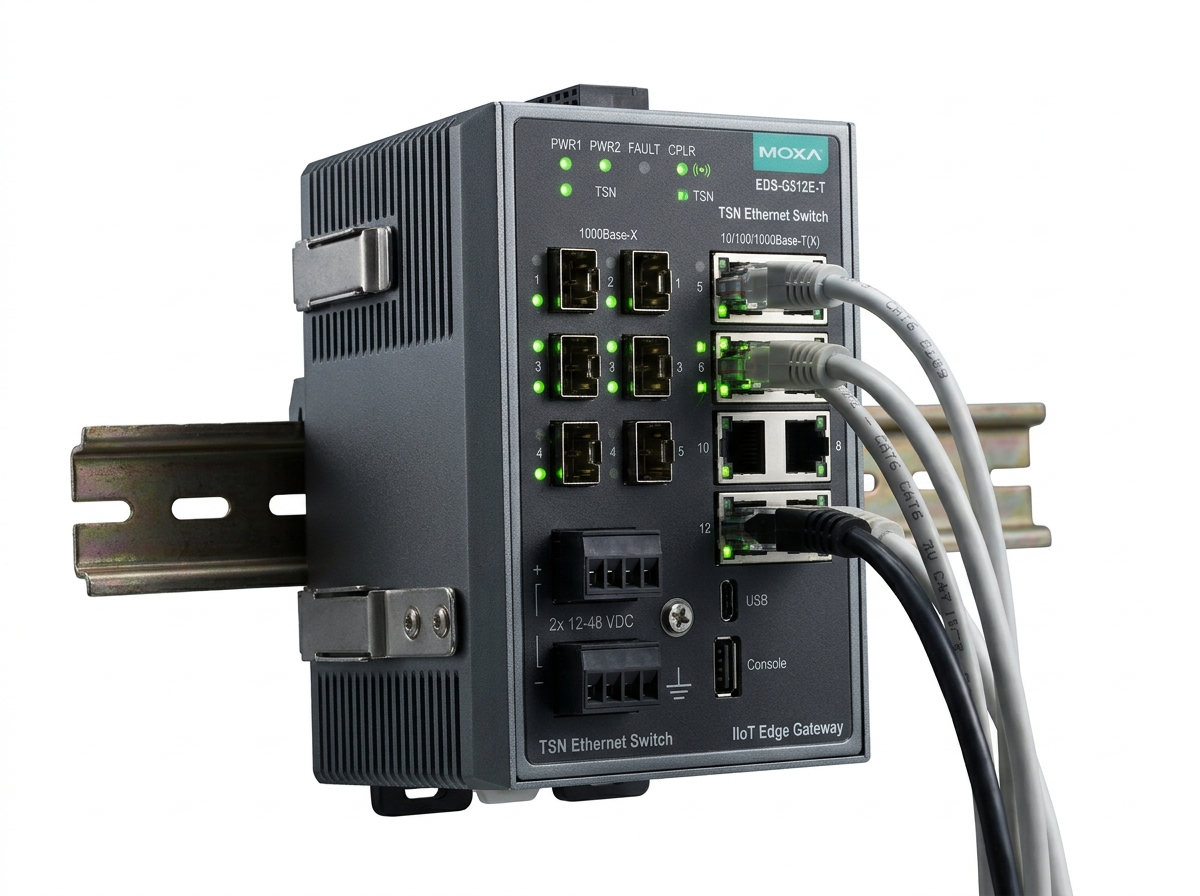
Motion controllers calculate 6-DOF kinematics, trajectory profiles, electronic gearing, and real-time fieldbus synchronization down to sub-microsecond jitter.


Central real-time kinematic coordination and high-level edge telemetry computation inside a fanless industrial chassis.

Synchronizes up to 64 physical servo axes with complex electronic camming, flying shears, and robot kinematics.

Complete plug-and-play controller cabinet including multi-axis inverter drives, safety PLC, and 10-inch color touchscreen pendant.

Allows academic robotics researchers and AI startups to run custom joint torque, impedance, and reinforcement learning policies.

Dynamic trajectory generation and circular conveyor belt tracking for pick-and-place robots at up to 200 picks/minute.

Combines standard ISO 6983 G-code toolpath execution with high-speed electronic camming and rotary table interpolation.

Onboard vehicle autonomy computer combining 3D SLAM, obstacle dynamic avoidance, and warehouse traffic orchestration.

Compact, low-cost motion control for automated laboratory instruments, medical pipetters, and semiconductor benchtop tools.

Coordinates up to 4 robots sharing a single geometric workspace without collisions and with synchronized part handover.

Executes 100 kHz position loop setpoint interpolation and laser pulse firing with sub-nanosecond pulse jitter.

Combines ladder logic, structured text, and multi-axis motion in a single unified deterministic runtime environment.

Protects sensitive drive electronics and controllers against extreme ambient heat (50°C), conductive graphite dust, and water jets.

Performs continuous dynamic visual servoing, updating robot trajectory in real time based on moving camera feedback.

Reflects tool contact forces back to a remote surgeon or operator with sub-10 ms latency and transparent haptic fidelity.

Drives piezoelectric stages with sub-nanometer position stability and active feedforward compensation for mechanical resonances.

Connects real robot controller hardware directly to physics simulation engines (NVIDIA Omniverse, Siemens Process Simulate) before physical building.

Zero-downtime hot-standby motion control for critical continuous chemical reactors, glass float lines, and semiconductor fab utilities.

Combines 275 TOPS of AI deep learning inference with microsecond-level deterministic robot joint trajectory control in one box.

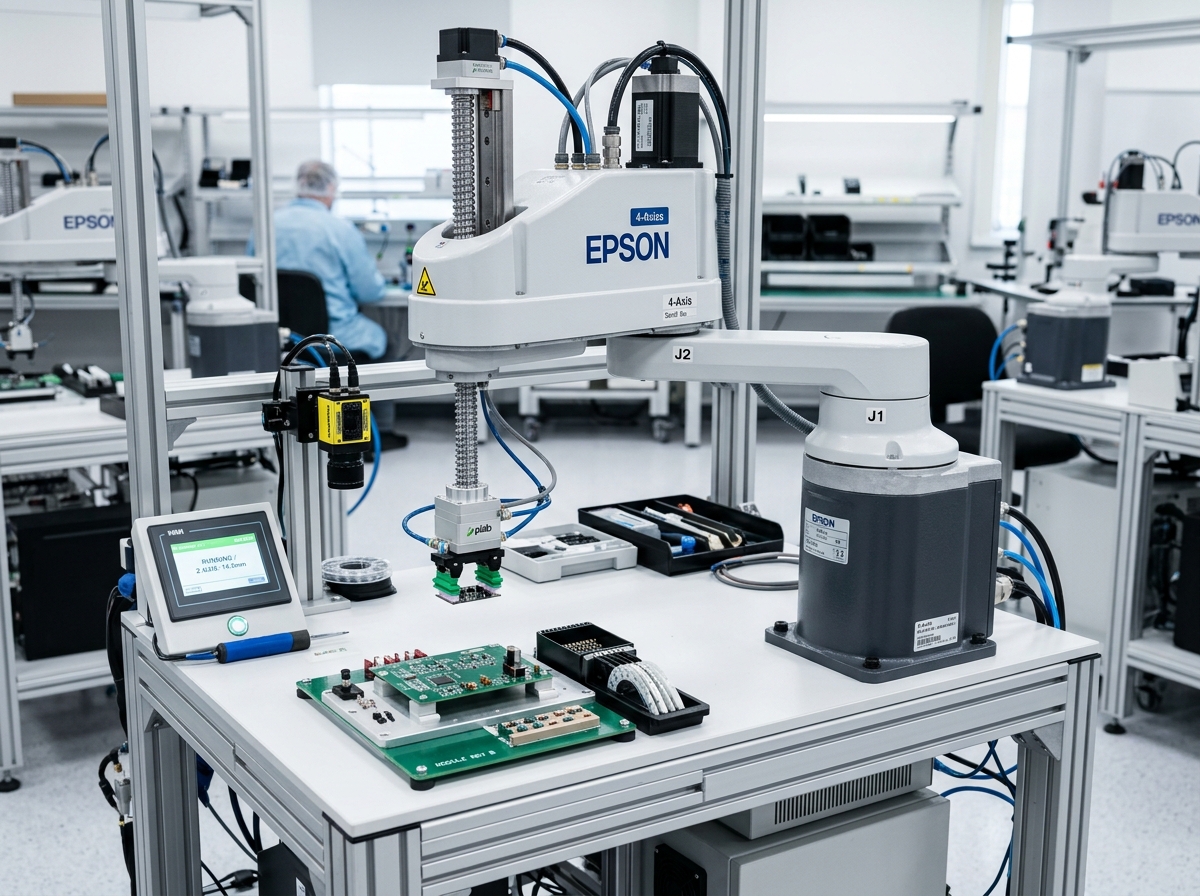
Dedicated low-cost, high-speed 4-axis motion controller optimized specifically for SCARA pick-and-place arms.

Precision position and pressure/force control for heavy hydraulic cylinders on forging presses and die-casting machines.
Specifying the appropriate robotic drivetrain and automation hardware requires a holistic evaluation of mechanical stiffness, duty cycle thermals, reflected inertia, and fieldbus communication latency.
Validated manufacturing tasks where Robot Controllers and Motion Control delivers proven precision and uptime.
Automotive Powertrain & EV Battery Assembly
Production VerifiedSemiconductor Wafer Transfer & Cleanroom Metrology
Production VerifiedCNC High-Speed Milling & Robotic Machine Tending
Production VerifiedAutomated Packaging, Sortation & Case Palletizing
Production VerifiedAerospace Composite Drilling & Rivet Inspection
Production VerifiedMedical Device Precision Micromanipulation
Production VerifiedInteroperable motion components and engineering sizing utilities.
Our application engineers can verify inertia ratios, motor torque curves, duty cycle thermals, and fieldbus synchronization parameters for your machinery before purchase.