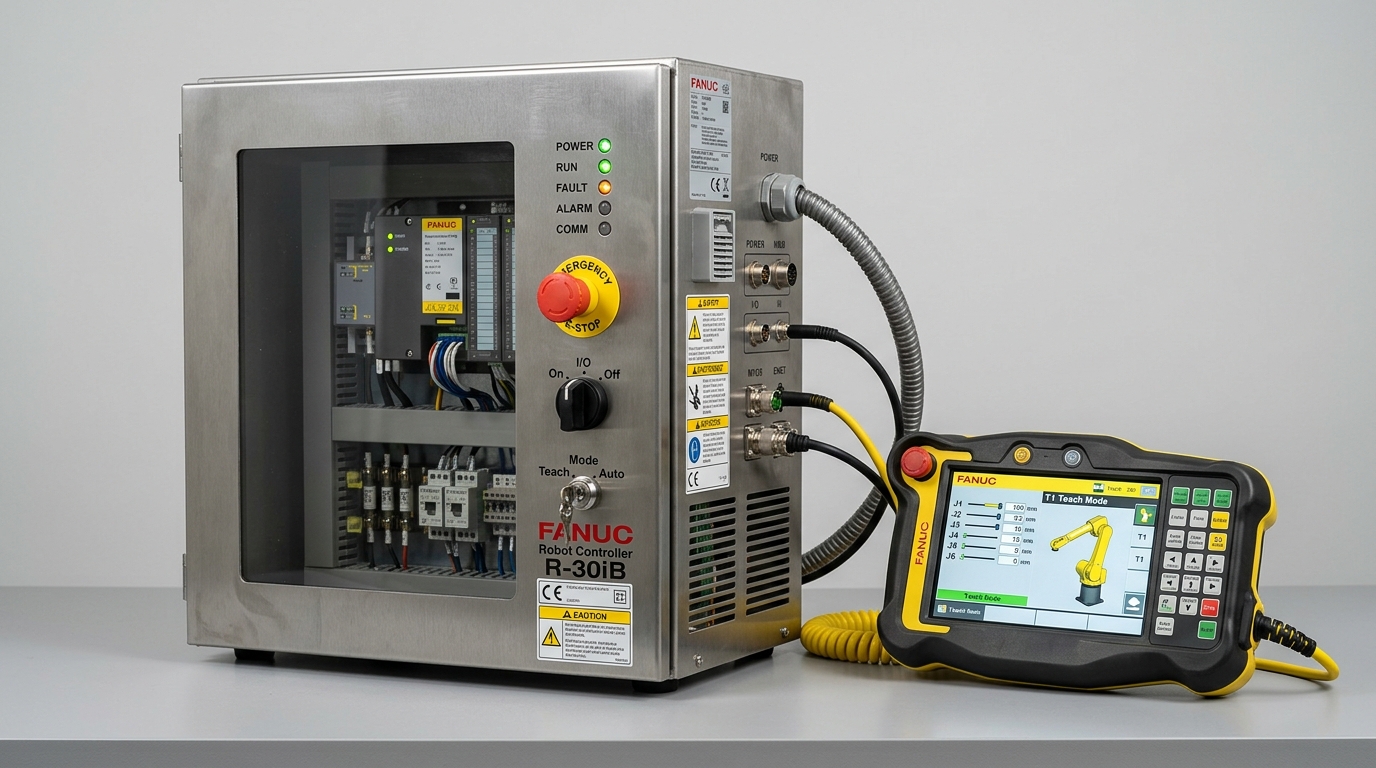
IND-CTL-RBC-X86-RT
Verified
Control Systems
Robot Controllers
Industrial-grade controller computing forward/inverse kinematics with integrated functional safety.
Coordinated Axis…Up to 16 Axes axes
Trajectory Inter…1.0 ms
EtherCAT Master …< 1.0 µs
Allows an operator to safely jog a robot inside its fence envelope; panic-squeeze or release immediately stops robot motion.
Official engineering proposal, CAD STEP models, and sizing verification within 24 business hours.
Detailed mechatronic breakdown of 3-Position Ergonomic Enabling Teach Pendant Switch, highlighting functional architecture, physical operating mechanisms, and deployment role.
Allows an operator to safely jog a robot inside its fence envelope; panic-squeeze or release immediately stops robot motion.
Ergonomic 3-position switch: Position 1 (Released = Off), Position 2 (Gently Pressed = Robot Enabled), Position 3 (Panicked Squeeze = Off).
Eliminates operational failure modes related to: IEC 60947-5-8 3-position enabling compliance, Dual redundant contact circuits.
Executes high-speed multi-axis kinematic manipulation, assembly, welding, or material handling tasks within structured automated cells.
Redundant dual-channel optical, mechanical, or electromechanical sensing with fail-safe cross-monitoring adhering to ISO 13849-1 Cat 4 / PLe. Assigned to Emergency Stop Circuitry, Cell Safeguarding & Safe Motion Supervision.
Safety laser scanner, light curtain, or RFID interlock detects human operator breaching the designated warning or protective cell boundary.
Safety PLC or safety relay evaluates dual inputs, testing for contact weld, wire short-circuits, and discrepancy time limits (< 100 ms).
Servo drives ramp robot to zero speed under active Safe Stop 1 (SS1), followed by mechanical brake drop and Safe Torque Off (STO) power cut.
100% passive mechanical containment with zero software complexity, but consumes large factory floor footprint and prevents collaborative operator loading.
Low cost for general part detection, but illegal and life-threatening to deploy for personnel safety because single component failures can leave hazardous motion active.
Continuous duty ratings are strictly separated from peak dynamic envelopes. All parameters reflect verified laboratory data traceable to ISO 13849-1 / ISO 13849-2 · IEC 62061 · ISO 10218-1/2 (Industrial Robots) · ISO/TS 15066 (Cobots).
| Parameter | Specification Value | Unit | Notes & Test Conditions |
|---|---|---|---|
Positions Verified | 3 Positions (Off - Enable - Off upon panic) | — | Audited per Enabling Devices Safety Standard IEC 60947-5-8 |
Standard Verified | IEC 60947-5-8 / ISO 10218-1 | — | Audited per Enabling Devices Safety Standard IEC 60947-5-8 |
Contacts Verified | 2 Normally Open + 1 Normally Closed | N | Audited per Enabling Devices Safety Standard IEC 60947-5-8 |
System Interface Compatibility Standard | Integrates into handheld teach pendants or direct robot base safety inputs | Standard | Supported physical and electronic mating connections |
Select a verified physical variant below to inspect continuous ratings, peak torque/force envelopes, and dimension comparisons.
Every application below reflects documented load capabilities, thermal equilibrium boundaries, and kinematics integration for 3-Position Ergonomic Enabling Teach Pendant Switch.
Environment: Automated production facilities and manufacturing cells
Demanding precision positioning and repeatability requirements under high-duty continuous operation.
Provides calibrated 3-Position Ergonomic Enabling Teach Pendant Switch performance adhering strictly to ISO 13849-1 / ISO 13849-2 · IEC 62061 · ISO 10218-1/2 (Industrial Robots) · ISO/TS 15066 (Cobots).
Environment: Automated production facilities and manufacturing cells
Demanding precision positioning and repeatability requirements under high-duty continuous operation.
Provides calibrated 3-Position Ergonomic Enabling Teach Pendant Switch performance adhering strictly to ISO 13849-1 / ISO 13849-2 · IEC 62061 · ISO 10218-1/2 (Industrial Robots) · ISO/TS 15066 (Cobots).
Environment: Automated production facilities and manufacturing cells
Demanding precision positioning and repeatability requirements under high-duty continuous operation.
Provides calibrated 3-Position Ergonomic Enabling Teach Pendant Switch performance adhering strictly to ISO 13849-1 / ISO 13849-2 · IEC 62061 · ISO 10218-1/2 (Industrial Robots) · ISO/TS 15066 (Cobots).
Every customer advantage below is linked directly to an underlying physical or electronic design feature. Operating boundaries and verification conditions are explicitly declared.
Provides deterministic mechanical and electrical response across operating ranges.
Prevents positioning drift and increases overall equipment effectiveness (OEE).
Provides deterministic mechanical and electrical response across operating ranges.
Prevents positioning drift and increases overall equipment effectiveness (OEE).
Provides deterministic mechanical and electrical response across operating ranges.
Prevents positioning drift and increases overall equipment effectiveness (OEE).
Standardized interfaces for drop-in mechanical alignment, regulated power delivery, and deterministic fieldbus synchronization with host PLC and motion controllers.
Integrates into handheld teach pendants or direct robot base safety inputs
Universal mounting in horizontal, vertical, or inverted orientations with precision dowel hole alignment.
48V DC Regulated Bus (24V–56V range)
Integrated field-oriented control or compatible with standard industrial AC/DC servo inverters.
Cycle Time ≤ 1.0 ms (Jitter < 1 µs)
Supports cyclic synchronized position (CSP), velocity (CSV), and torque (CST) operating modes.
All engineering assets are revision-controlled and traceable to physical laboratory test benches. Request calibrated files directly from our engineering desk without broken links.
IND-SAF-3POS-DEADMAN-PENDANT_ASSEMBLY.STEPAudited Lab Specification
Accurate C.G. Matrix
Official Documentation
Industrial-grade controller computing forward/inverse kinematics with integrated functional safety.
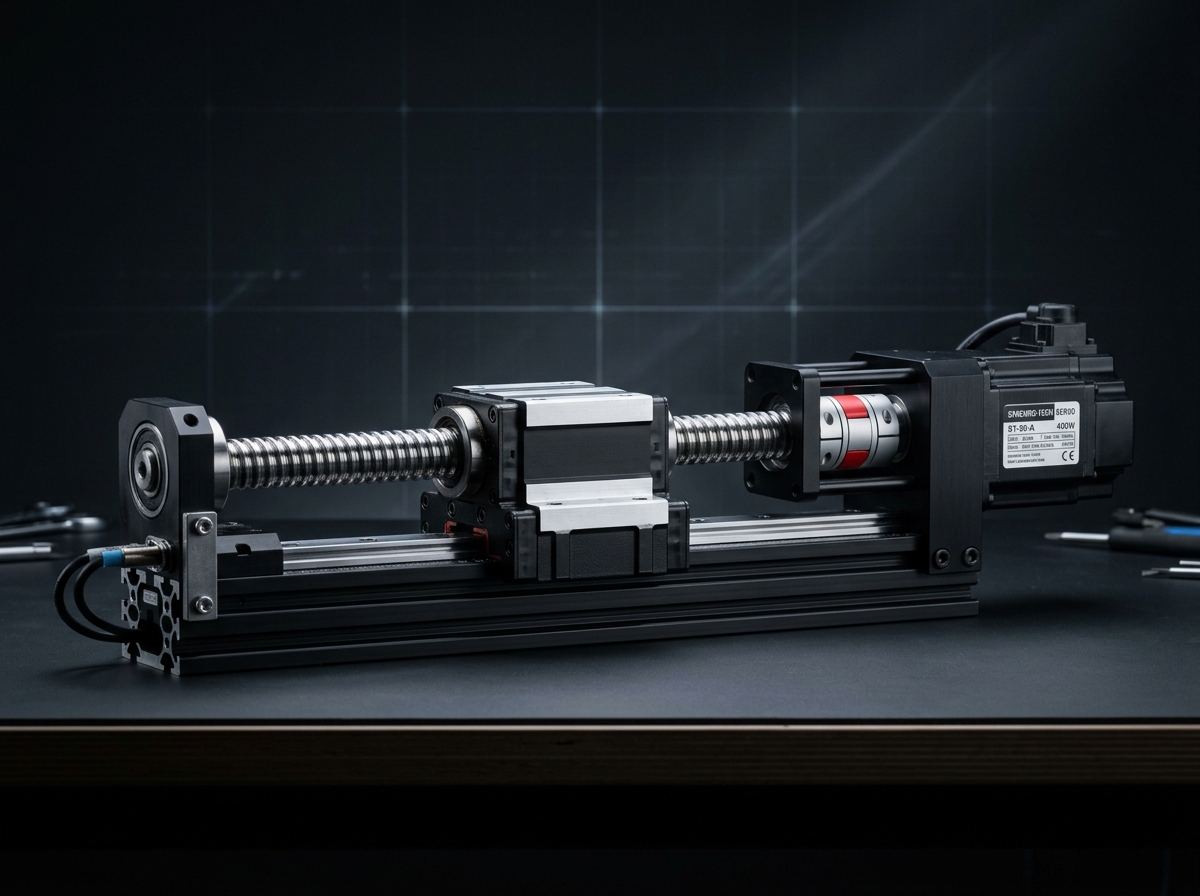
Precision guided linear motion module for controlled travel and repeatable positioning.
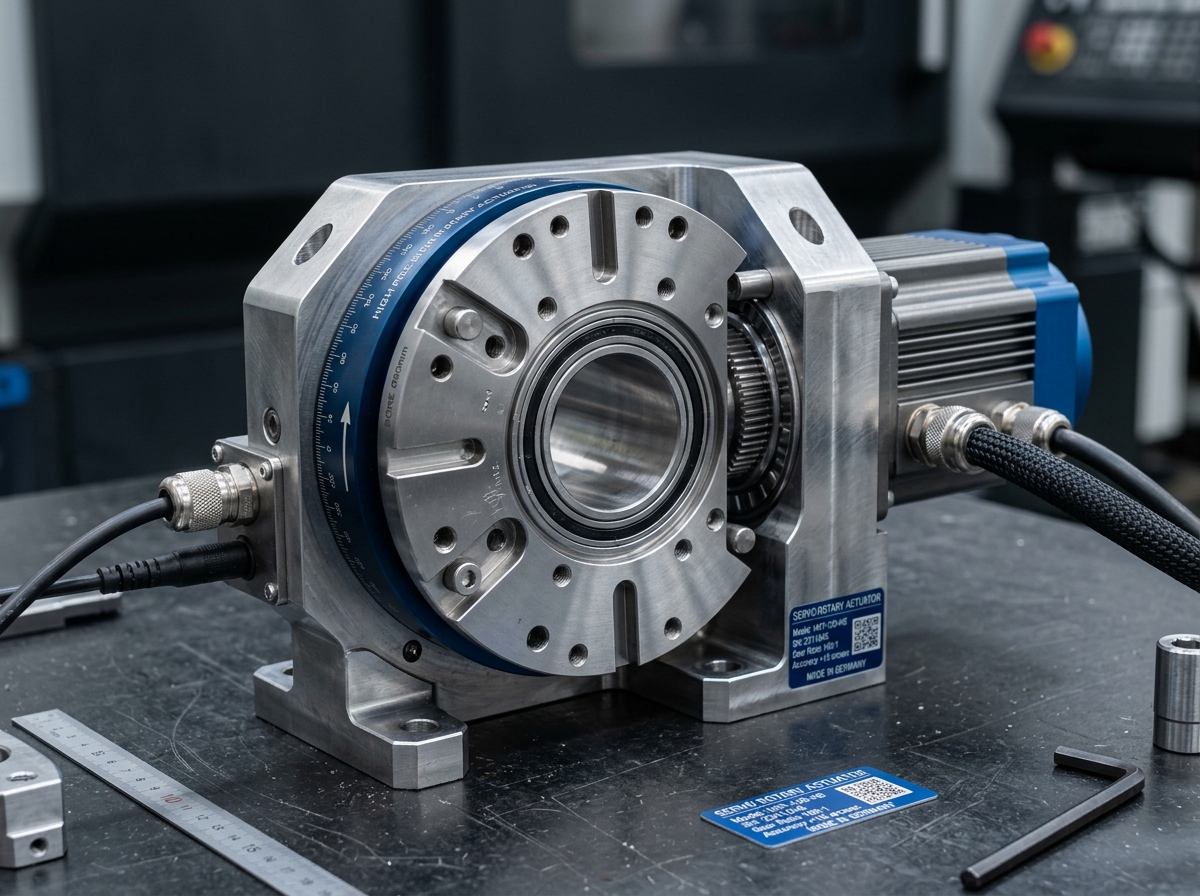
High-torque rotary actuation module with zero-backlash gearing for joint articulation.
Direct answers to common engineering questions regarding sizing verification, mechanical tolerances, fieldbus integration, and documentation for 3-Position Ergonomic Enabling Teach Pendant Switch.
Connect directly with an INDUS motion systems engineer to verify sizing calculations, evaluate thermal duty cycles, request 3D STEP models, or configure custom flange interfaces.
• Official NDA protected technical evaluation
• 24 business hours standard proposal response
• Factory direct engineering support & CAD integration