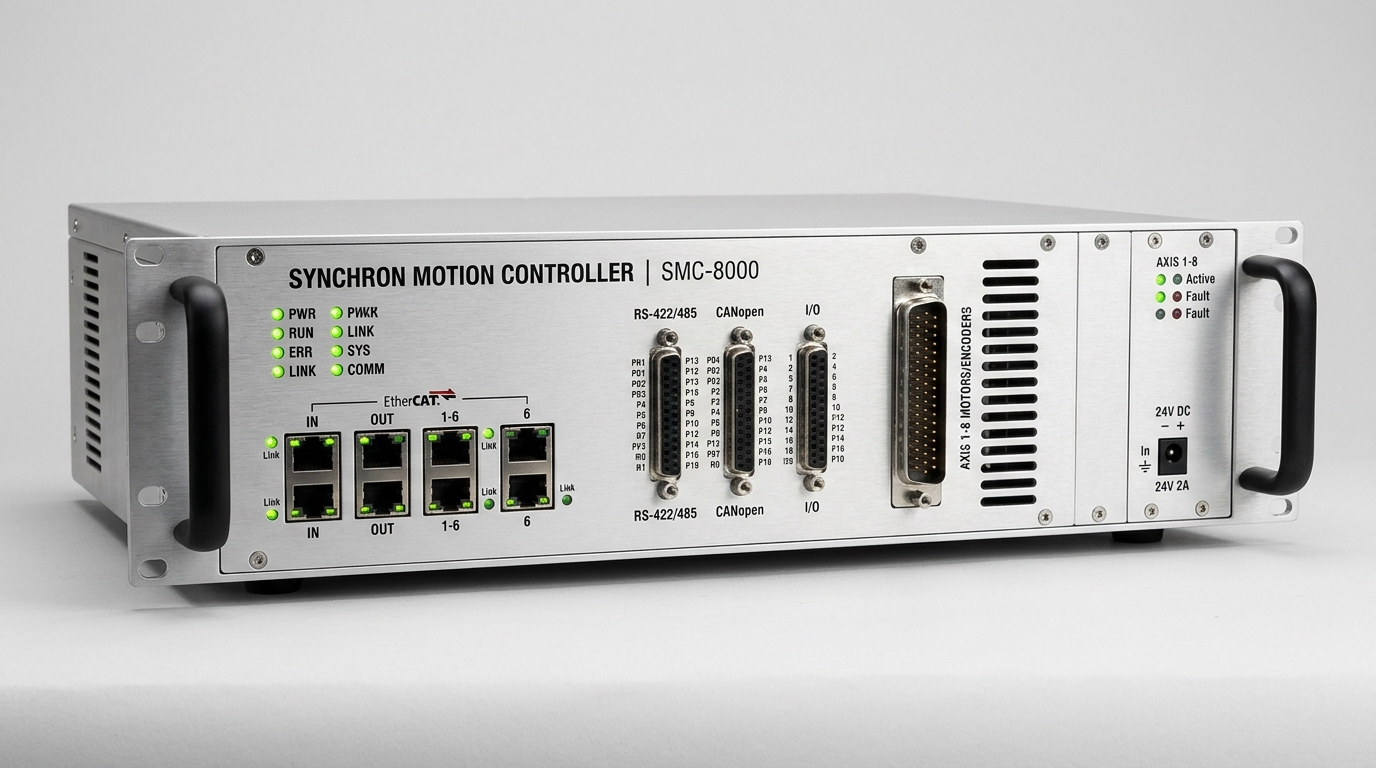
IND-CTL-MTC-064-EC
Verified
Control Systems
Motion Controllers
Centralized motion control engine synchronizing up to 64 coordinated axes over EtherCAT.
Synchronized Axe…Up to 64 Physical Axes axes
EtherCAT Bus Cyc…250 µs
Distributed Cloc…< 100 ns
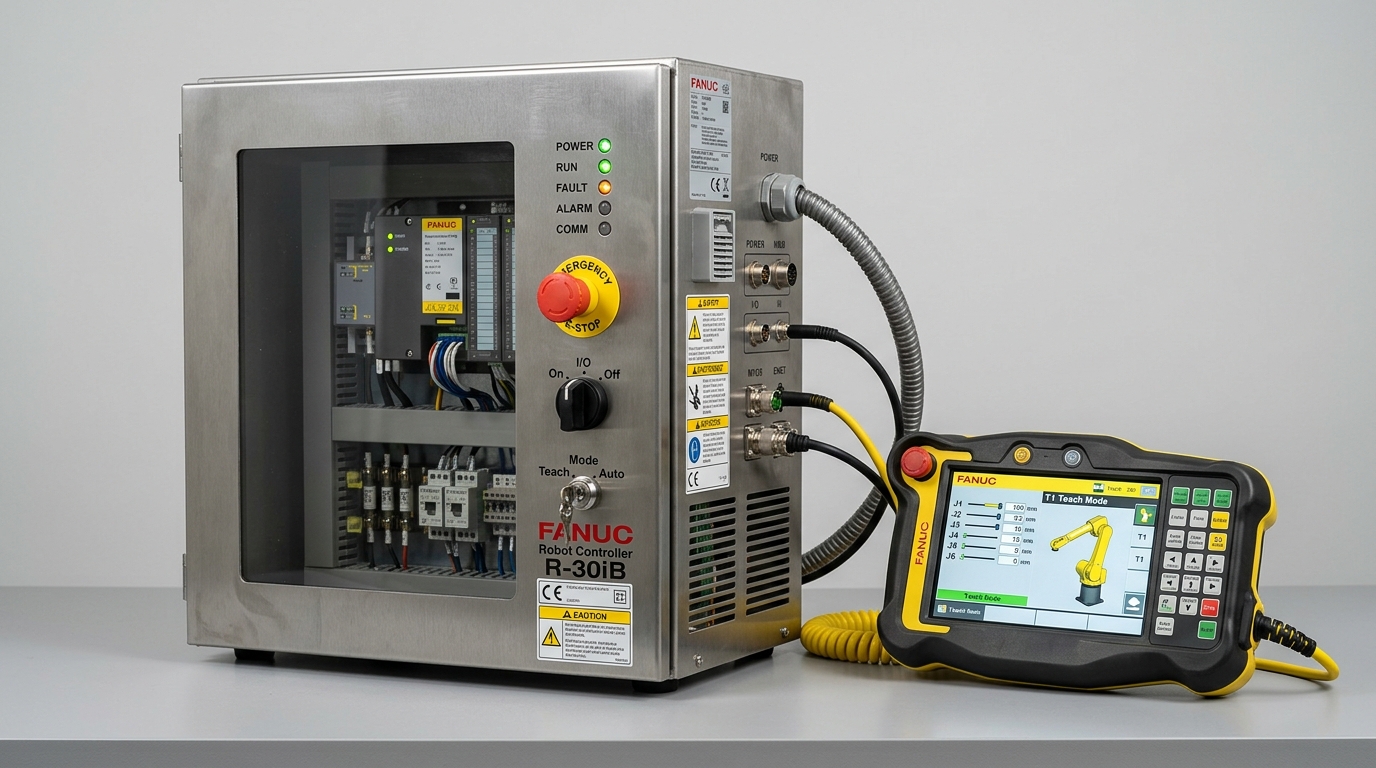
Industrial-grade controller computing forward/inverse kinematics with integrated functional safety.
Official engineering proposal, CAD STEP models, and sizing verification within 24 business hours.
Detailed mechatronic breakdown of Robot Controllers, highlighting functional architecture, physical operating mechanisms, and deployment role.
The IND-CTL-RBC-X86 is a high-performance central robot controller cabinet executing real-time kinematic transformation algorithms, trajectory generation, and safety interlocks for 4-axis, 6-axis, and parallel Delta robots. Powered by an industrial quad-core Intel x86 processor running a hard real-time Linux RTOS kernel, it coordinates multi-joint interpolation over an ultra-low-jitter EtherCAT fieldbus while providing an intuitive 10.1" IP65 teach pendant interface.
The IND-CTL-RBC-X86 is a high-performance central robot controller cabinet executing real-time kinematic transformation algorithms, trajectory generation, and safety interlocks for 4-axis, 6-axis, and parallel Delta robots. Powered by an industrial quad-core Intel x86 processor running a hard real-time Linux RTOS kernel, it coordinates multi-joint interpolation over an ultra-low-jitter EtherCAT fieldbus while providing an intuitive 10.1" IP65 teach pendant interface.
Addresses kinematic precision challenges by: Total axis count: 6 robot joints plus any external linear tracks or rotary positioner tables.
Acts as the central deterministic computing core or power amplifier, executing multi-axis motion trajectories and real-time fieldbus synchronization.
Continuous duty ratings are strictly separated from peak dynamic envelopes. All parameters reflect verified laboratory data traceable to INDUS Embedded Systems Hardware Lab Validation #14.
| Parameter | Specification Value | Unit | Notes & Test Conditions |
|---|---|---|---|
Coordinated Axis Capacity Verified | Up to 16 Axes | axes | 6 robot axes + 2 positioner axes + auxiliary conveyor tracks |
Trajectory Interpolation Cycle Rate Verified | 1.0 | ms | Configurable 500 µs to 2 ms |
EtherCAT Master Sync Jitter Verified | < 1.0 | µs | With distributed clocks (DC) enabled |
Processor Architecture Verified | Intel Core i5 Quad-Core Industrial Embedded CPU | hardware | Base clock 2.4 GHz, 16GB DDR4 ECC RAM |
Teach Pendant Display Verified | 10.1-inch Color Touchscreen | display | Ergonomic 3-position deadman switch & emergency stop button |
Functional Safety Certification Verified | SIL 3 / Cat 4 PLe | ISO 13849-1 | TÜV Rheinland certified dual-channel safety board |
Cabinet Supply Voltage Verified | 3-Phase 380 - 480 VAC, 50/60 Hz | voltage | Internal 24VDC 20A auxiliary bus supply |
Cabinet Protection Rating Verified | IP54 Standard (IP65 air-conditioned option) | rating | Powder-coated steel enclosure with filtered fans |
Every application below reflects documented load capabilities, thermal equilibrium boundaries, and kinematics integration for Robot Controllers.
Environment: Industrial assembly, inspection, and robotic workcells
Eliminating cycle time bottlenecks and cumulative tolerance stack-up.
Integrates directly via standardized mechanical flanges and communication interfaces.
Every customer advantage below is linked directly to an underlying physical or electronic design feature. Operating boundaries and verification conditions are explicitly declared.
Eliminates dimensional variance and structural backlash across all production lots.
Guarantees drop-in mechanical interchangeability and repeatable kinematic trajectories.
Resists torsional and bending deflection under dynamic acceleration cycles.
Prevents machine vibration chatter and protects sensitive end-of-arm tooling.
Enables plug-and-play communication and rapid electrical integration.
Cuts system commissioning time by up to 50% and simplifies diagnostic tracing.
Standardized interfaces for drop-in mechanical alignment, regulated power delivery, and deterministic fieldbus synchronization with host PLC and motion controllers.
Standard Rittal Floor/Wall Enclosure
Vertical upright mounting with minimum 150mm clearance for ventilation
380 - 480 VAC 3-Phase + Neutral + PE, 50/60 Hz
Integrated internal drive rack or external modular servo drives
Sync Cycle: 1 ms deterministic control cycle
Supports cyclic synchronized position (CSP), velocity (CSV), and torque (CST) operating modes.
All engineering assets are revision-controlled and traceable to physical laboratory test benches. Request calibrated files directly from our engineering desk without broken links.
IND-ROBOT-CONTROLLERS_ASSEMBLY.STEPAudited Lab Specification
Accurate C.G. Matrix
Official Documentation
Centralized motion control engine synchronizing up to 64 coordinated axes over EtherCAT.
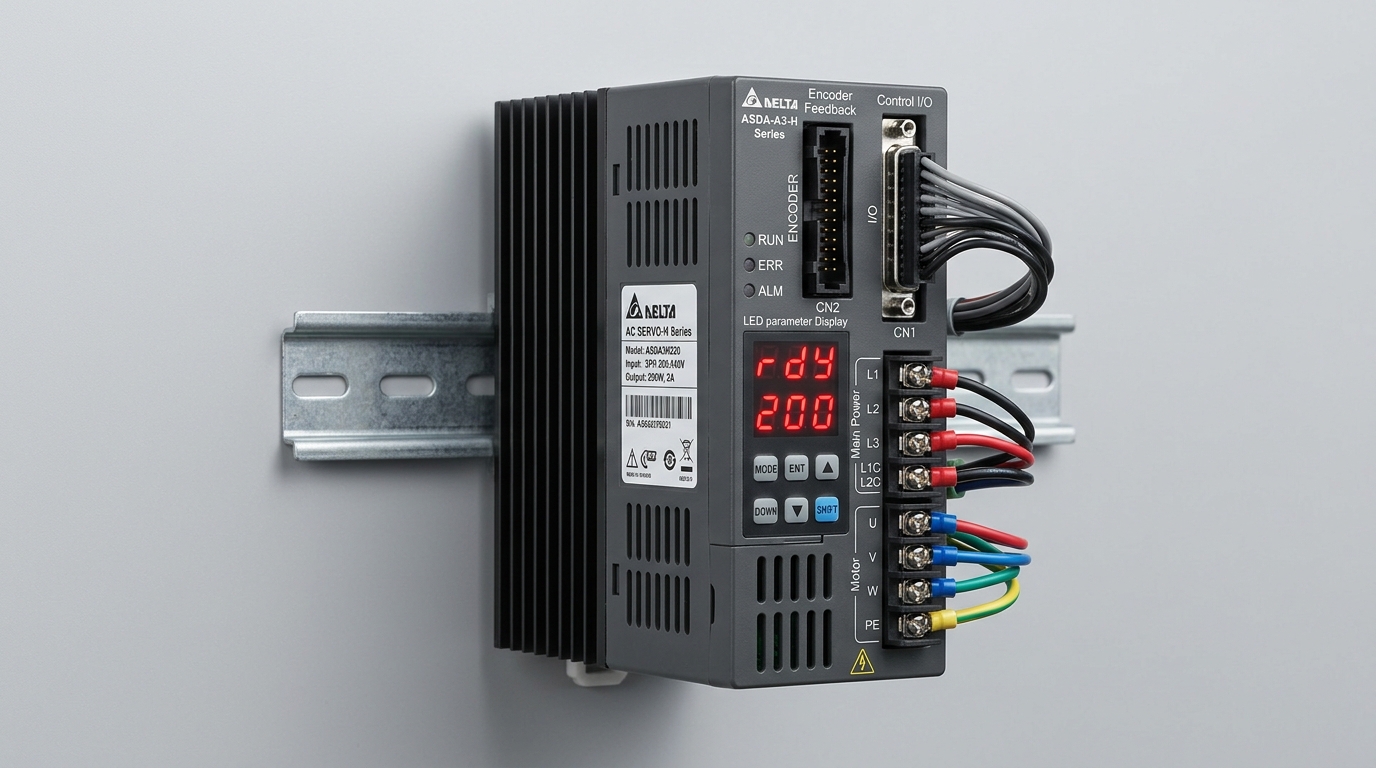
Compact multi-axis digital servo amplifier regulating current, velocity, and position loops.
Flexible multi-axis platform for complex welding, machine tending, and precision assembly tasks.
Direct answers to common engineering questions regarding sizing verification, mechanical tolerances, fieldbus integration, and documentation for Robot Controllers.
Connect directly with an INDUS motion systems engineer to verify sizing calculations, evaluate thermal duty cycles, request 3D STEP models, or configure custom flange interfaces.
• Official NDA protected technical evaluation
• 24 business hours standard proposal response
• Factory direct engineering support & CAD integration