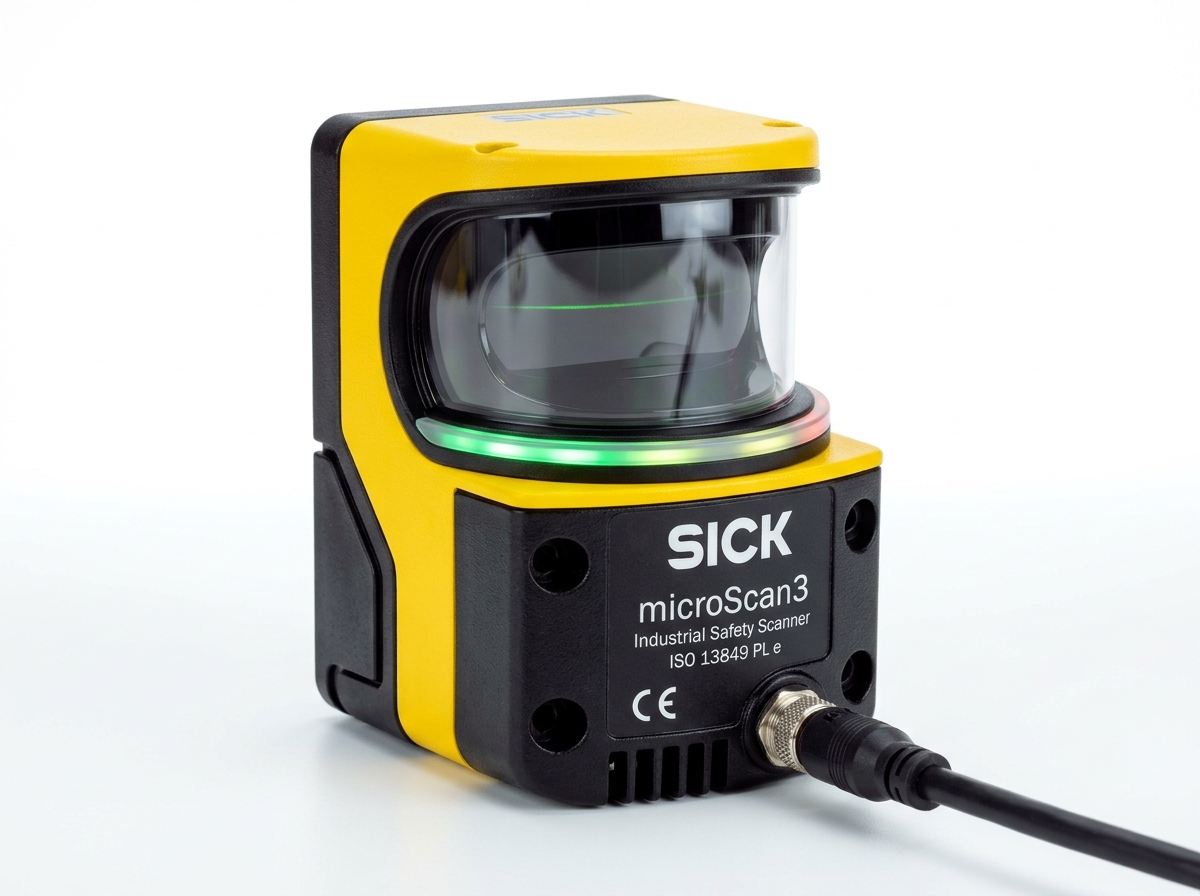
Safety Laser Area Scanner with Dynamic Field Switching (Type 3 / SIL 2 / PLd)
Creates configurable safety warning and protective stop fields around moving robots and mobile AGV chassis.
Safety laser scanners, Type 4 light curtains, modular safety PLCs, and edge IIoT gateways
Dynamic safety laser area scanners, Type 4 light curtains, modular safety PLCs, TSN managed Ethernet switches, and industrial edge AI compute.


Creates configurable safety warning and protective stop fields around moving robots and mobile AGV chassis.

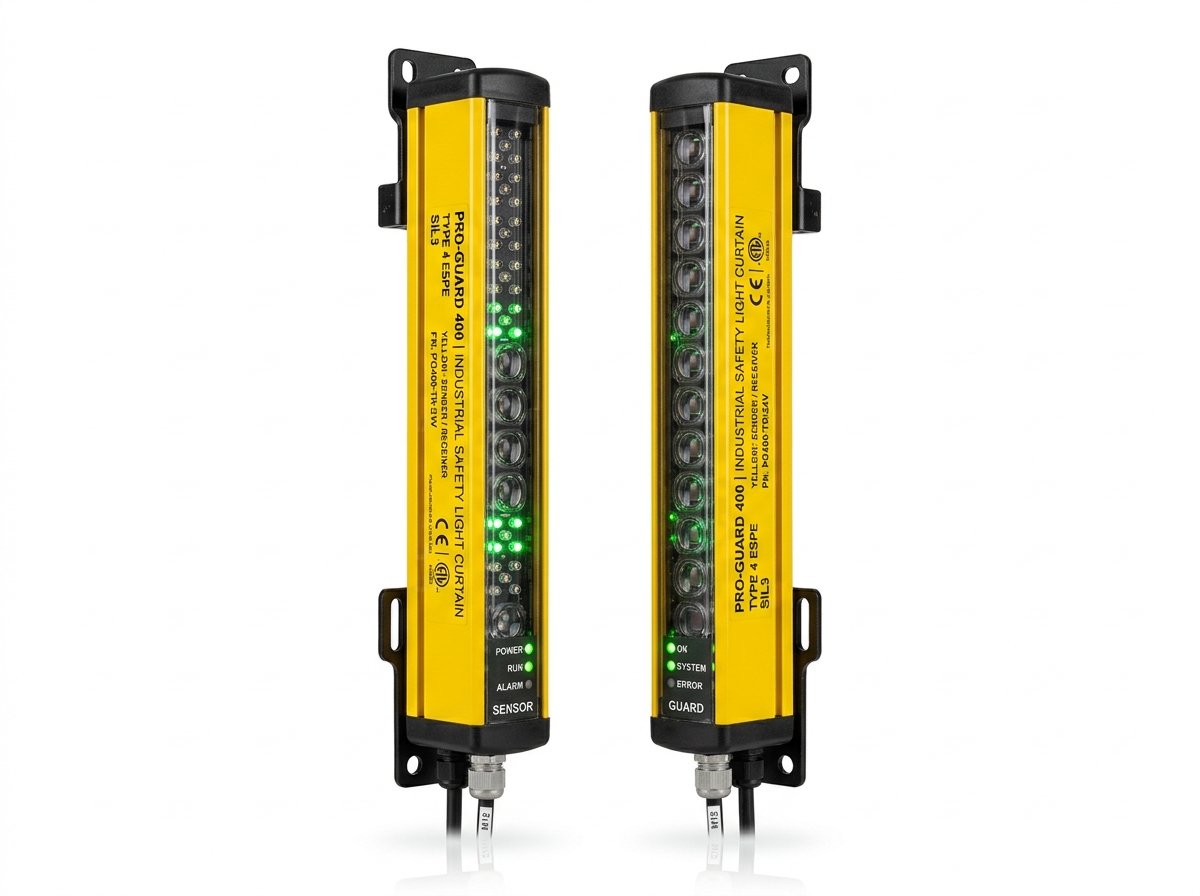
Point-of-operation hand and finger protection at machine openings with built-in conveyor muting logic.

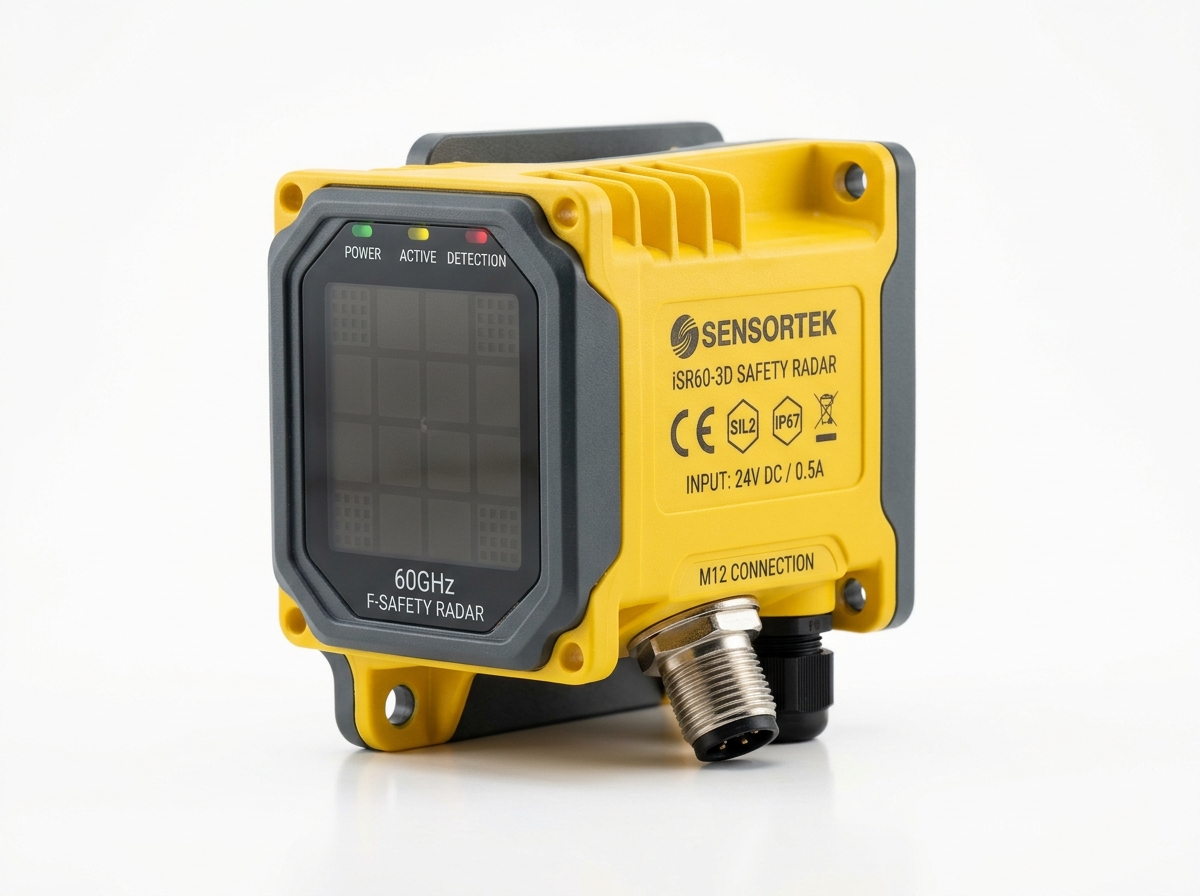
Guarantees personnel detection in harsh wood dust, welding sparks, metal swarf, and steam environments where optical sensors trip falsely.

Eliminates physical safety fences by creating dynamic 3D virtual protective safety cages around operating robot arms.

Floor-level area detection that detects human presence whenever an operator steps into a hazardous robot work area.

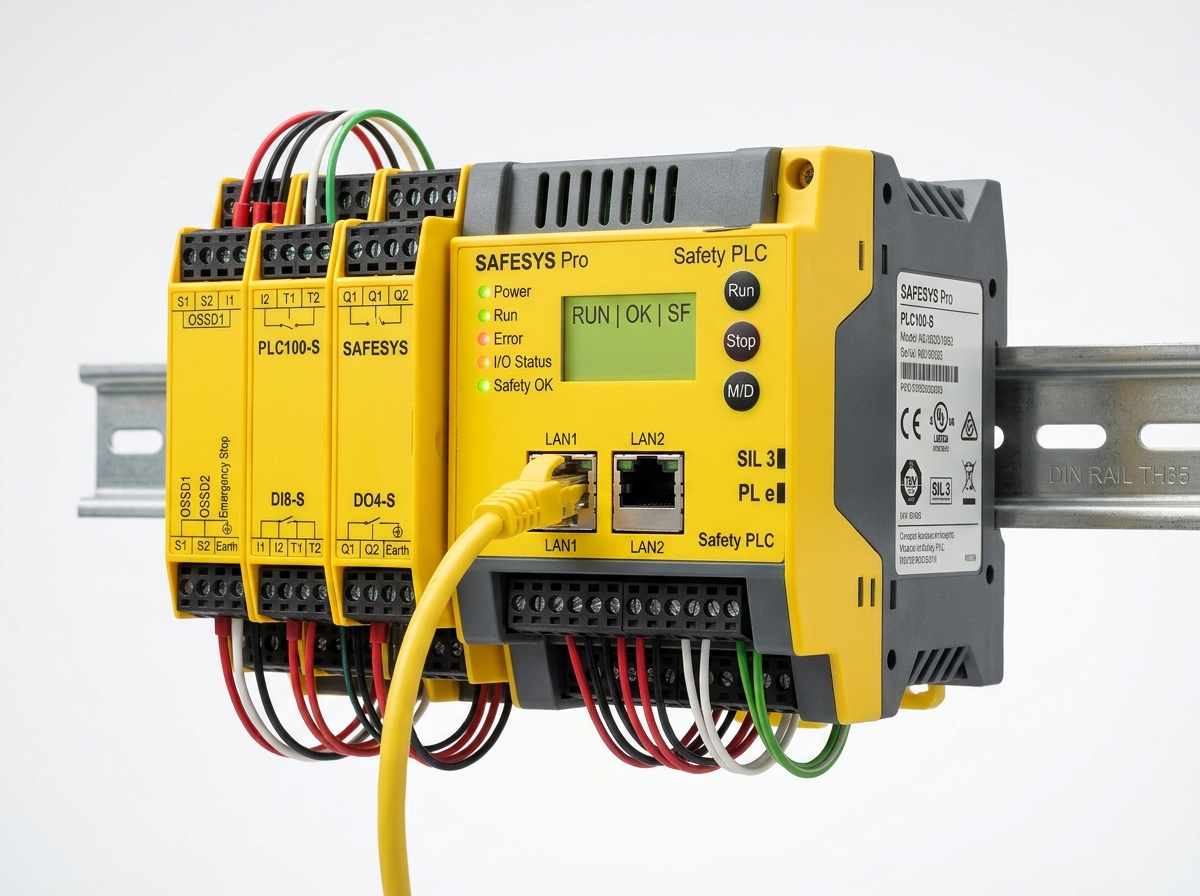
Centralized execution of safety logic functions (e-stops, light curtains, interlocks, muting, and Safe Motion) with certified SIL 3 architecture.

Monitors robot perimeter fence safety doors, preventing defeat or tampering via unique RFID transponder pairing.

Adds certified Safe Limited Speed (SLS) and Safe Operating Stop (SOS) to legacy servo drives without replacing motor amplifiers.

Evaluates emergency stop buttons, interlock switches, and light curtains for small standalone machines without a safety PLC.

Gives crane and robot operators mobile freedom around giant workcells with certified failsafe wireless emergency stop.

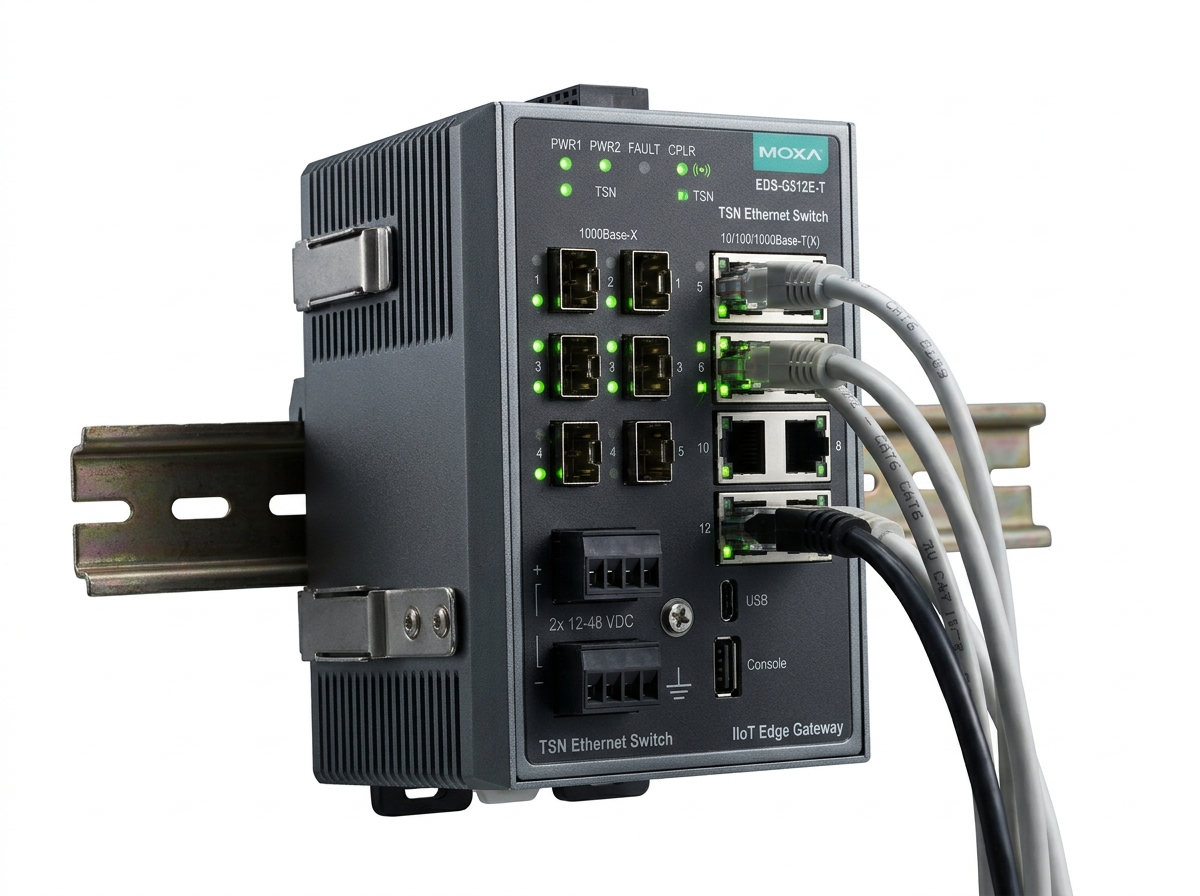
Provides deterministic, sub-microsecond scheduled Ethernet packet delivery for converged OT/IT robotic traffic on a shared physical cable.

Connects intelligent end-of-arm grippers, laser distance sensors, and RFID heads directly to fieldbus with zero electrical cabinet footprint.

Publishes standardized semantic machine models (OPC UA Companion Specs) from robot controllers directly into cloud data lakes and MES.

Provides ultra-reliable low-latency wireless communication (URLLC) for untethered autonomous mobile robots (AMRs) across large logistics facilities.

Delivers zero-packet-drop wireless roaming for mobile robots navigating high-multipath metallic factory environments.

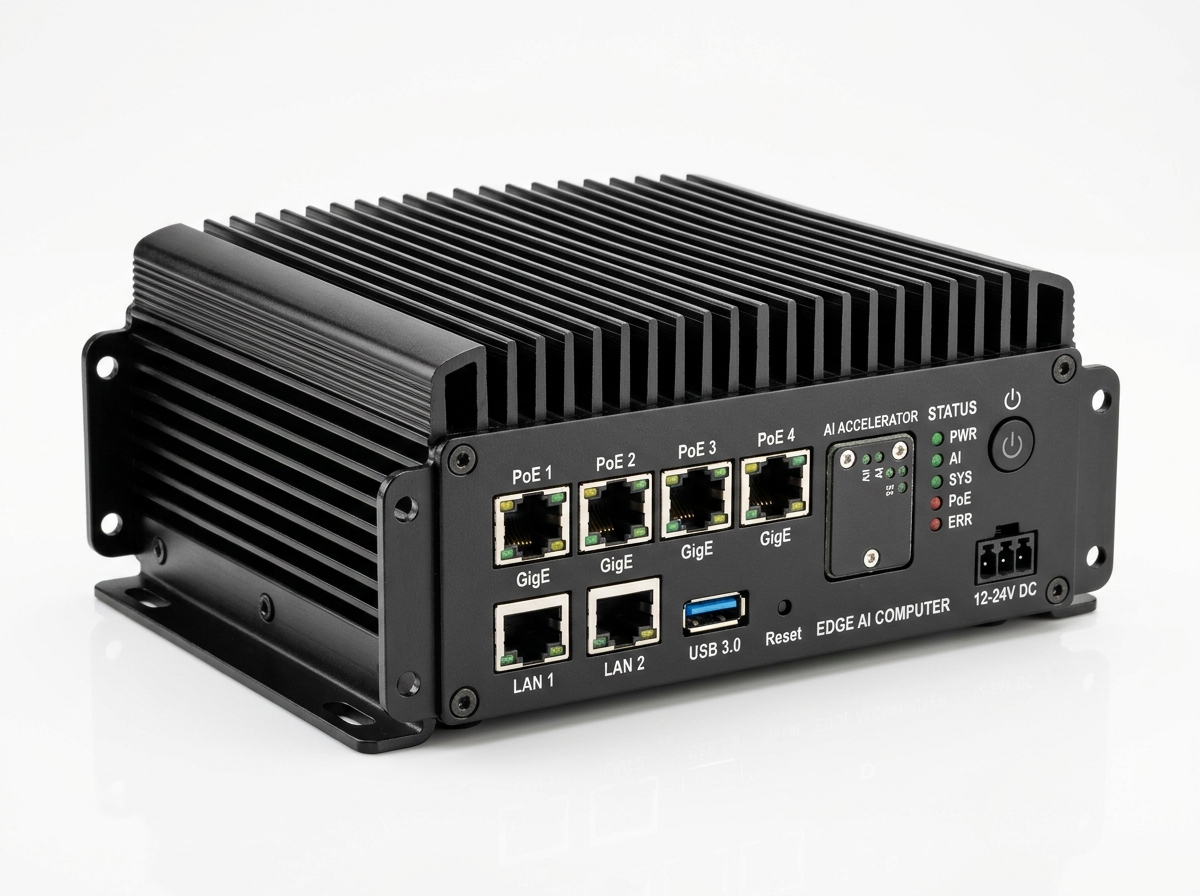
Executes deep learning object detection, 3D point cloud segmentation, and defect classification directly on the robot arm or mobile chassis.

Detects early-stage bearing fluting, gear tooth pitting, and mechanical imbalance on robot reducer gearboxes before functional failure occurs.

Non-invasively diagnoses motor rotor bar faults, stator winding short circuits, and mechanical transmission binding from electrical cabinet.

Counts microscopic ferrous and non-ferrous metallic wear particles in robot gearbox oil loops, preventing sudden gear tooth catastrophic seizure.

Guarantees zero communication loss during physical cable cuts in safety-critical automated manufacturing cells.
Specifying the appropriate robotic drivetrain and automation hardware requires a holistic evaluation of mechanical stiffness, duty cycle thermals, reflected inertia, and fieldbus communication latency.
Validated manufacturing tasks where Safety & Intelligent Systems delivers proven precision and uptime.
Automotive Powertrain & EV Battery Assembly
Production VerifiedSemiconductor Wafer Transfer & Cleanroom Metrology
Production VerifiedCNC High-Speed Milling & Robotic Machine Tending
Production VerifiedAutomated Packaging, Sortation & Case Palletizing
Production VerifiedAerospace Composite Drilling & Rivet Inspection
Production VerifiedMedical Device Precision Micromanipulation
Production VerifiedInteroperable motion components and engineering sizing utilities.
Our application engineers can verify inertia ratios, motor torque curves, duty cycle thermals, and fieldbus synchronization parameters for your machinery before purchase.