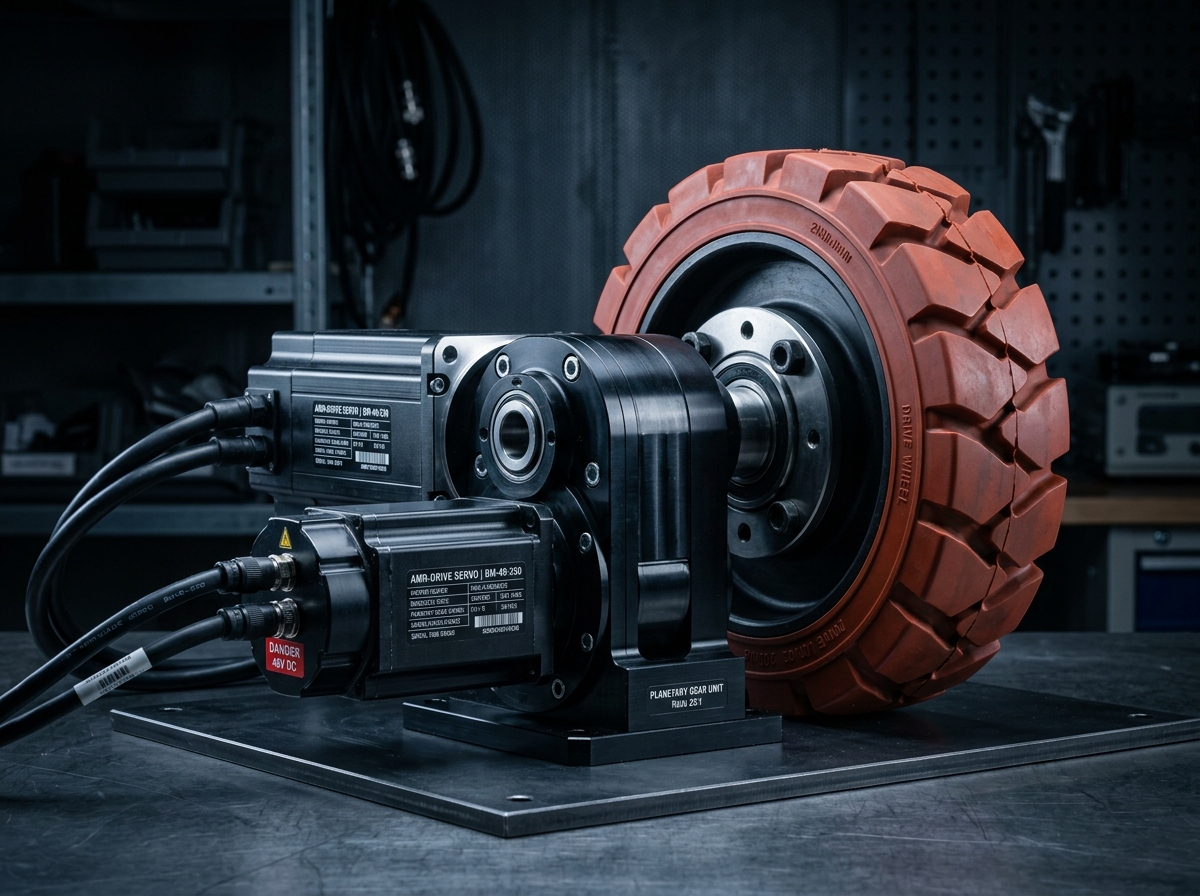
IND-WHL-DRV-200-BLDC
Verified
Robotic Wheels
Drive Wheels
Traction wheel unit with integrated planetary gearbox and electromagnetic brake.
Wheel Outer Diam…200 mm
Tread Width75 mm
Max Static Radia…850 kg
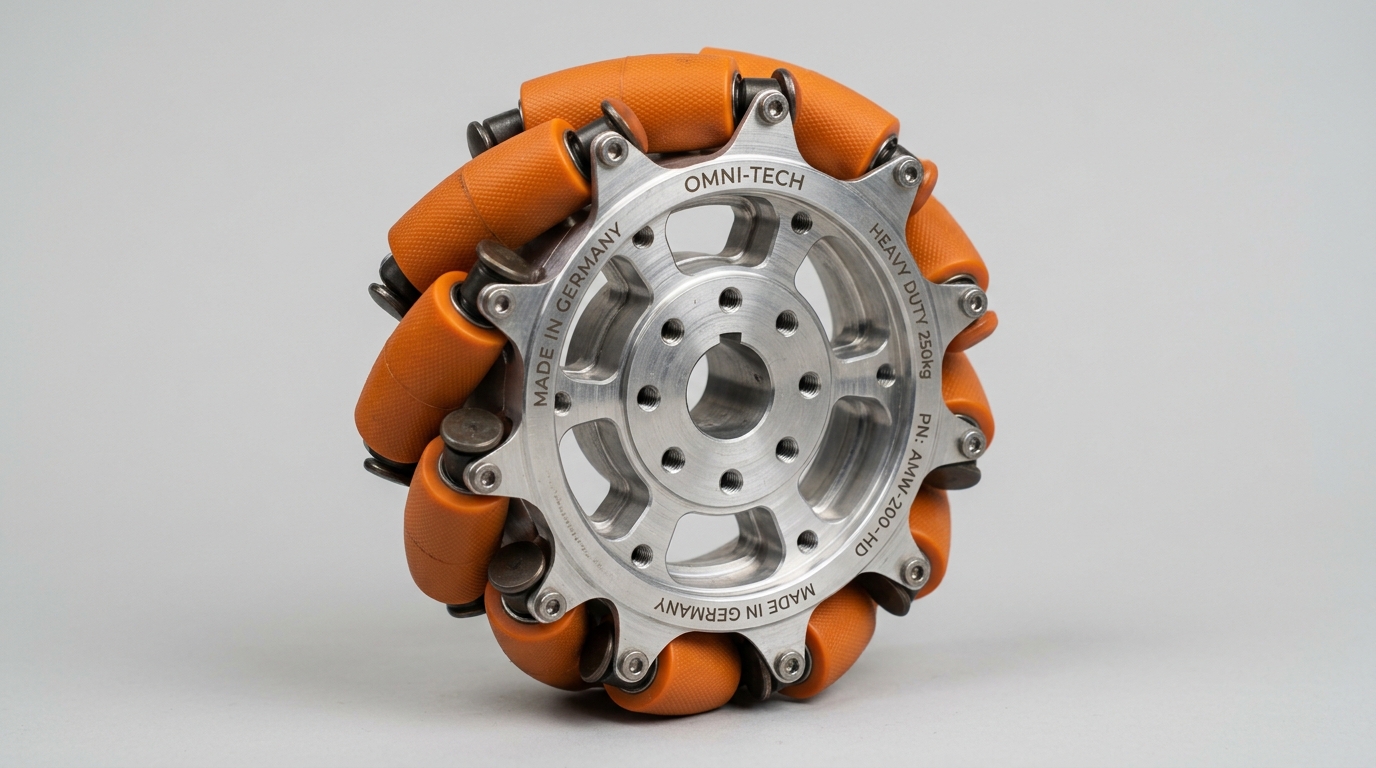
Multi-roller wheel allowing forward traction while rolling freely in transverse directions.
Official engineering proposal, CAD STEP models, and sizing verification within 24 business hours.
Detailed mechatronic breakdown of Omni Wheels, highlighting functional architecture, physical operating mechanisms, and deployment role.
The IND-WHL-OMN-150 is a multi-directional wheel engineered with two rows of staggered barrel rollers angled at 90° to the primary wheel hub. Driven directly, it provides forward/reverse traction while allowing free low-friction lateral slip. This enables holonomic 3-DoF mobile chassis maneuvering in cramped factory aisles.
The IND-WHL-OMN-150 is a multi-directional wheel engineered with two rows of staggered barrel rollers angled at 90° to the primary wheel hub. Driven directly, it provides forward/reverse traction while allowing free low-friction lateral slip. This enables holonomic 3-DoF mobile chassis maneuvering in cramped factory aisles.
Addresses kinematic precision challenges by: Total chassis mass distributed across omni contact points.
Executes high-speed multi-axis kinematic manipulation, assembly, welding, or material handling tasks within structured automated cells.
Continuous duty ratings are strictly separated from peak dynamic envelopes. All parameters reflect verified laboratory data traceable to INDUS Multidirectional Platform Dynamometer #2.
| Parameter | Specification Value | Unit | Notes & Test Conditions |
|---|---|---|---|
Wheel Outer Diameter Verified | 152 | mm | Roller outer envelope |
Hub Width Verified | 48 | mm | Axial bore length |
Max Static Radial Payload Verified | 350 | kg | At zero motion |
Rated Dynamic Payload Verified | 200 | kg | Continuous operation at 1.2 m/s |
Perimeter Roller Quantity Verified | 14 | rollers | Dual staggered row design |
Roller Material Verified | Polyurethane 90 Shore A on Stainless Shaft | material | Dual sealed precision ball bearings |
Axial Rolling Resistance Coefficient Verified | 0.018 | coefficient | Smooth industrial epoxy floor |
Maximum Operating Speed Verified | 2.0 | m/s | Continuous rolling |
Every application below reflects documented load capabilities, thermal equilibrium boundaries, and kinematics integration for Omni Wheels.
Environment: Industrial assembly, inspection, and robotic workcells
Eliminating cycle time bottlenecks and cumulative tolerance stack-up.
Integrates directly via standardized mechanical flanges and communication interfaces.
Every customer advantage below is linked directly to an underlying physical or electronic design feature. Operating boundaries and verification conditions are explicitly declared.
Eliminates dimensional variance and structural backlash across all production lots.
Guarantees drop-in mechanical interchangeability and repeatable kinematic trajectories.
Resists torsional and bending deflection under dynamic acceleration cycles.
Prevents machine vibration chatter and protects sensitive end-of-arm tooling.
Enables plug-and-play communication and rapid electrical integration.
Cuts system commissioning time by up to 50% and simplifies diagnostic tracing.
Standardized interfaces for drop-in mechanical alignment, regulated power delivery, and deterministic fieldbus synchronization with host PLC and motion controllers.
Direct Keyed Shaft Bore (DIN 6885 Keyway)
Typically mounted in 3-wheel (120°) or 4-wheel (90°) radial configurations
Passive mechanical wheel; driven by external gearmotor
Multi-axis kinematics controller with omni-drive inverse matrix
Sync Cycle: N/A
Supports cyclic synchronized position (CSP), velocity (CSV), and torque (CST) operating modes.
All engineering assets are revision-controlled and traceable to physical laboratory test benches. Request calibrated files directly from our engineering desk without broken links.
IND-OMNI_ASSEMBLY.STEPAudited Lab Specification
Accurate C.G. Matrix
Official Documentation
Traction wheel unit with integrated planetary gearbox and electromagnetic brake.
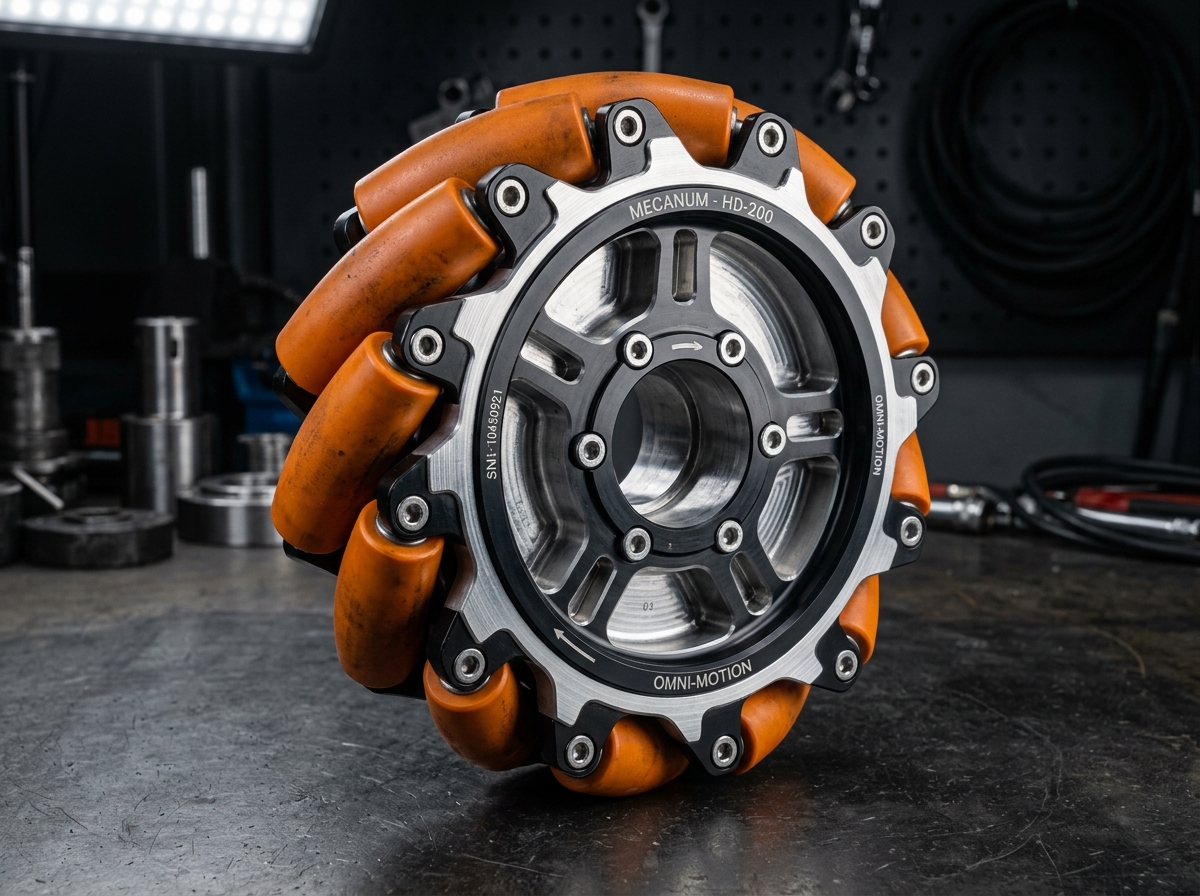
45-degree angled roller wheel enabling full holonomic movement on flat industrial floors.
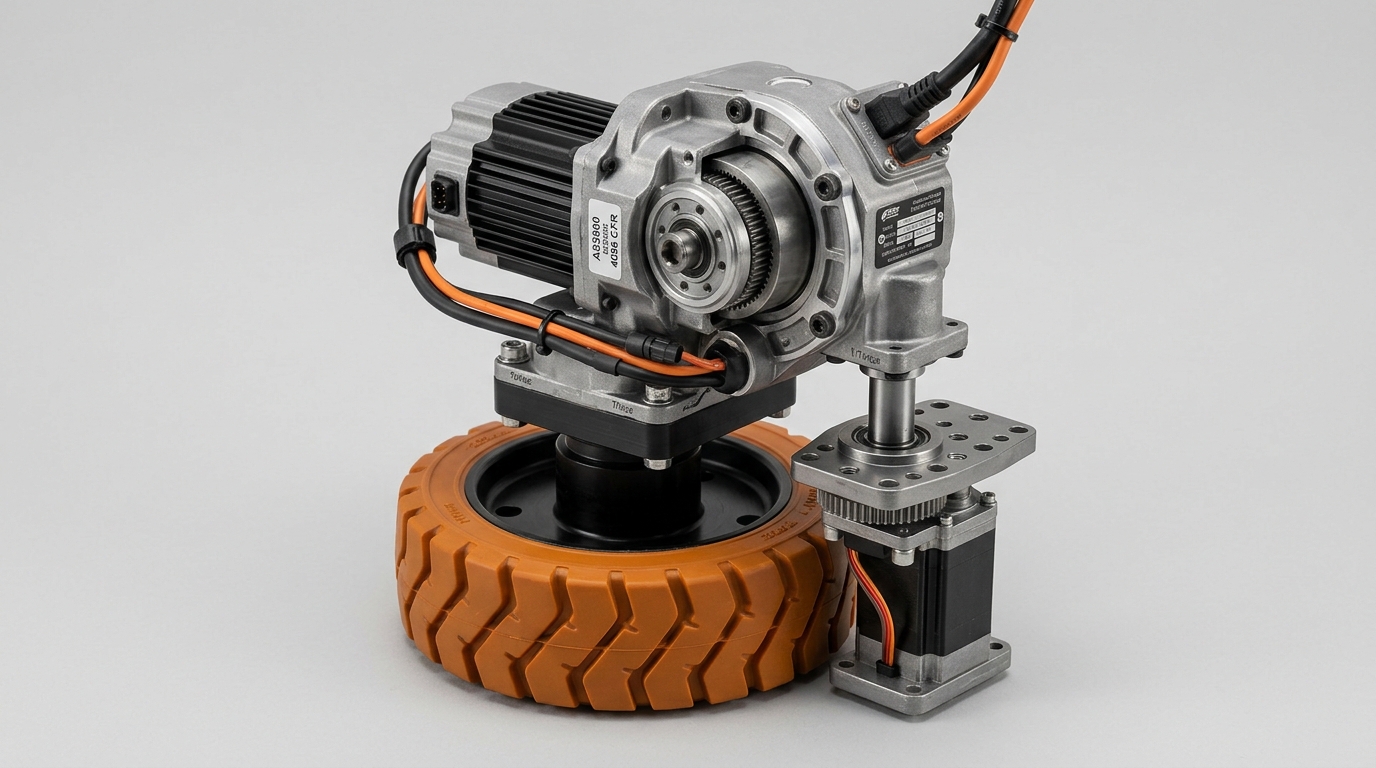
All-in-one traction, steering, reduction, and feedback unit for fast vehicle chassis integration.
Direct answers to common engineering questions regarding sizing verification, mechanical tolerances, fieldbus integration, and documentation for Omni Wheels.
Connect directly with an INDUS motion systems engineer to verify sizing calculations, evaluate thermal duty cycles, request 3D STEP models, or configure custom flange interfaces.
• Official NDA protected technical evaluation
• 24 business hours standard proposal response
• Factory direct engineering support & CAD integration